ContactKernels: Adaptive Proposals using Geometry-Conditioned Wrenches for Contact-Rich Manipulation
Motivation
Problem: Controller Uncertainty in Contact-rich Manipulation settings
Goal: Improve uncertainty using Contact information
Operational Space Control commanding ground truth hole pose, exhibits steady state error that prevents tight tolerance insertion
Text
Sampling-based Model Predictive Control
Sampling-based MPC provides necessary tooling for adaptation. MPPI/PS can be used to sample around
Sampling-based Model Predictive Control provides necessary language for adapting Operational Space Control, making it suitable for contact-implicit control for tasks such as insertion.
However, the default isotropic gaussian proposal kernel for sampling is inefficient
Behaviours that mimic the wiggly behaviour that humans employ before inserting a key into the hole - while being informed by local contact
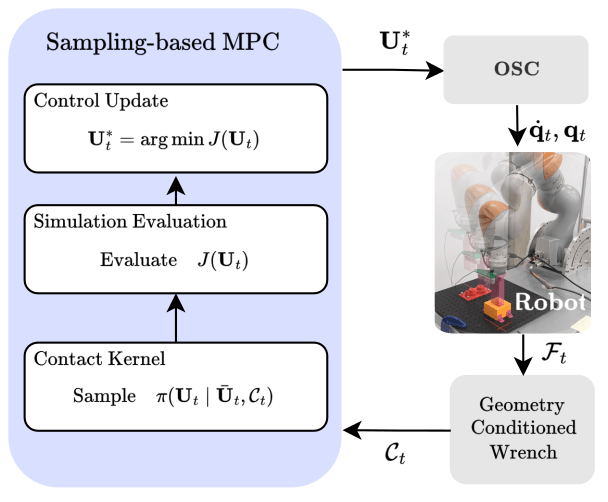
ContactKernels
- Sampling-based MPC (MPPI/PS) for insertion task
- Contact-conditioned proposal kernel
SMPC with Isotropic Gaussian Kernel
SMPC with proposed contact-conditioned Kernel
Contributions
System Overview
Results
ContactKernels enables
- Sample efficient adaptation to local contact
- Improved Insertion success across geometries
- Improved Insertion times
Results
ContactKernels enables
- Sample efficient adaptation to local contact
- Improved Insertion success across geometries
- Improved Insertion times