Lecture 21: Task and Motion Planning
This is a live streamed presentation. You will automatically follow the presenter and see the slide they're currently on.
This is a live streamed presentation. You will automatically follow the presenter and see the slide they're currently on.
MIT 6.4210/2:
Robotic Manipulation
Fall 2022, Lecture 21
Follow live at https://slides.com/d/4rigVS4/live
(or later at https://slides.com/russtedrake/fall22-lec21)
/// Base type for all action primitives
class ActionPrimitiveInterface
{
  virtual bool IsCandidate(const State& state) const = 0;
  virtual Container GetOutcomes(const State& state) const = 0;
  virtual double EstimateActionCost(
      const State& current, const State& target) const = 0;
  virtual Container Execute(const State& state) = 0;
  virtual double Ranking() const = 0;
};
OpenDishwasherDoor
CloseDishwasherDoor
StartDishwasher
LoadSoapPacket
PullOutLowerRack
PullOutUpperRack
PullOutSilverwareRack
PushInLowerRack
PushInUpperRack
PushInSilverwareRack
PutPlateInDishwasher
ReorientMug
PutMugInDishwasher
OptimisticPutMugInDishwasher
PutSilverwareInDishwasher
PushUnmanipulableDish
SenseDishCounts
SenseDishToManipulate
work by Calder Phillips-Grafflin et al. at TRI
DishTaskState(const DishState& active_dish_state,
              int32_t clean_items_put_away, int32_t clean_items_in_dishwasher,
              int32_t dirty_items_in_dishwasher,
              int32_t dirty_items_available,
              const DishwasherState& current_dishwasher_state);

DishState(const RigidTransformd& dish_pose, DishType dish_type,
          DishProgress dish_progress, RackRequirement rack_required);

DishwasherState(bool known, bool door_open, bool lower_rack_out,
                bool upper_rack_out, bool silverware_rack_out,
                bool lower_rack_full, bool upper_rack_full,
                bool silverware_rack_full, bool started, bool soap_loaded);
enum class DishType : uint8_t {
Unknown = 0x00,
Mug = 0x01,
Plate = 0x02,
Silverware = 0x03
};
enum class RackRequirement : uint8_t {
Unknown = 0x00,
LowerRack = 0x01,
UpperRack = 0x02,
SilverwareRack = 0x03
};enum class DishProgress : uint8_t {
Unknown = 0x00,
Unmanipulable = 0x01,
LikelyManipulable = 0x02,
Sensed = 0x03,
OptimisticOriented = 0x04,
Oriented = 0x05,
Placed = 0x06,
Released = 0x07
};work by Calder Phillips-Grafflin et al. at TRI
https://en.wikipedia.org/wiki/Stanford_Research_Institute_Problem_Solver
/// Base type for all action primitives
class ActionPrimitiveInterface
{
  virtual bool IsCandidate(const State& state) const = 0;
  virtual Container GetOutcomes(const State& state) const = 0;
  ...
};
(define (domain gripper-strips)
   (:predicates (room ?r)
		(ball ?b)
		(gripper ?g)
		(at-robby ?r)
		(at ?b ?r)
		(free ?g)
		(carry ?o ?g))

   (:action move
       :parameters  (?from ?to)
       :precondition (and  (room ?from) (room ?to) (at-robby ?from))
       :effect (and  (at-robby ?to)
		     (not (at-robby ?from))))


   (:action pick
       :parameters (?obj ?room ?gripper)
       :precondition  (and  (ball ?obj) (room ?room) (gripper ?gripper)
			    (at ?obj ?room) (at-robby ?room) (free ?gripper))
       :effect (and (carry ?obj ?gripper)
		    (not (at ?obj ?room))
		    (not (free ?gripper))))


   (:action drop
       :parameters  (?obj  ?room ?gripper)
       :precondition  (and  (ball ?obj) (room ?room) (gripper ?gripper)
			    (carry ?obj ?gripper) (at-robby ?room))
       :effect (and (at ?obj ?room)
		    (free ?gripper)
		    (not (carry ?obj ?gripper)))))
https://github.com/SoarGroup/Domains-Planning-Domain-Definition-Language/blob/master/pddl/gripper.pddl
(define (problem strips-gripper4)
   (:domain gripper-strips)
   (:objects rooma roomb ball1 ball2 ball3 ball4 left right)
   (:init (room rooma)
          (room roomb)
          (ball ball1)
          (ball ball2)
          (ball ball3)
          (ball ball4)
          (gripper left)
          (gripper right)
          (at-robby rooma)
          (free left)
          (free right)
          (at ball1 rooma)
          (at ball2 rooma)
          (at ball3 rooma)
          (at ball4 rooma))
   (:goal (and (at ball1 roomb)
               (at ball2 roomb)
               (at ball3 roomb))))
https://github.com/SoarGroup/Domains-Planning-Domain-Definition-Language/blob/master/pddl/gripper-4.pddl
In the dish-loading example, we replan before each action to handle unexpected outcomes...
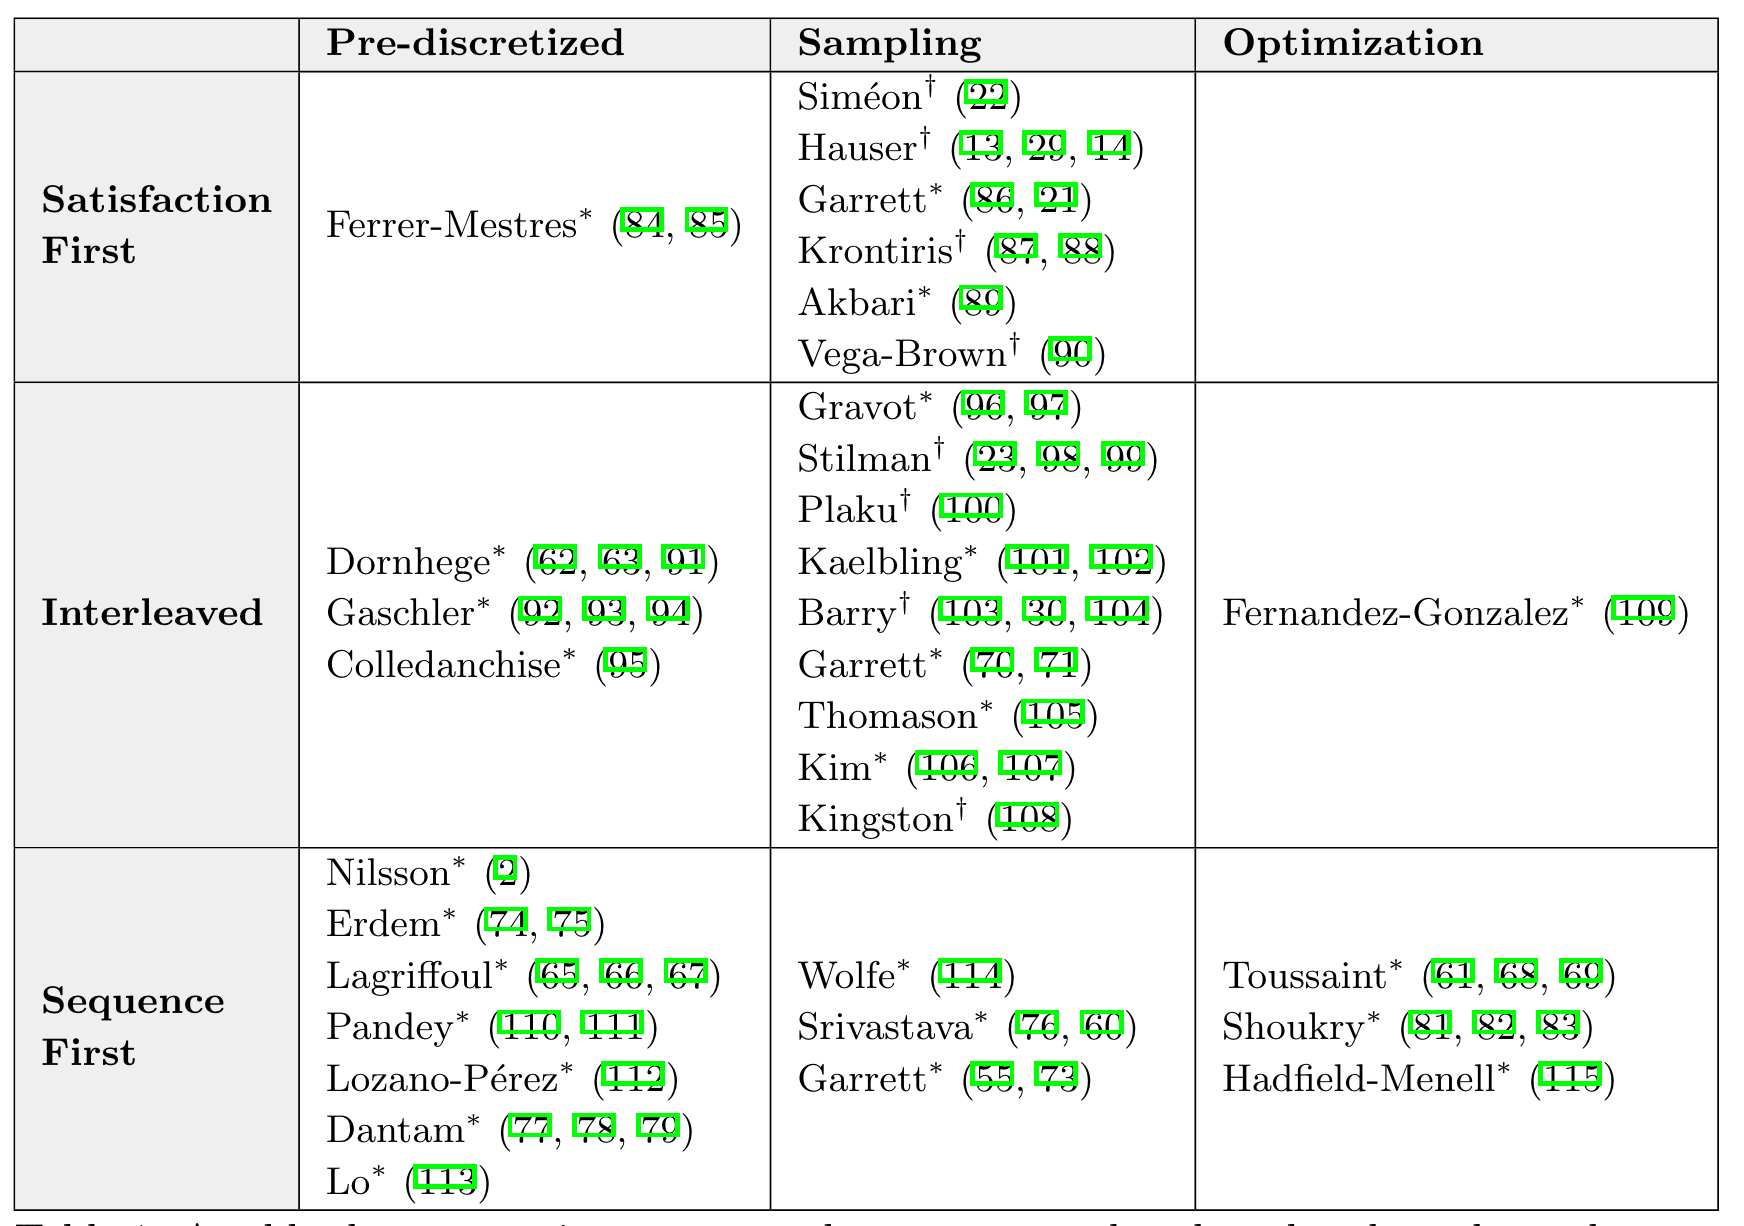
A nice survey (from Oct, 2020):
Logic-Geometric Programming
PDDLStream
Logic-Geometric Programming
PDDLStream
Danny Driess and Jung-Su Ha and Marc Toussaint, Deep Visual Reasoning: Learning to Predict Action Sequences for Task and Motion Planning from an Initial
Scene Image, Robotics: Science and Systems (R:SS) 2020.
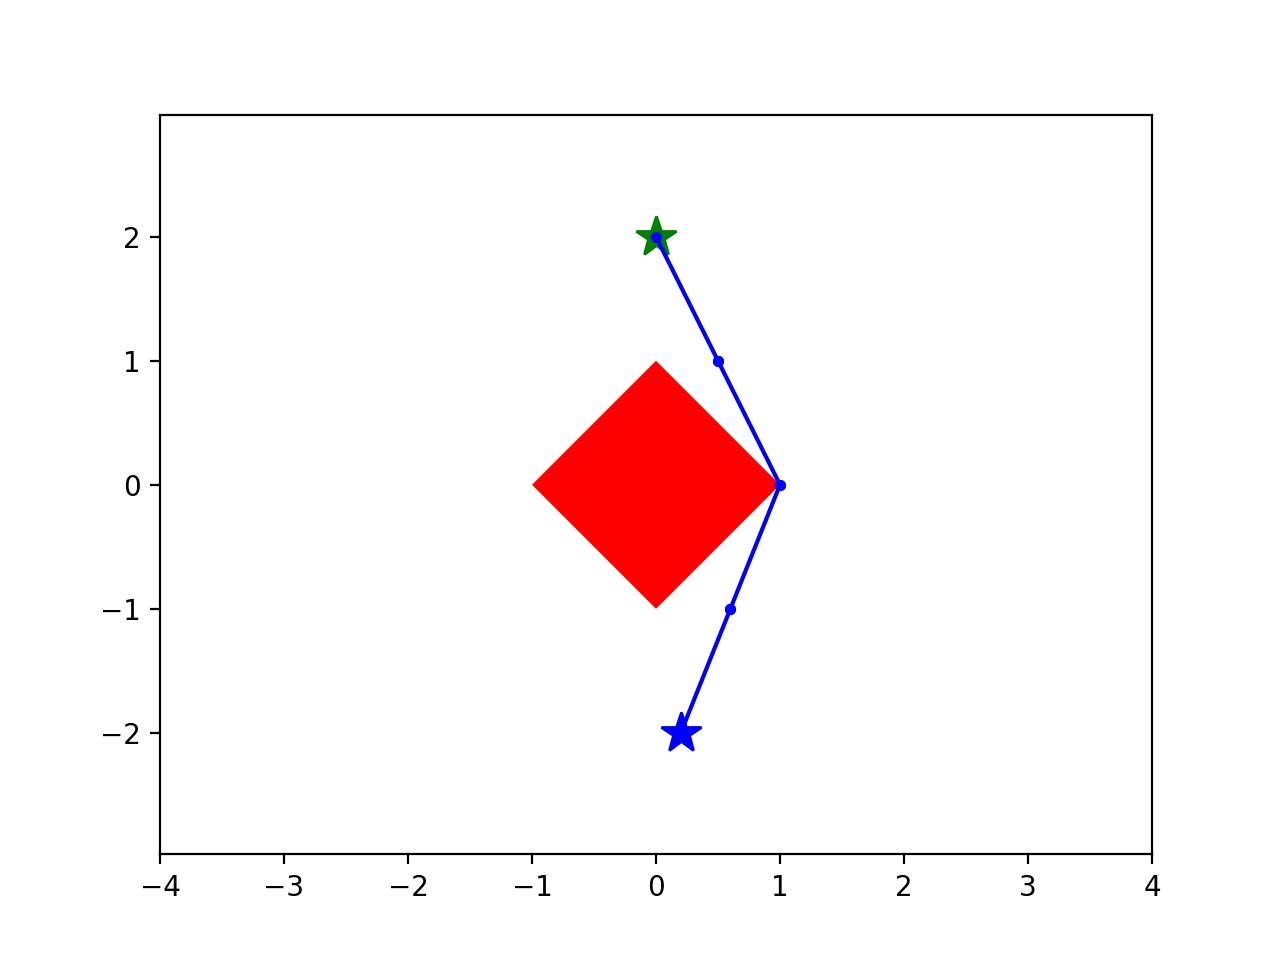
start
goal
collision-avoidance
(outside the \(L^1\) ball)
nonconvex
Convex relaxations provide lower bounds
Feasible solutions provide upper bounds
convex
convex
convex
convex
convex
Marc Toussaint and Jung-Su Ha and Danny Driess, Describing Physics For Physical Reasoning: Force-based Sequential Manipulation Planning, IEEE Robotics and Automation Letters 2020.
Logic-Geometric Programming
PDDLStream
Interleave sampling (from IK, or collision-free motion planner) with fast symbolic search.
Work by Savva Morozov
PDDLStream (by Caelan)
Work by Savva Morozov
And now Boyuan's presentation on
Large Language Models
Follow live at https://slides.com/d/EyfmqBY/live
(or later at slides.com/buoyancy99/deck)