Introduction: Anatomy of a
Manipulation System
MIT 6.4210/2: Robotic Manipulation
Fall 2023, Lecture 1
Follow live at https://slides.com/d/sE8qYNg/live
(or later at https://slides.com/russtedrake/fall23-lec01)
Course Info
Website: http://manipulation.mit.edu
6.4210 is a CI-M (Communication Intensive in the Major)
Communications Instructors from Comparative Media Studies/Writing
Recitations Fridays afternoons (starting Sept 15)
Logistics
- Students: Make sure you're on Piazza
- CI-M (6.4210) material on Canvas.
- Review the course guidelines.
- Read/comment on the lecture notes
- ~ weekly problem sets throughout the class, due Wed.
- Problem Set 1 released tomorrow (on the course calendar).
- Final project.
from the course website:
Today
- What do I mean by "manipulation"? (with examples!)
- The systems theory perspective
- Anatomy of a manipulation system
- Goals for the course
Matt Mason says
- Definition 1 (etymological). Manipulation refers to the activities performed by hands.
- ...
- Definition 5. Manipulation refers to an agent’s control of its environment through selective contact.
Matthew T. Mason. Toward Robotic Manipulation. Annual Review of Control, Robotics, and Autonomous Systems, 1:1-28, 2018.
Autonomous "Open-world" Manipulation
- Definition 5. Manipulation refers to an agent’s control of its environment through selective contact.
-
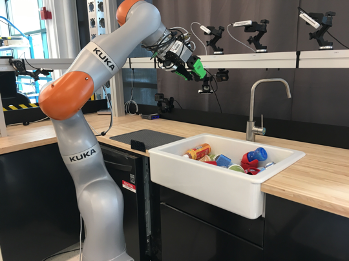
Even broader: "Open-world" manipulation requires:
- rich perceptual understanding of the environment,
- "common-sense" understanding of objects,
- the ability to make long-term (task-level) plans, and combine them with fine (joint-level) motions.
Motivation
Low-level feedback control from cameras / sensors
(continuous time/state/action)
Scene-understanding +
Task-level Planning
(discrete/symbolic)
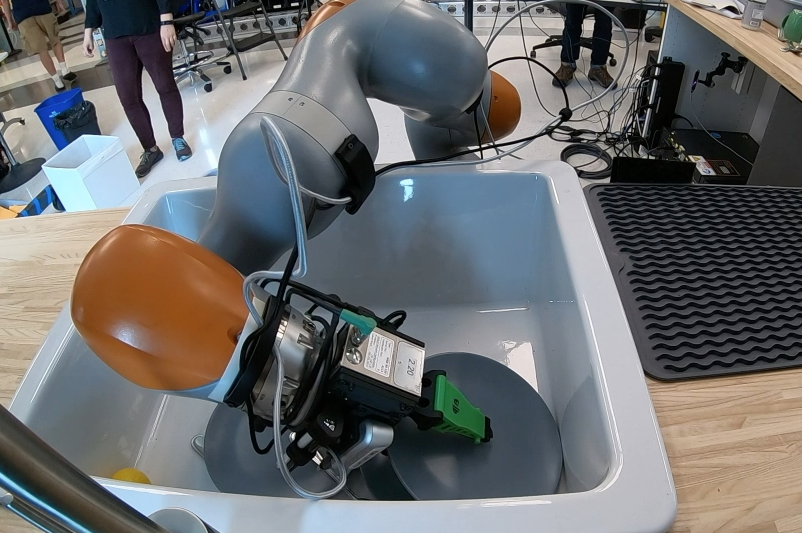
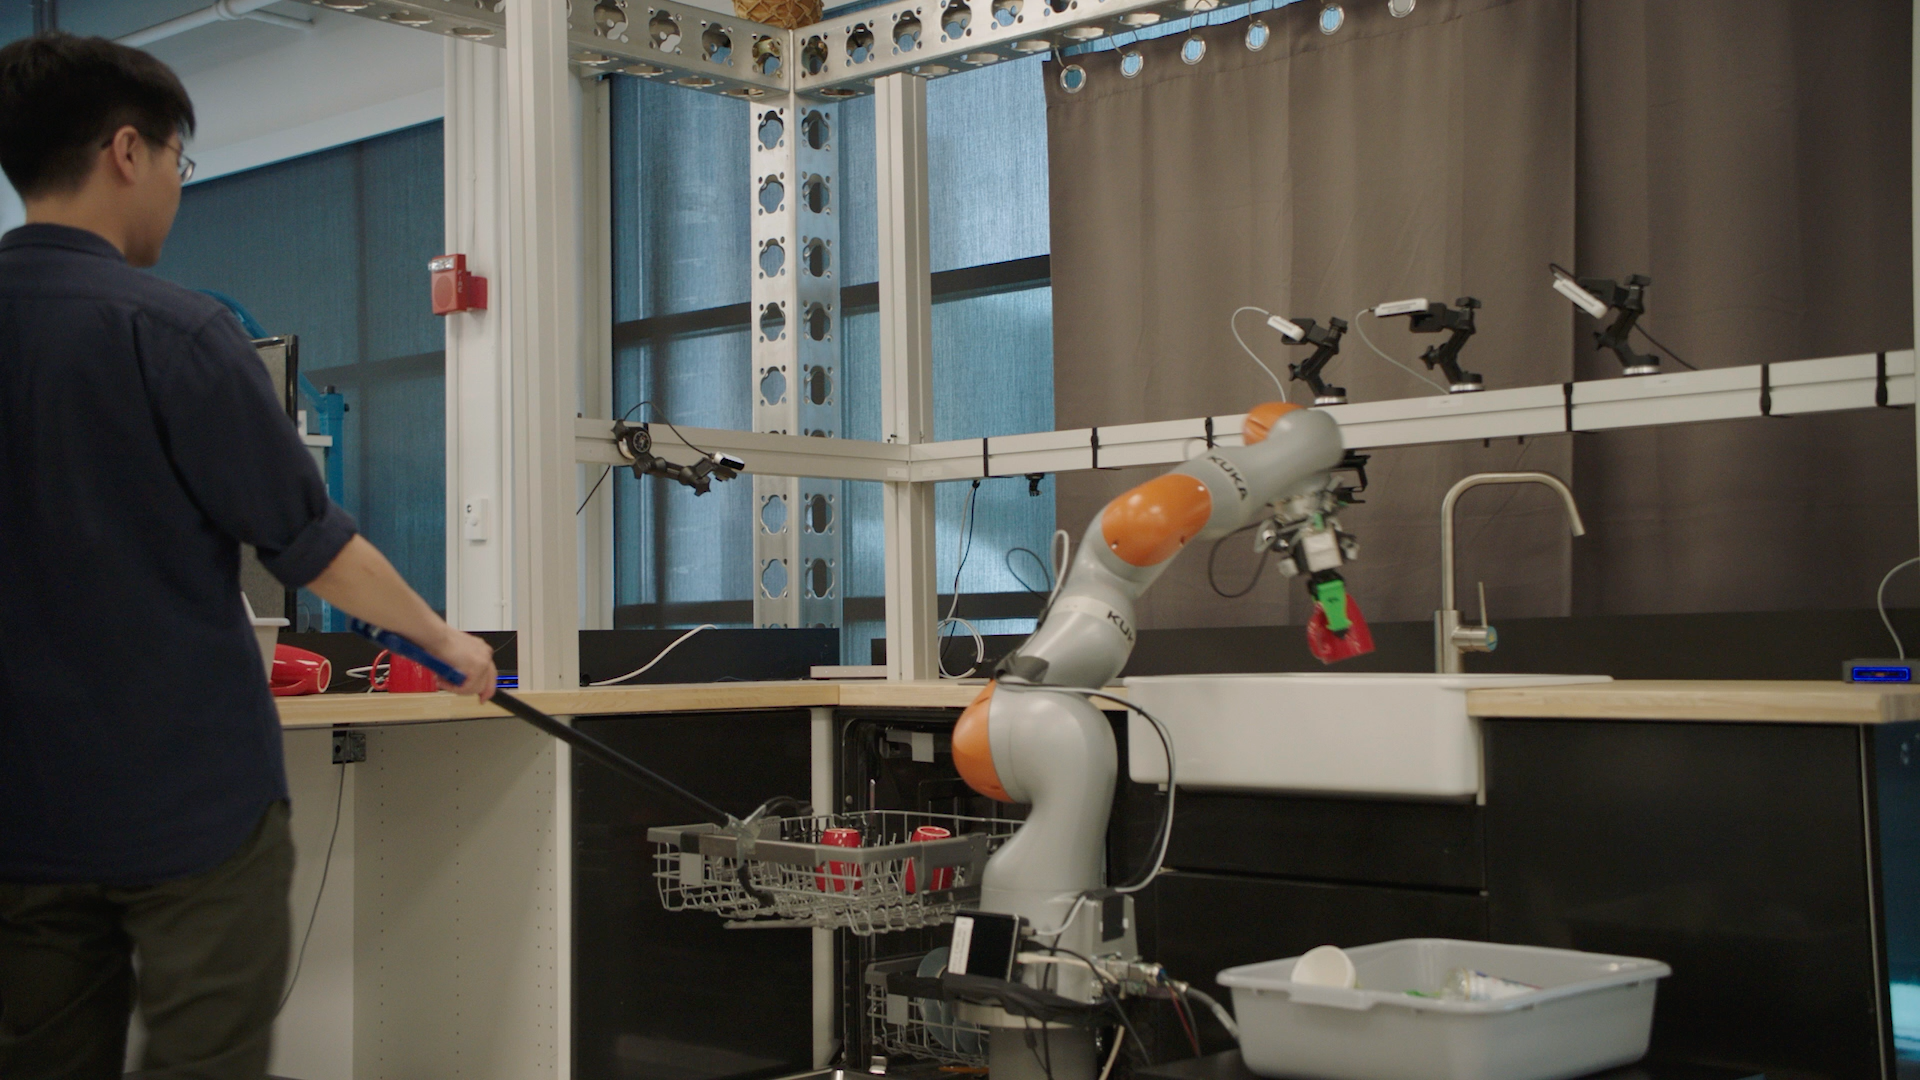
The world is even more "open" when the manipulation system goes mobile.
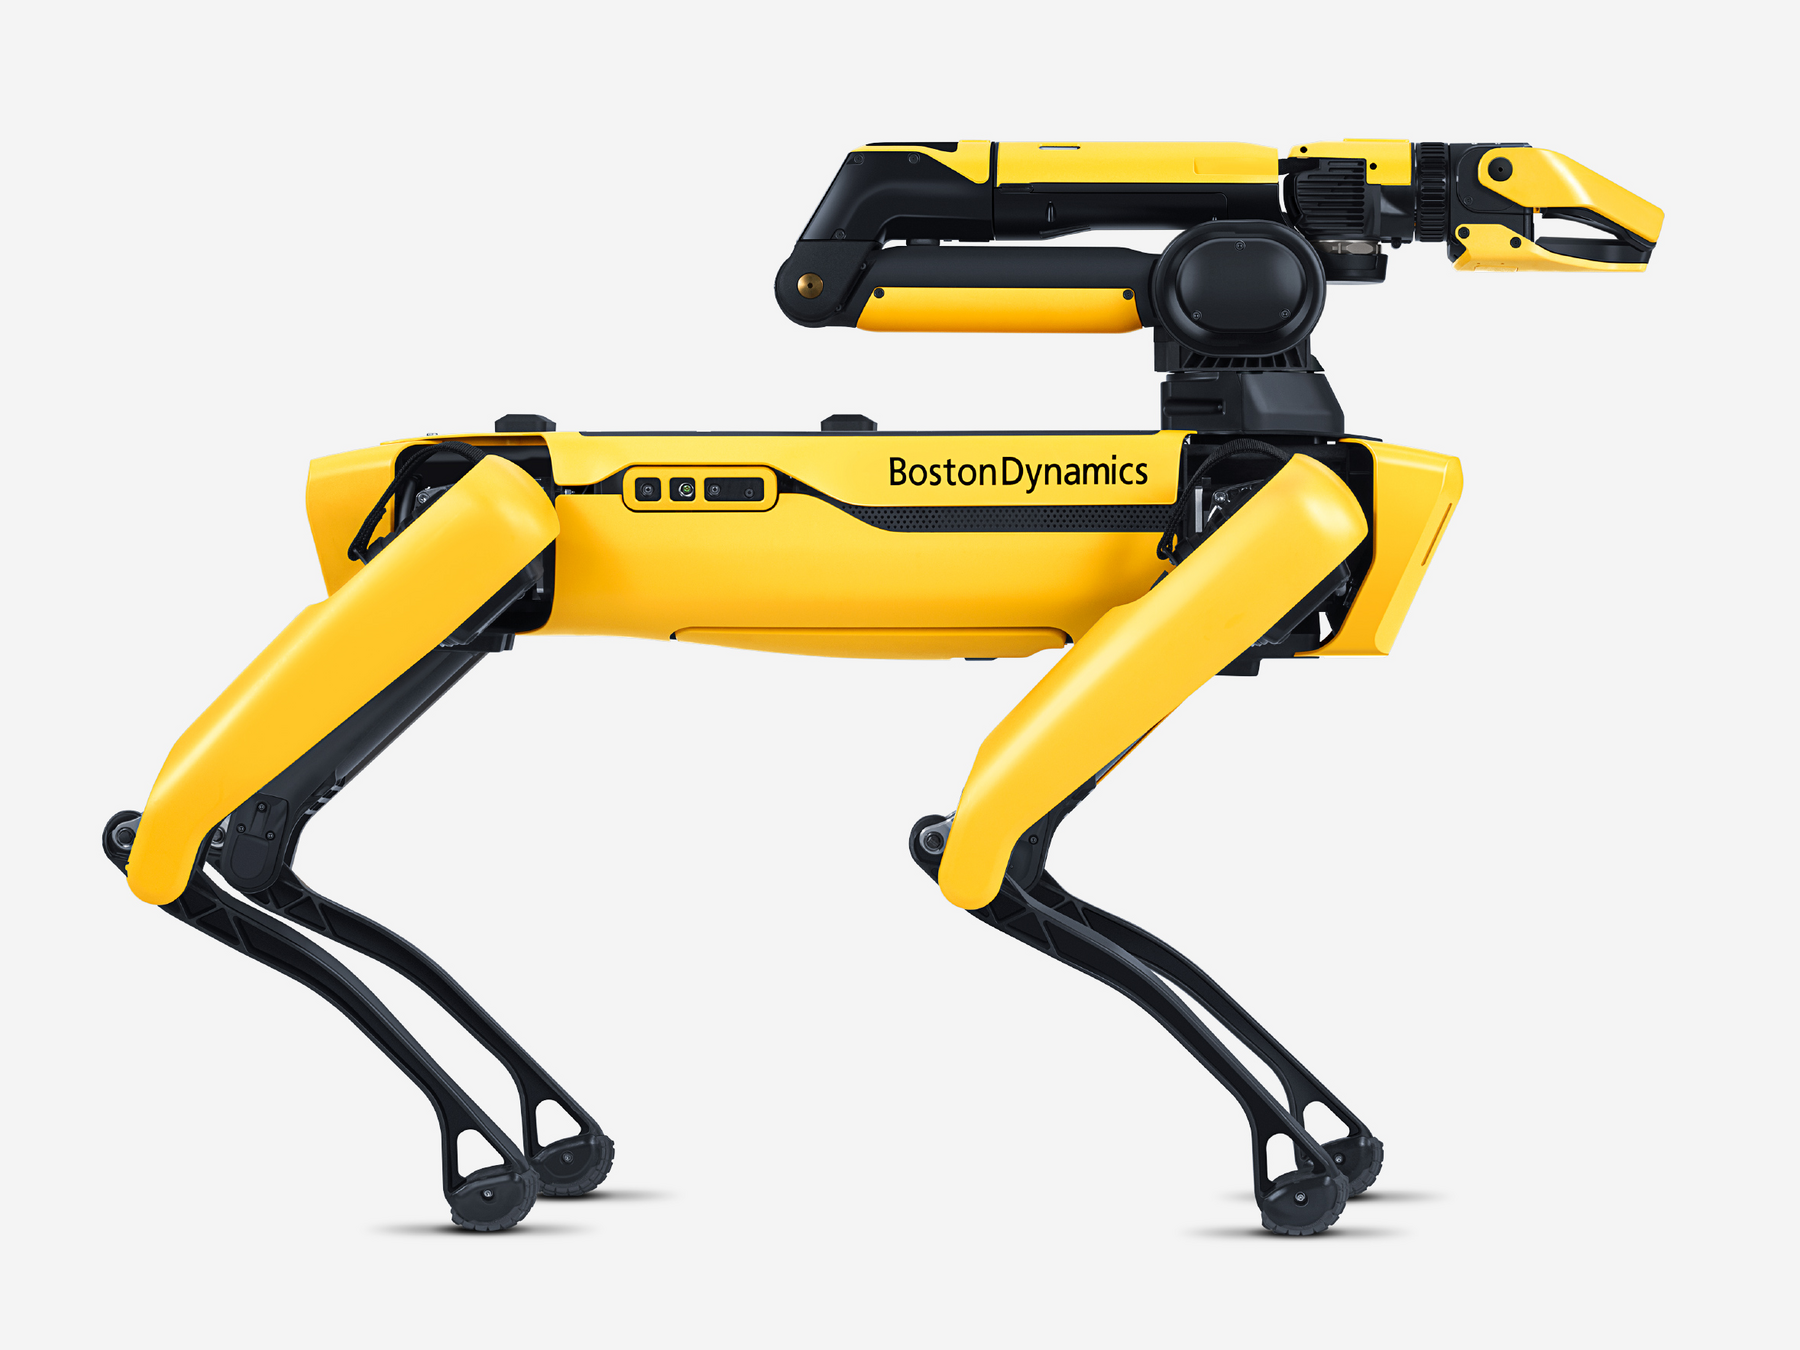
One goal for this year:
more mobile manipulation
(in lecture + projects)
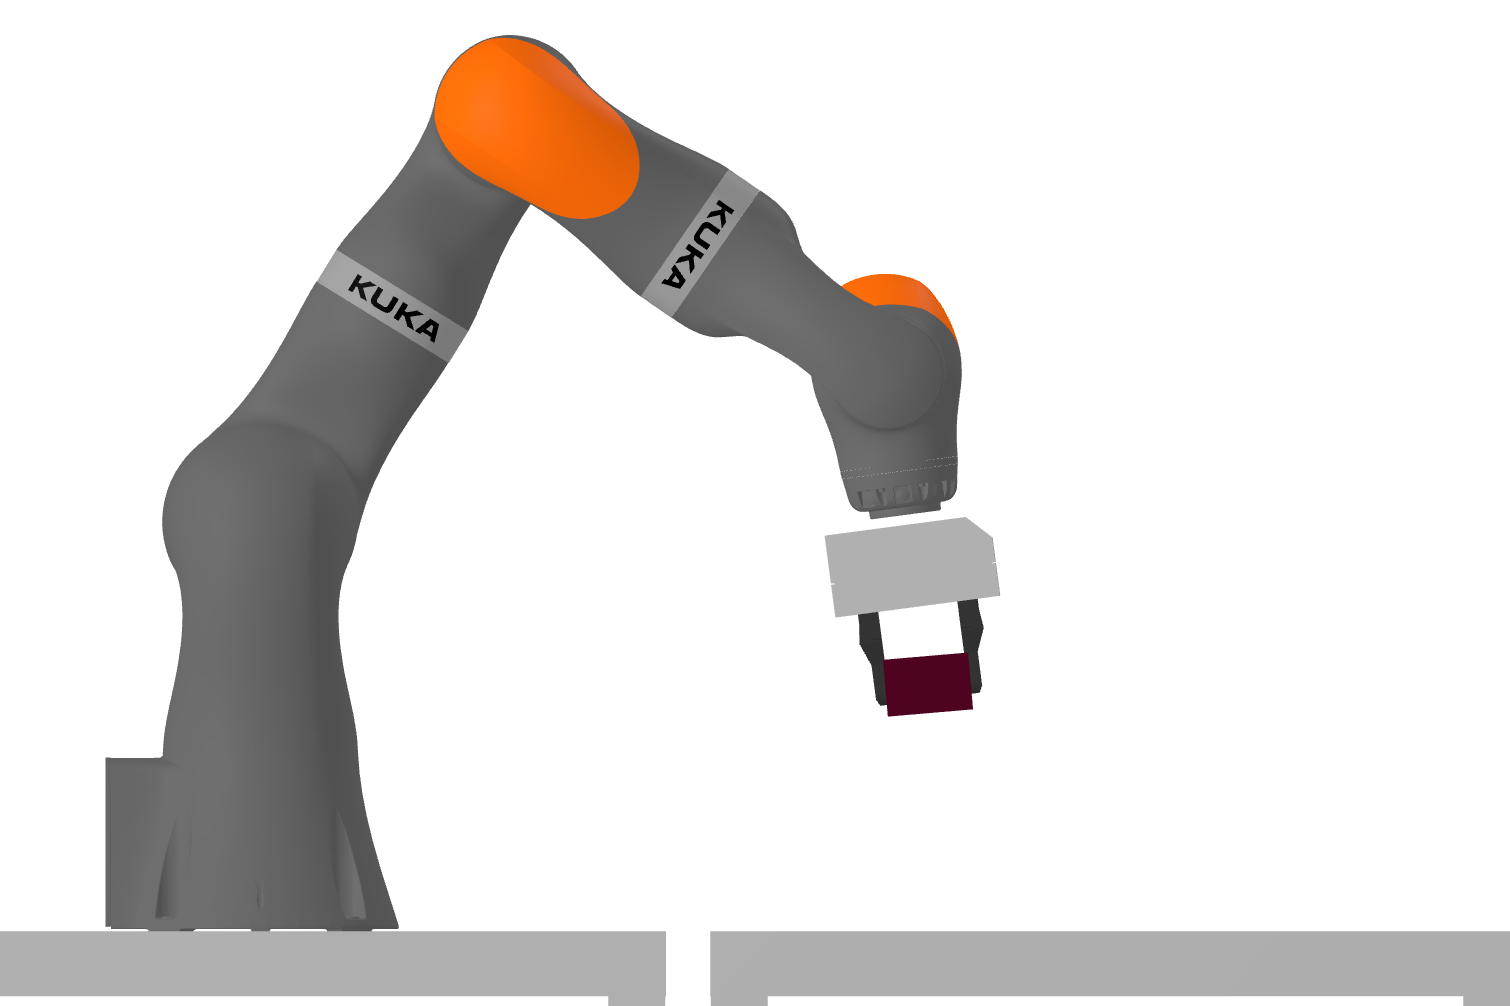
Manipulation from the dynamics and controls perspective...
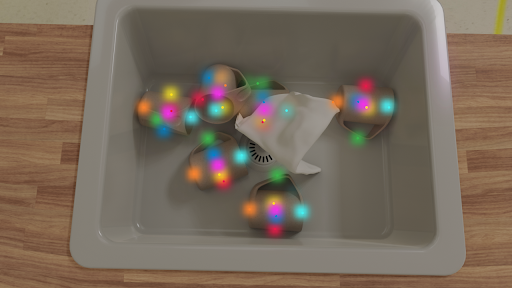
To be clear: we're not just controlling the arm
state of the robot x state of the environment
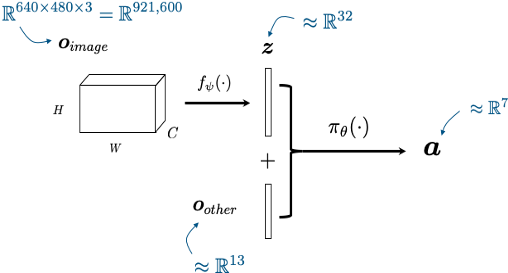
Levine*, Finn*, Darrel, Abbeel, JMLR 2016
Visuomotor policies
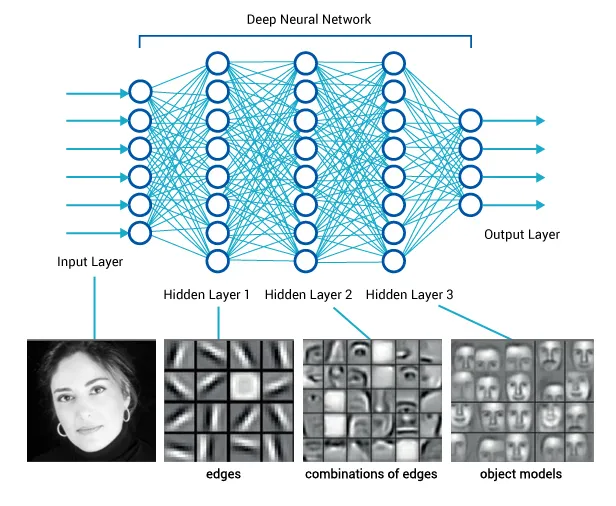
perception network
(often pre-trained)
policy network
other robot sensors
learned state representation
actions
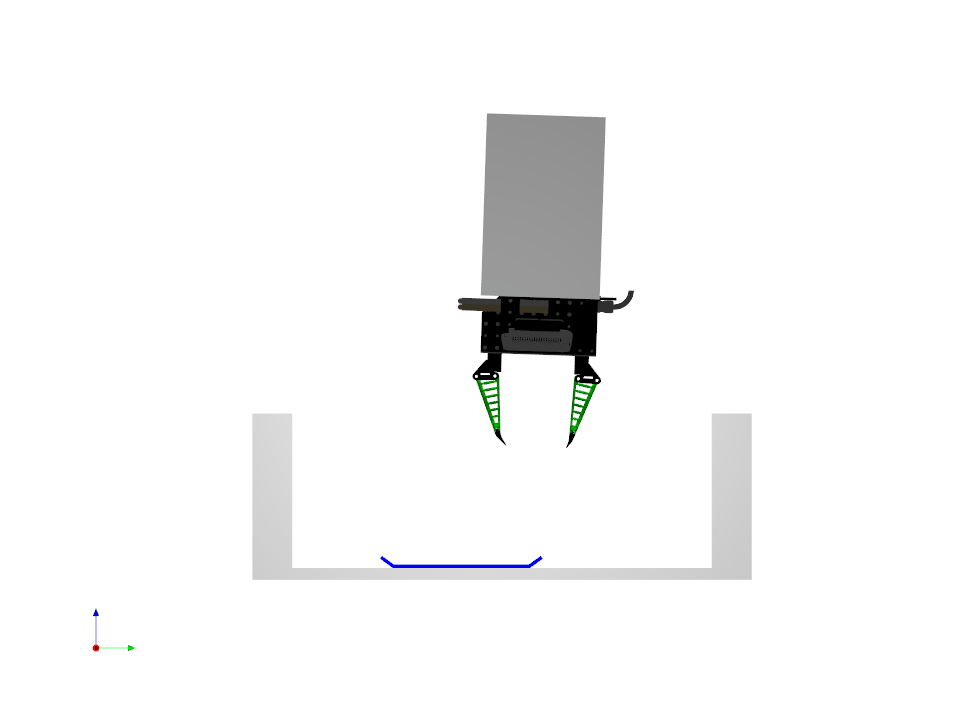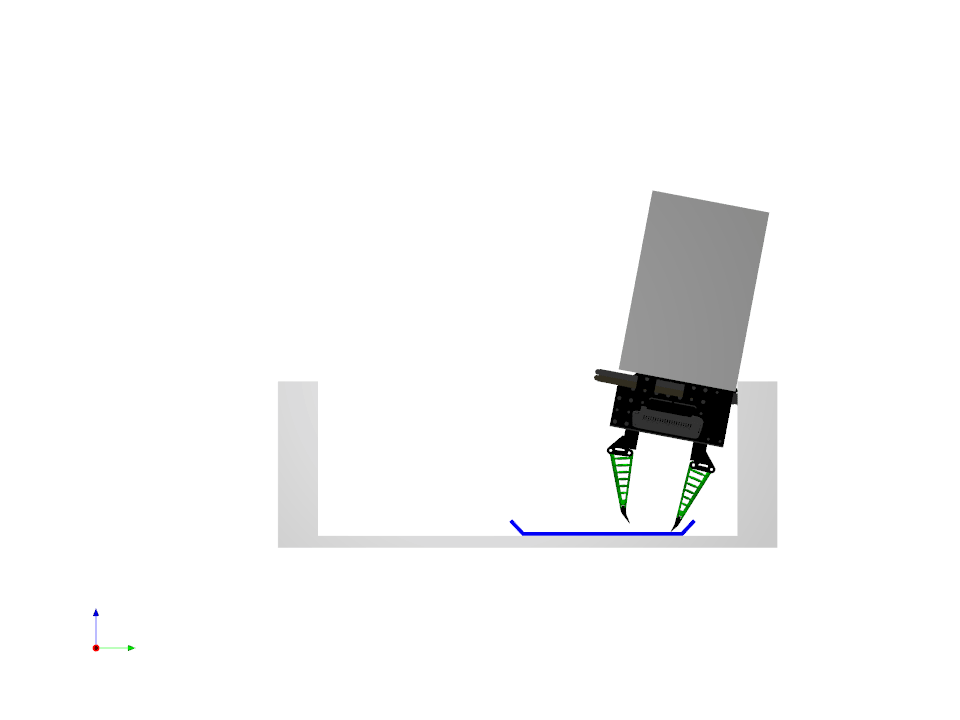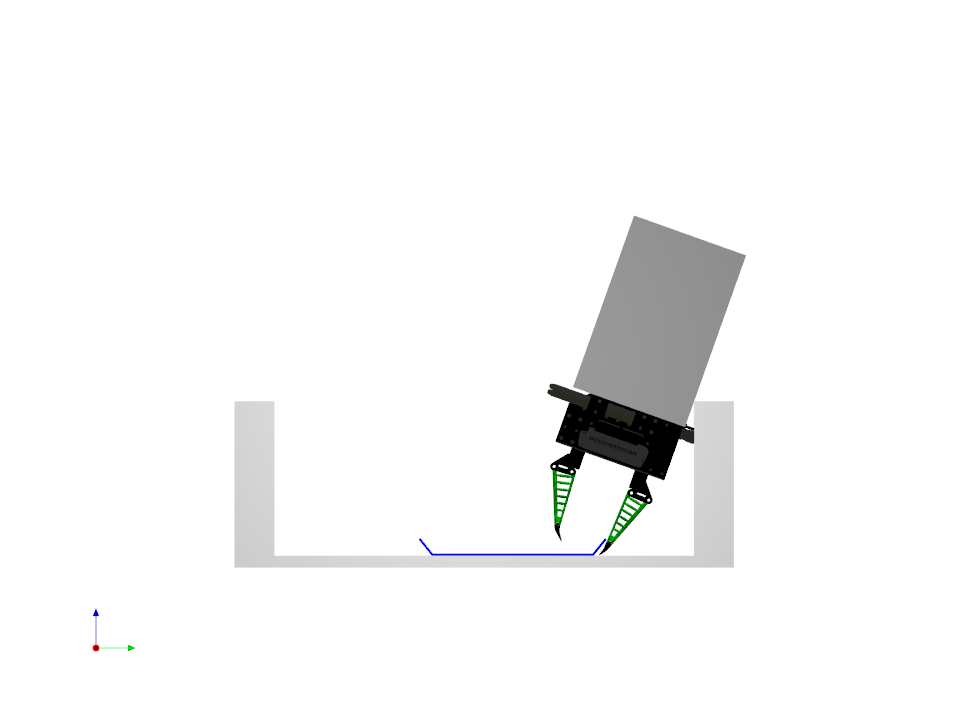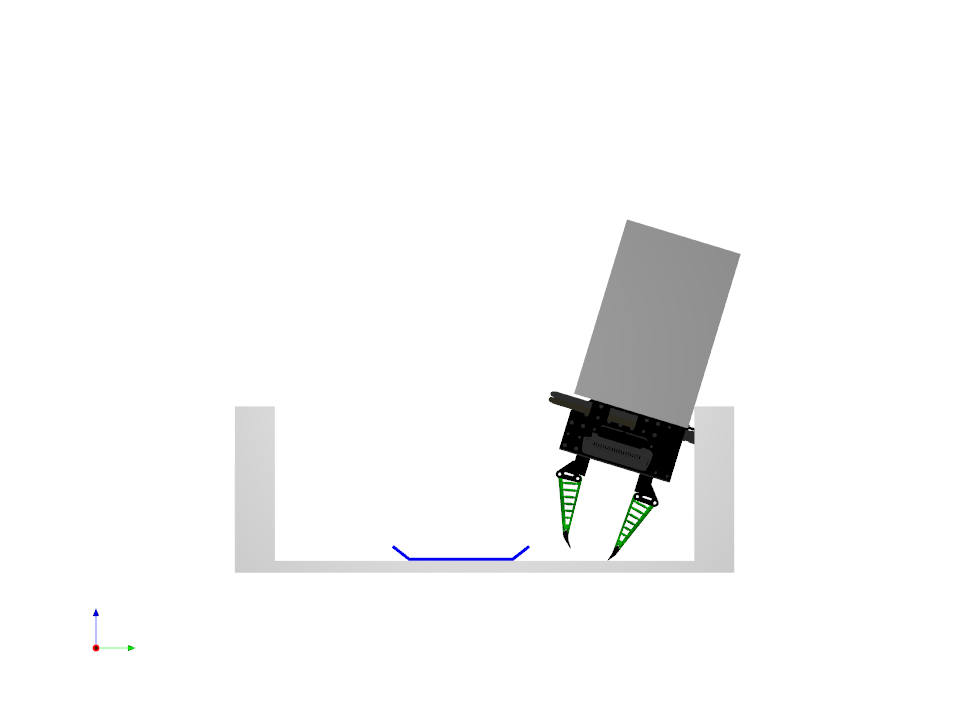
Manipulation is much more than "pick and place"!

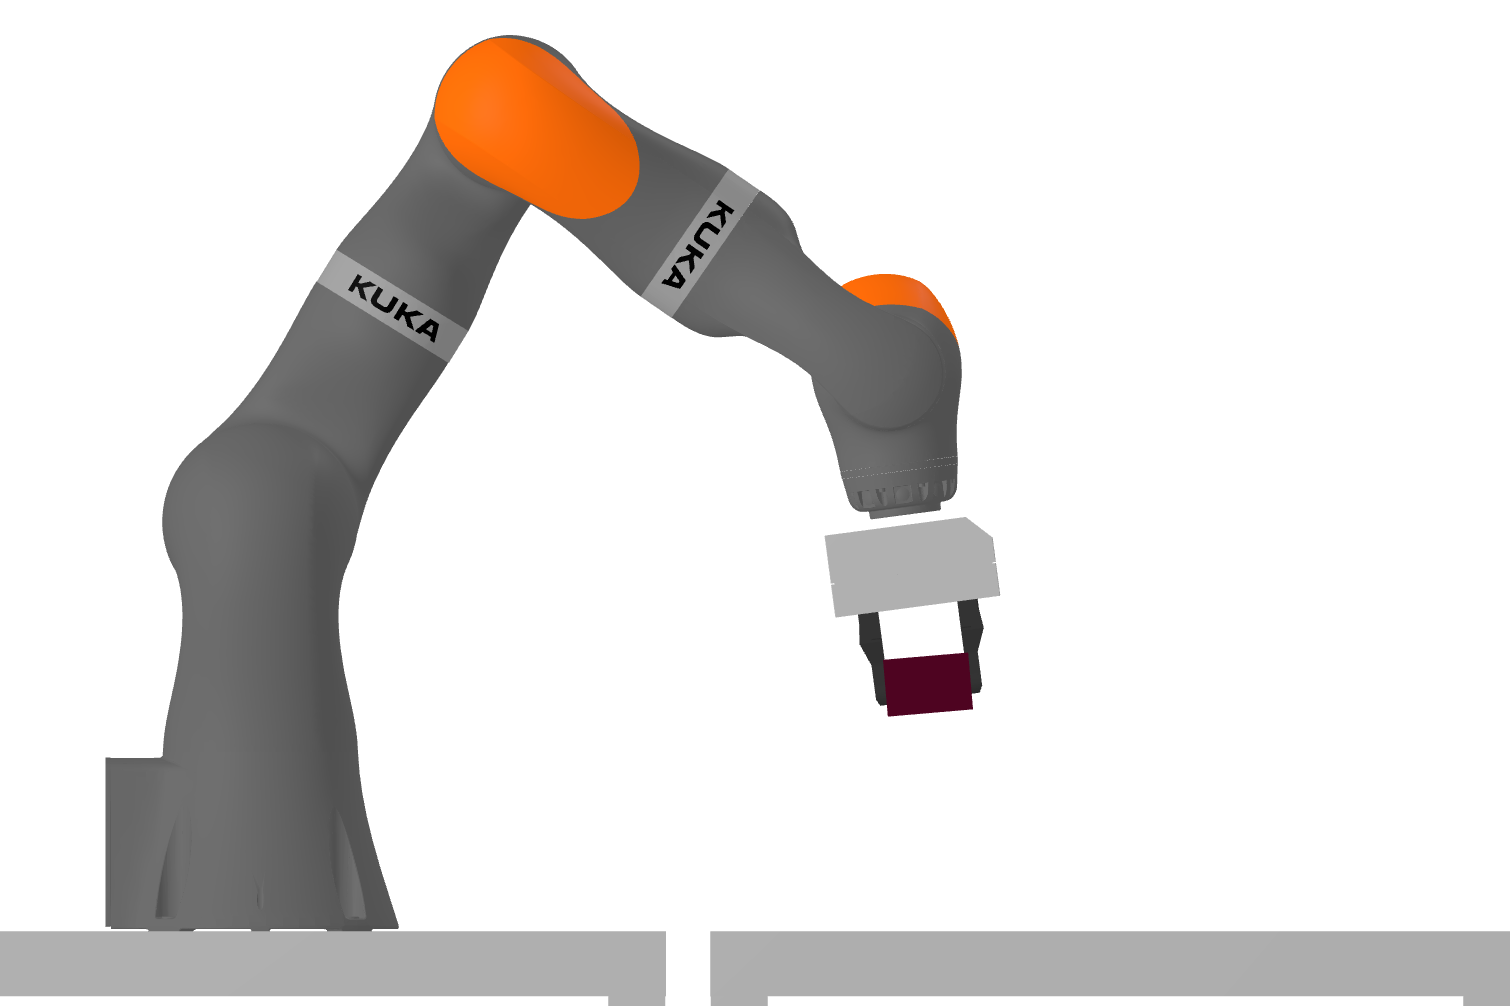
The anatomy of a modern manipulation system
What is Drake?
Logistics
- Students: Make sure you're on Piazza
- CI-M (6.4210) material on Canvas.
- Review the course guidelines.
- Read/comment on the lecture notes
- ~ weekly problem sets throughout the class, due Wed.
- Problem Set 1 released tomorrow (on the course calendar).
- Final project.