Vector-Accelerated Motion Planning
with Constraints
Thomas Cohn
In collaboration with Shrutheesh Iyer (project lead) and Prof. Zachary Kingston
October 9, 2026
Types of Parallelism in Planning
CPU multithreading
GPU parallelism
CPU SIMD instructions

- Independent cores, each with its own instruction stream
- Coarse-grained: whole queries or planners in parallel
- Tens of threads; synchronization overhead
- Thousands of lightweight threads
- Great for large batch size compute (e.g. cuRobo)
- Host–device transfer latency; branchy code diverges
- One instruction, many data lanes (AVX2: 8 floats)
- Fine-grained: parallel inside a single planner step
- No transfer or sync cost, but every lane runs the same code
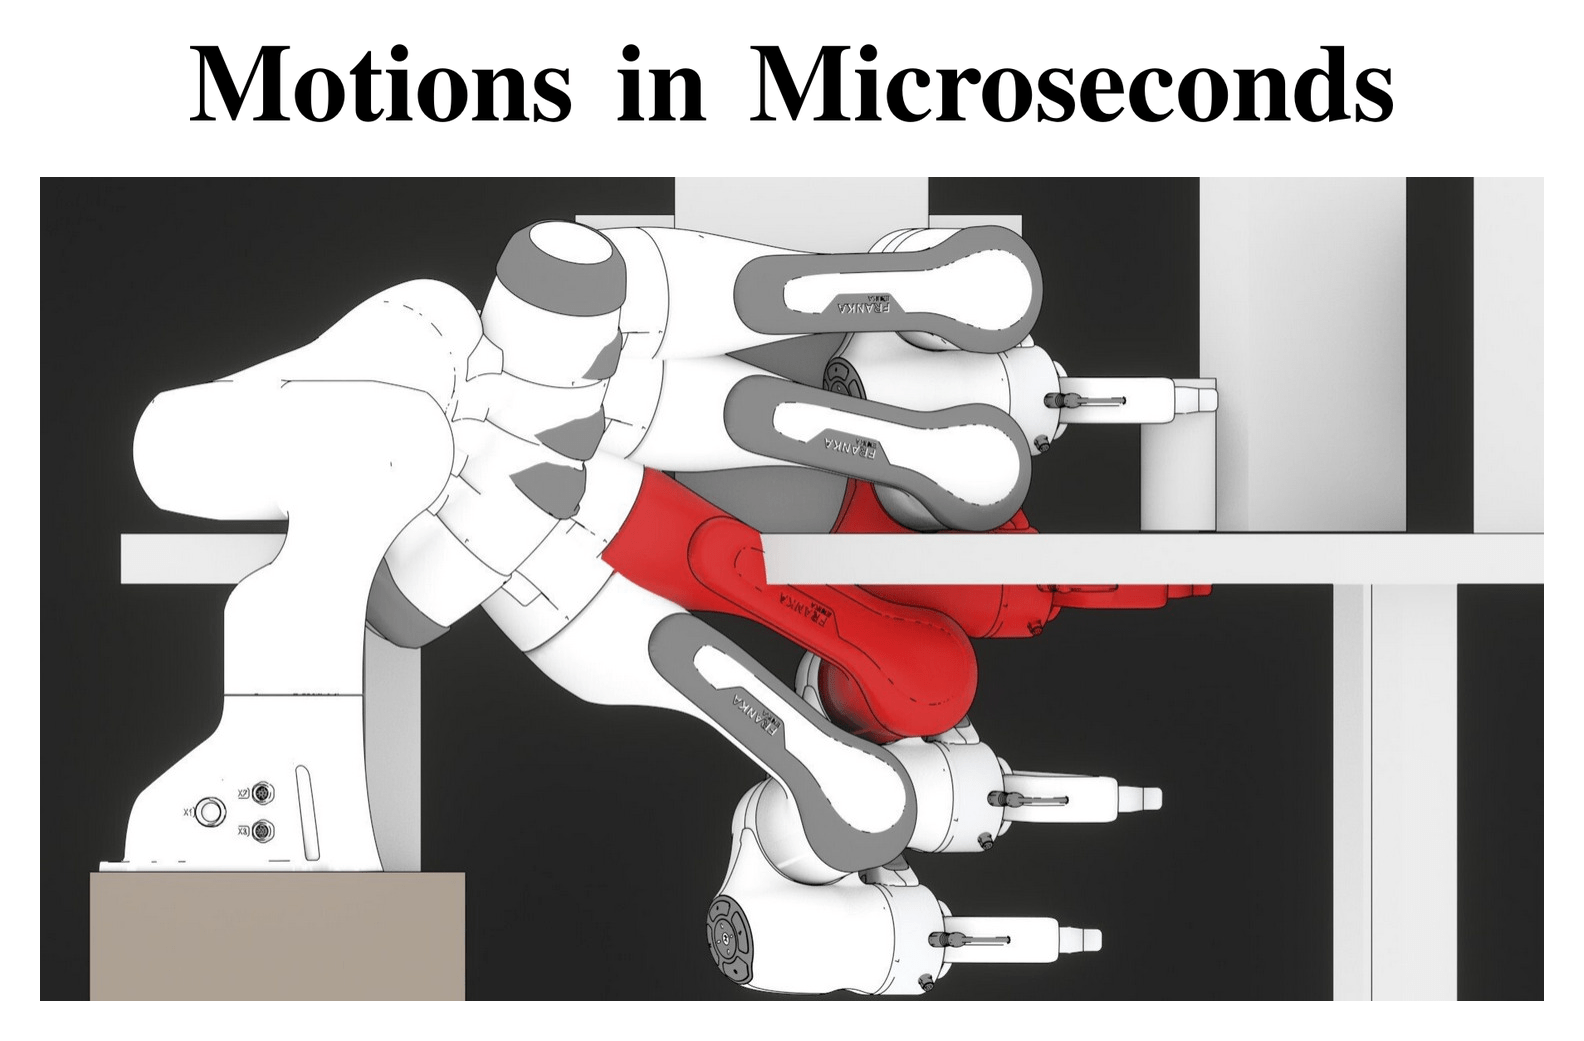
Motions in Microseconds
- Parallel FK across configurations
- Hierarchical sphere collision checking
- Edge-parallel collision checking
- Collision-affording point trees
(branchless approximate nearest-neighbors)
140 Hz
Full pipeline from a raw 166k-point depth camera cloud (filter, build CAPT, plan, simplify), UR5, one CPU core
Motions in Microseconds via Vectorized Sampling-Based Planning, W. Thomason, Z. Kingston, L. E. Kavraki, 2024
Collision-Affording Point Trees: SIMD-Amenable Nearest Neighbors for Fast Collision Checking,
C. W. Ramsey, Z. Kingston, W. Thomason, L. E. Kavraki, 2024
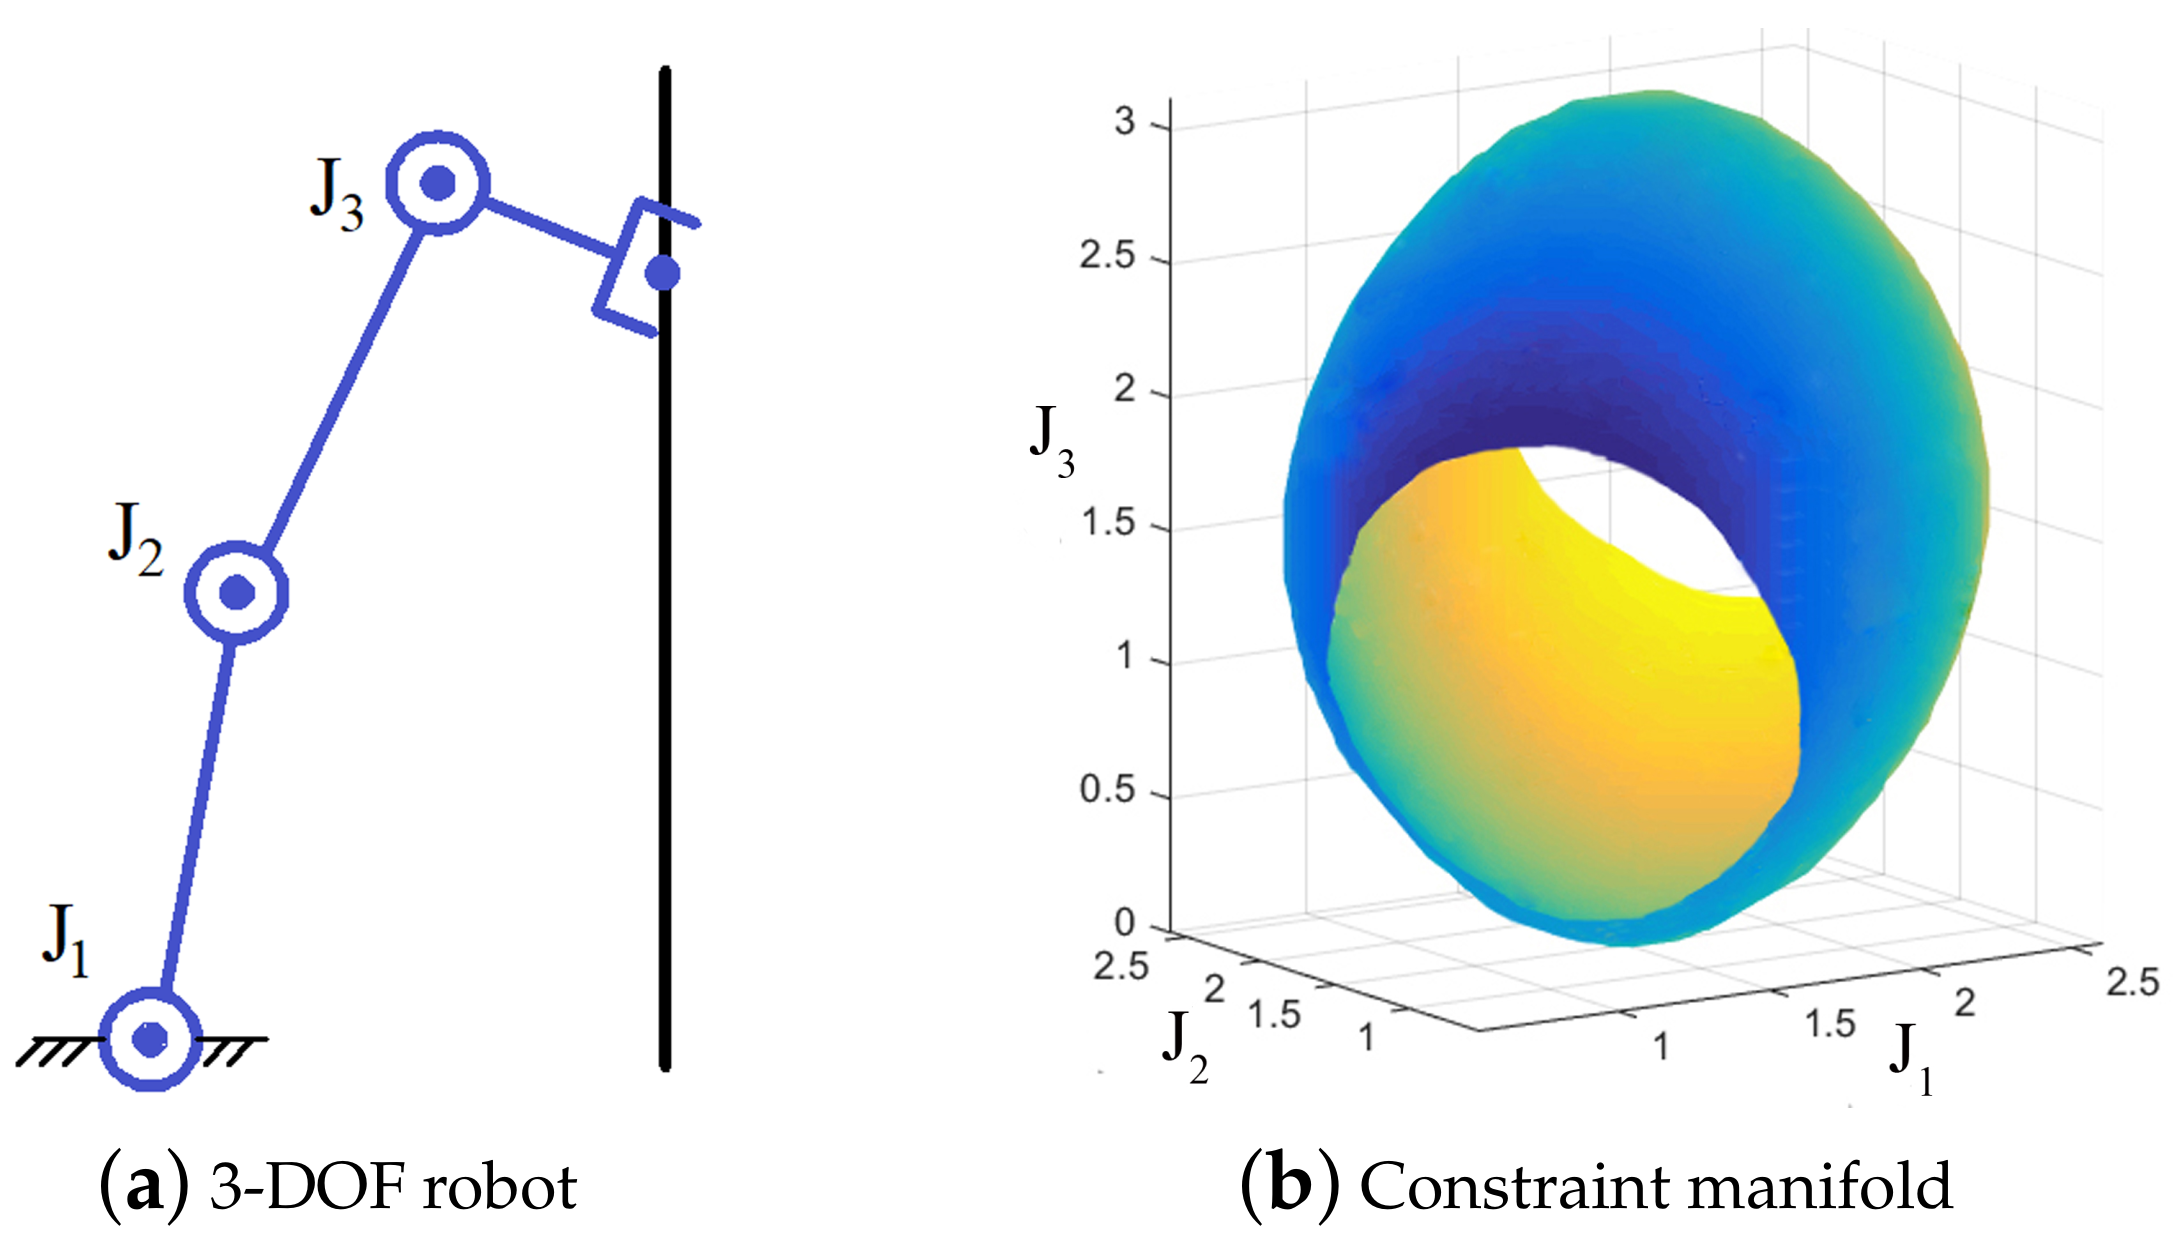
Kinematic Equality Constraints
Learning the Metric of Task Constraint Manifolds for Constrained Motion Planning,
F. Zha, Y. Liu, W. Guo, P. Wang, M. Li, X. Wang, J. Li, 2018
Projection-Based Sampling
McVAMP: Vectorized Projection
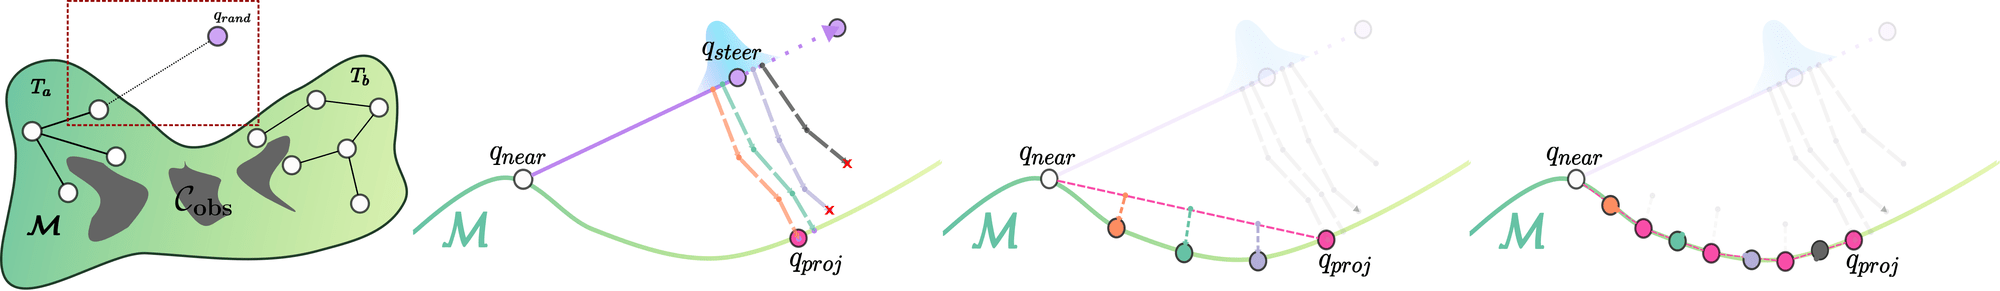
Vectorizing Projection in Manifold-Constrained Motion Planning for Real-Time Whole-Body Control,
S. R. Iyer, I.-C. Chang, A. Z. Liu, Y. Gu, Z. Kingston, 2026
McVAMP Weakness
- Iterative numerical algorithms are fundamentally hard to parallelize
- McVAMP runs multiple projections in parallel to avoid this
- CPU SIMD parallelism \(\Rightarrow\) bottlenecked by slowest projection
High iteration-count failure
High iteration-count success
(Re)Parameterized Planning
ReVAMP
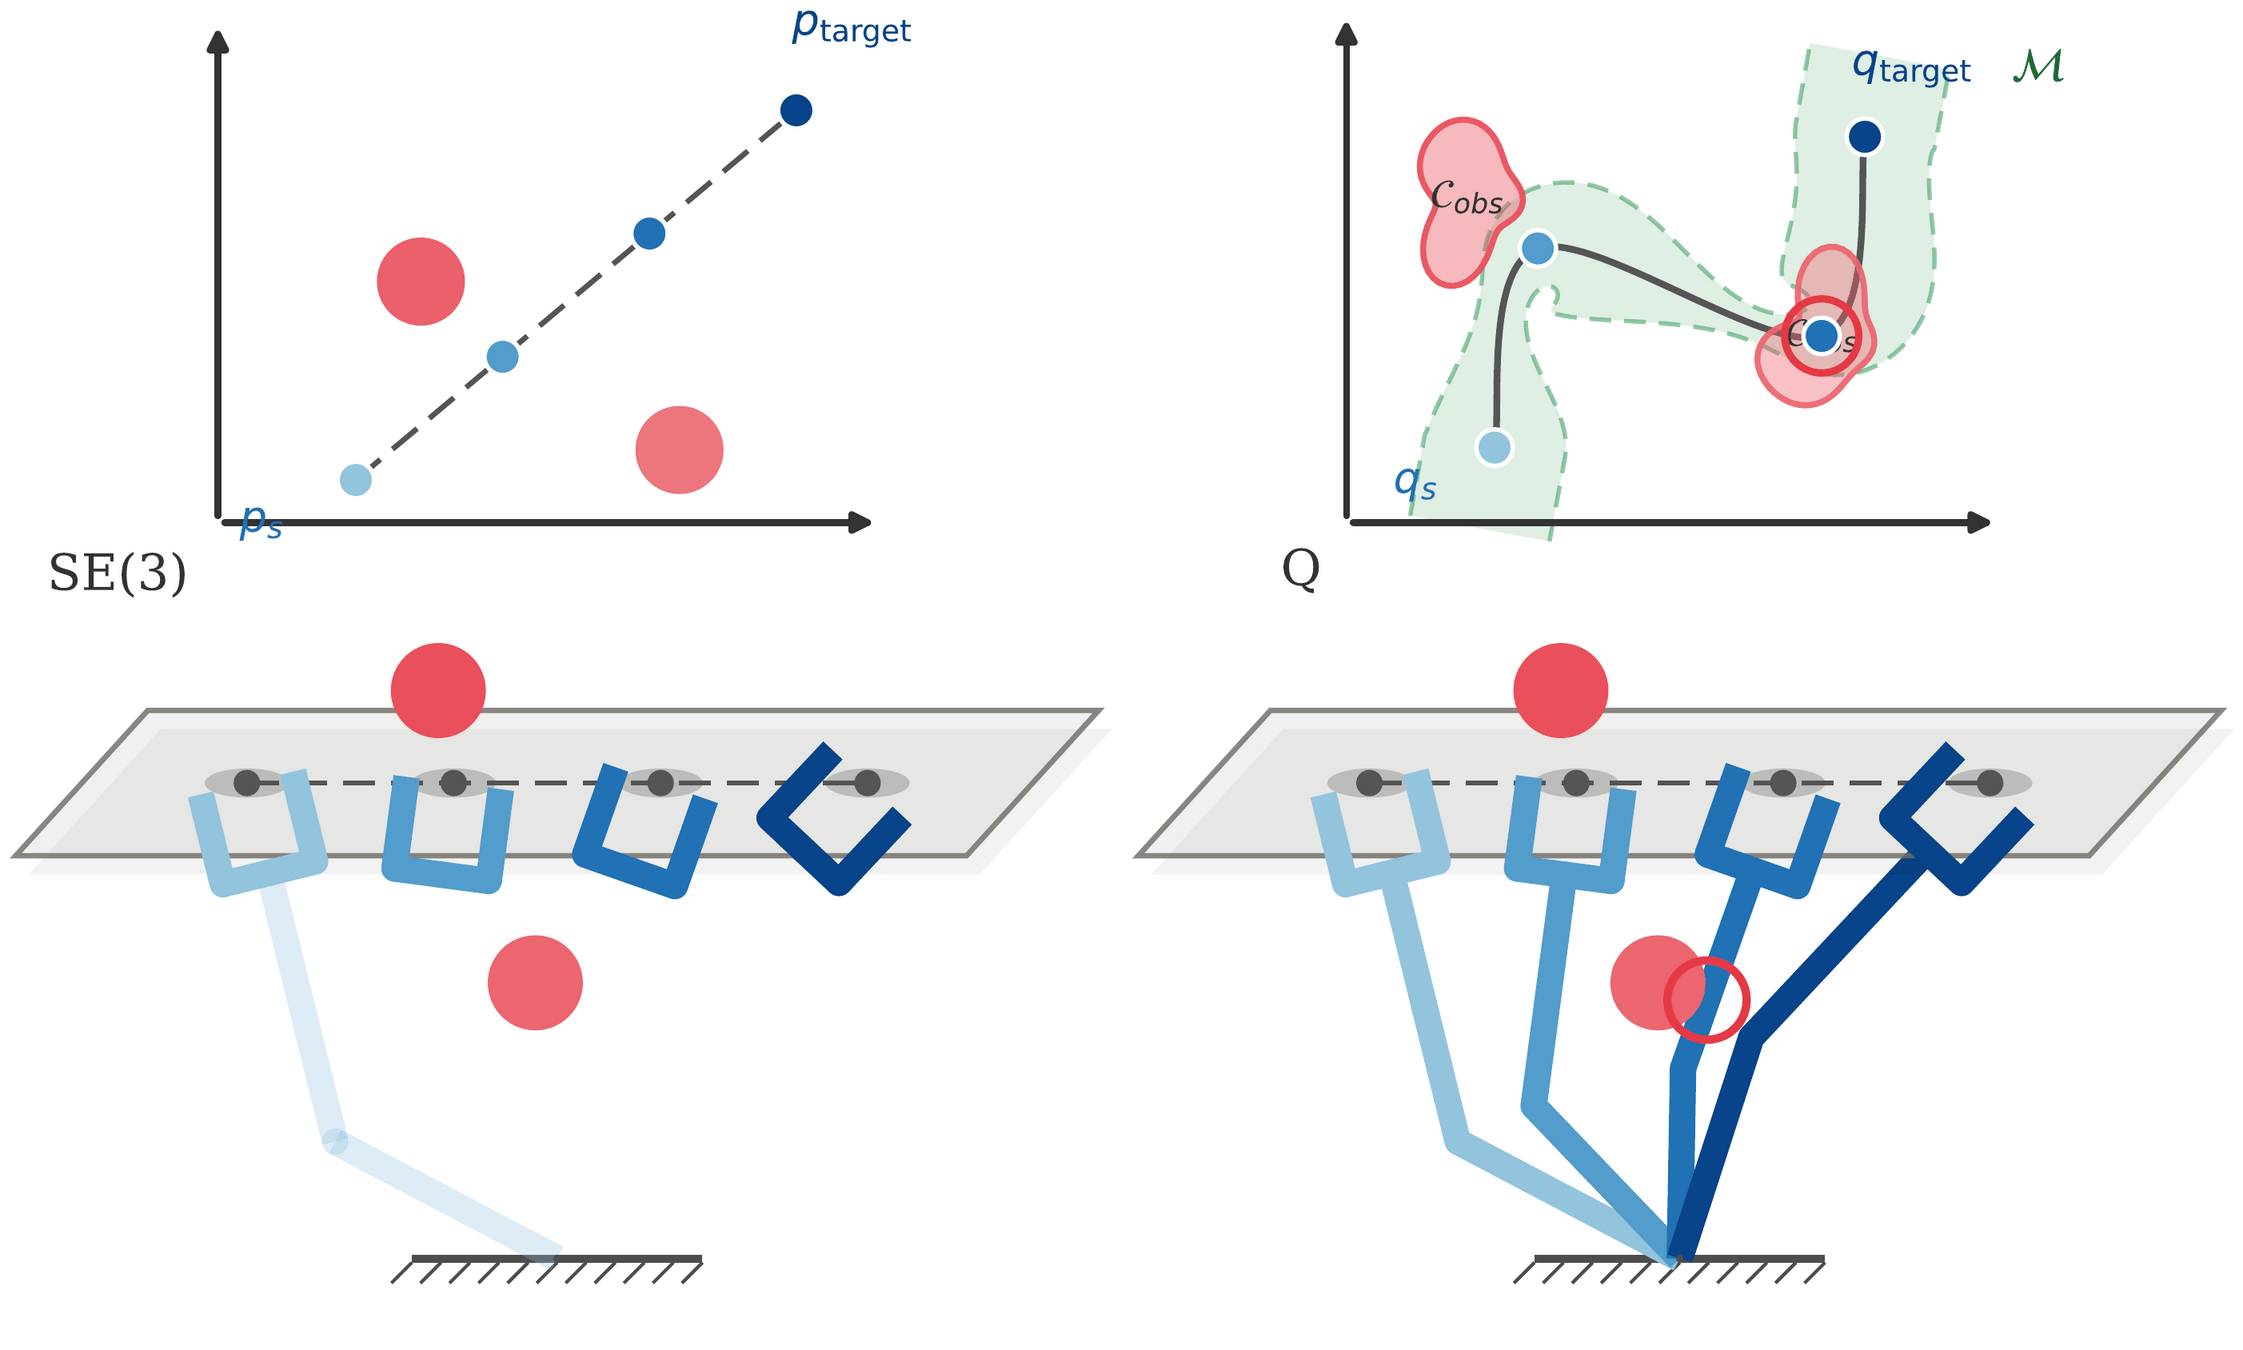
IK
ReVAMP: Vector-Accelerated Motion Planning for Kinematically-Constrained Systems via Reparameterization,
S. R. Iyer, T. Cohn, Z. Kingston, 2026
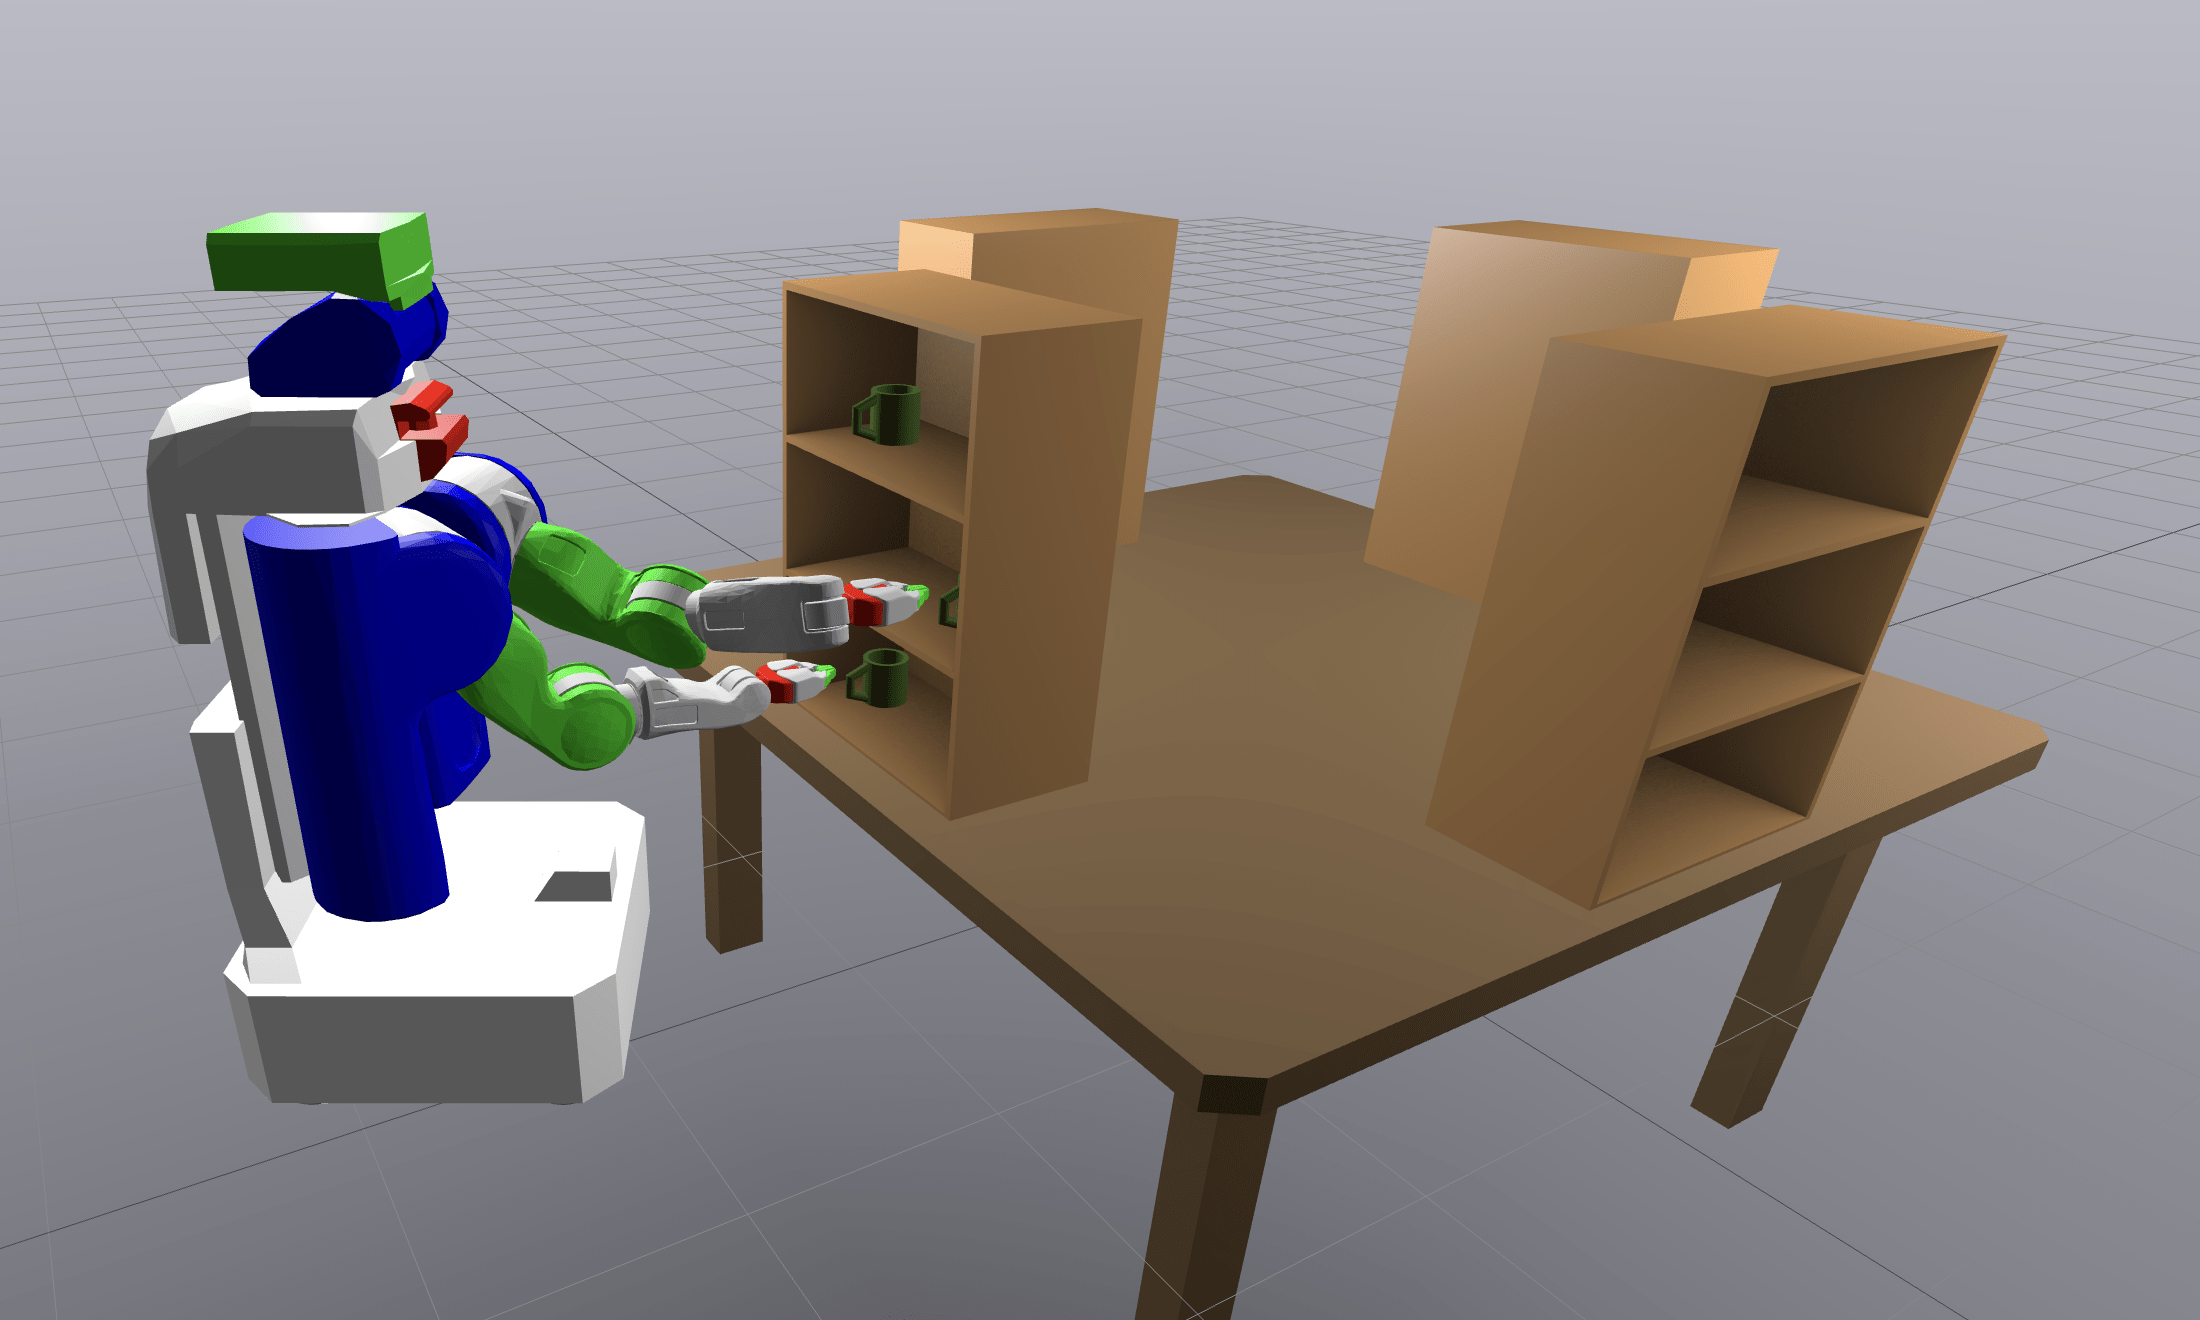
Bimanual Transport (Sim)
0.13 ms
median planning time, 14-DoF bimanual iiwa (Dual-Follower)
- McVAMP: 2.89 ms (22× slower)
- Leader-Follower: 0.44 ms, despite 5× more iterations than McVAMP
- Dual-Follower: 58 iterations vs 310, and shorter paths (5.5 vs 14.1 rad)
- 200 random queries between 3 shelf poses
Maze Tracing (Hardware)
12 ms
median replanning time on hardware, FR3 held to the maze plane, moving obstacles, 2.5 GHz i5
- McVAMP: 146 ms (12× slower)
- Planned z-error: 0 mm (exact by construction) vs 1.02 mm
- Executed z-error: 0.19 mm vs 1.08 mm
- Sim, 200 queries: 4.8 ms vs 59.8 ms; failures end 8× sooner (57 vs 473 ms)
When Planning Is Free
Planning is expensive
- Ration planner calls
- Guess the best candidate first
- A failure costs a 30 s timeout
- Retries, fallbacks, special cases
Planning is free
- Plan every candidate
- Let the planner pick the best
- A failure costs milliseconds
- One loop over candidates
Case study: bimanual pick-and-place on the RB-Y1
Old RB-Y1 Pick-and-Place
Per box pose (20-point grid)
- IK for the grasp, carry and place poses
- Six legs; lift and place are constrained (box in both hands)
- Each leg: BiRRT \(\to\) shortcut \(\to\) trajectory optimization \(\to\) TOPPRA
Choosing the grasp
- Fix one of 8 IK branches
- Solve grasp IK 6 times; rank with a hand-tuned heuristic
- Probe the best grasp: can we plan lift + place?
- Probe fails \(\to\) probe the other grasps in parallel
- Still failing \(\to\) retry with new seeds, then the next IK branch
43.6 s per box pose, much of it wasted
Every failed planning call runs to its 30 s timeout
79% of IK time goes to ranking candidates that are thrown away
RB-Y1 Pick-and-Place
Just plan everything
- One IK branch; 5 IK solutions each for grasp, carry and place
- ReVAMP plans every grasp \(\to\) carry and carry \(\to\) place pair: up to 50 calls, ~7 ms each
- Keep the shortest of the 125 grasp \(\to\) carry \(\to\) place chains
- Trajectory optimization, TOPPRA and dense checks as before
17.9 s
median per box pose (IFT: 43.6 s)
20/20
grid points planned (IFT: 20/20)
6 ms
per failed planning call (IFT: 30 s timeout)
And What Else…
- MPC, but always to the true goal
- Actual confidence about plan infeasibility for TAMP
- Fast pathwise IK for policy deployment
Towards Practical Finite Sample Bounds for Motion Planning in TAMP,
S. Shaw, A. Curtis, L. P. Kaelbling, T. Lozano-Pérez, N. Roy, 2024
Vector-Accelerated Motion Planning
with Constraints
Thomas Cohn
October 9, 2026
In collaboration with Shrutheesh Iyer (project lead) and Prof. Zachary Kingston