Manipulator
Control
MIT 6.4210/2
Robotic Manipulation
Fall 2026, Lecture 15
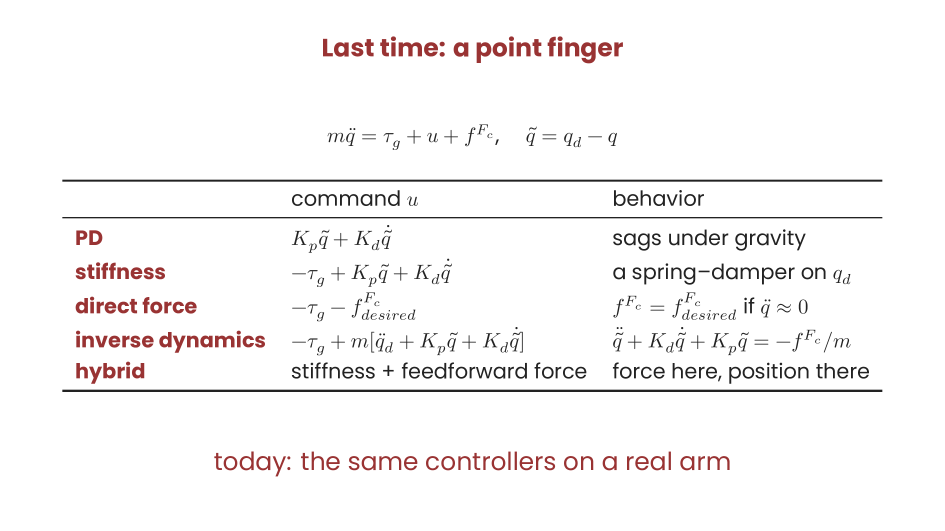
From last time....
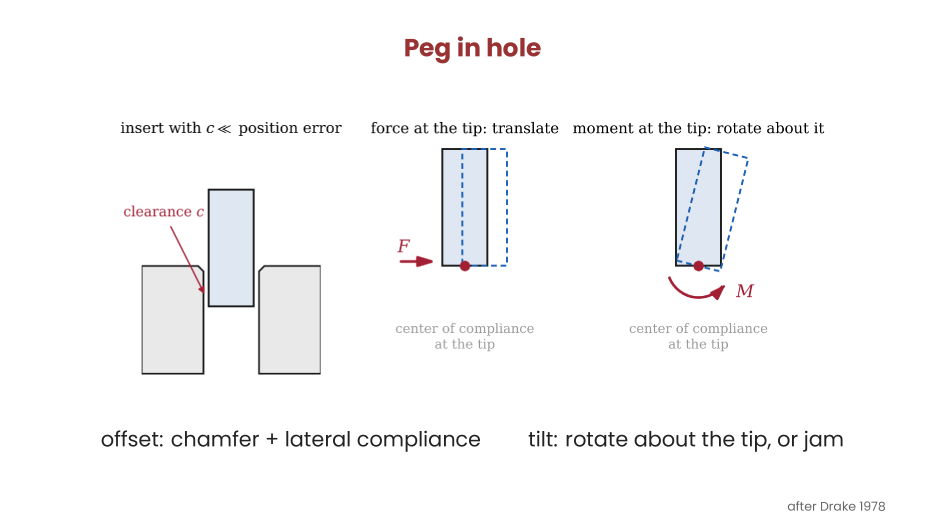
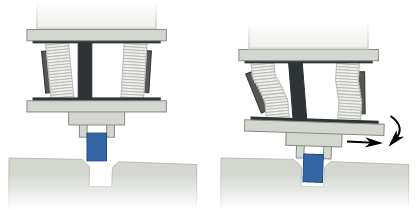
Image credit for Arne Nordmann, 2008
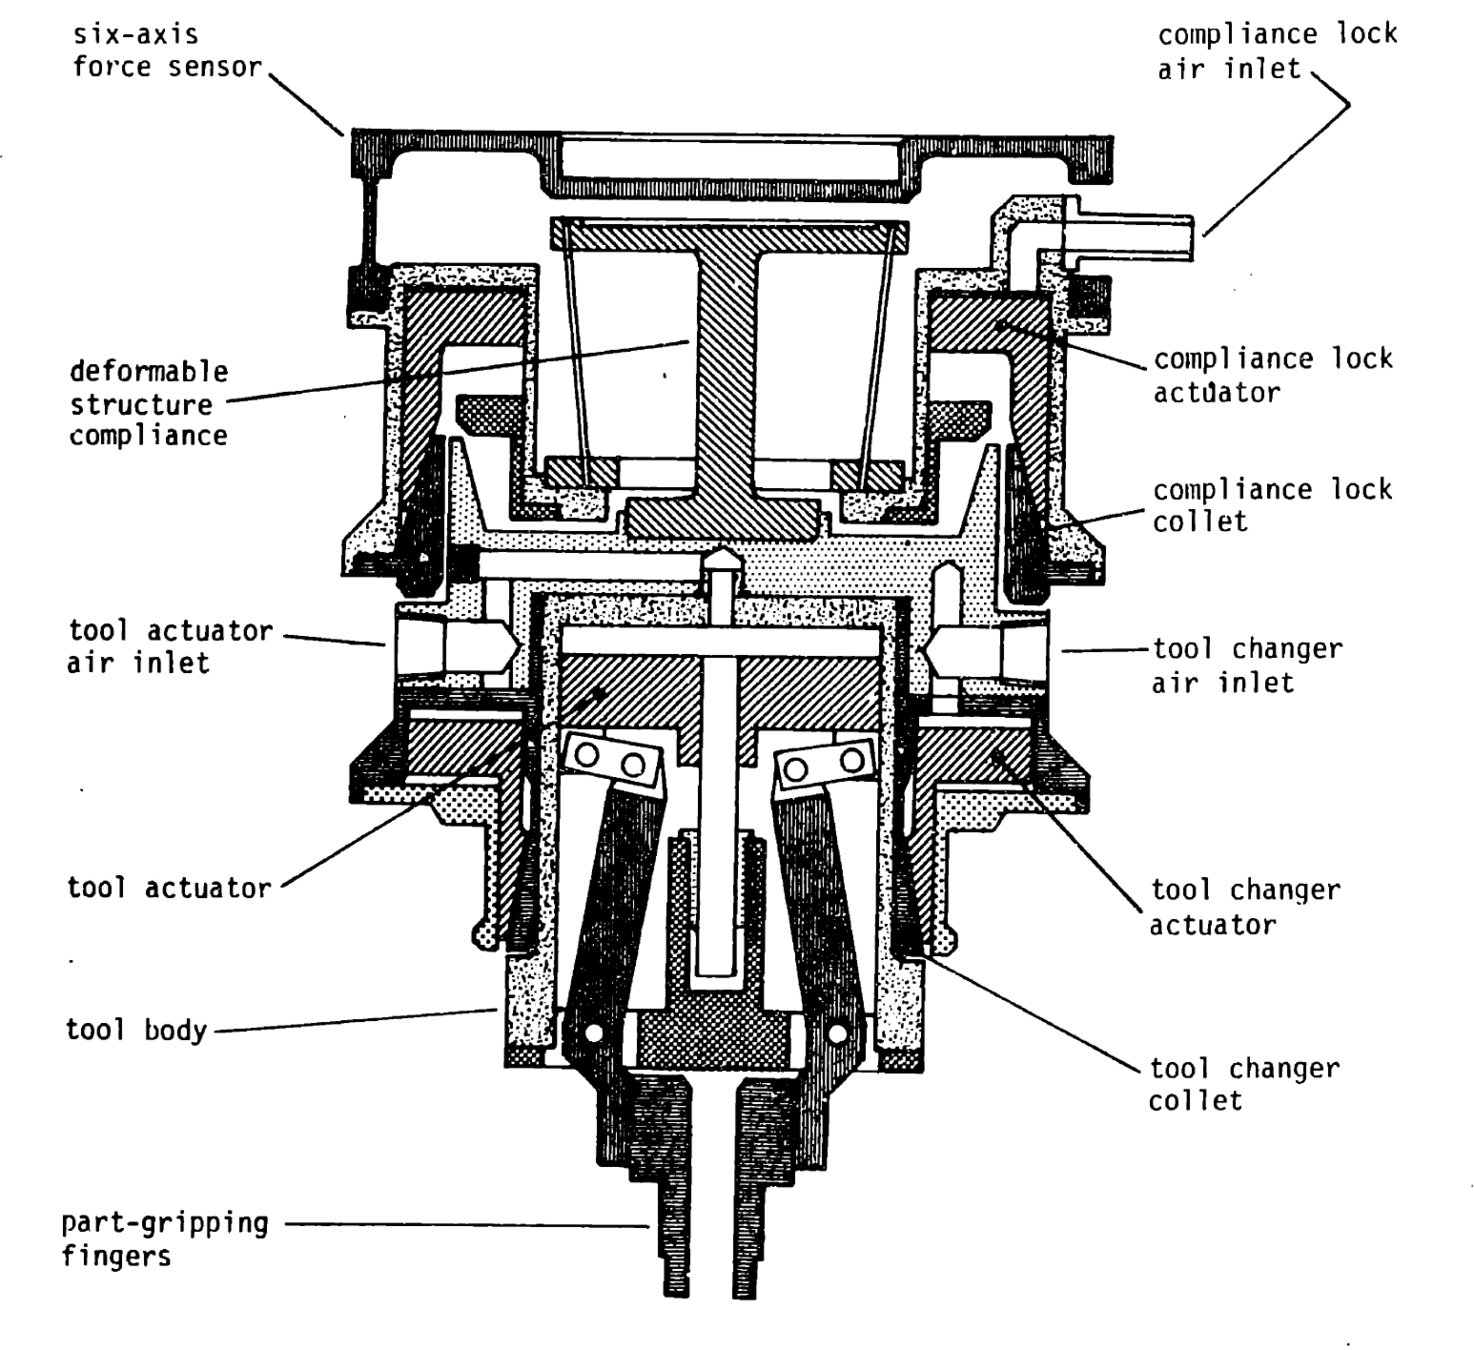
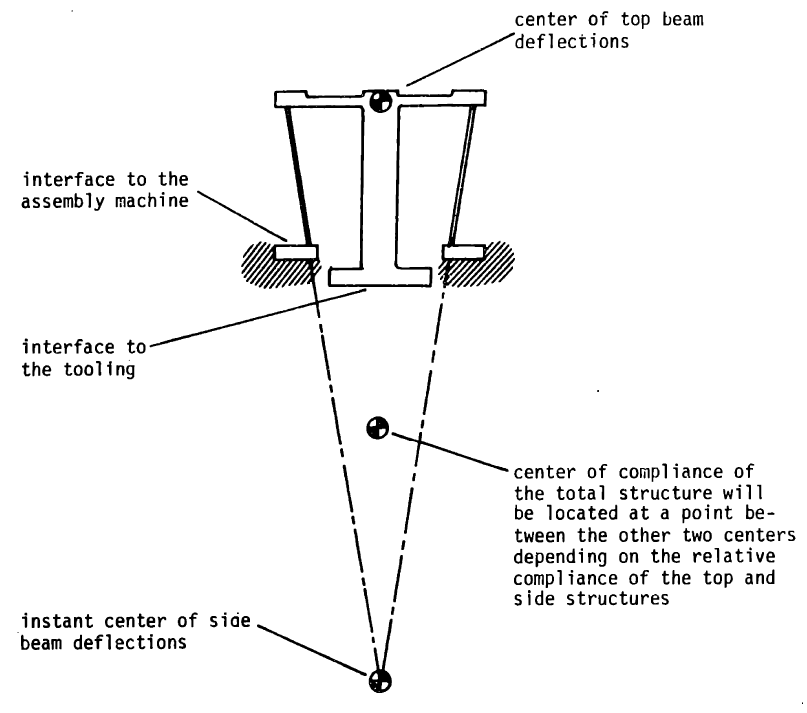
S. H. Drake, “Using compliance in lieu of sensory feedback for automatic assembly.,” Massachusetts Institute of Technology, 1978.