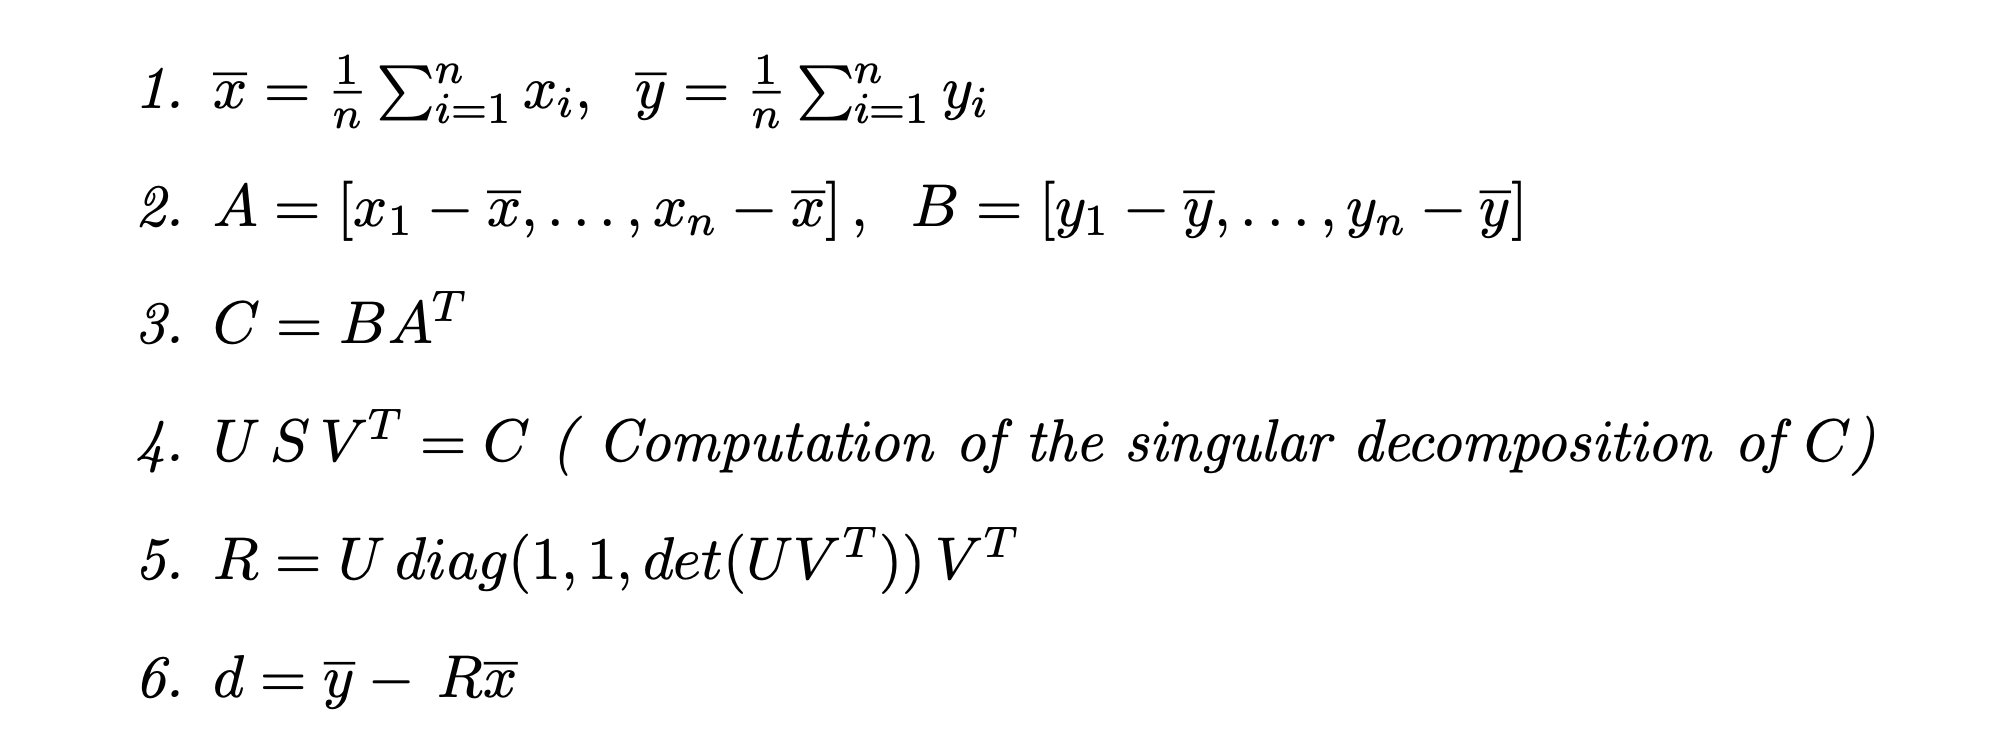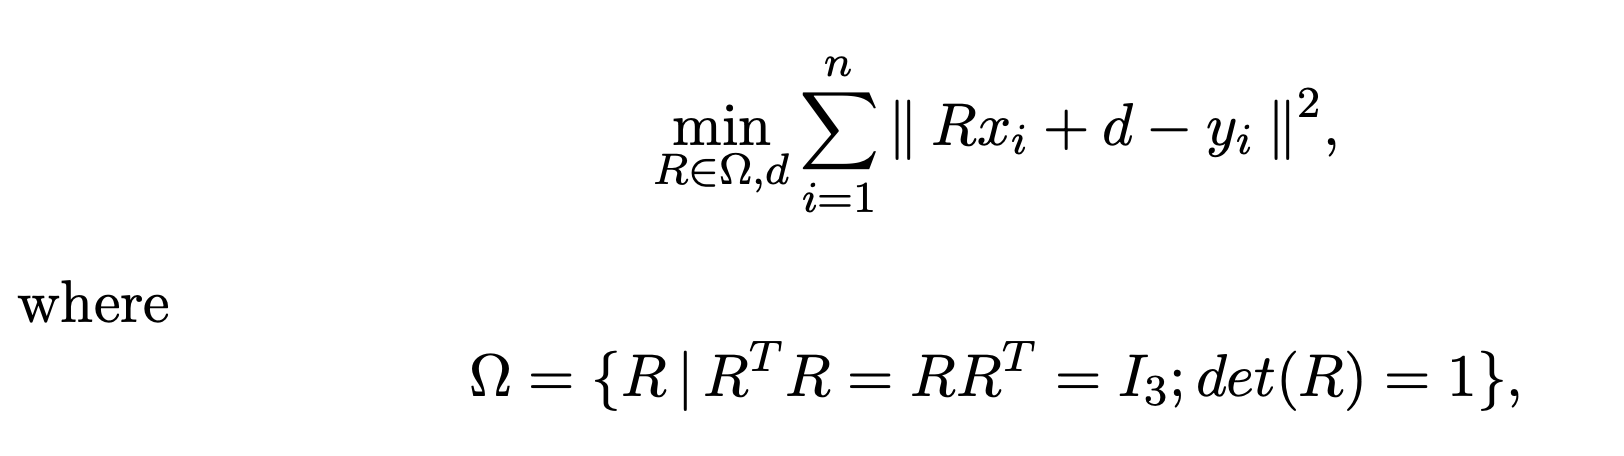Perception I
MIT 6.4210/2:
Robotic Manipulation
Fall 2026, Lecture 16
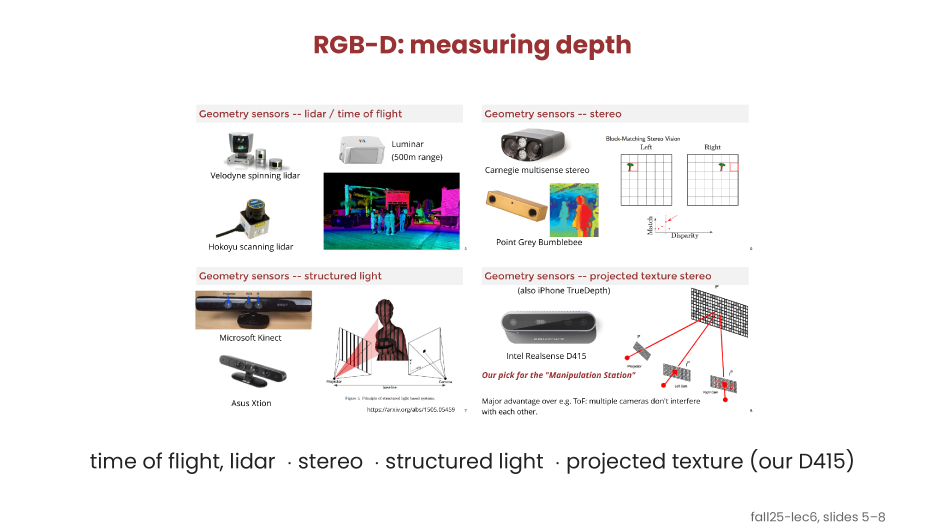
Geometry sensors -- lidar / time of flight
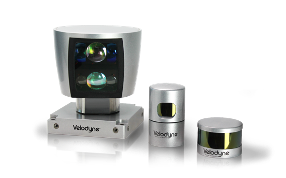
Velodyne spinning lidar
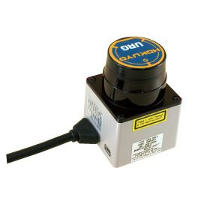
Hokoyu scanning lidar
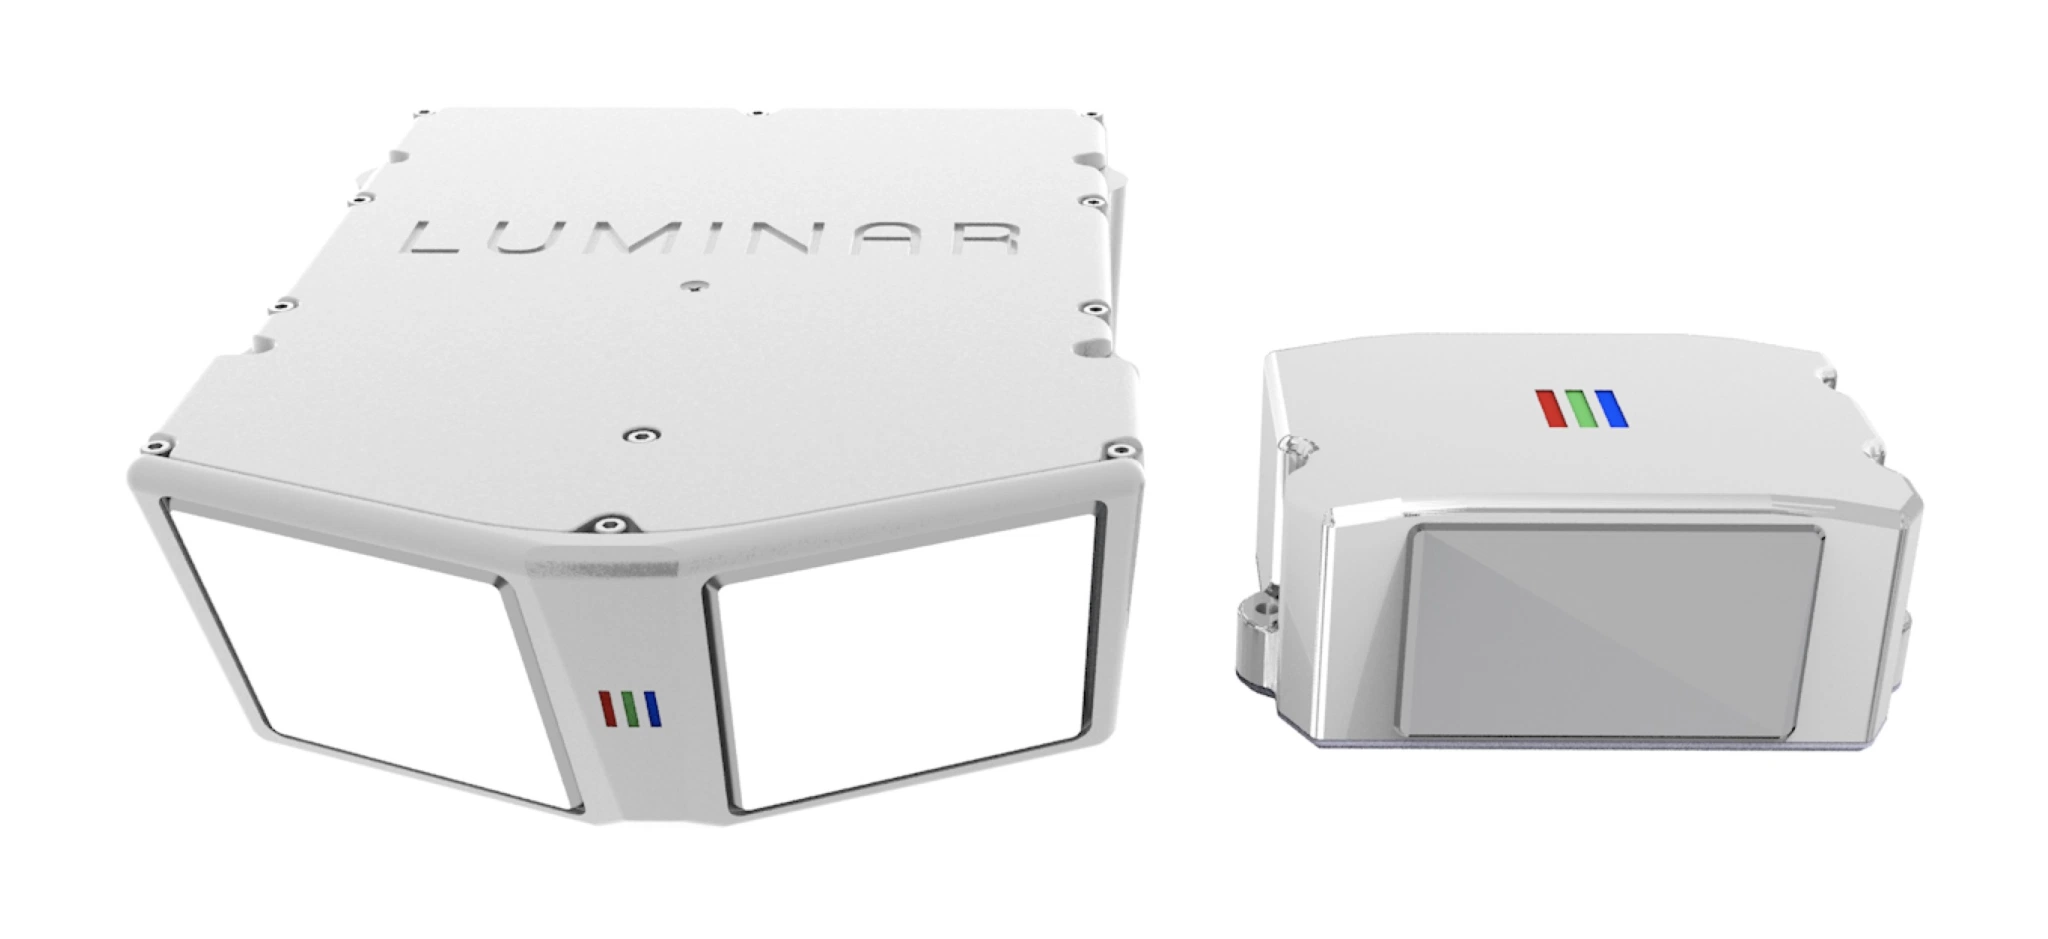
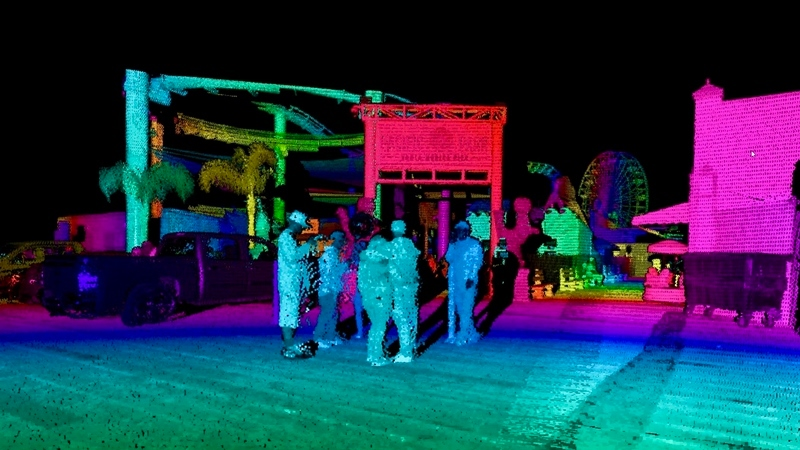
Luminar
(500m range)
Geometry sensors -- stereo
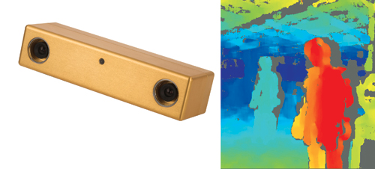
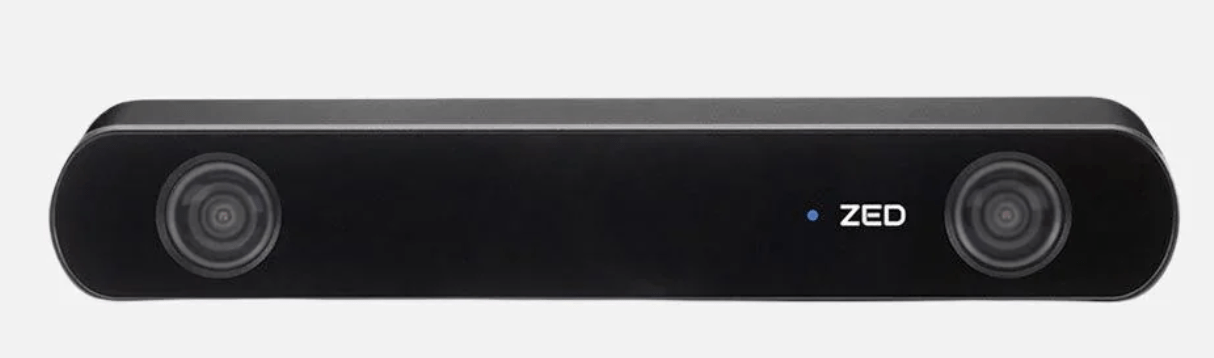
Zed 2i
Point Grey Bumblebee
Geometry sensors -- structured light
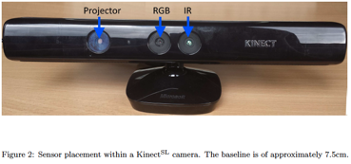
Microsoft Kinect
Asus Xtion
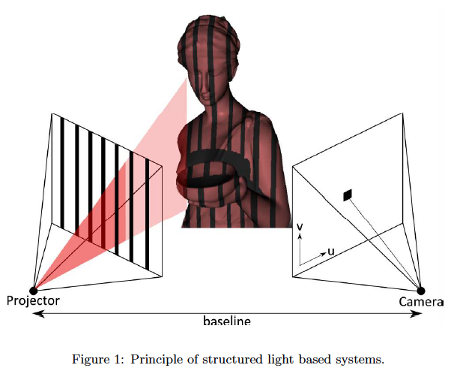
https://arxiv.org/abs/1505.05459
Geometry sensors -- projected texture stereo
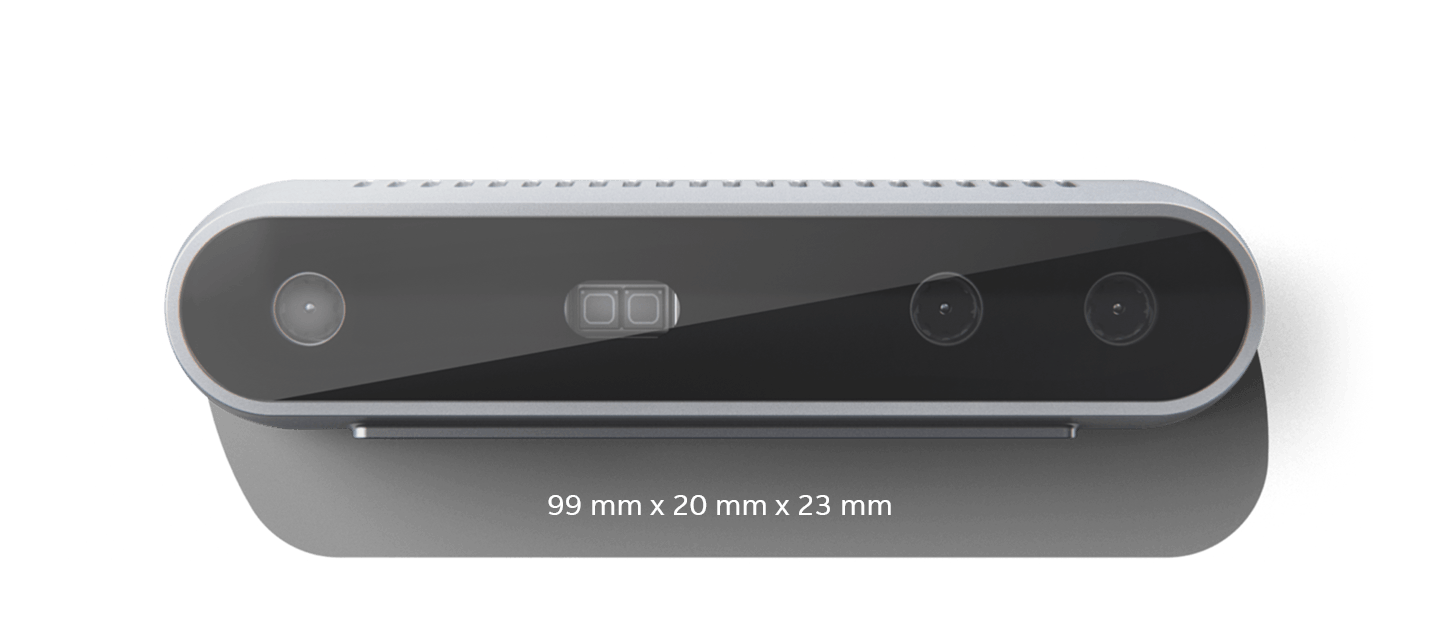
Intel Realsense D415
Our pick for the "Manipulation Station"
Major advantage over e.g. ToF: multiple cameras don't interfere with each other.
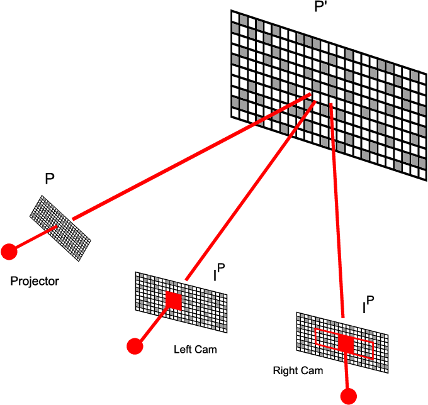
(also iPhone TrueDepth)
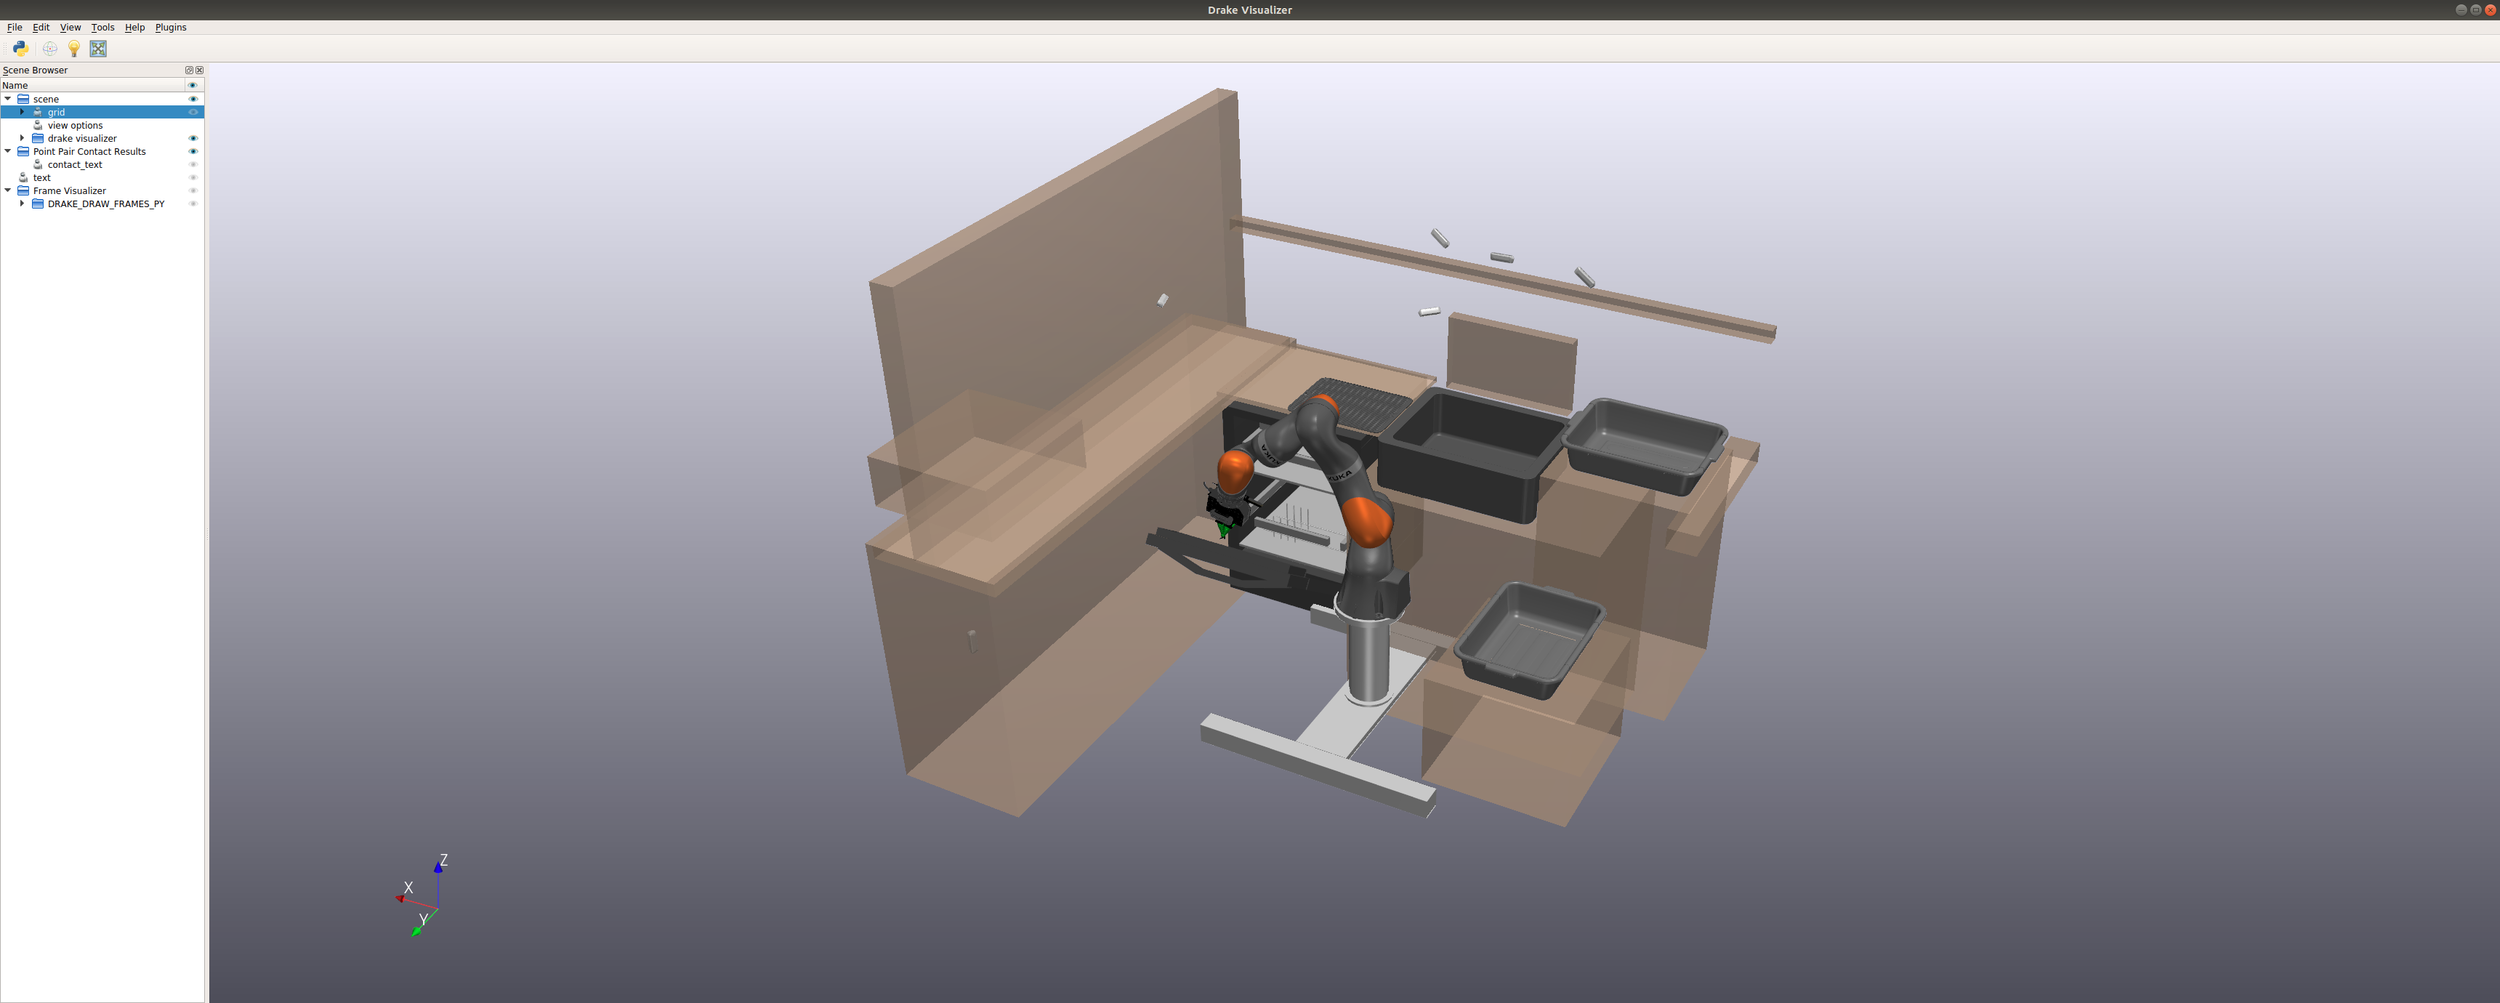
two on wrist
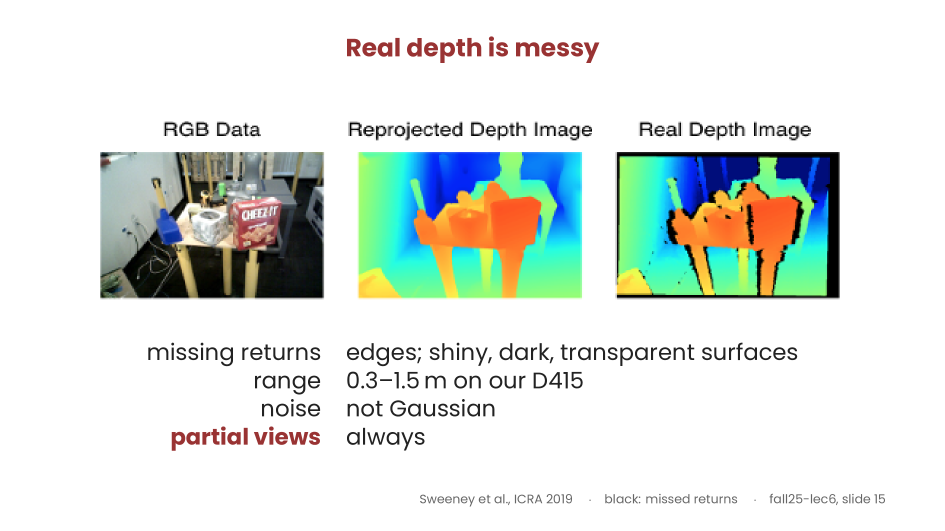
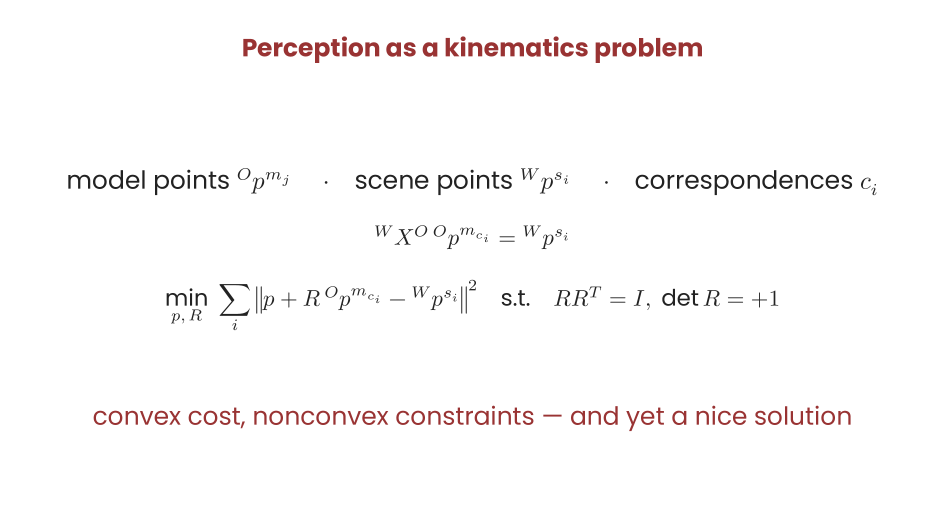
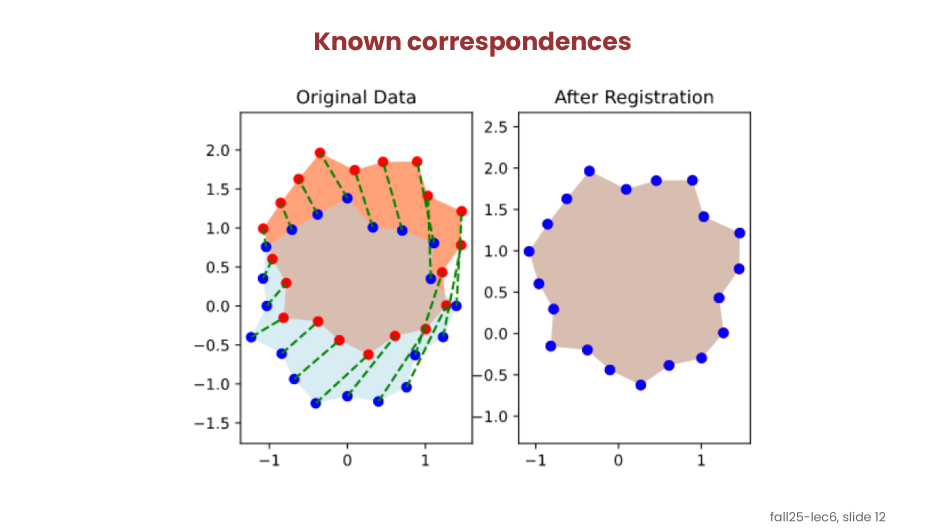
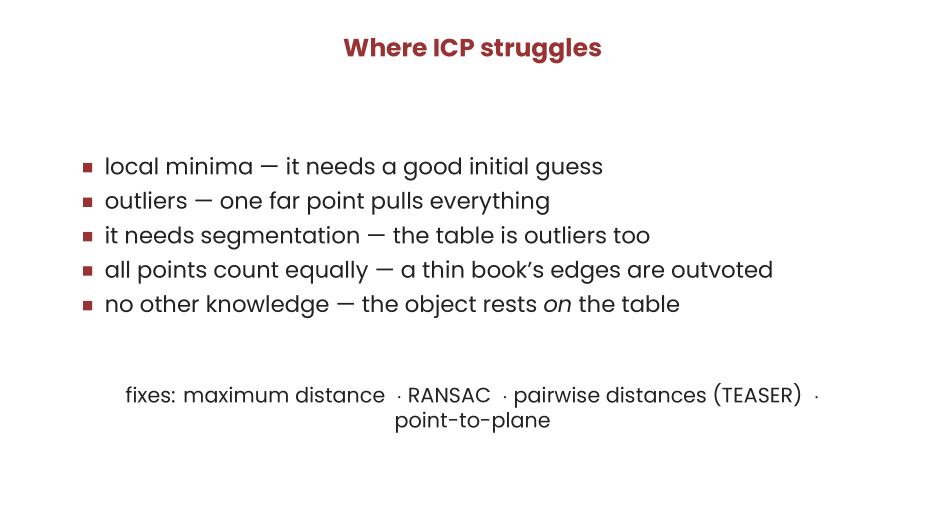
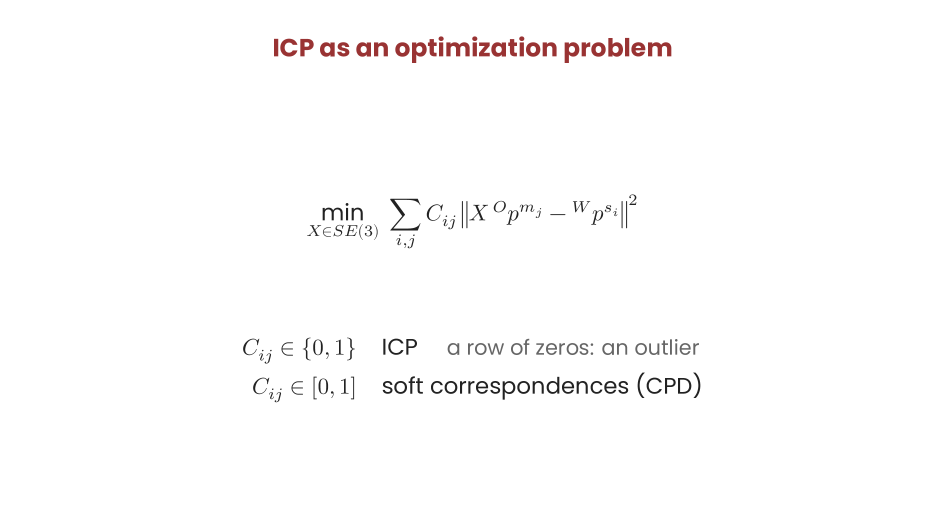
Solving for alignment transform