Frames and Transforms
MIT 6.4210/2: Robotic Manipulation
Fall 2026, Lecture 3
Office Hours
- Tuesday 7 - 9 PM in 36-112
- Wednesday 7 - 9 PM in 36-153
- Thursday 3 - 7 PM in 36-112
Why learn the basics
- Real robot systems (even "end-to-end" ML) are built on a control and perception stack.
- You need to understand the constraints imposed by the real systems.
- You need to understand what your coding agent produces.
Robot throwing in
Drake (by Claude)
Basic Pick and Place
Step 1: Kinematic Frames / Spatial Algebra
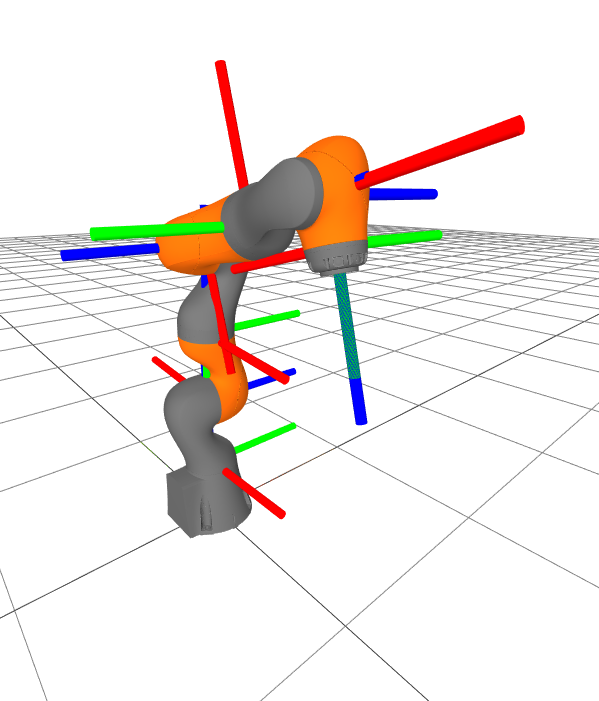
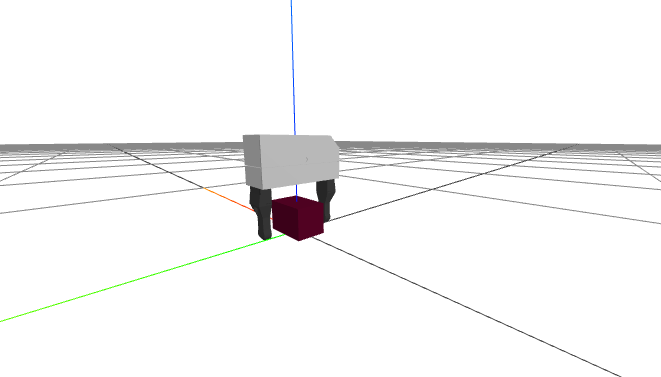
Step 2: Gripper Frame Plan "Sketch"
Step 3: Forward kinematics of the iiwa + WSG
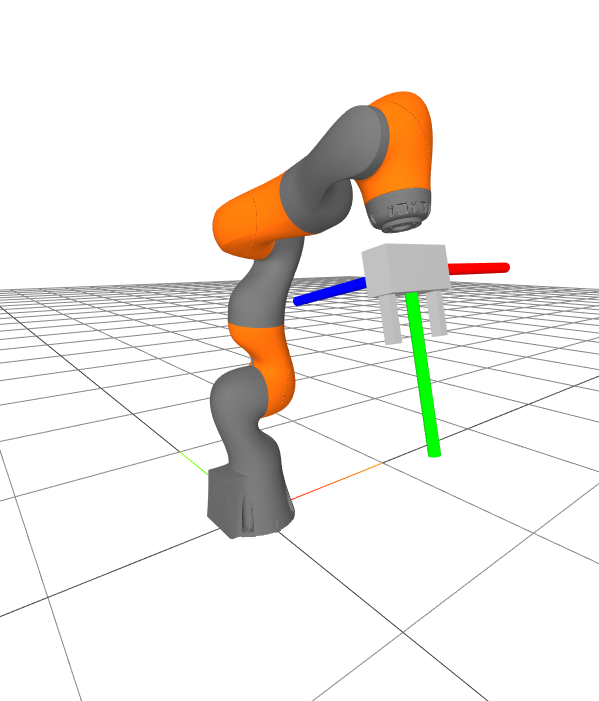
Step 4: Differential Inverse Kinematics
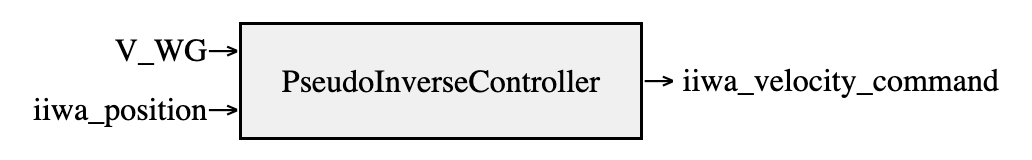
Kinematic Jacobian: \( {}^WV^G = J^{G}(q) v \)
\( v = [J^{G}(q)]^{+} {}^WV^G \)
spatial velocity
generalized velocity
Step 1: Kinematic Frames / Spatial Algebra
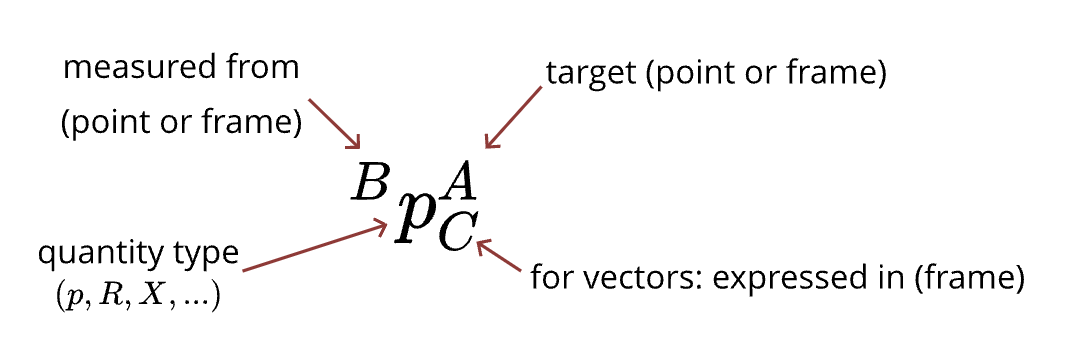
Monogram notation
Check yourself
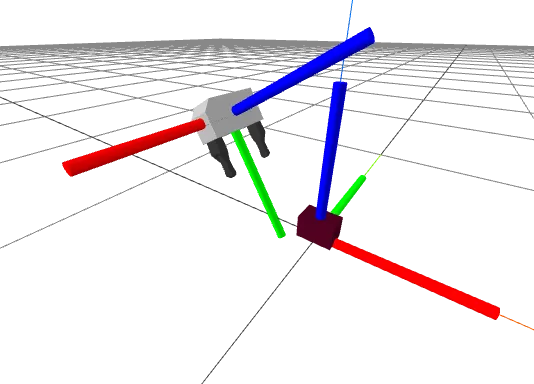
- \(G\) is the gripper frame
- \(O\) is the object frame
which is a possible value for \({}^Gp^O\)?
a) [.3, 0, -.1]
b) [0, .3, .1]
c) [0, -.3, .1]
Answer: (b)
Check yourself 2
- \(G\) is the gripper frame
- \(O\) is the object frame
which is a possible value for \({}^Gp^O_O\)?
a) [.3, 0, -.1]
b) [0, .3, .1]
c) [0, -.3, .1]
Answer: (a)
Representations of Rotation
- Rotation matrix
- Euler angles
- Axis-angle
- Quaternions
Rotations (single axis)
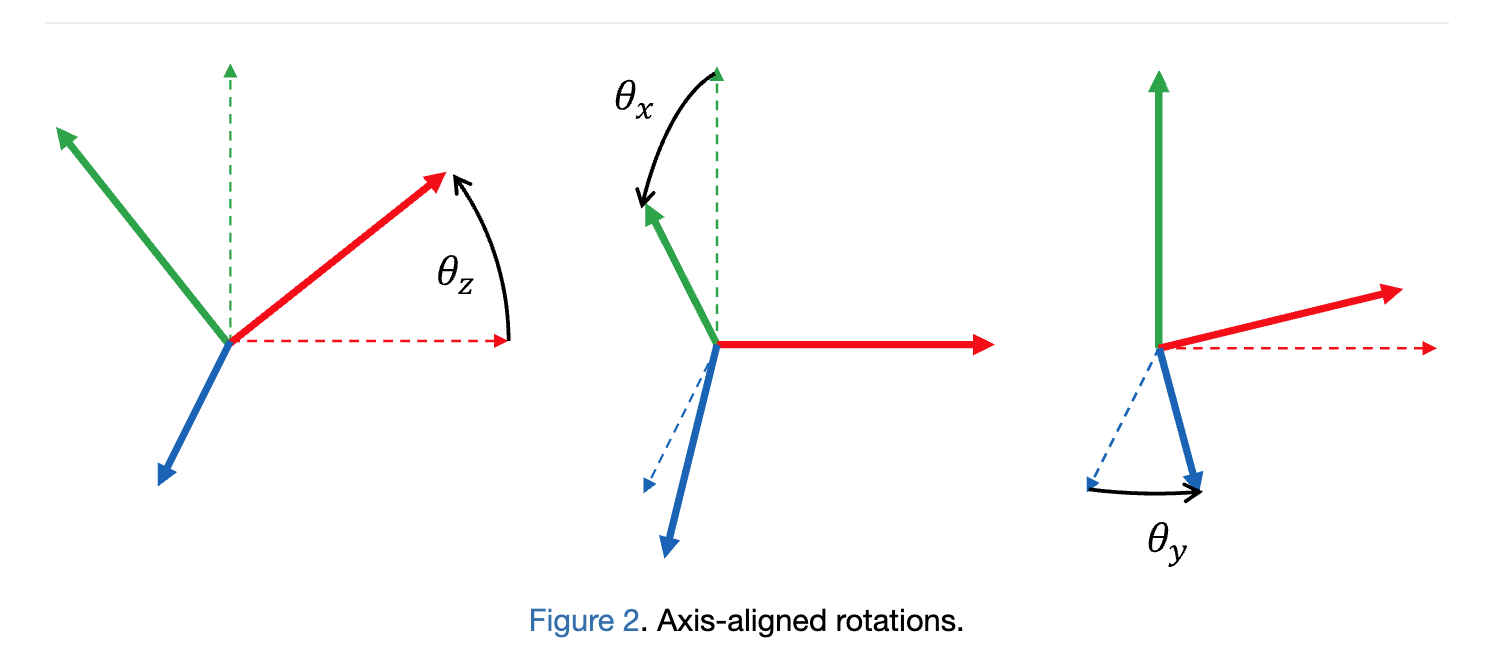
Roll Pitch Yaw (extrinsic)
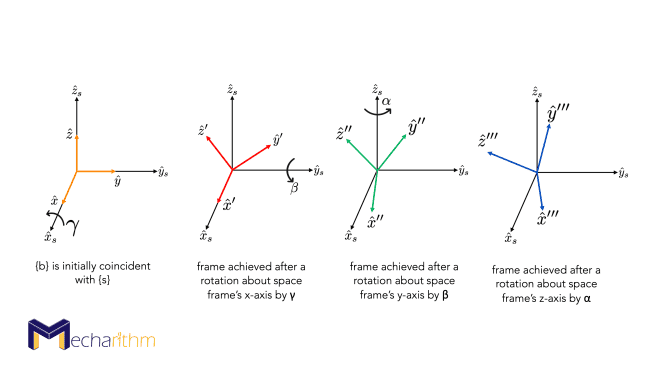
Example: Gimbal Lock
Step 2: Gripper Frame Plan "Sketch"
def MakeGripperFrames(X_WG, X_WO):
    """
    Takes a partial specification with X_G["initial"] and X_O["initial"] and
    X_0["goal"], and returns a X_G and times with all of the pick and place
    frames populated.
    """
    # Define (again) the gripper pose relative to the object when in grasp.
    p_GgraspO = [0, 0.11, 0]
    R_GgraspO = RotationMatrix.MakeXRotation(
        np.pi / 2.0
    ) @ RotationMatrix.MakeZRotation(np.pi / 2.0)
    X_GgraspO = RigidTransform(R_GgraspO, p_GgraspO)

    X_OGgrasp = X_GgraspO.inverse()
    # pregrasp is negative y in the gripper frame (see the figure!).
    X_GgraspGpregrasp = RigidTransform([0, -0.08, 0])

    X_WG["pick"] = X_WO["initial"] @ X_OGgrasp
    X_WG["prepick"] = X_WG["pick"] @ X_GgraspGpregrasp
    X_WG["place"] = X_WO["goal"] @ X_OGgrasp
    X_WG["preplace"] = X_WG["place"] @ X_GgraspGpregrasp

    # I'll interpolate a halfway orientation by converting to axis angle and halving the angle.
    X_GprepickGpreplace = X_WG["prepick"].inverse() @ X_WG["preplace"]
    angle_axis = X_GprepickGpreplace.rotation().ToAngleAxis()
    X_GprepickGclearance = RigidTransform(
        AngleAxis(angle=angle_axis.angle() / 2.0, axis=angle_axis.axis()),
        X_GprepickGpreplace.translation() / 2.0 + np.array([0, -0.3, 0]),
    )
    X_WG["clearance"] = X_WG["prepick"] @ X_GprepickGclearance

    # Now let's set the timing
    times = {"initial": 0}
    X_GinitialGprepick = X_G["initial"].inverse() @ X_WG["prepick"]
    times["prepick"] = times["initial"] + 10.0 * np.linalg.norm(
        X_GinitialGprepick.translation()
    )
    # Allow some time for the gripper to close.
    times["pick_start"] = times["prepick"] + 2.0
    times["pick_end"] = times["pick_start"] + 2.0
    X_WG["pick_start"] = X_WG["pick"]
    X_WG["pick_end"] = X_WG["pick"]
    times["postpick"] = times["pick_end"] + 2.0
    X_WG["postpick"] = X_WG["prepick"]
    time_to_from_clearance = 10.0 * np.linalg.norm(
        X_GprepickGclearance.translation()
    )
    times["clearance"] = times["postpick"] + time_to_from_clearance
    times["preplace"] = times["clearance"] + time_to_from_clearance
    times["place_start"] = times["preplace"] + 2.0
    times["place_end"] = times["place_start"] + 2.0
    X_WG["place_start"] = X_WG["place"]
    X_WG["place_end"] = X_WG["place"]
    times["postplace"] = times["place_end"] + 2.0
    X_WG["postplace"] = X_WG["preplace"]

    return X_WG, times
Make sure your trajectory safely clears the bins...