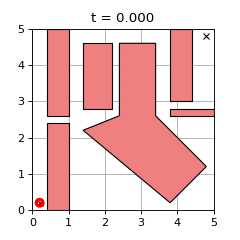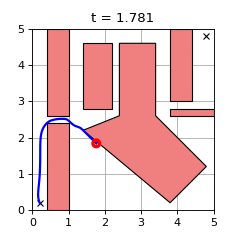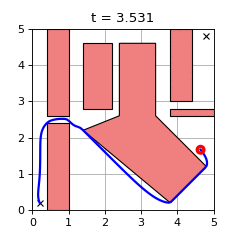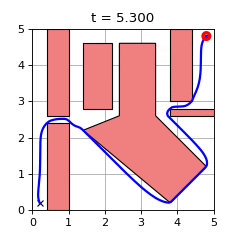
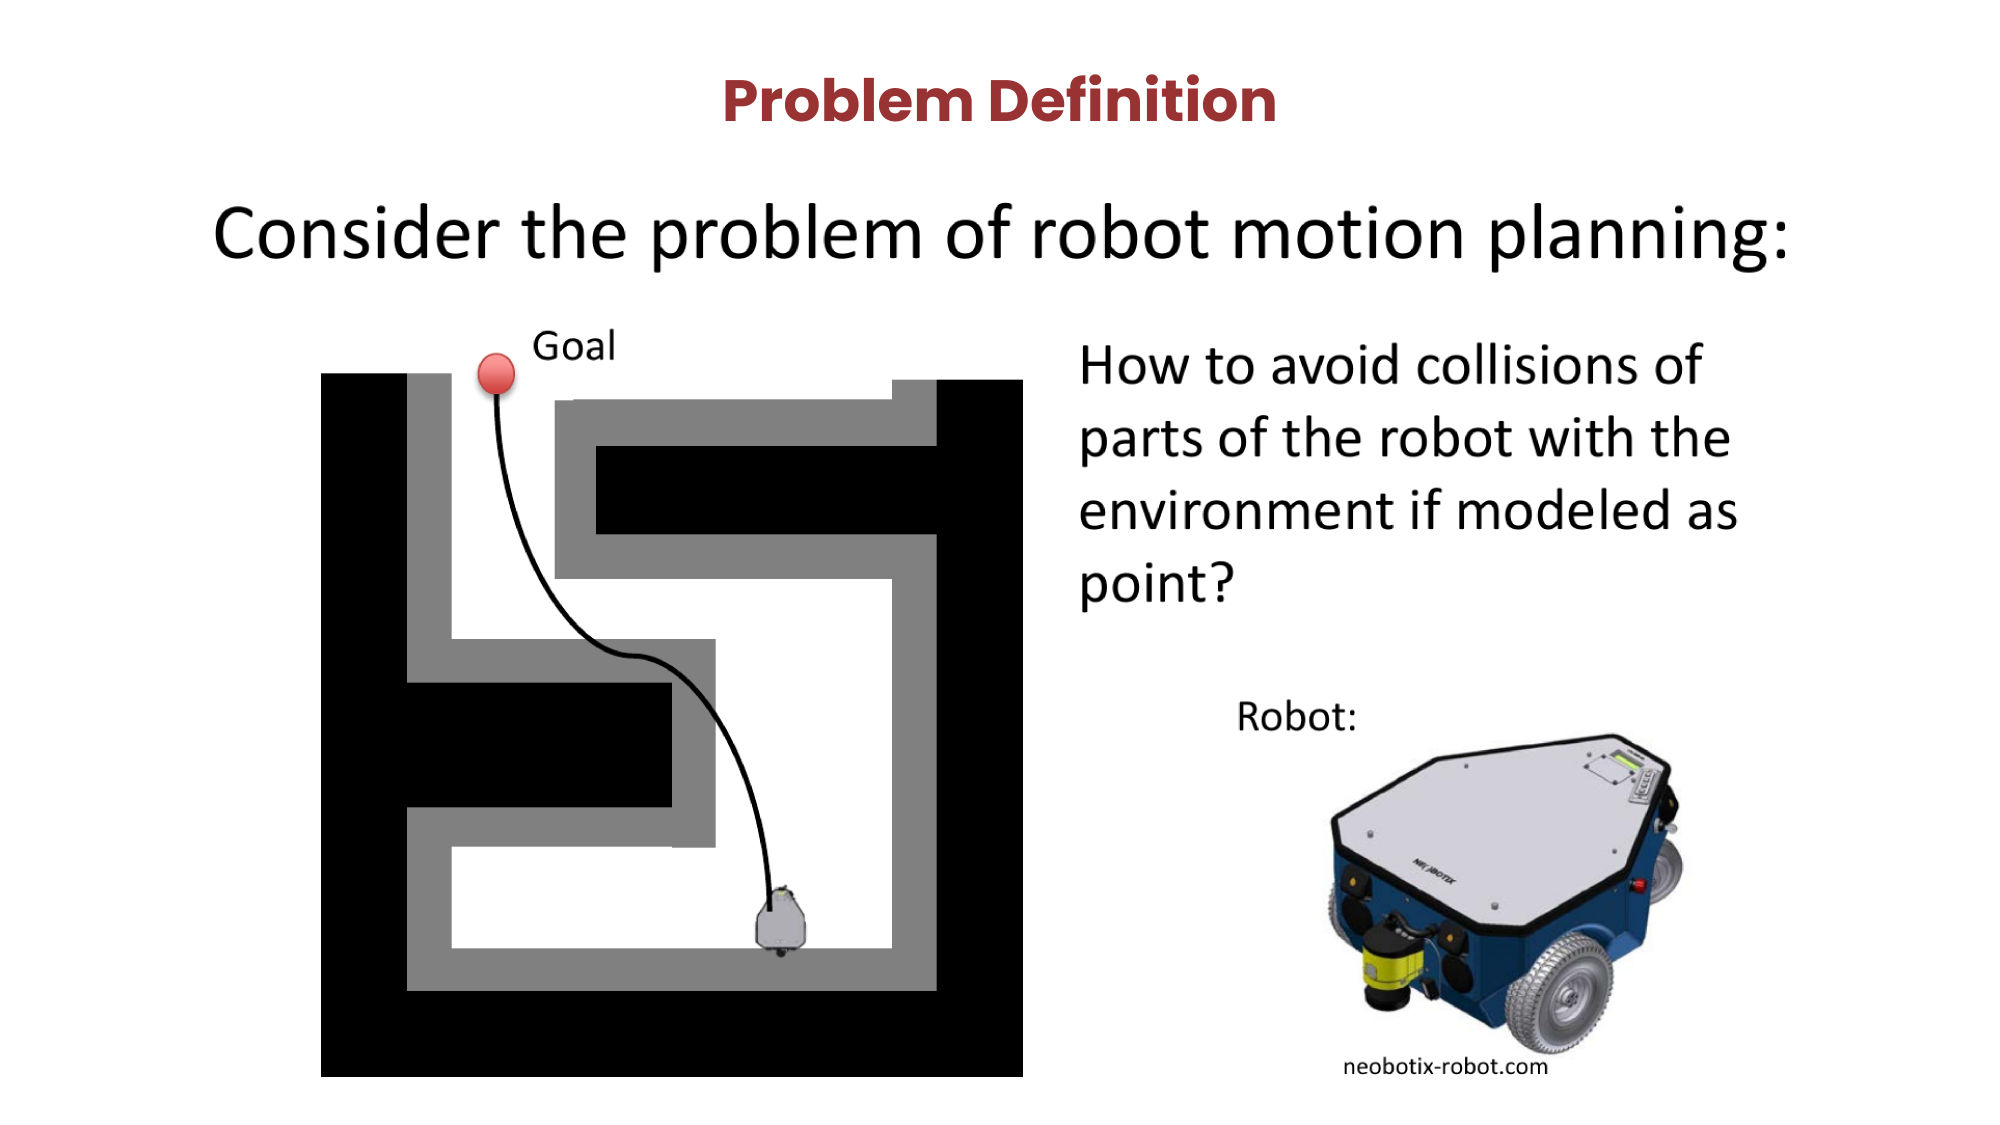
Motion Planning
MIT 6.4210/2
Robotic Manipulation
Fall 2026, Lecture 6
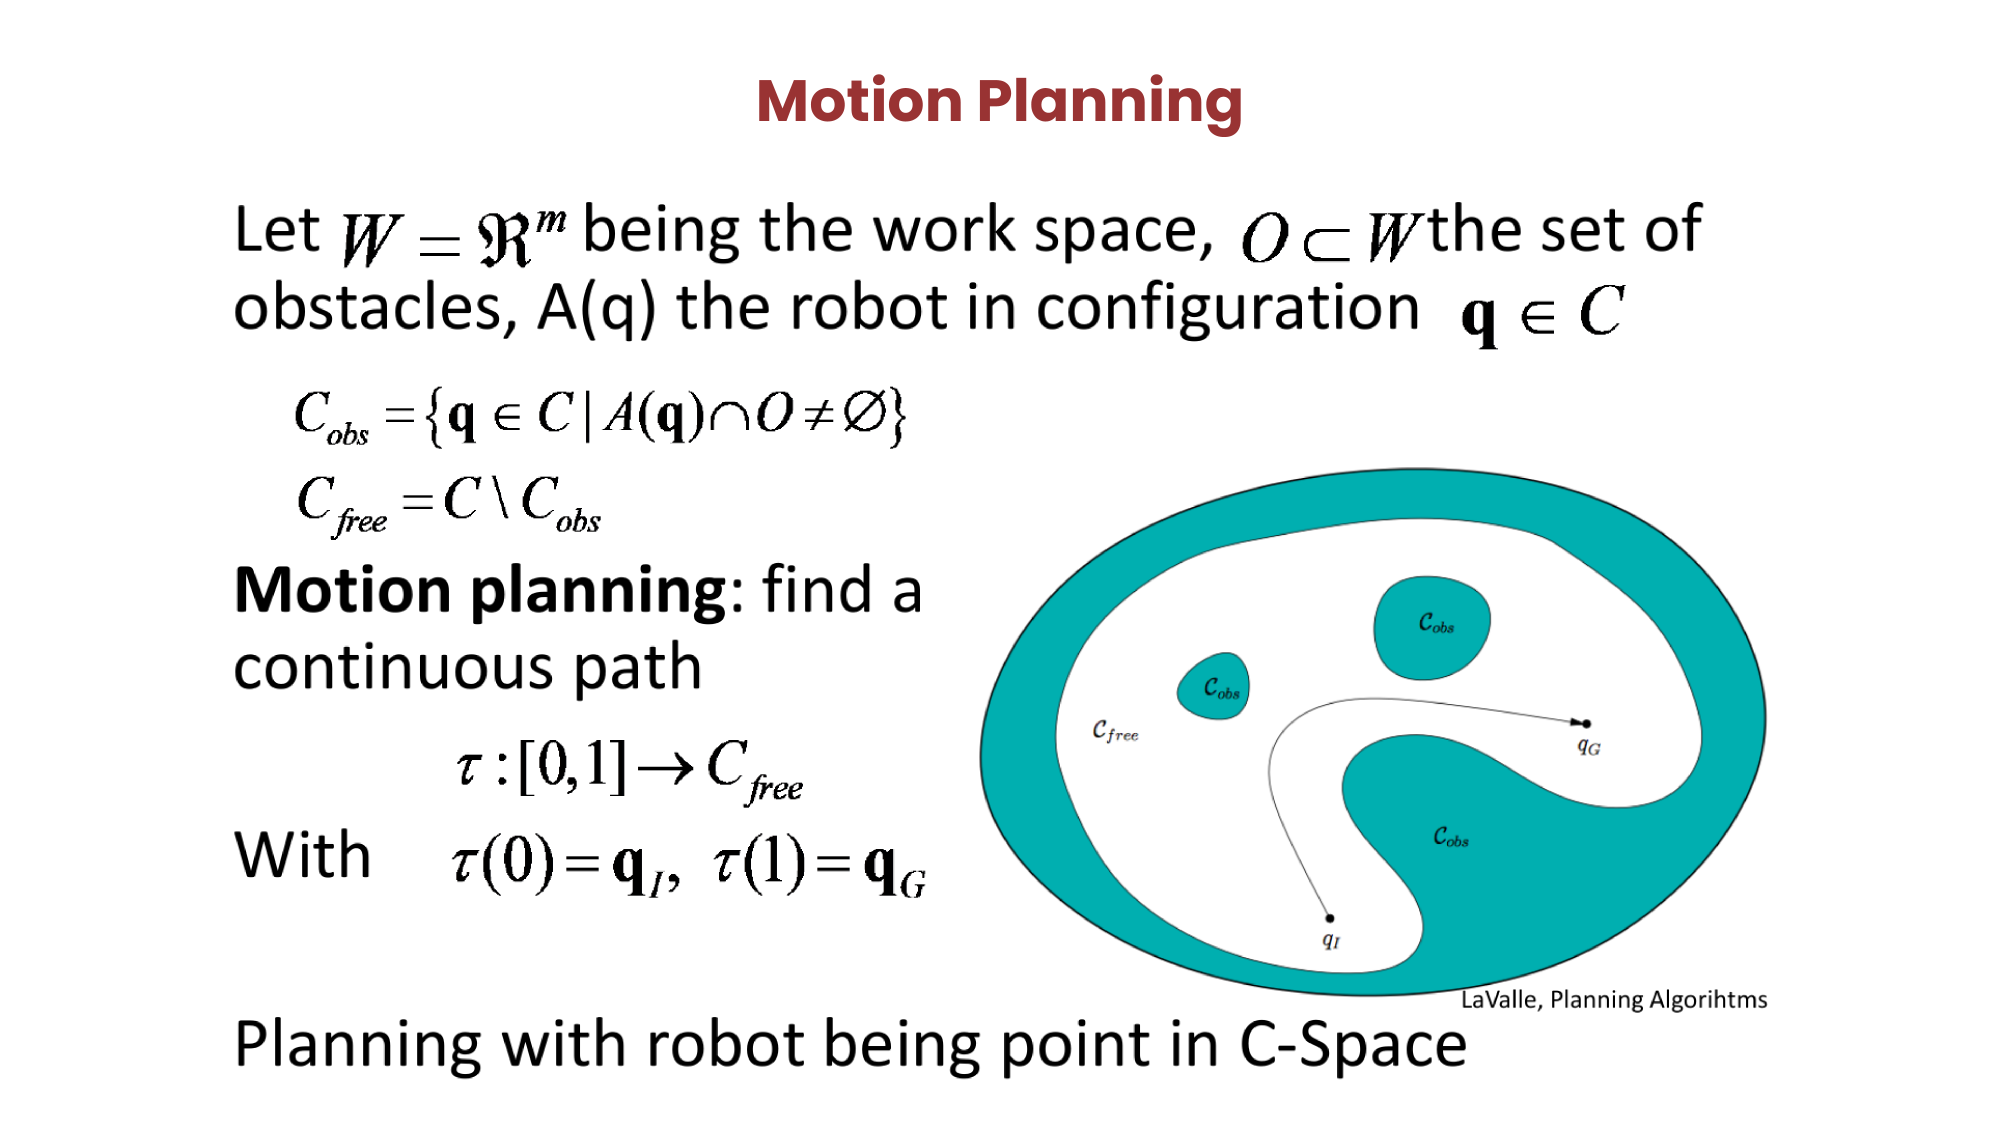
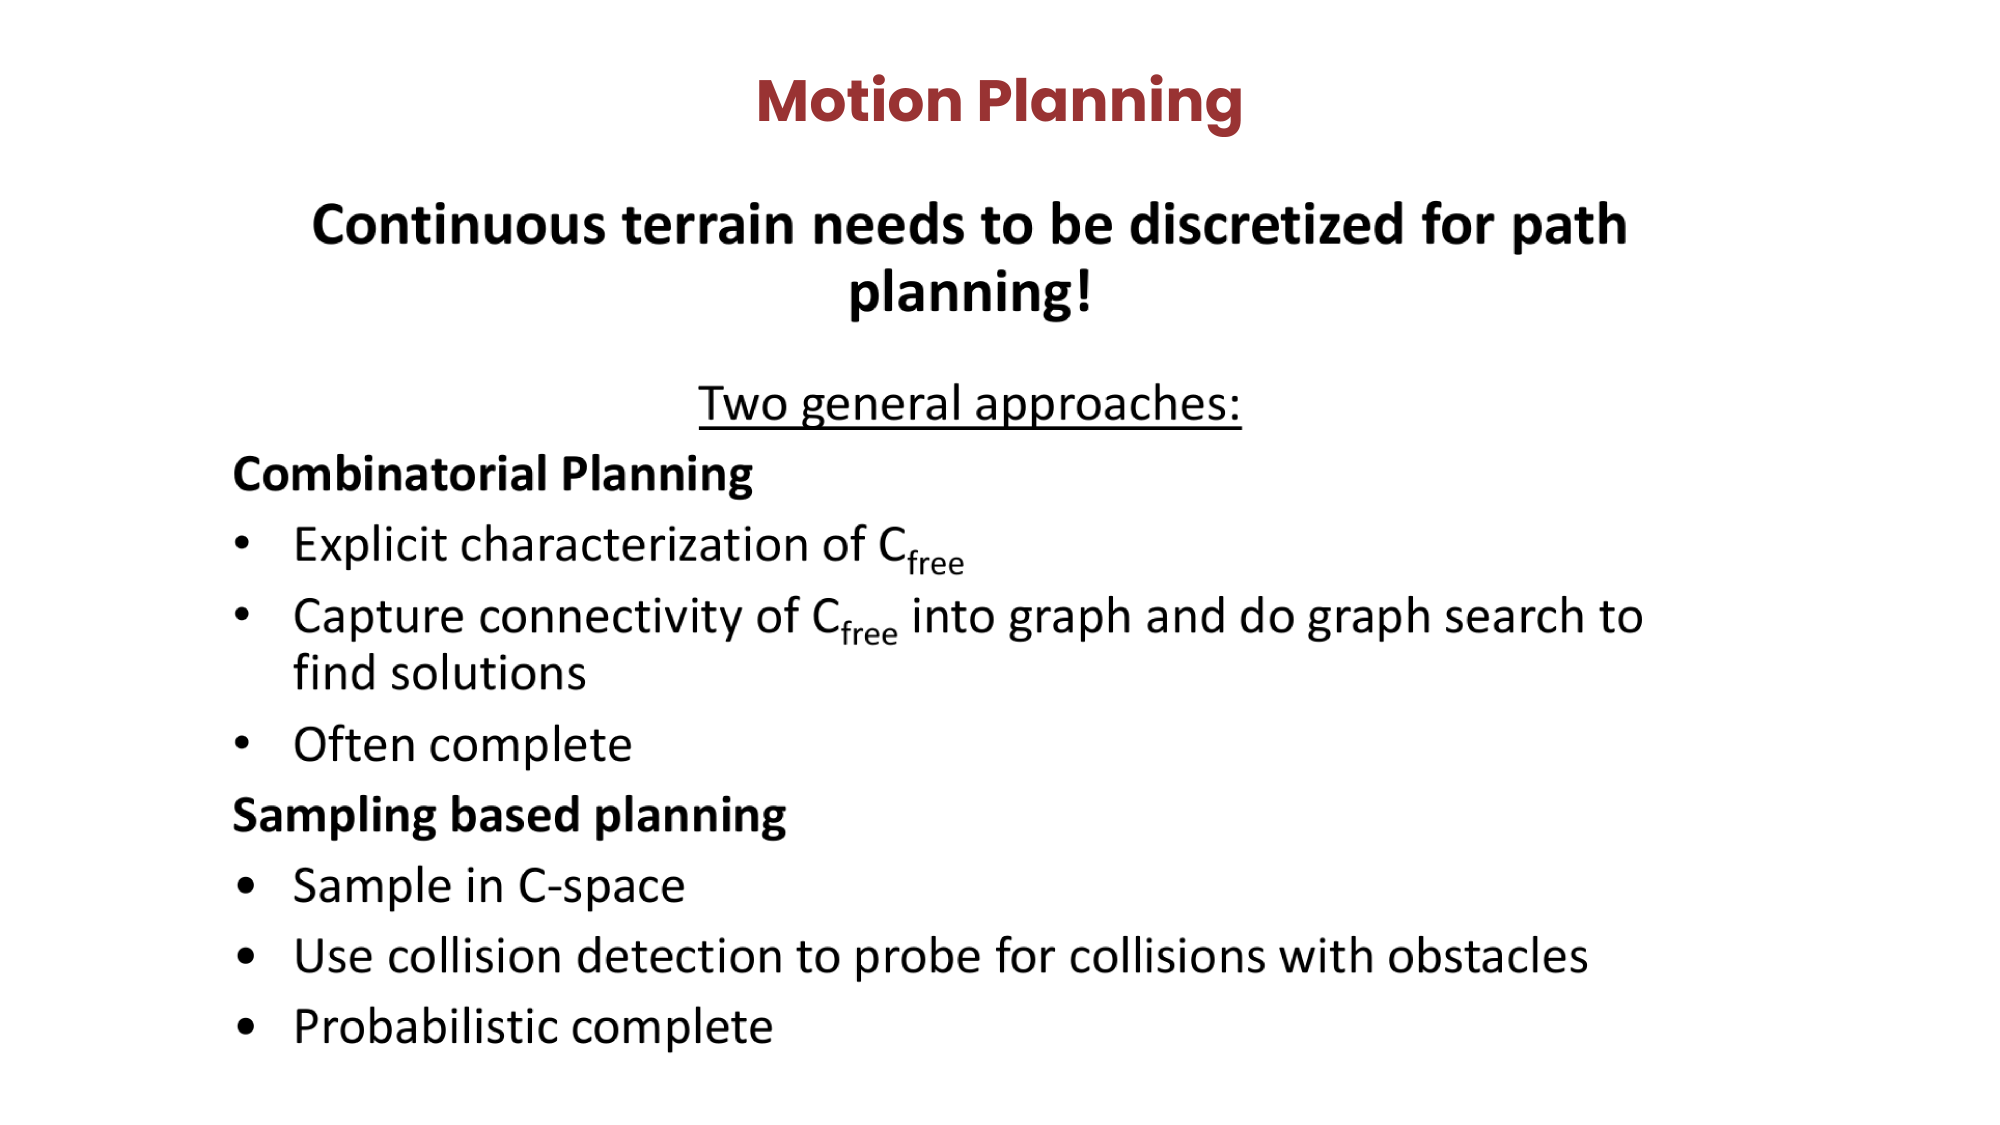
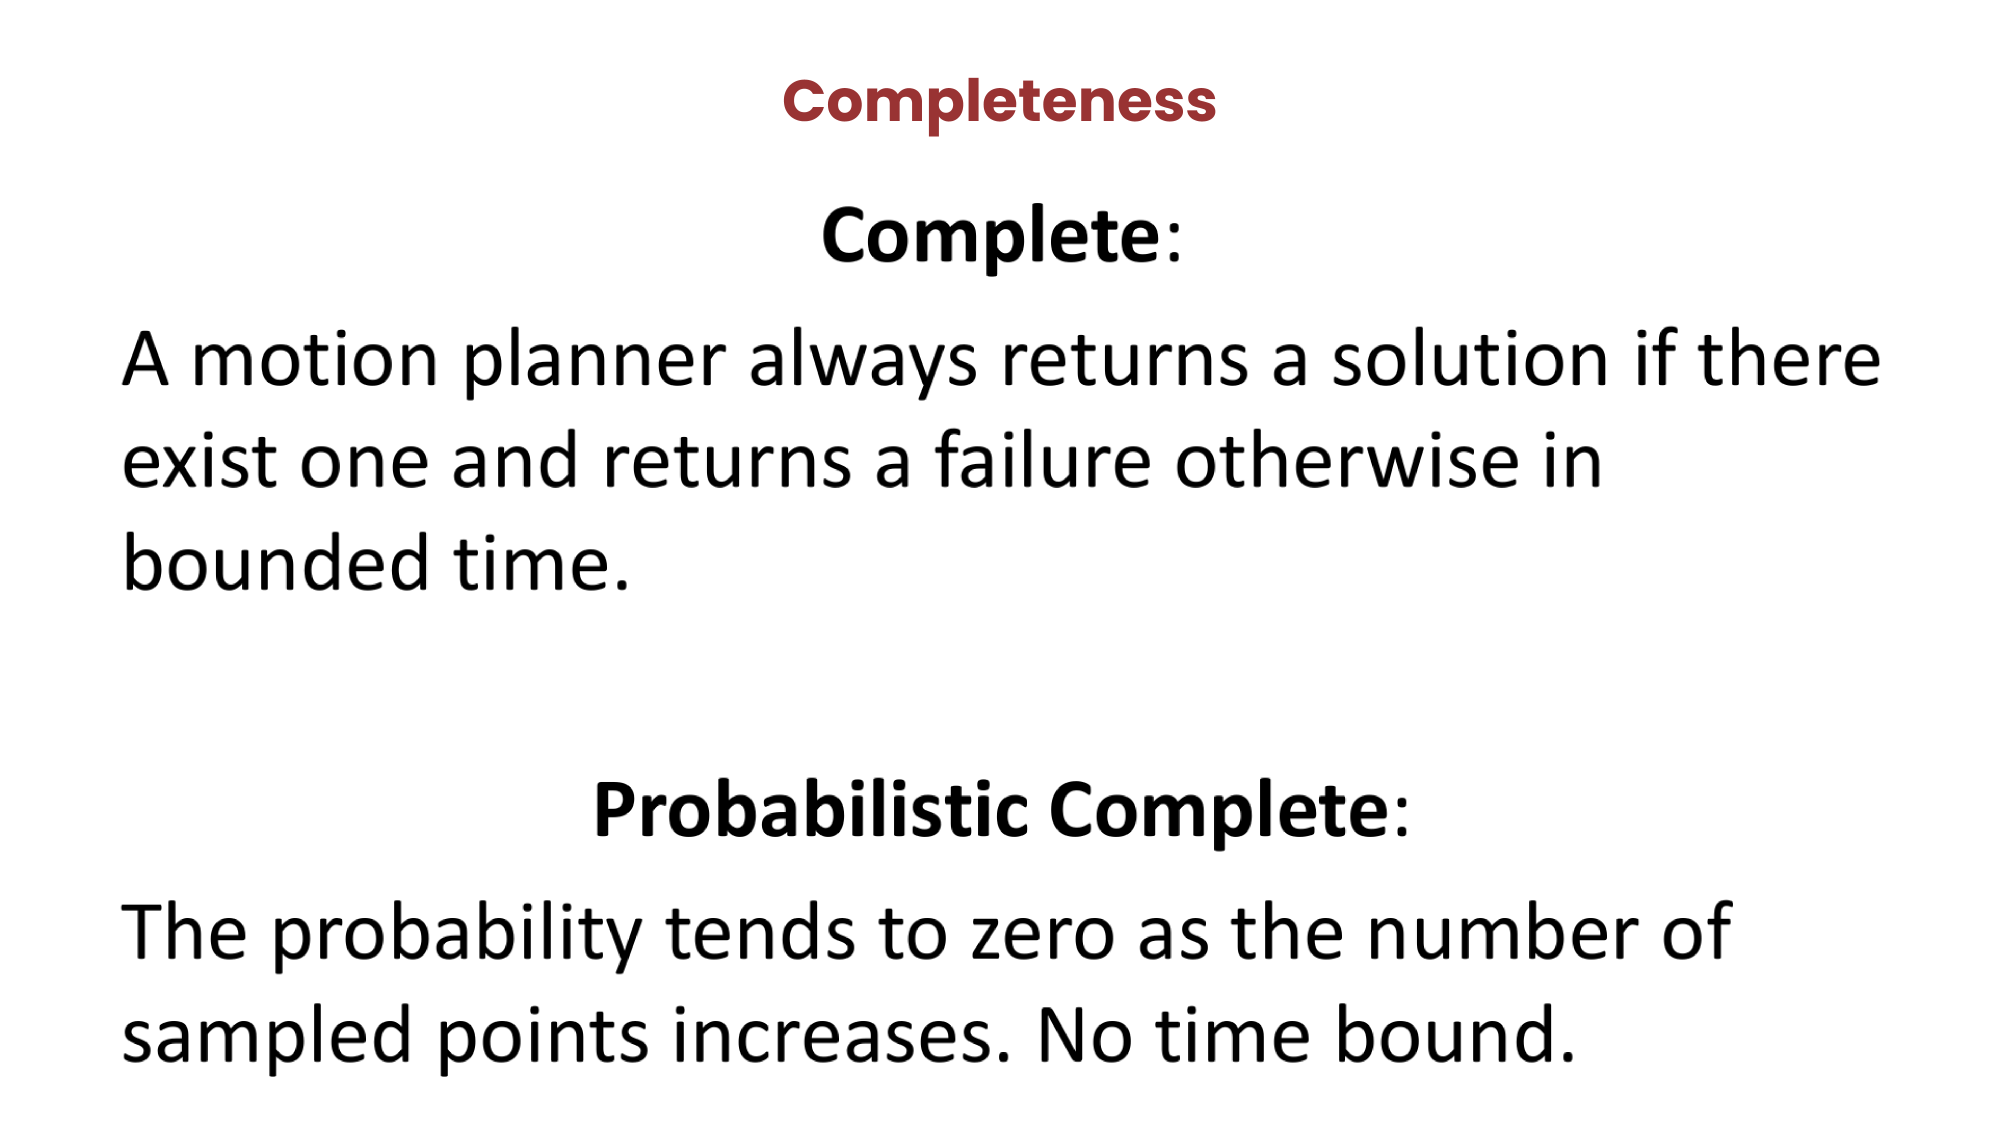
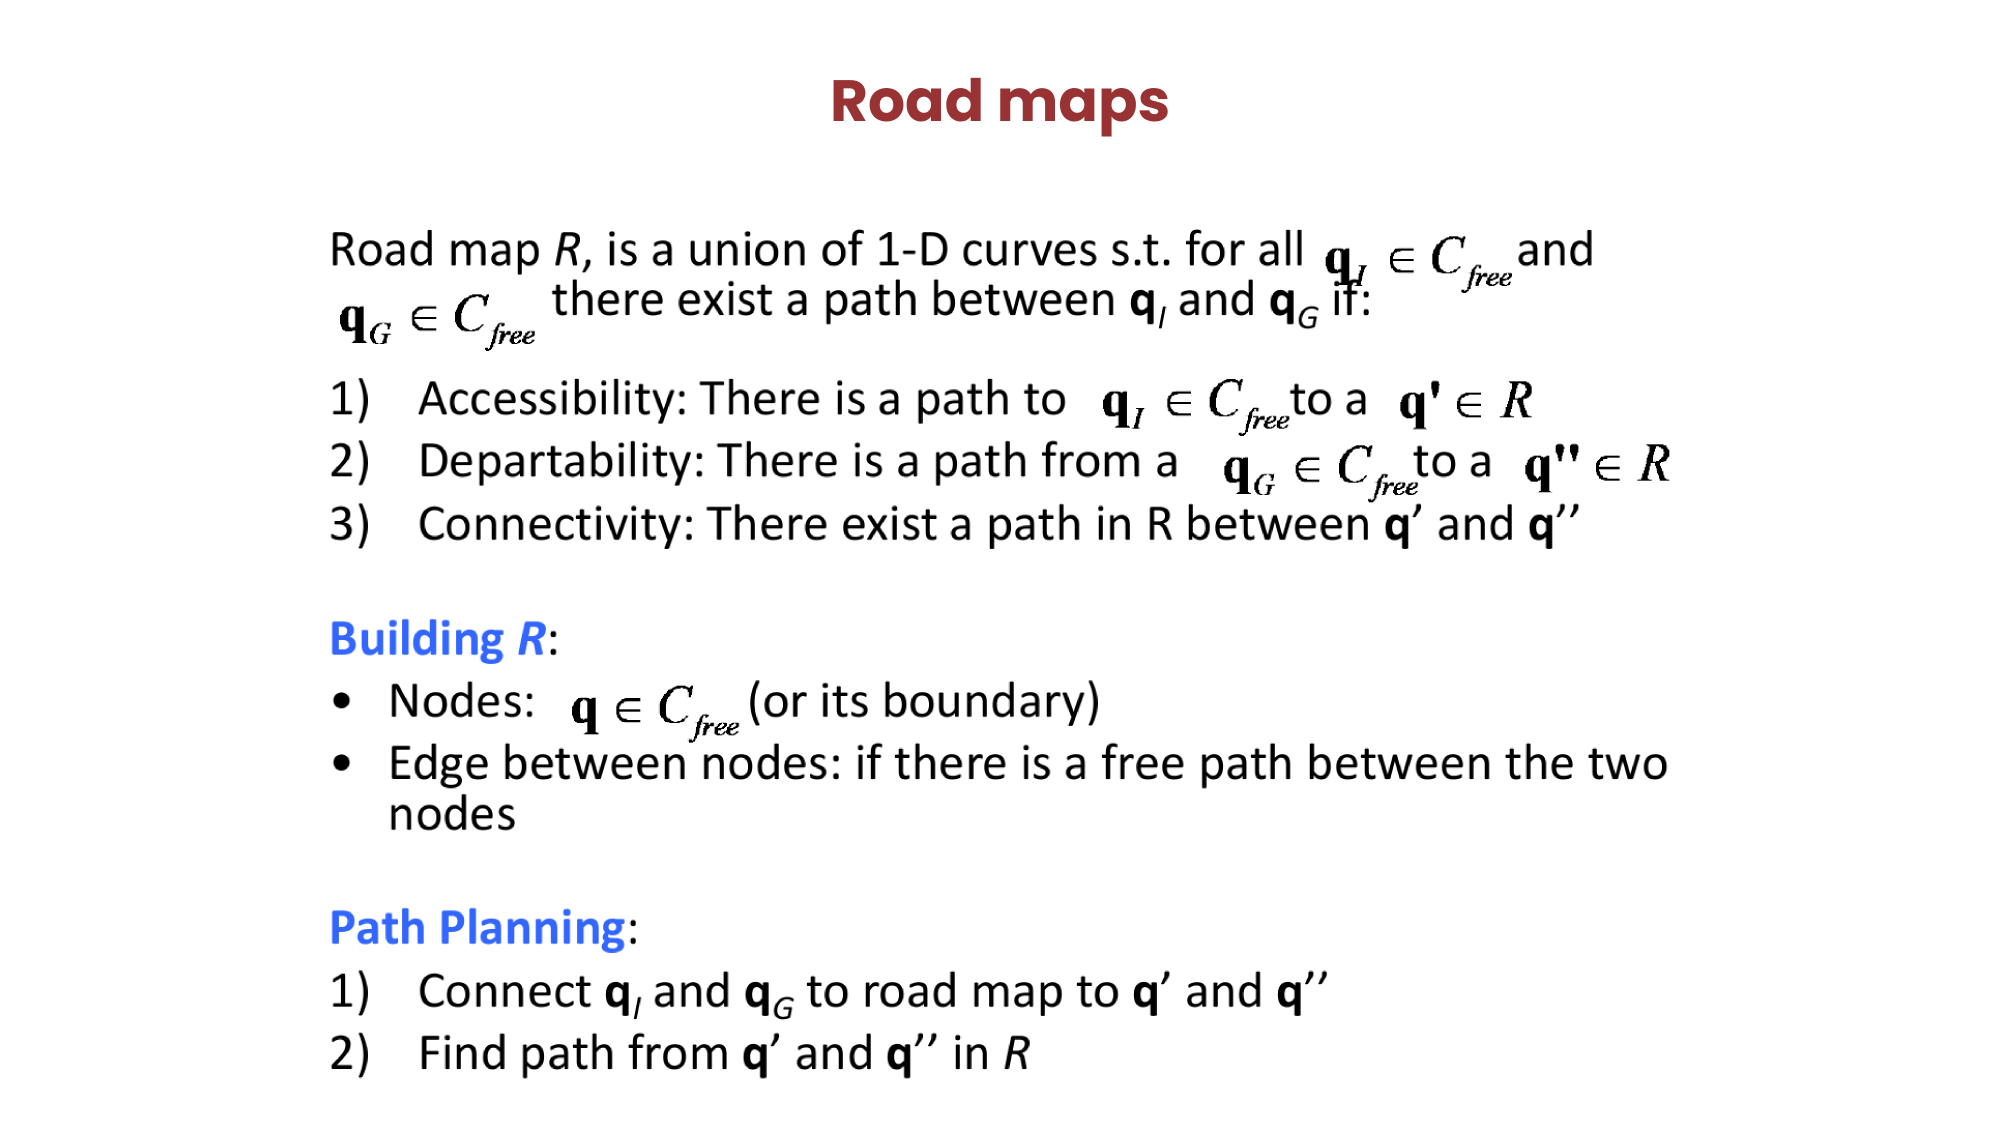
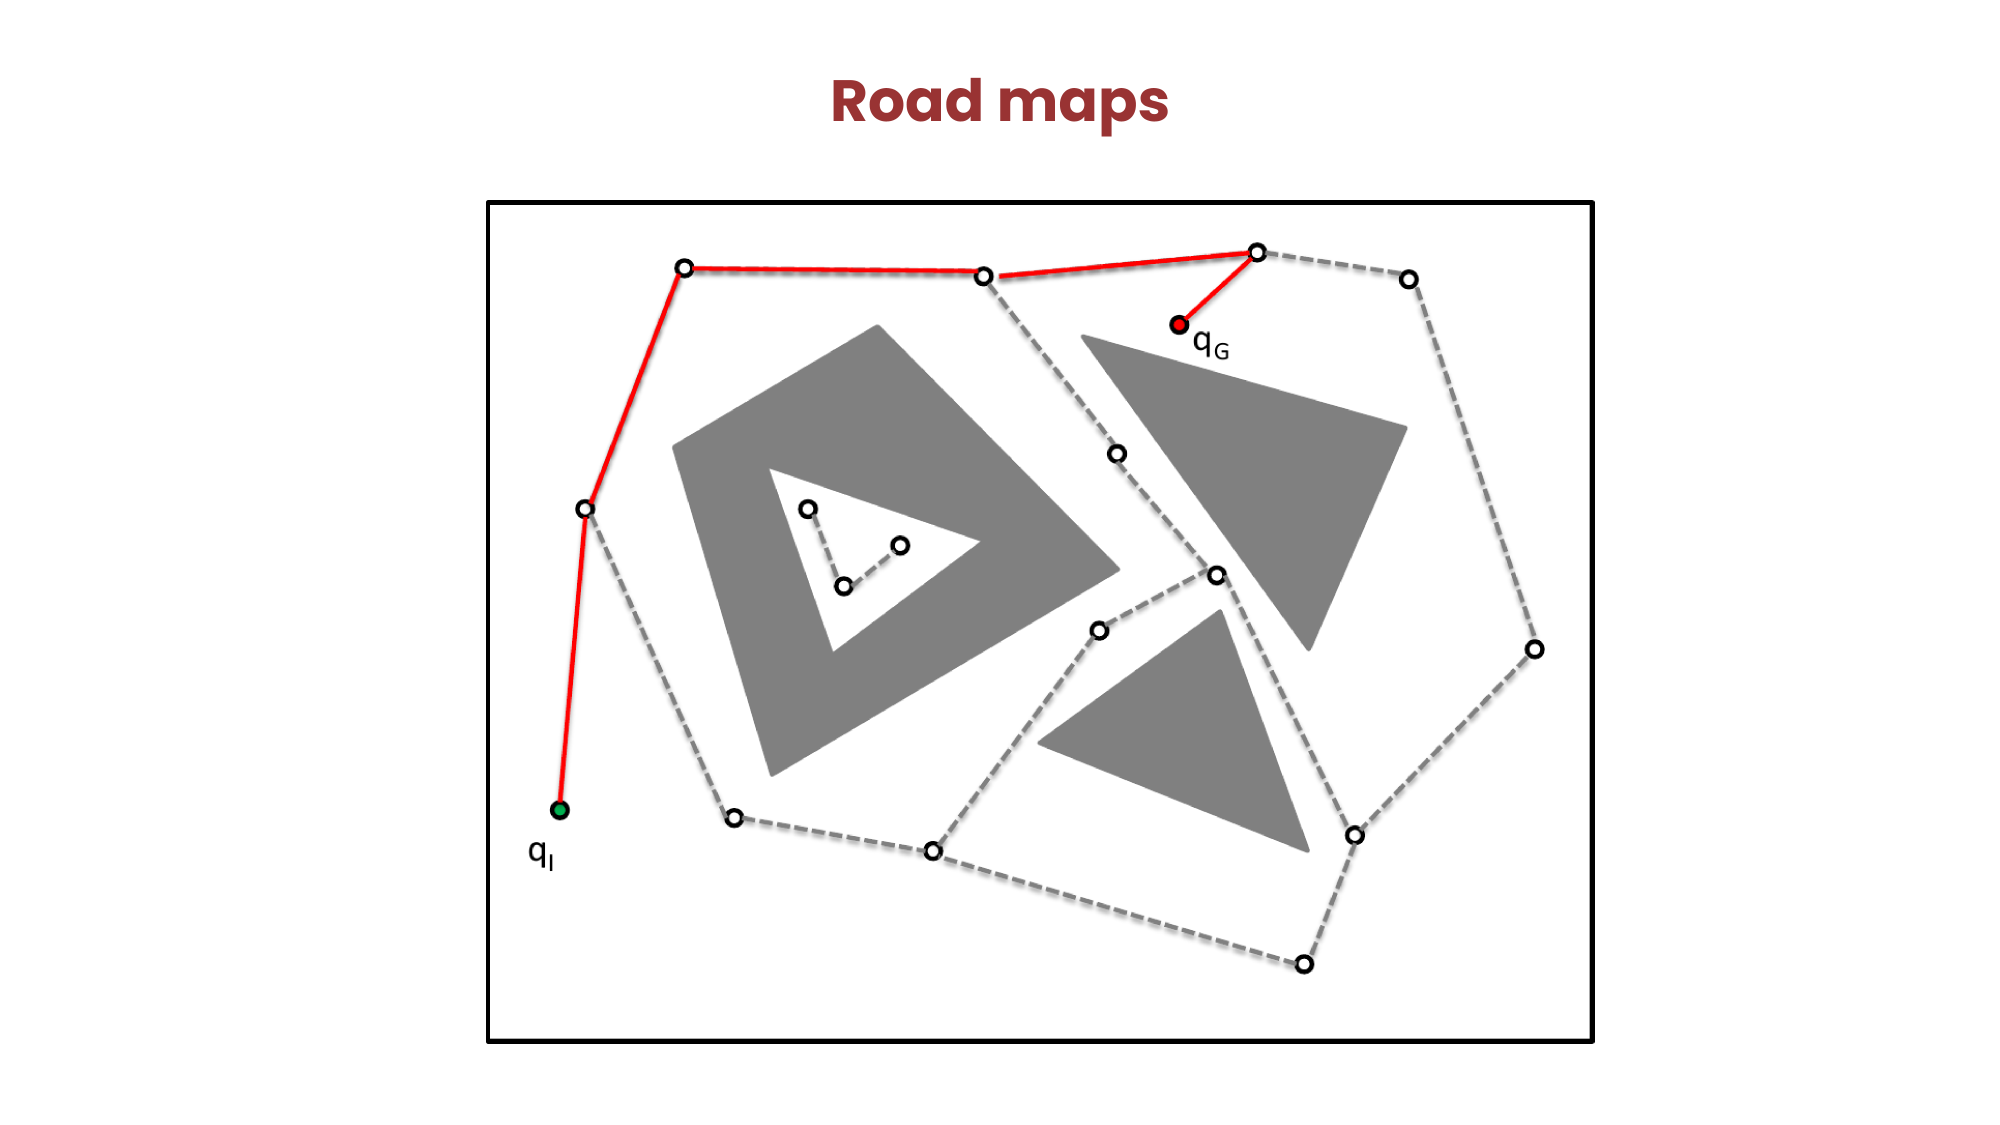
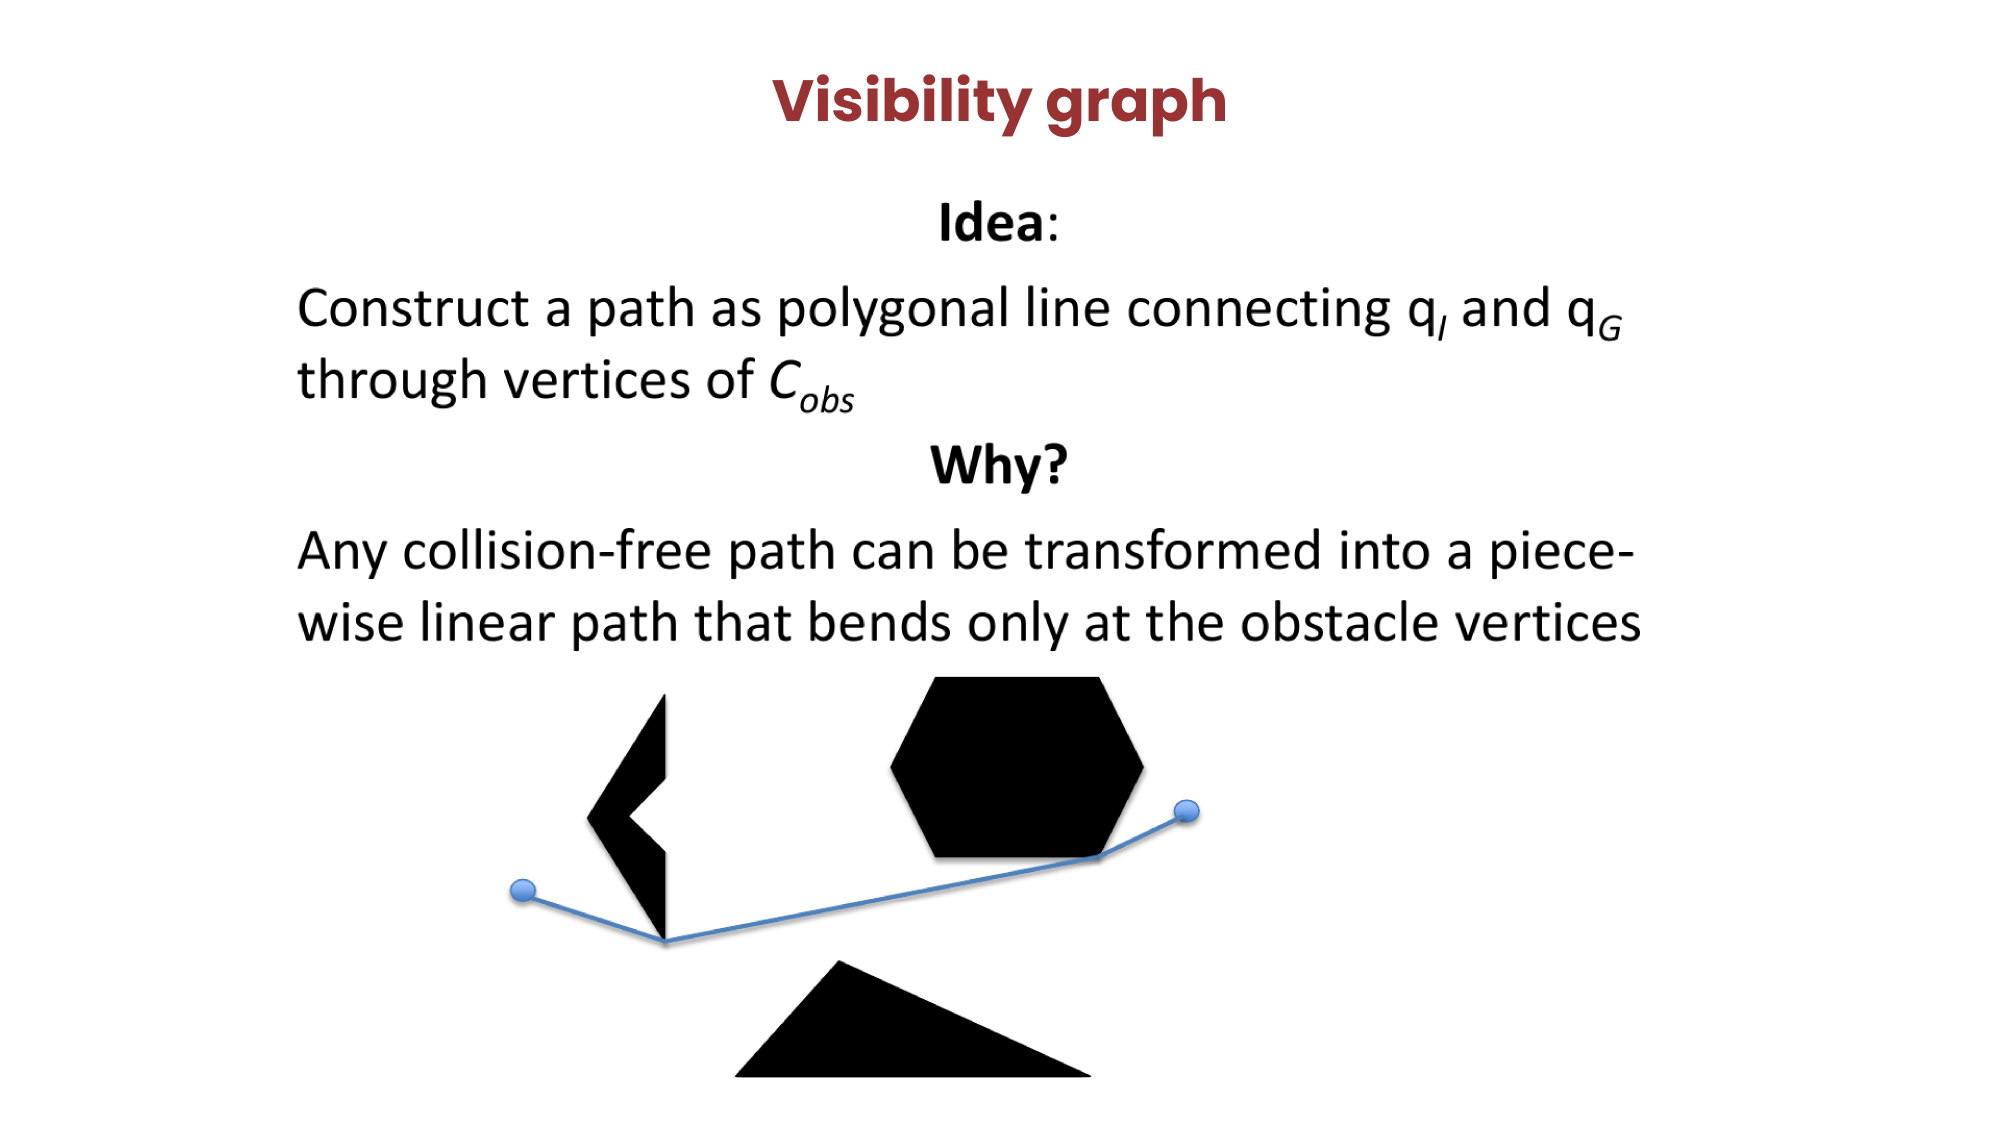
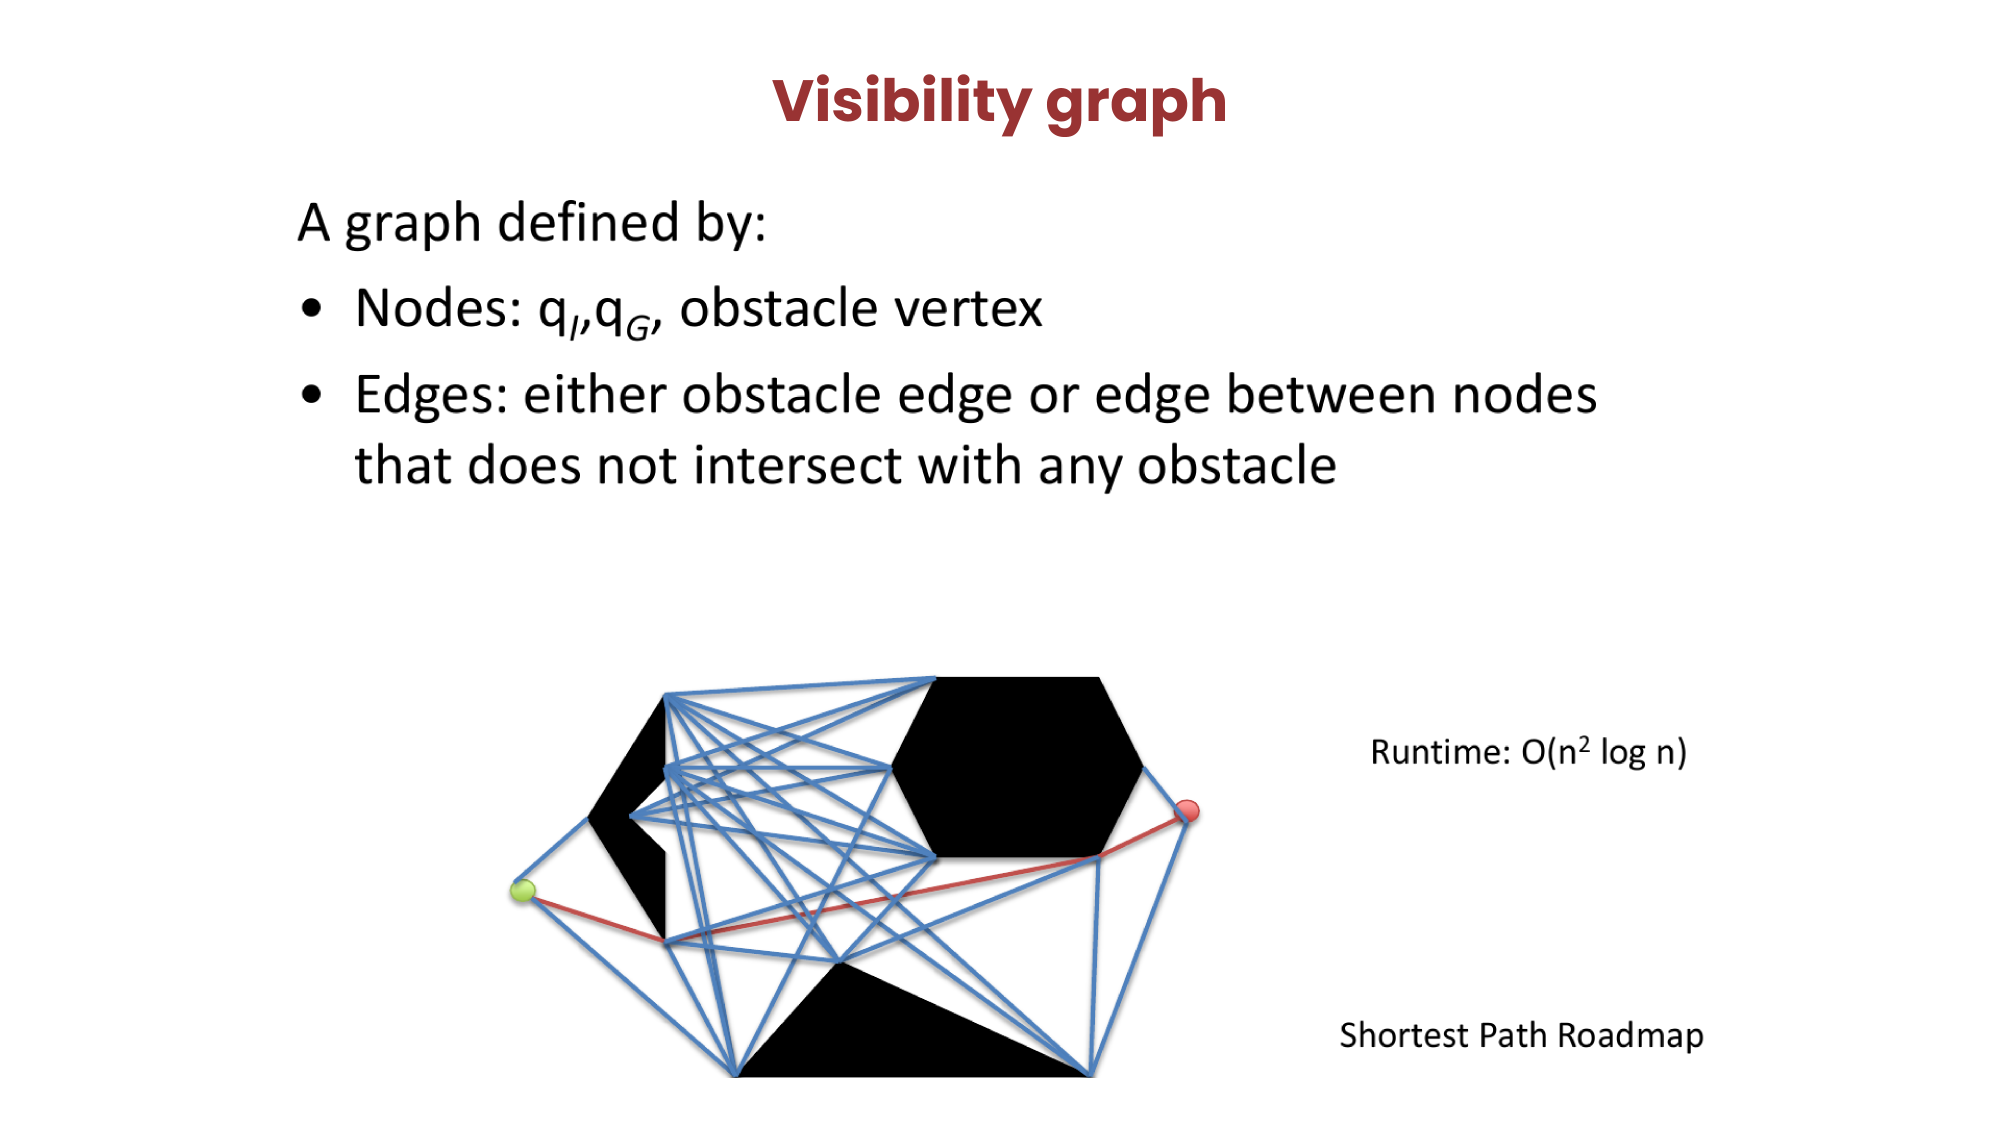
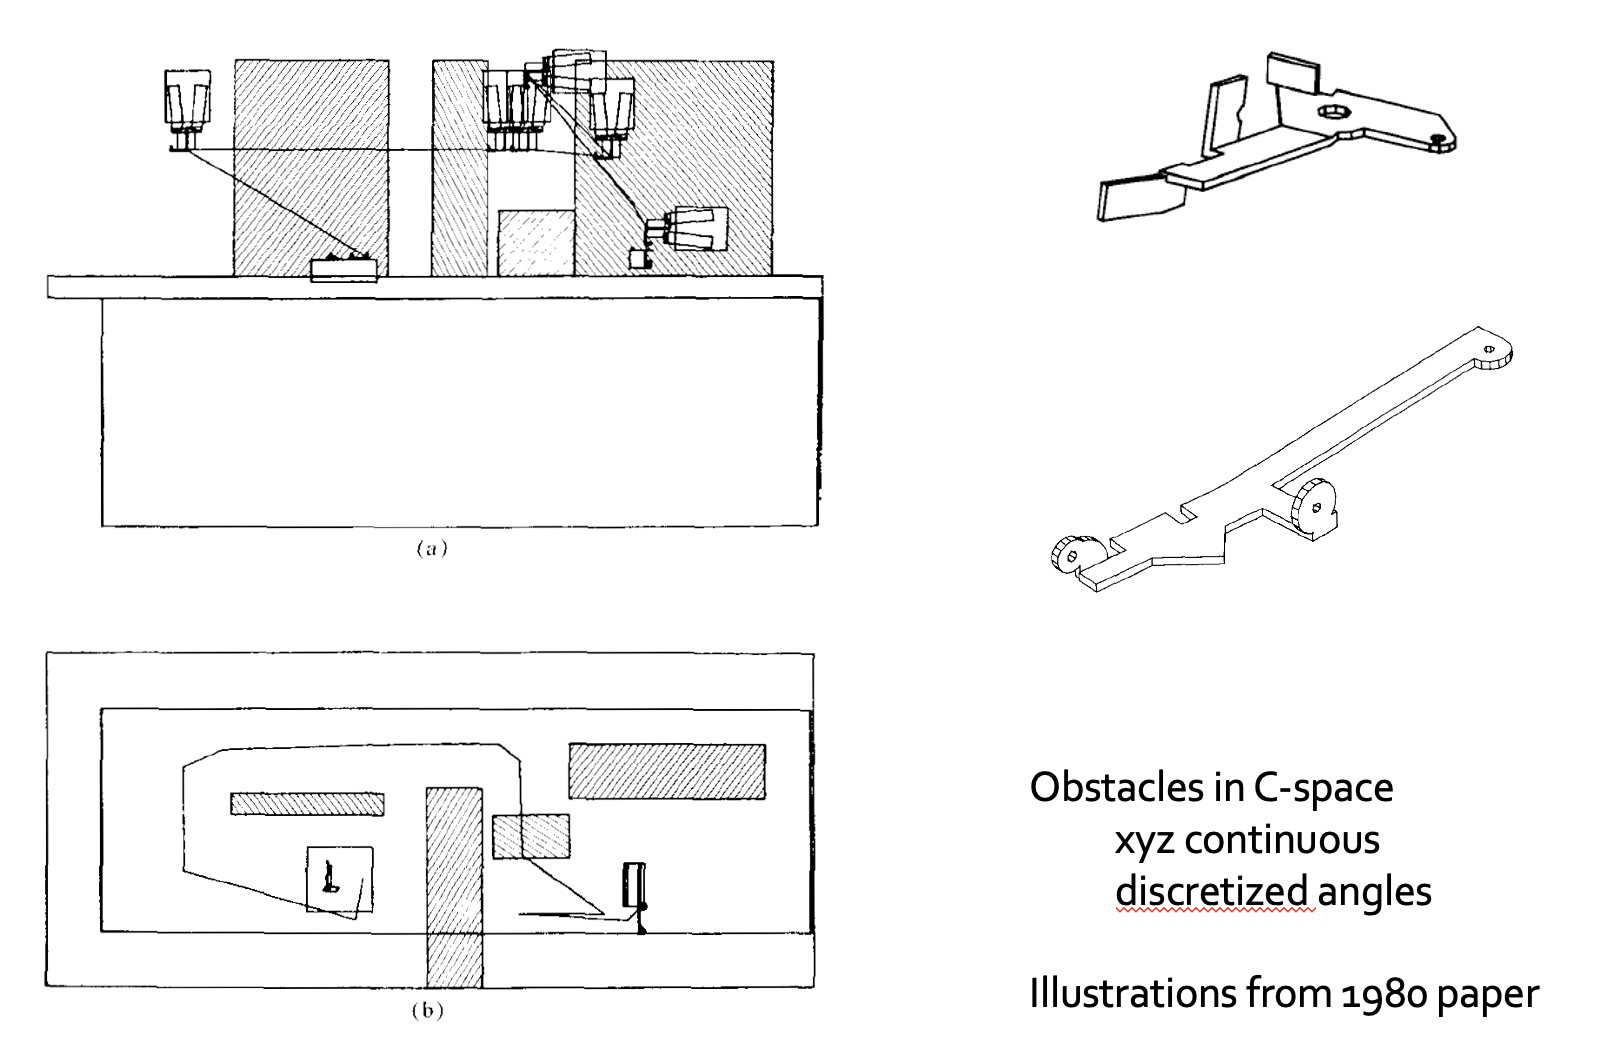
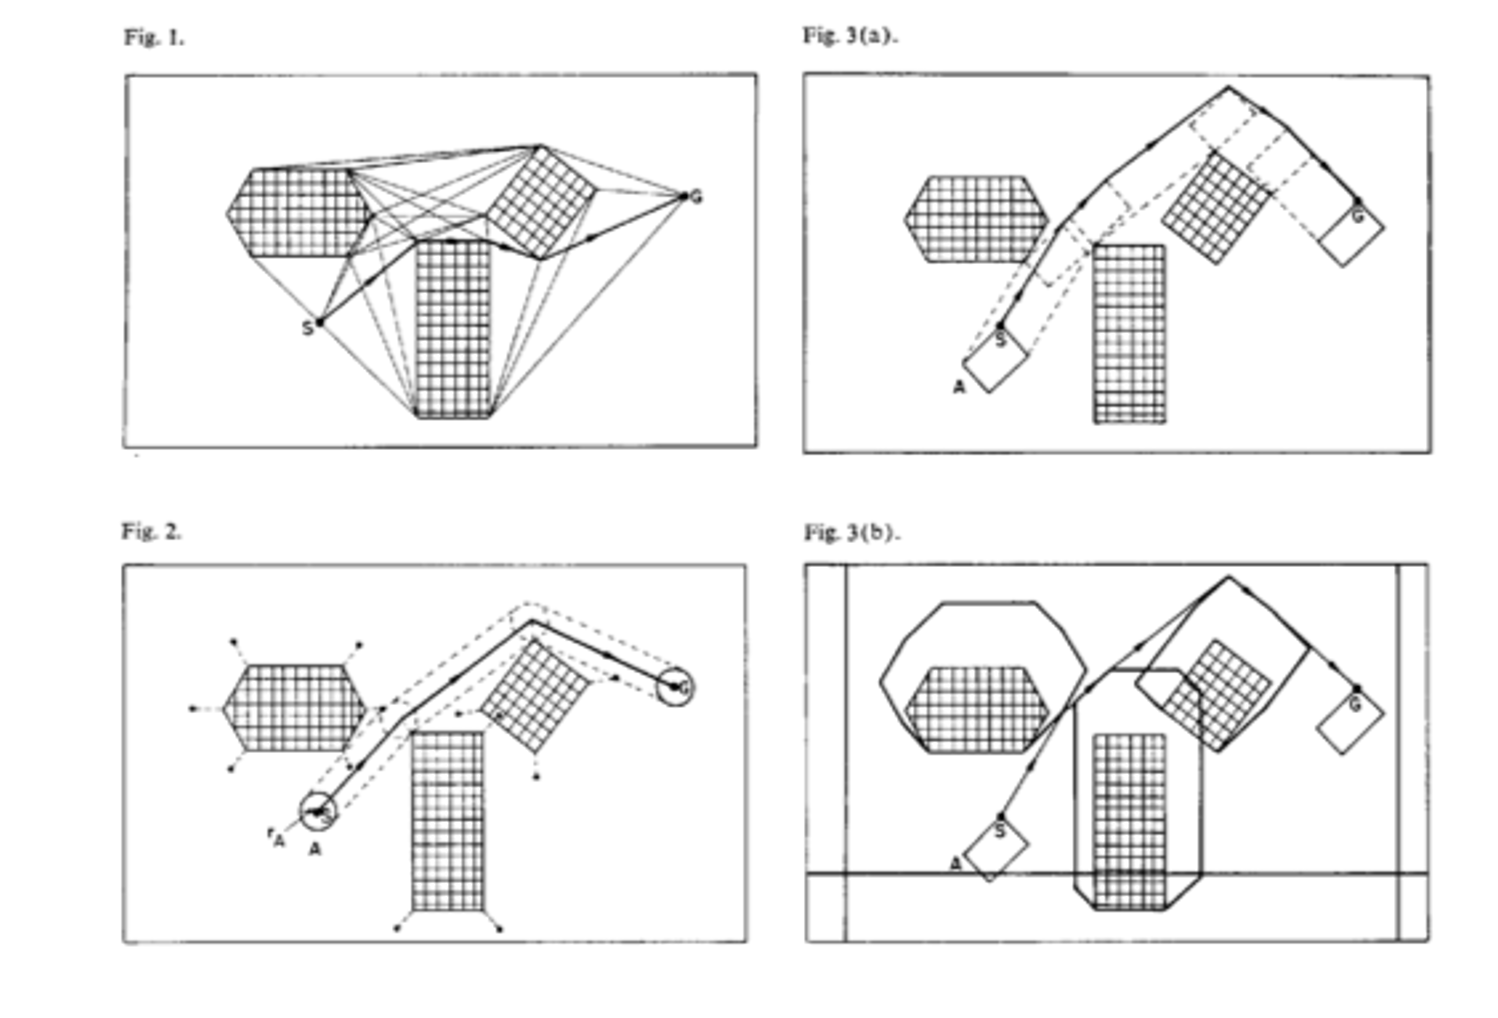
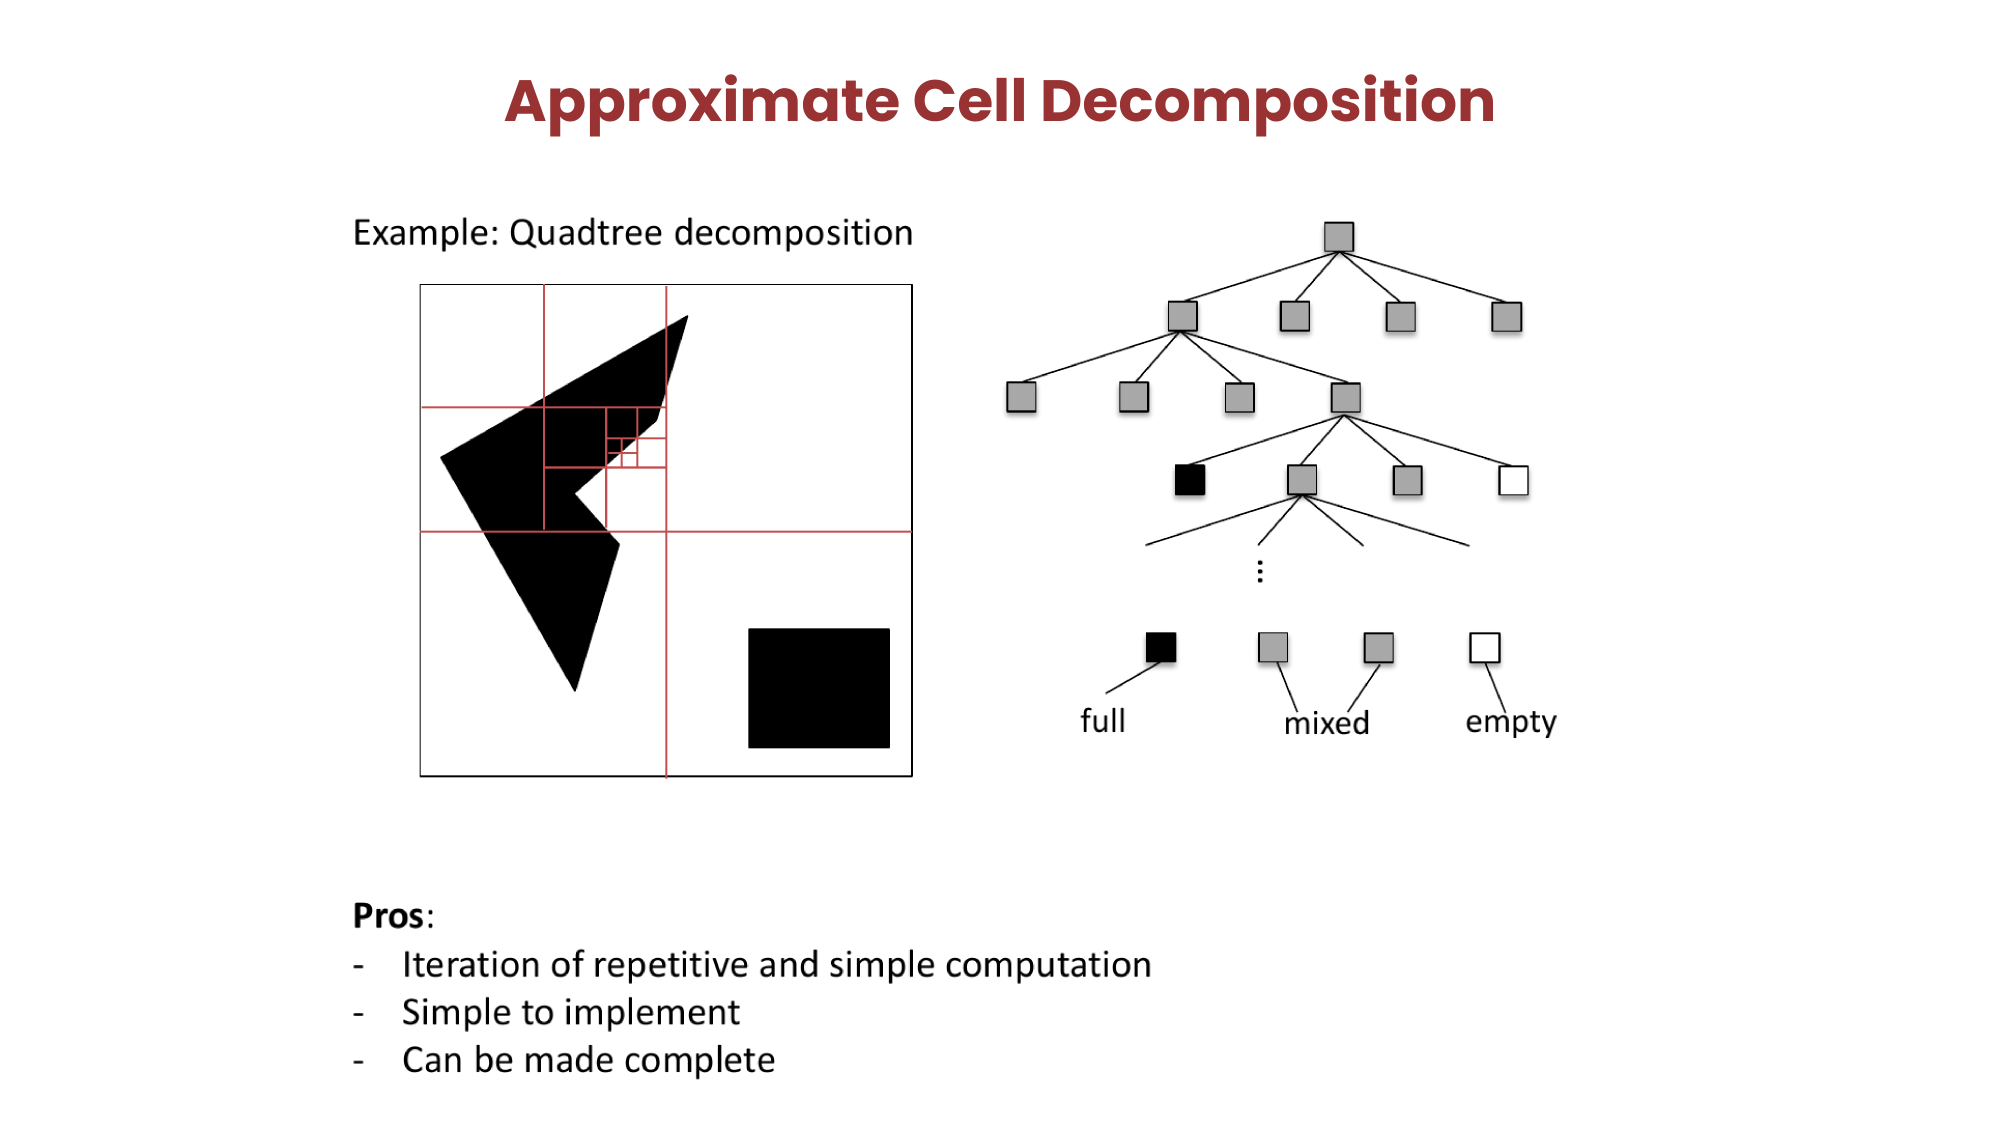
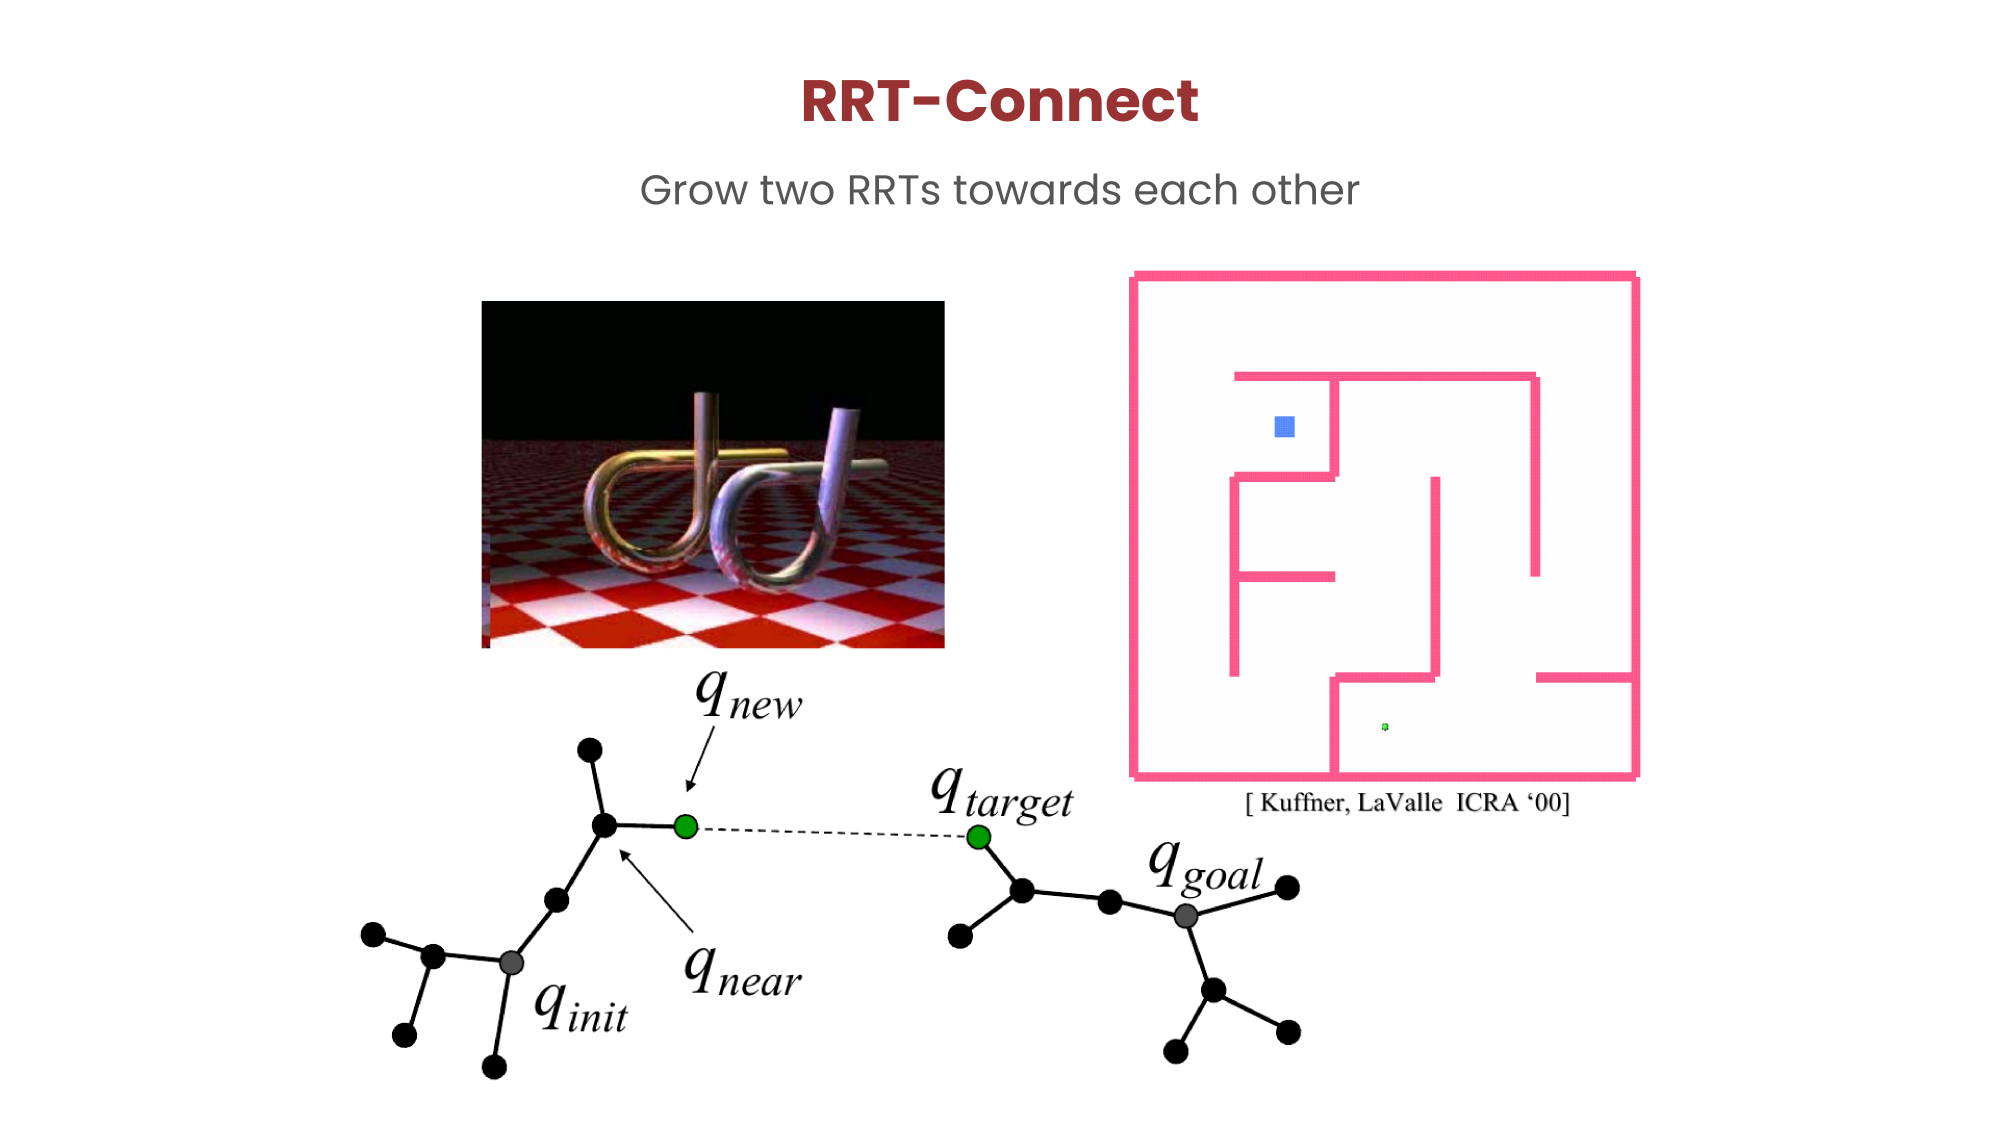
Visibility graph in Cspace (Lozano-Perez and Wesley) 1977-99
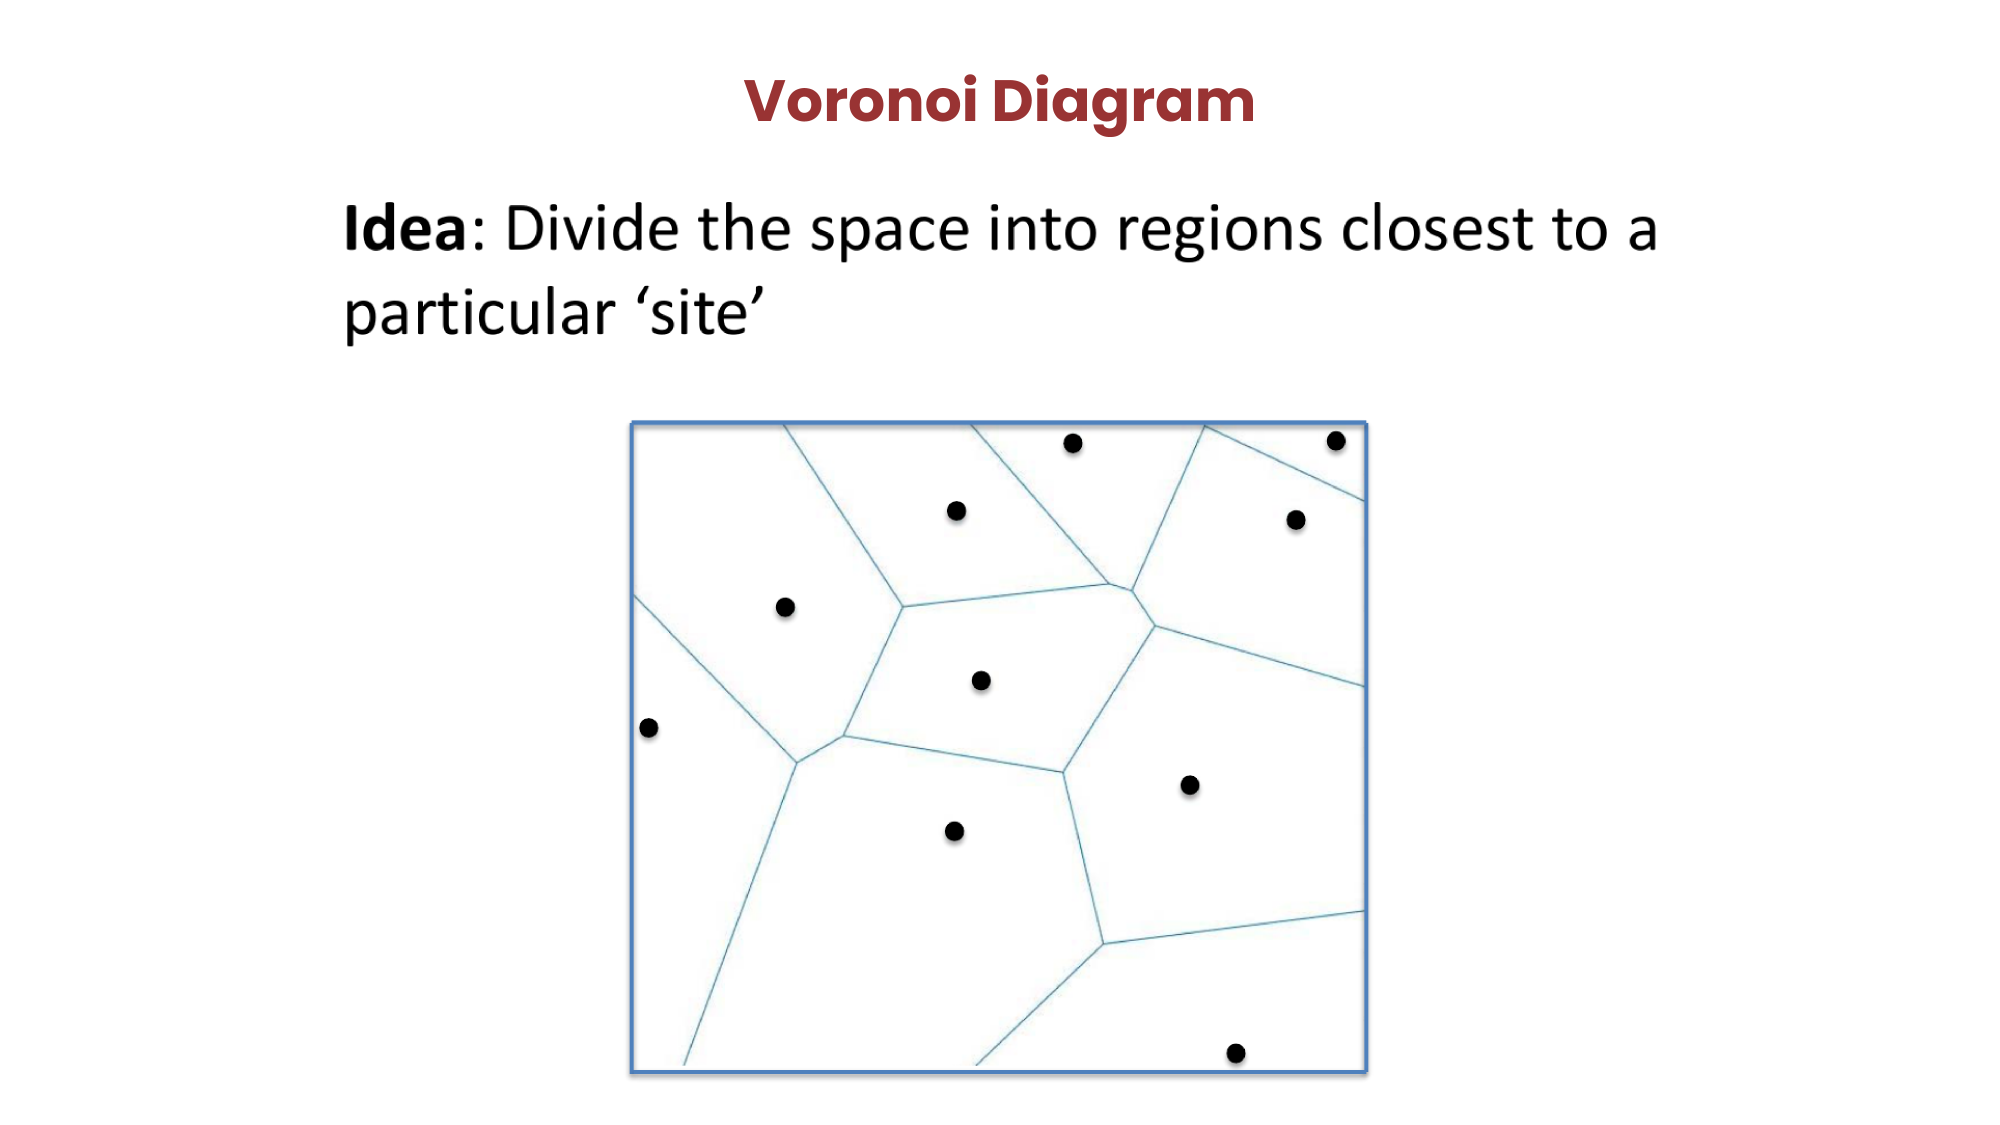
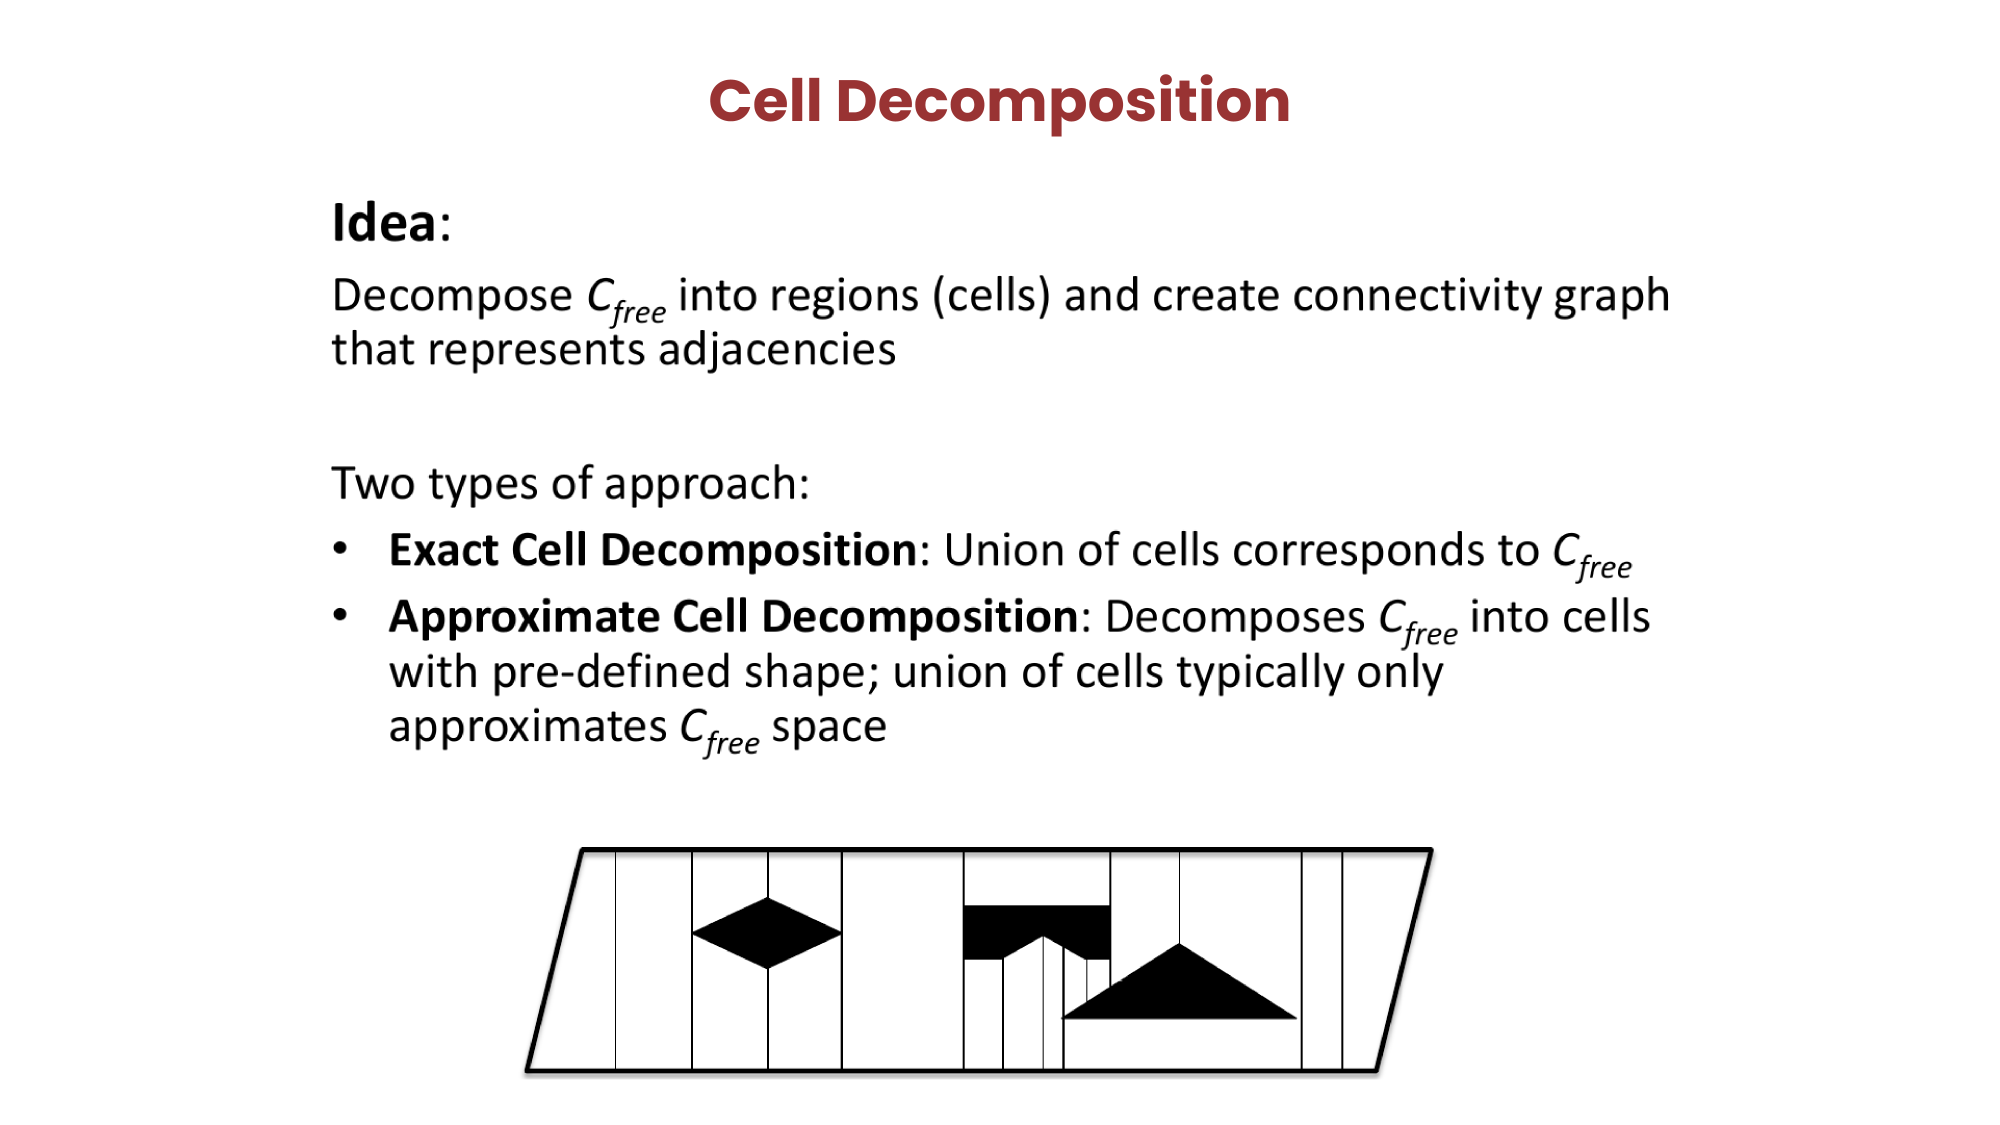
Handey (Lozano-Perez, et al) 1987-89
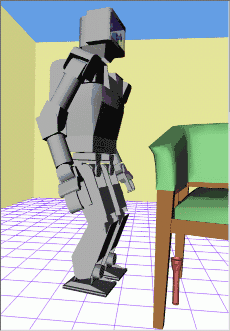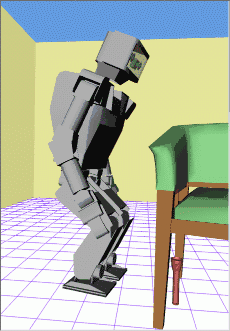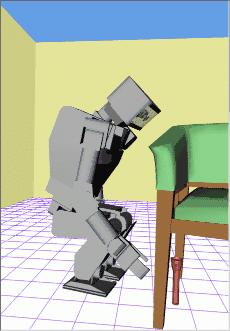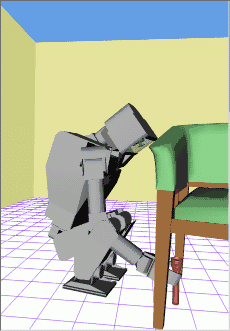
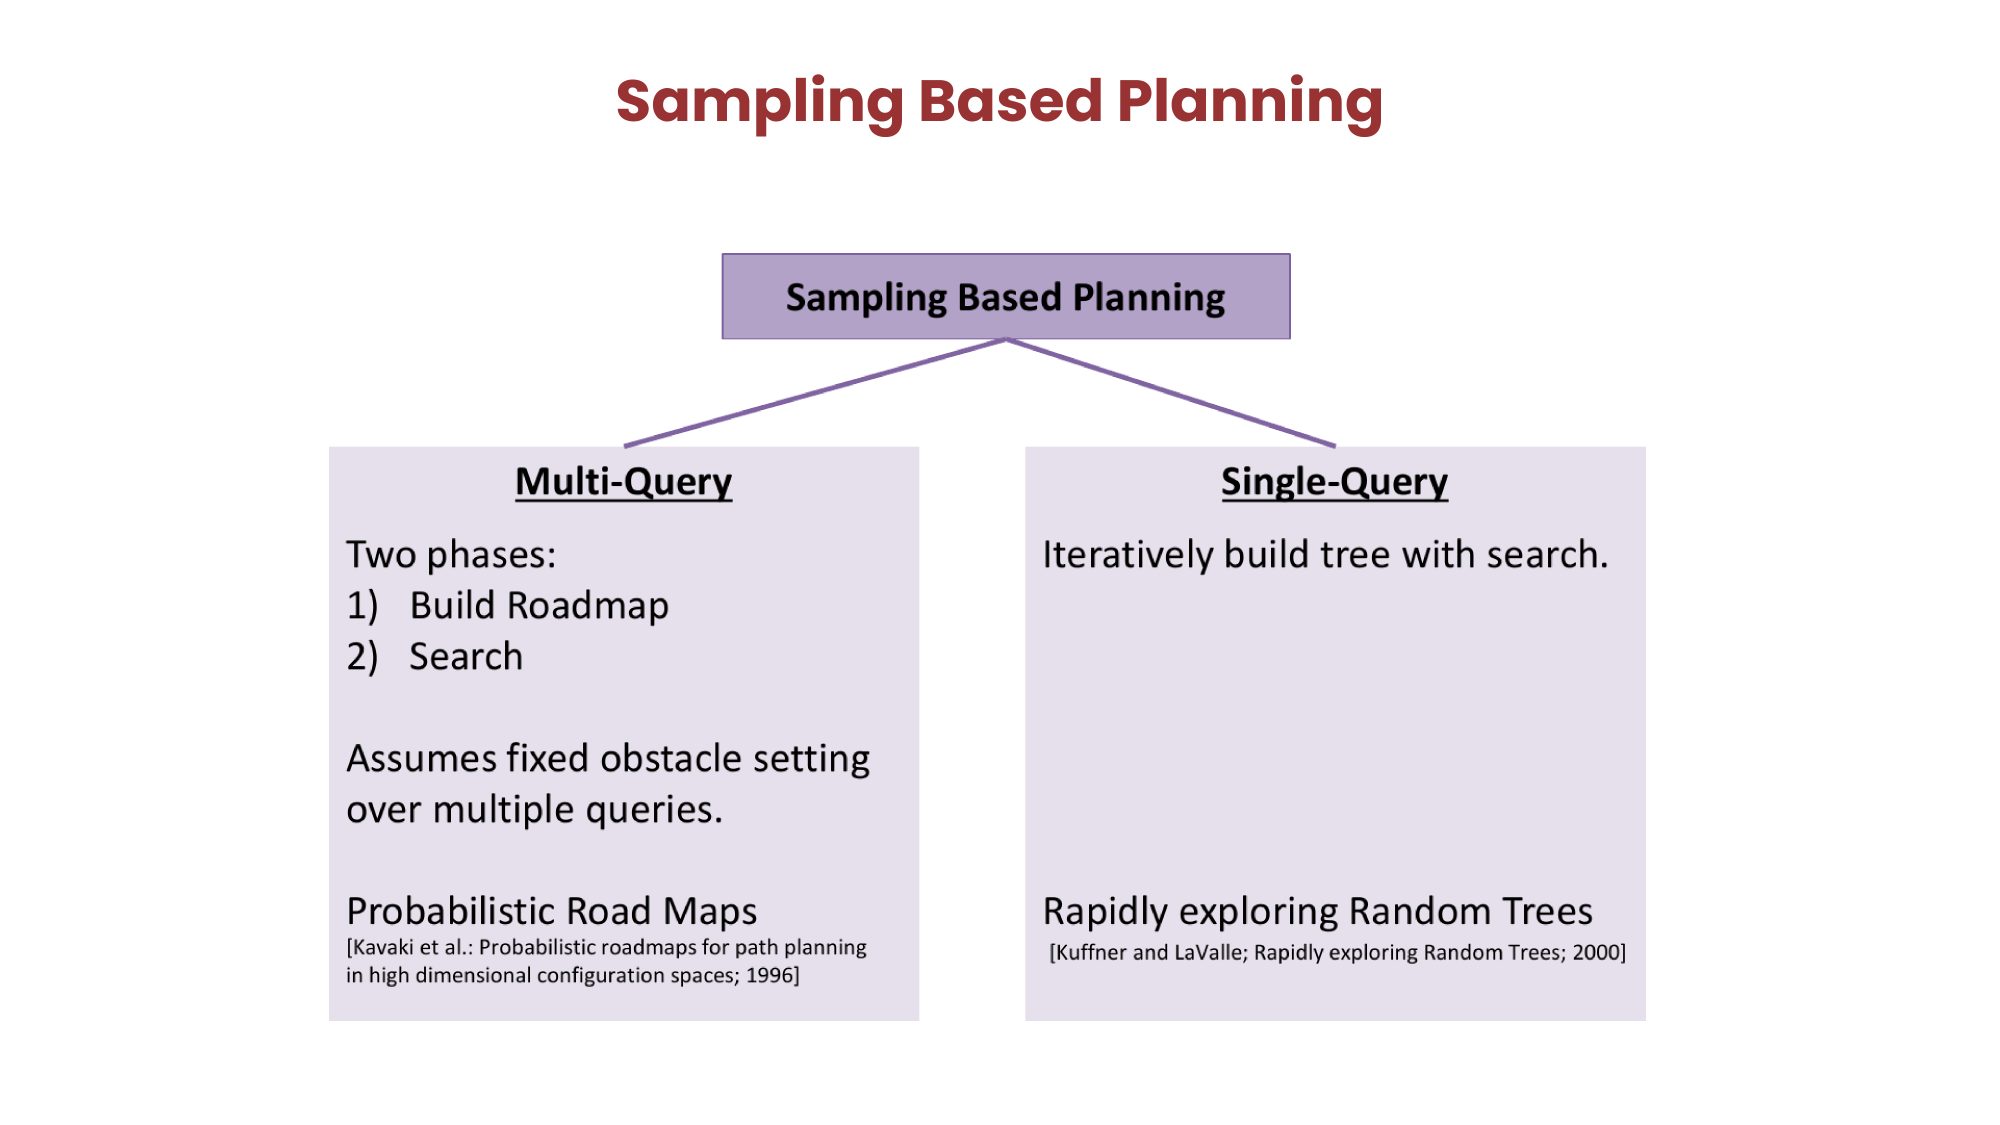
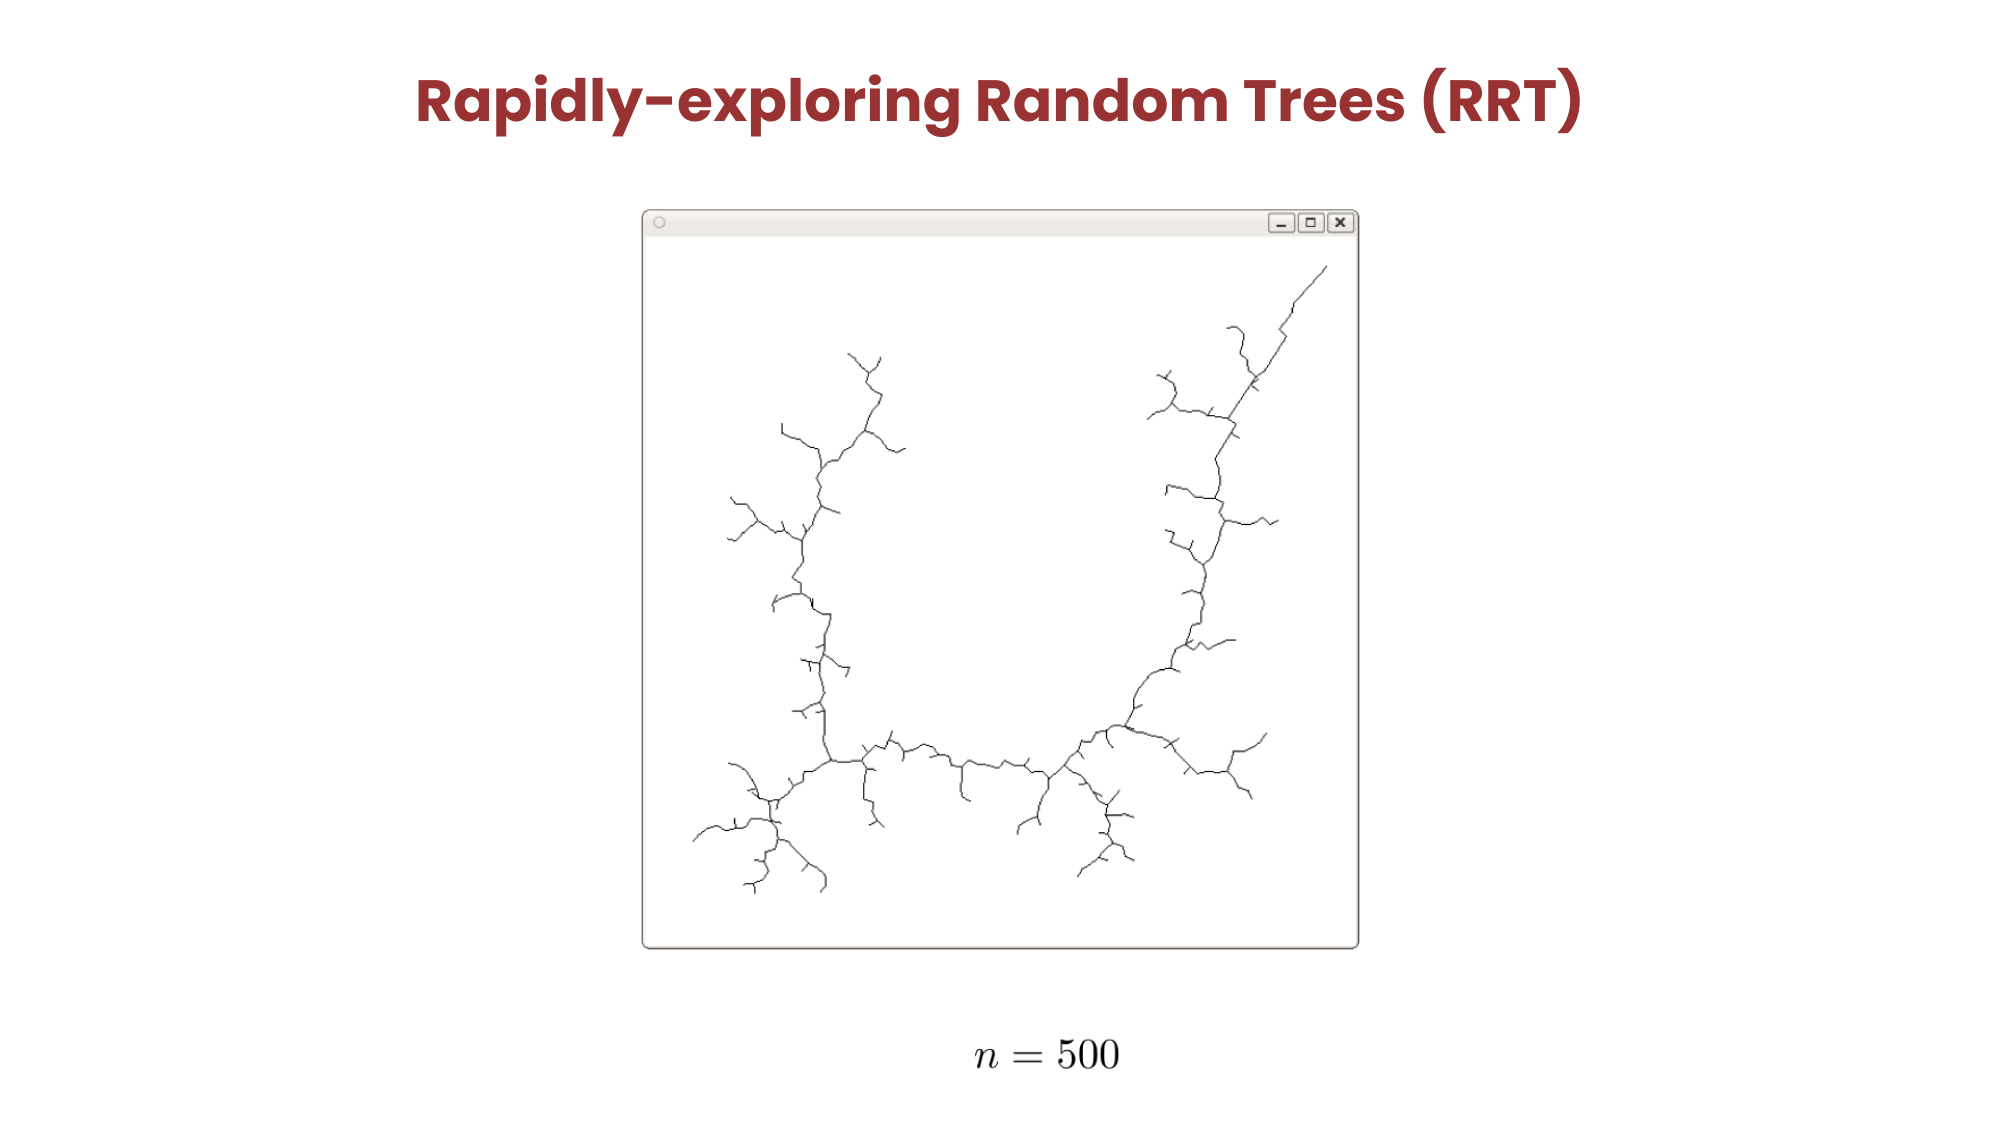
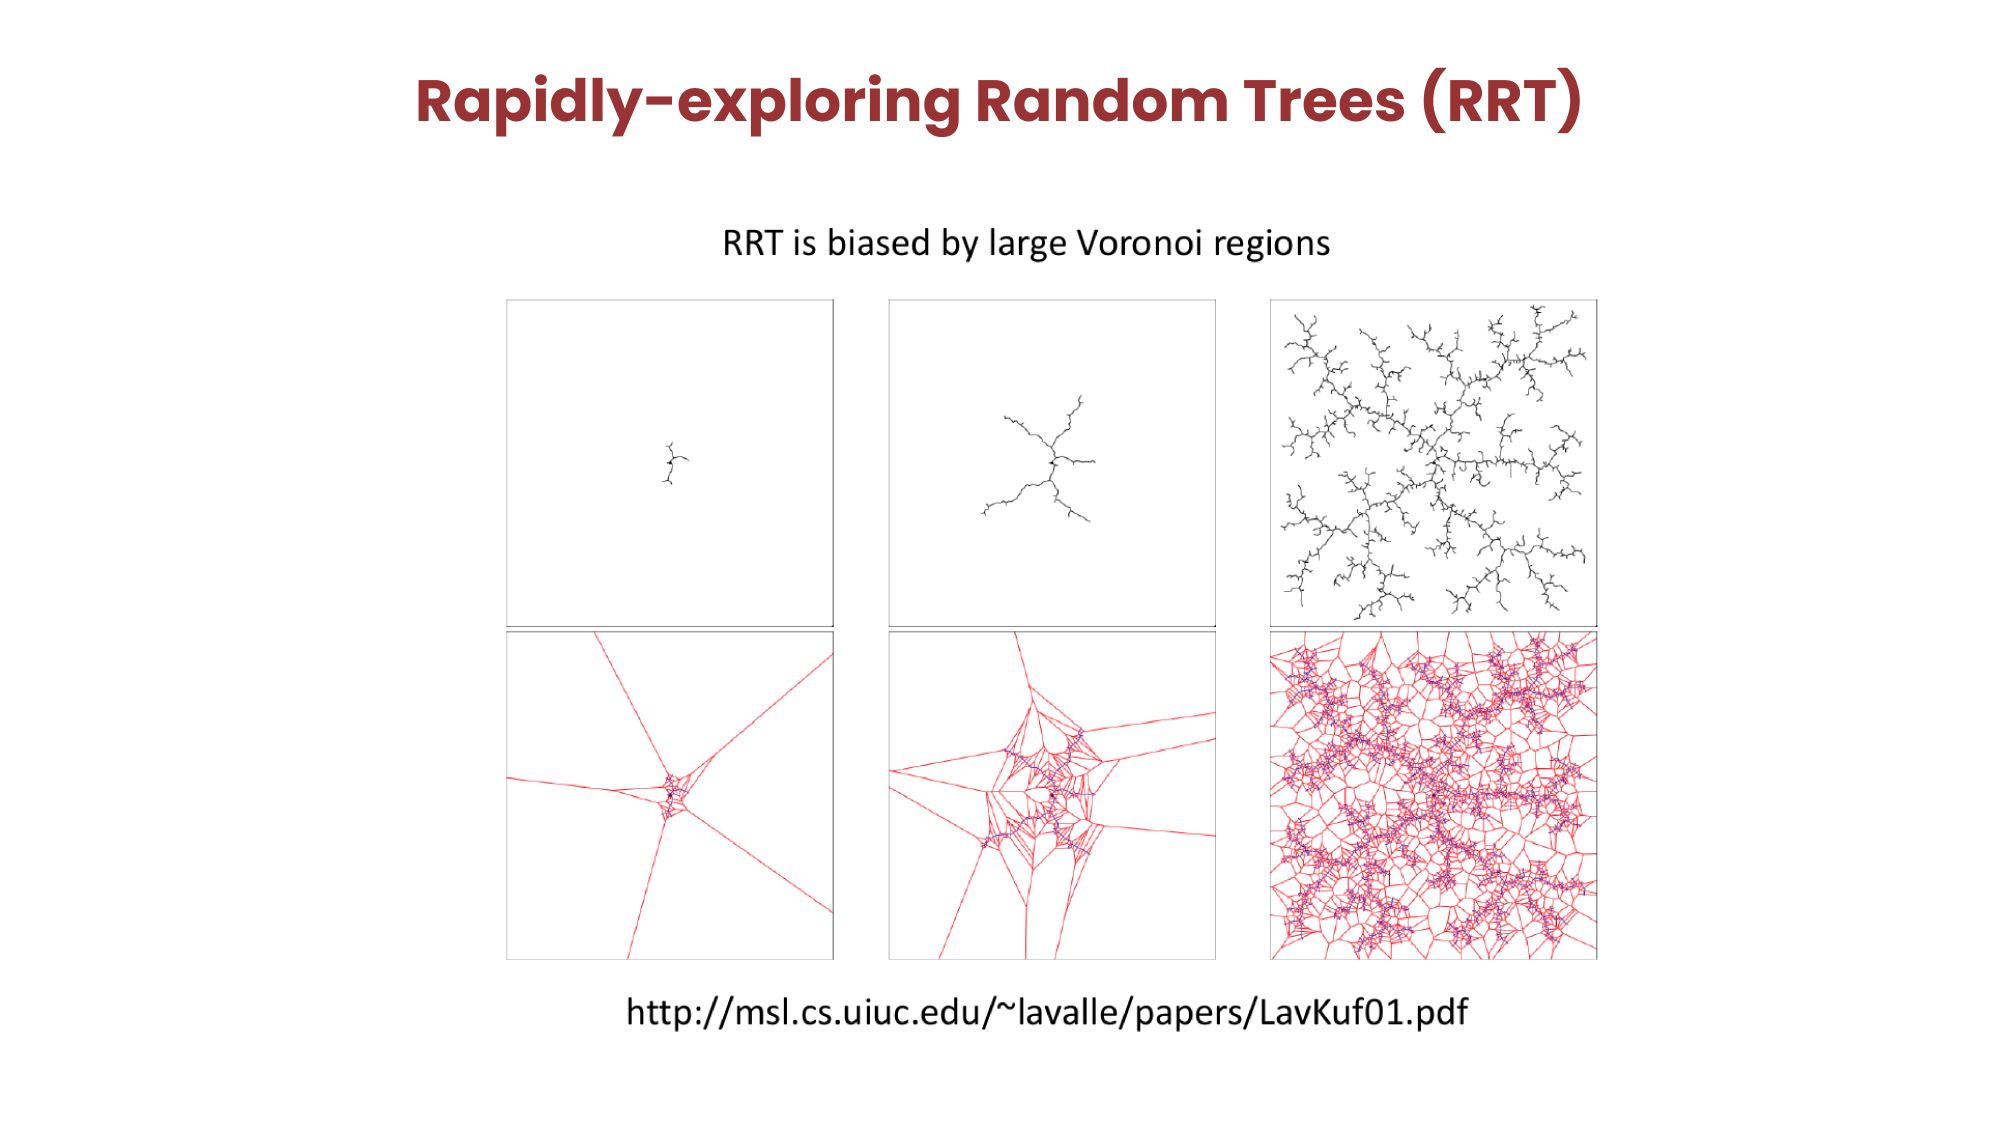
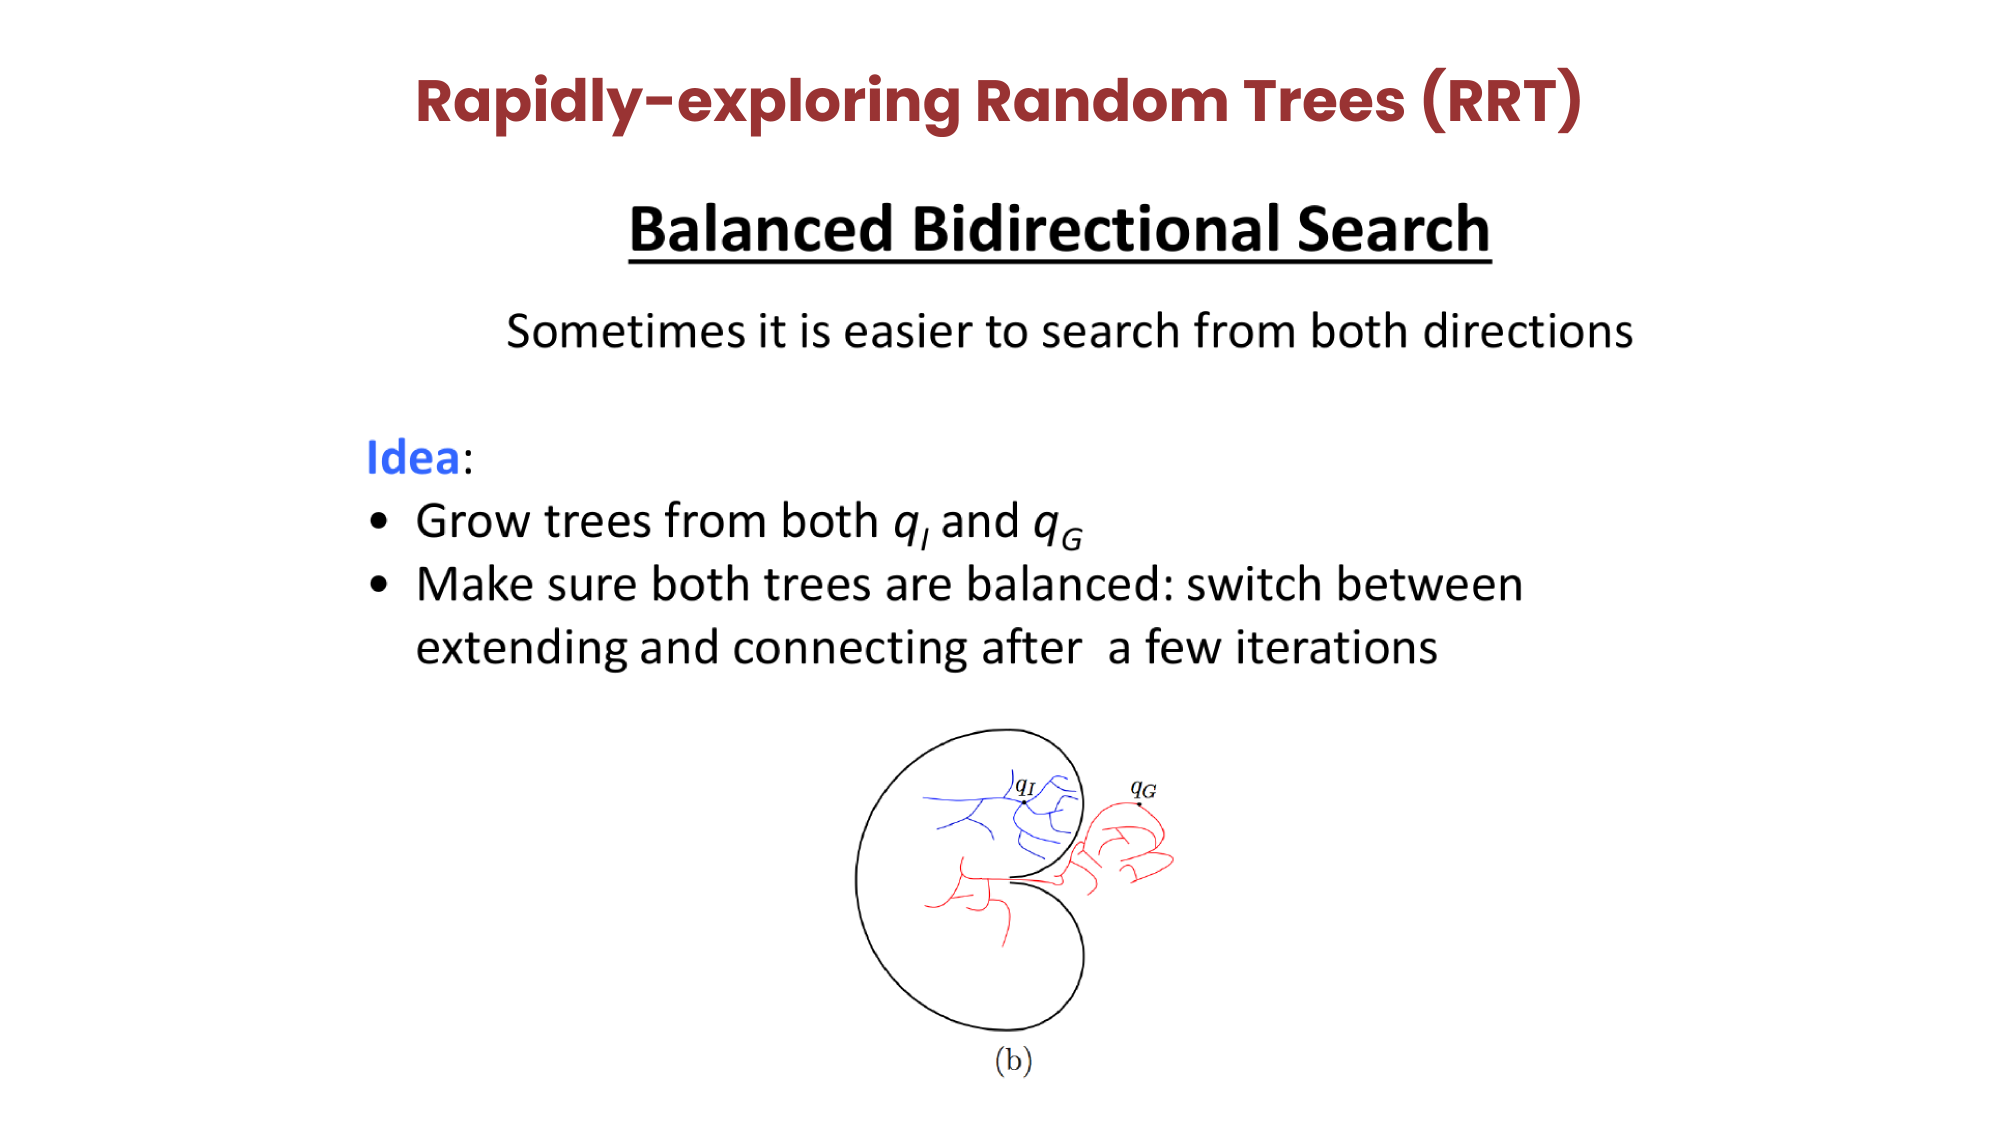
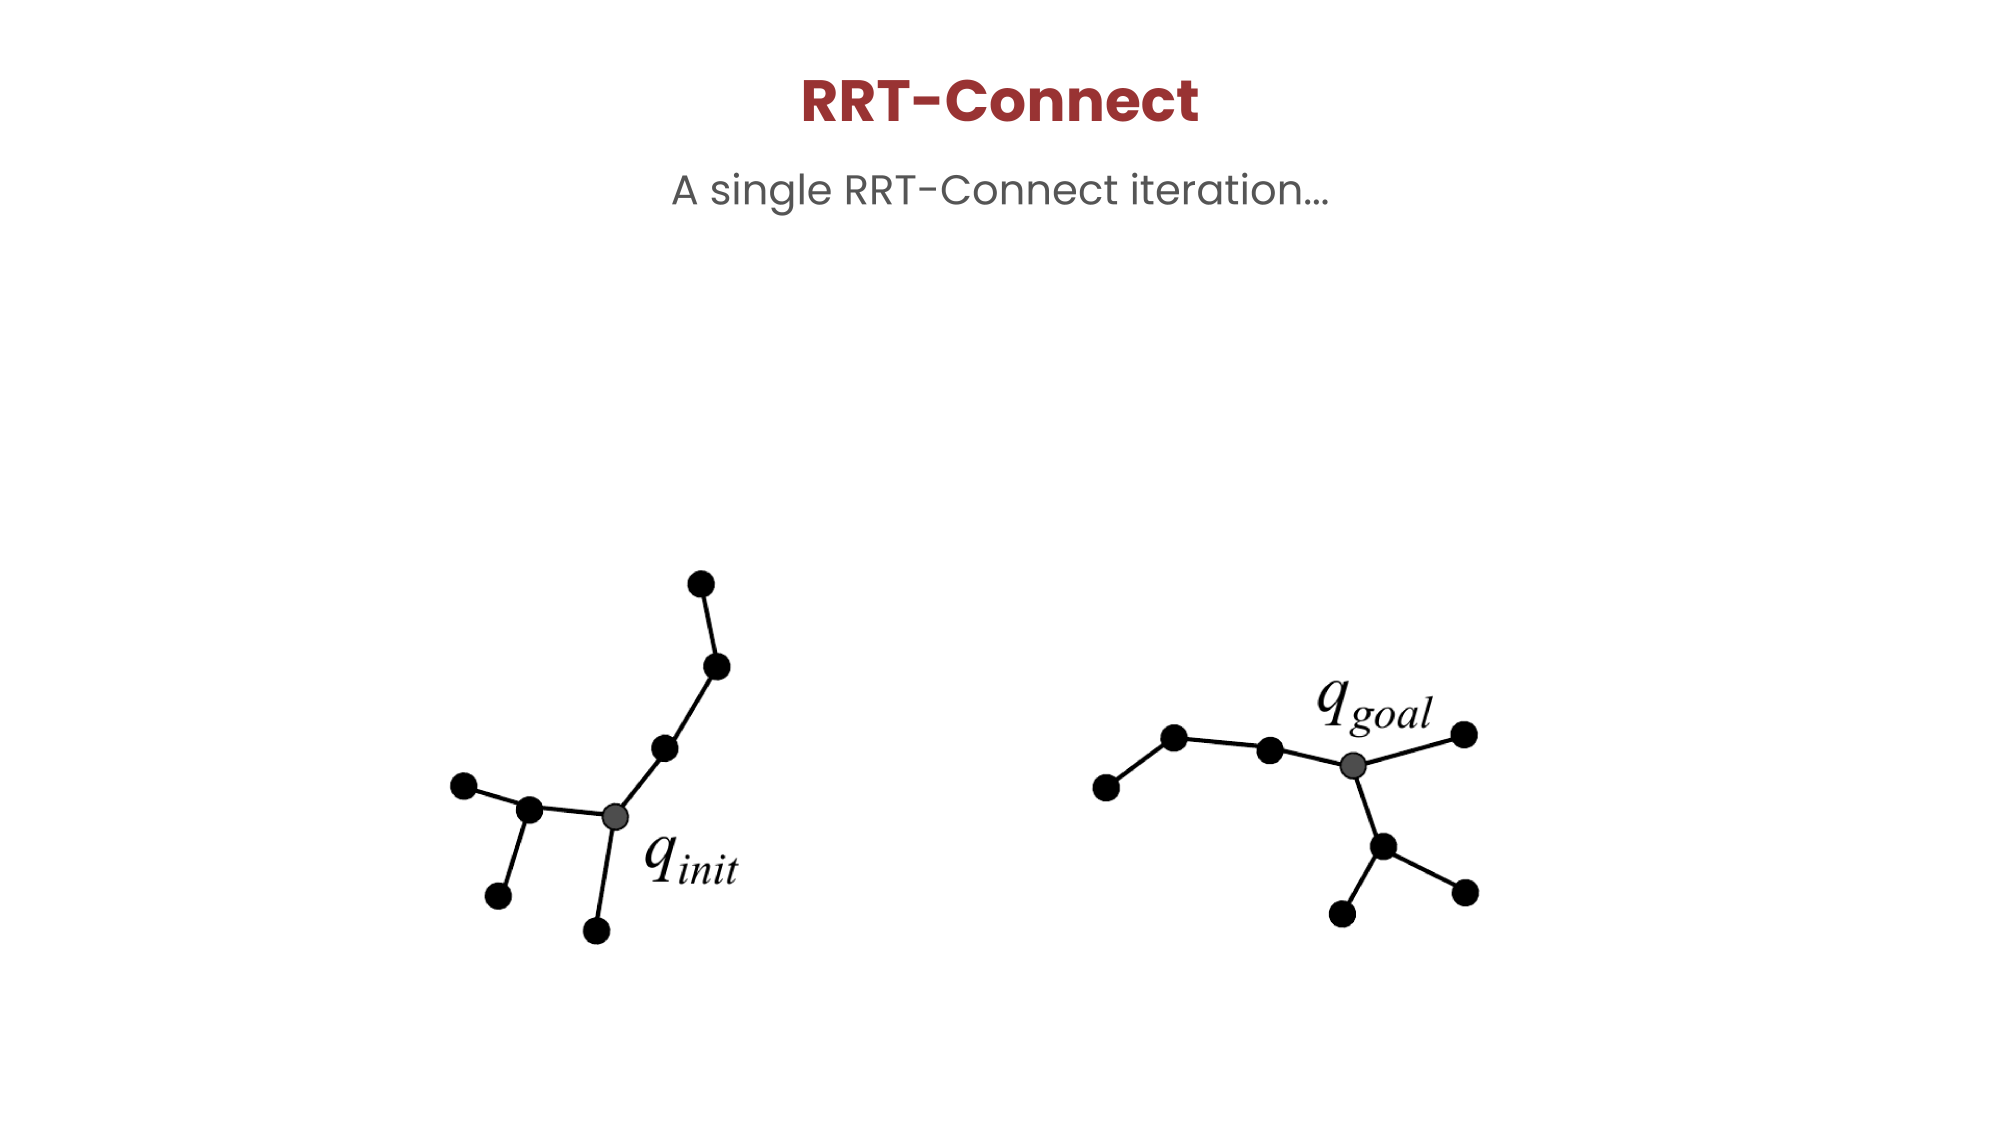
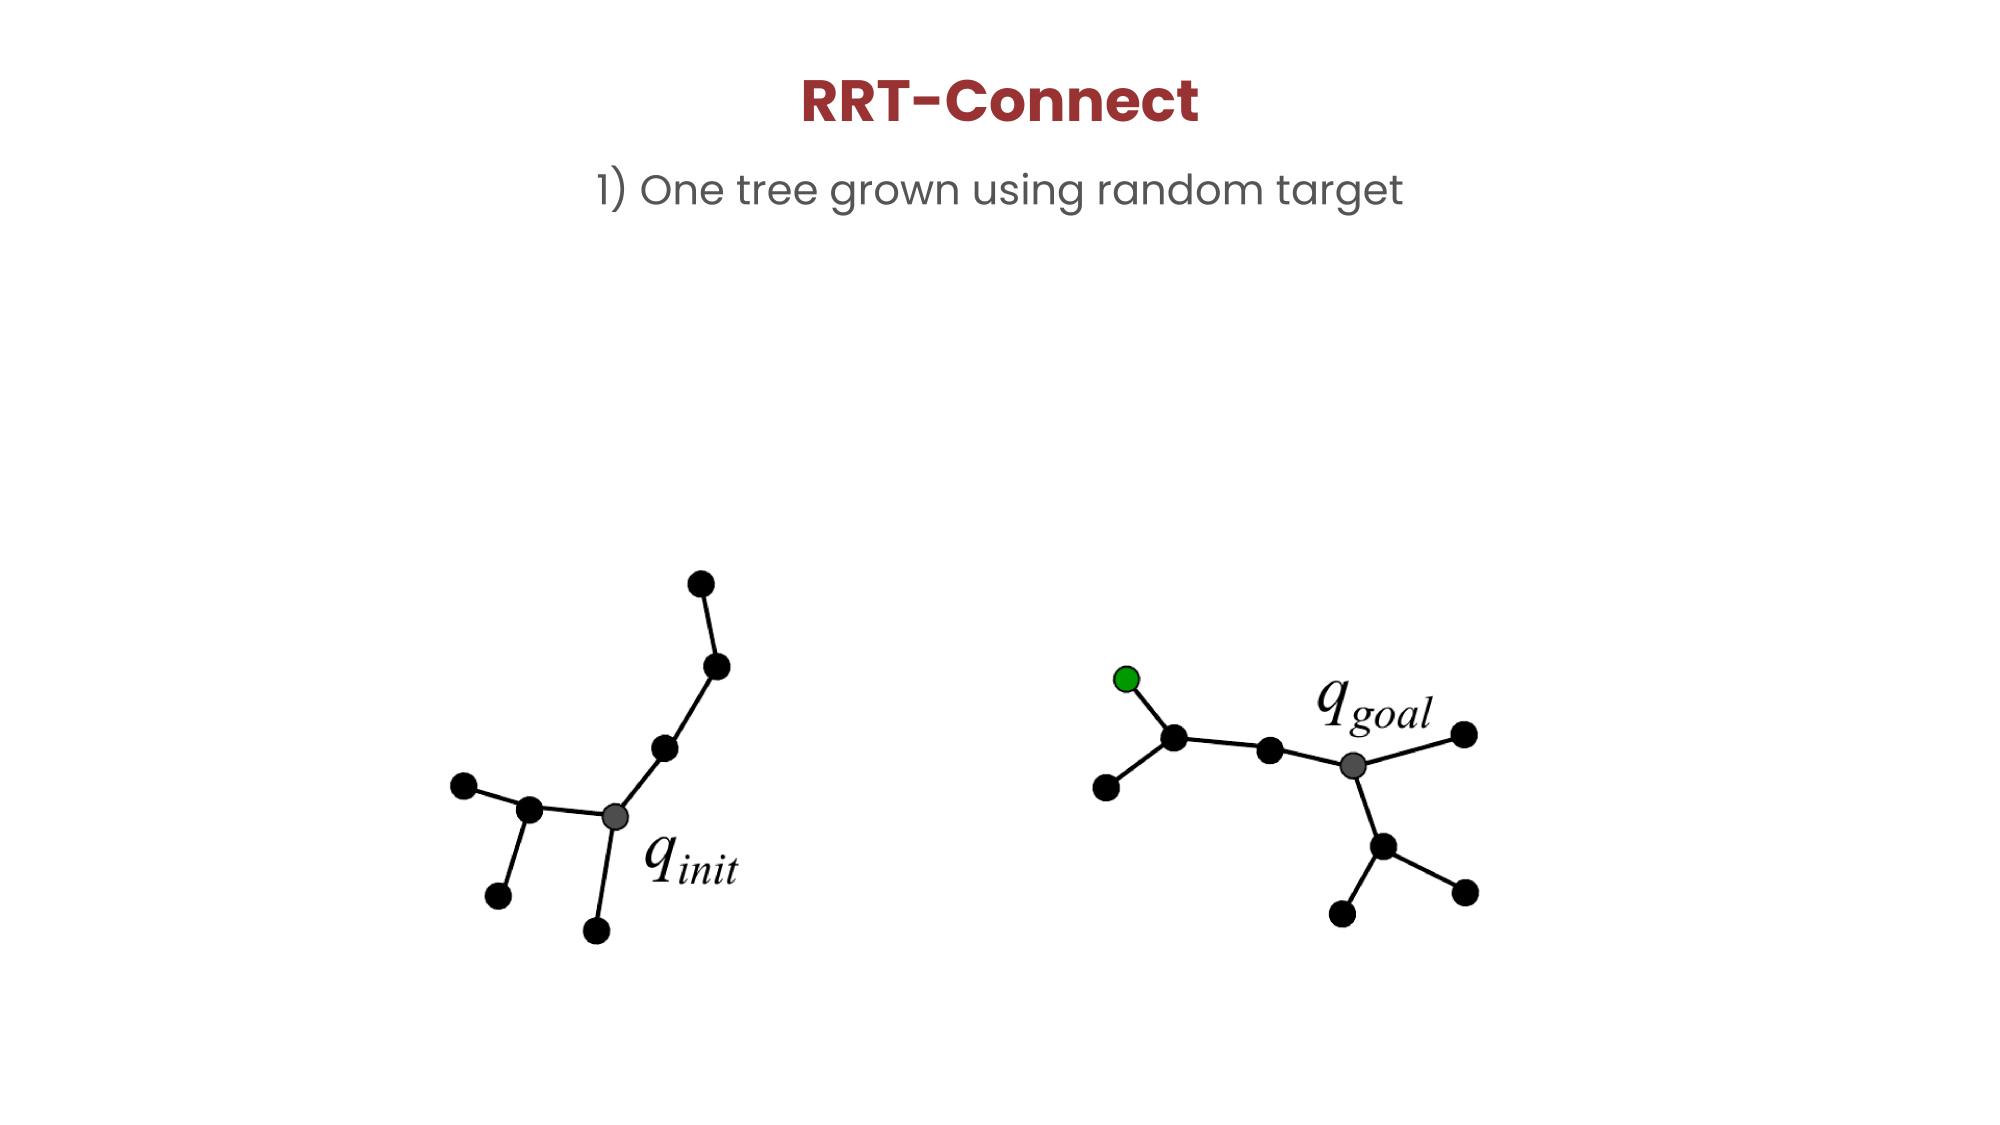
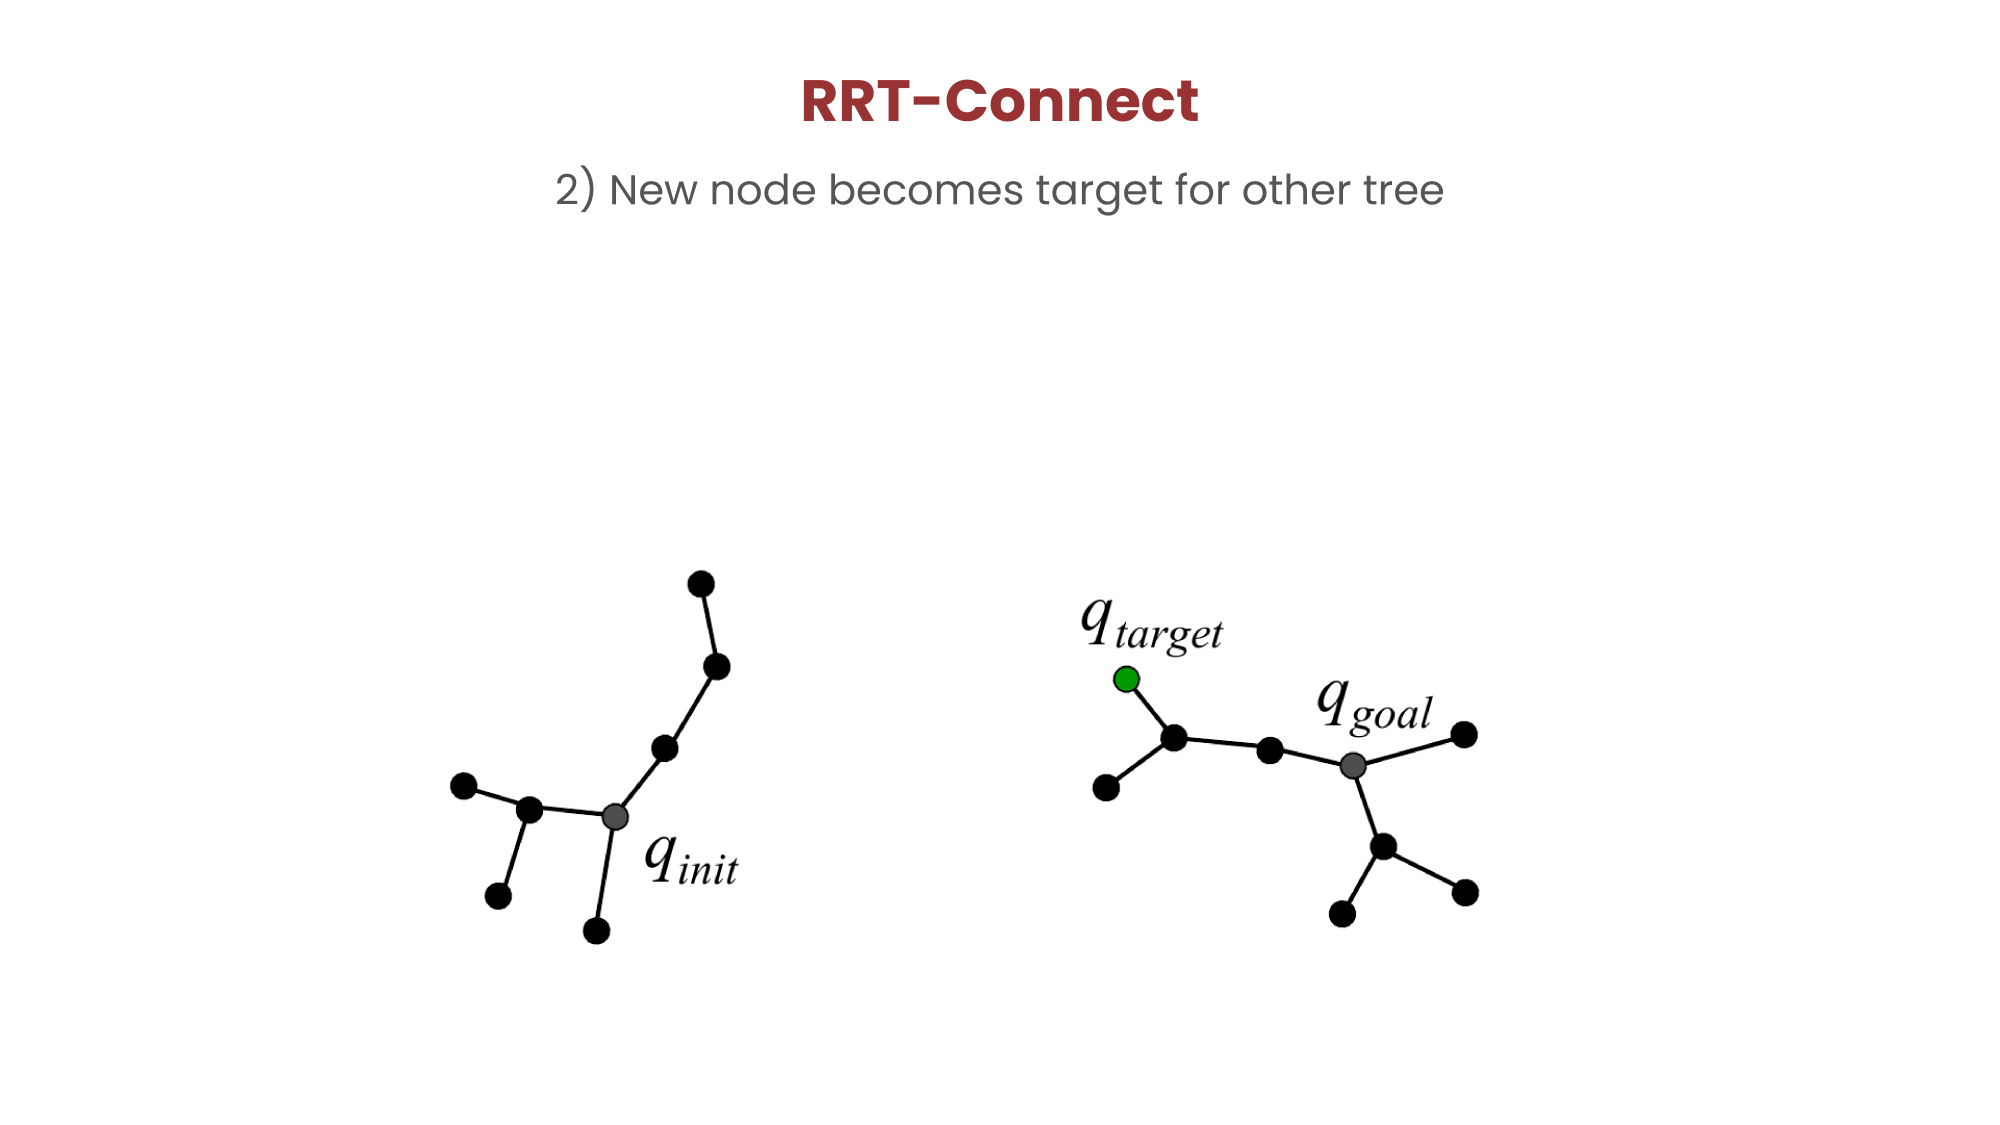
Sample-based (Barraquand, Kavraki, Latombe, LaValle, et al) 1990-2000
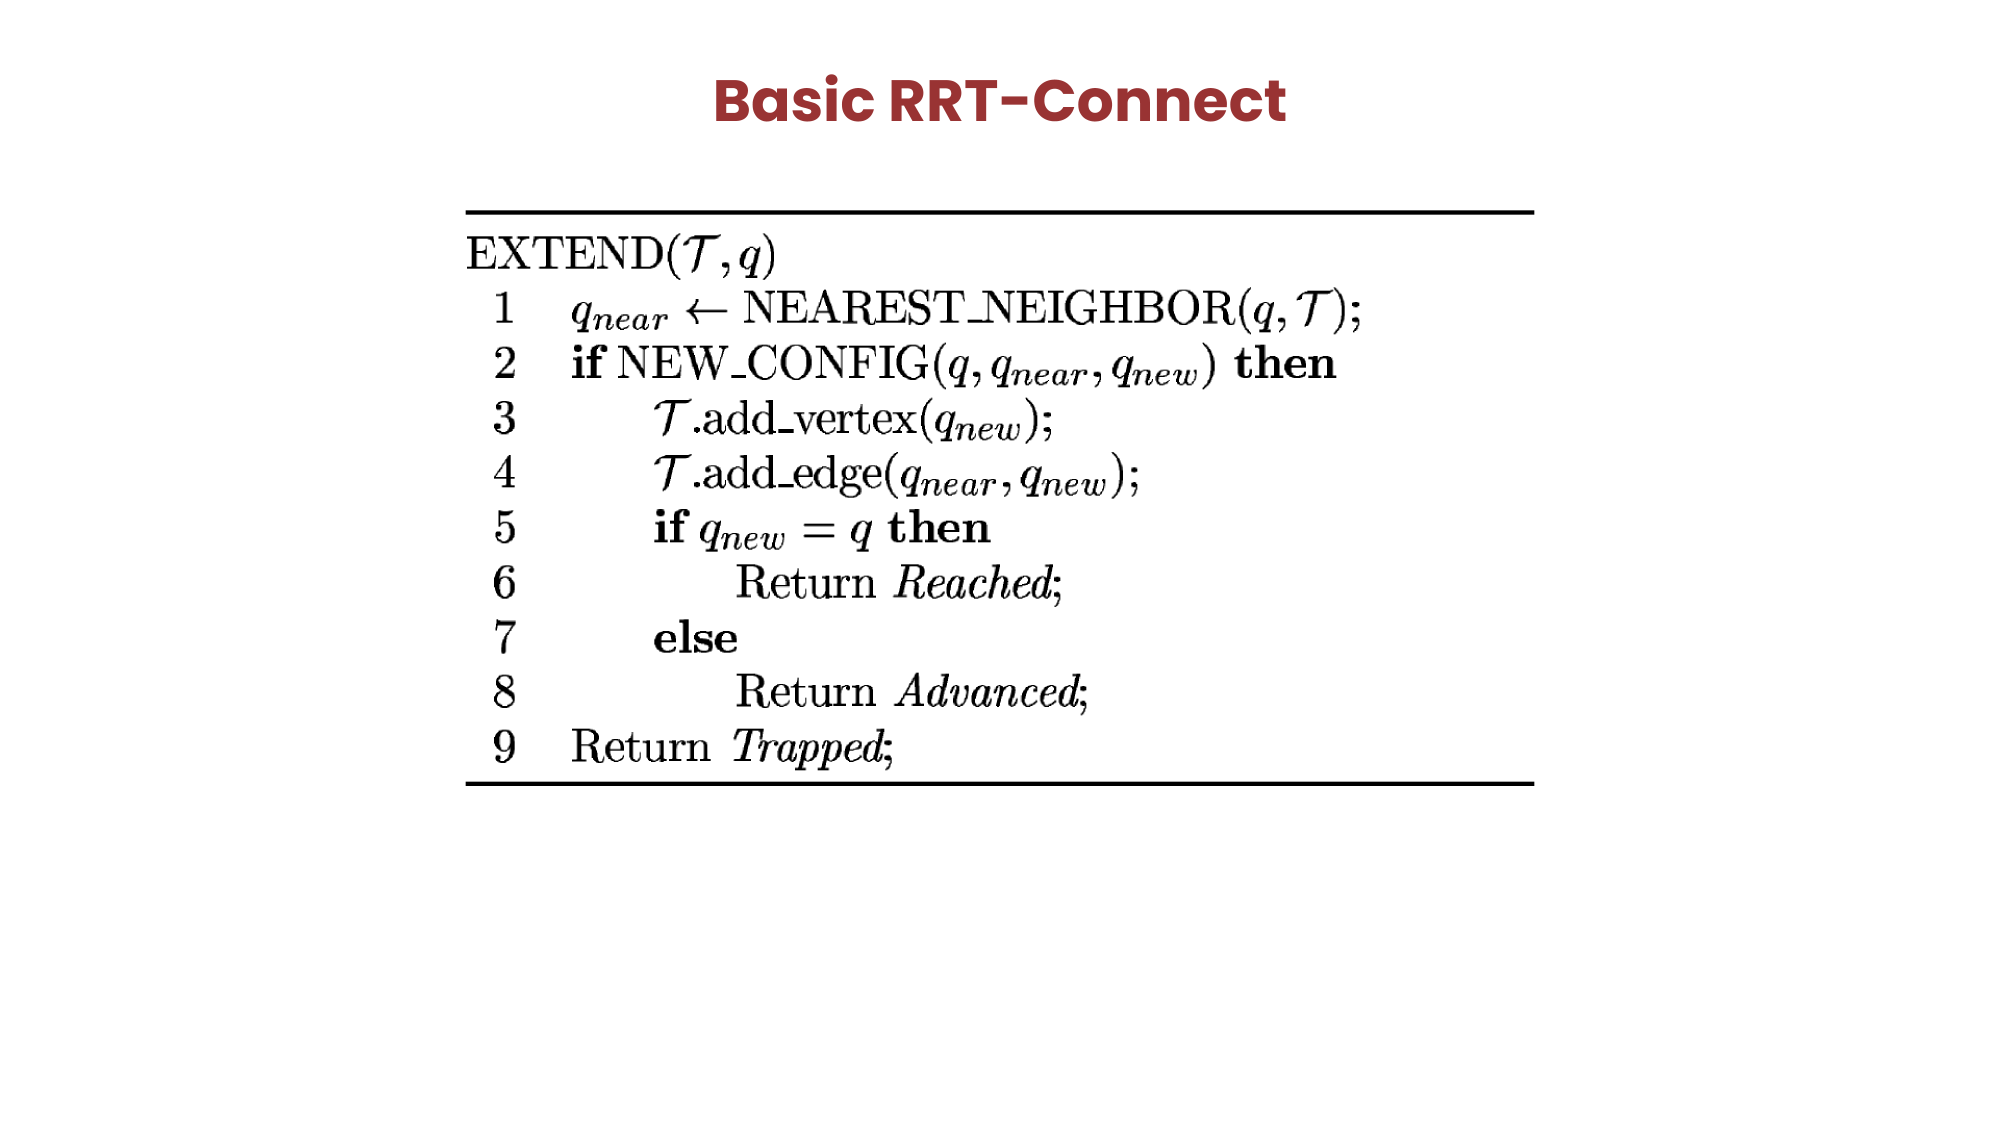
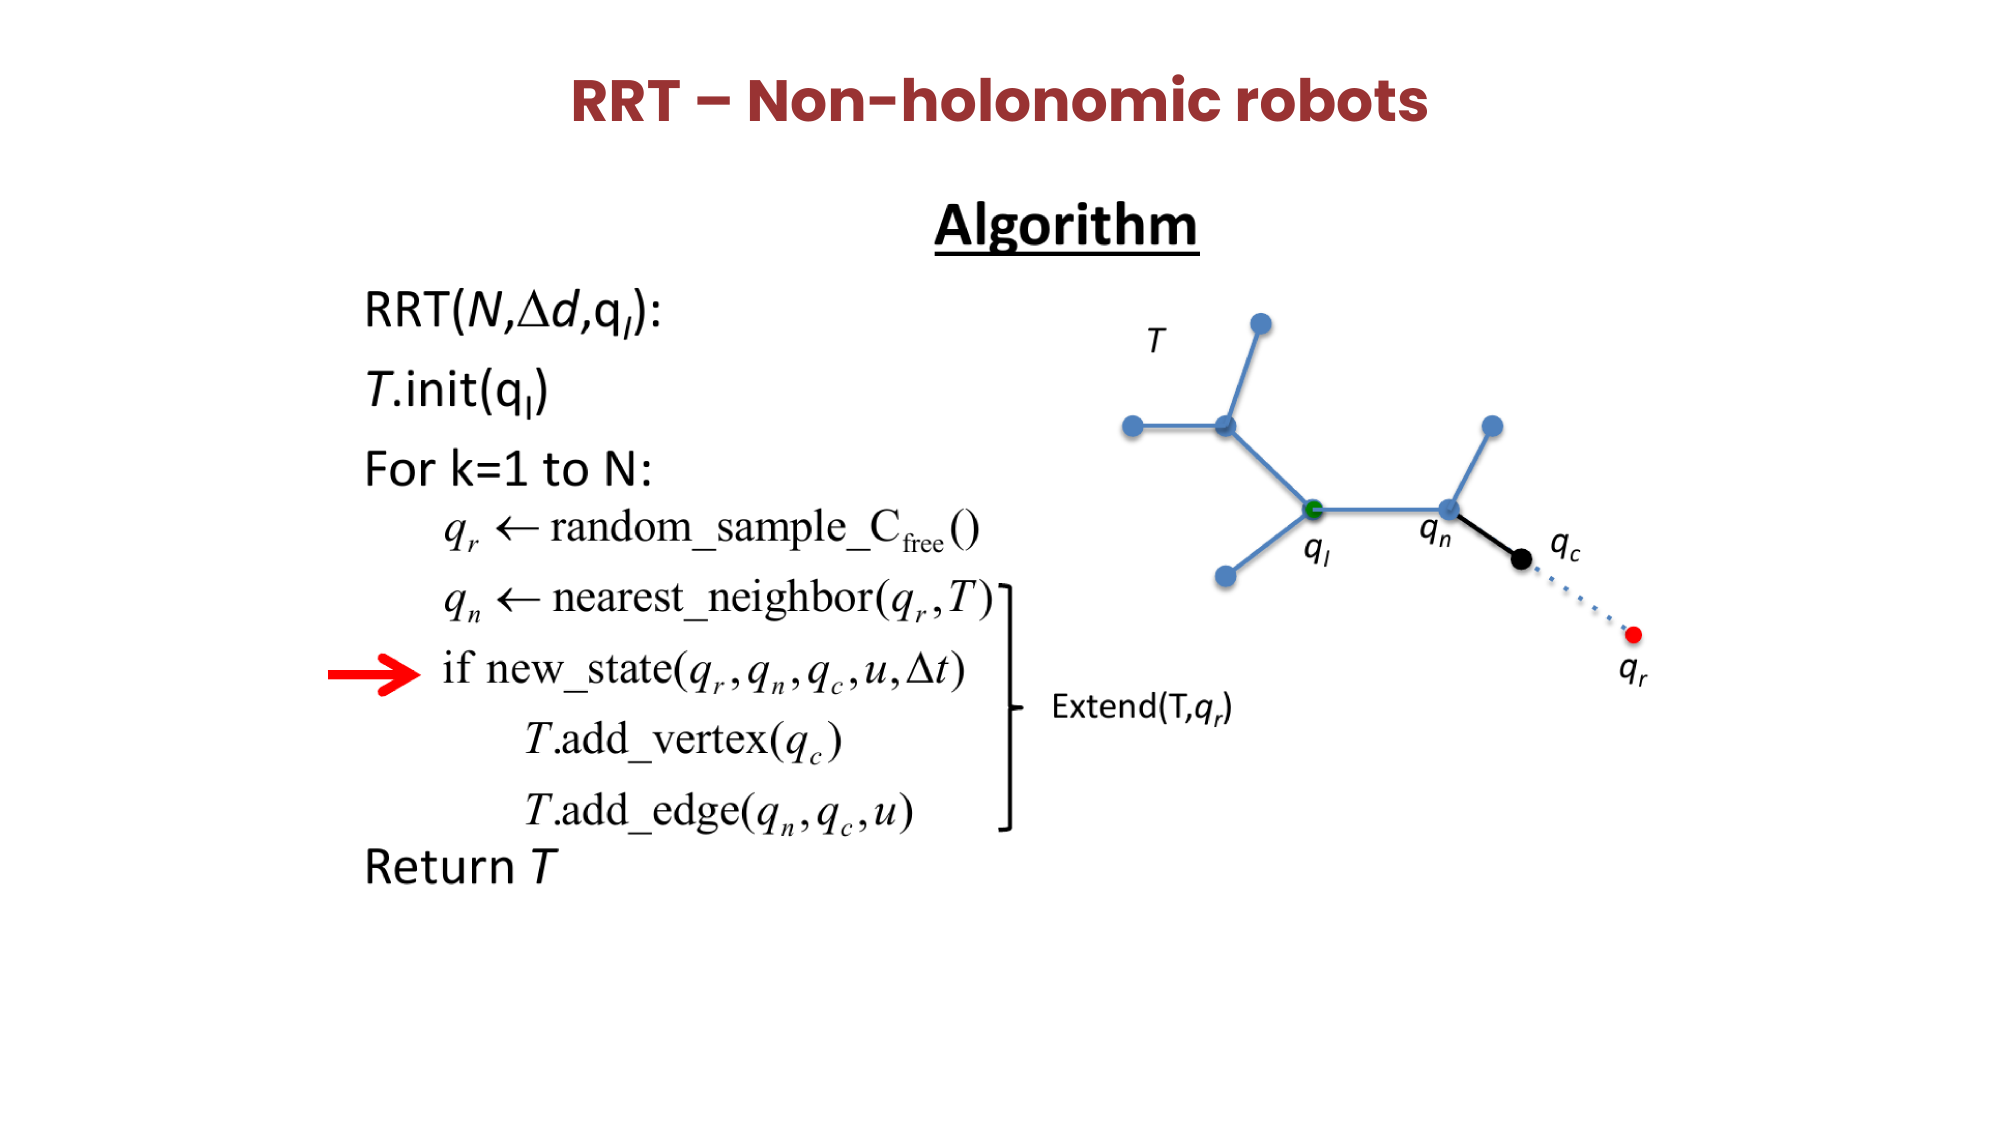
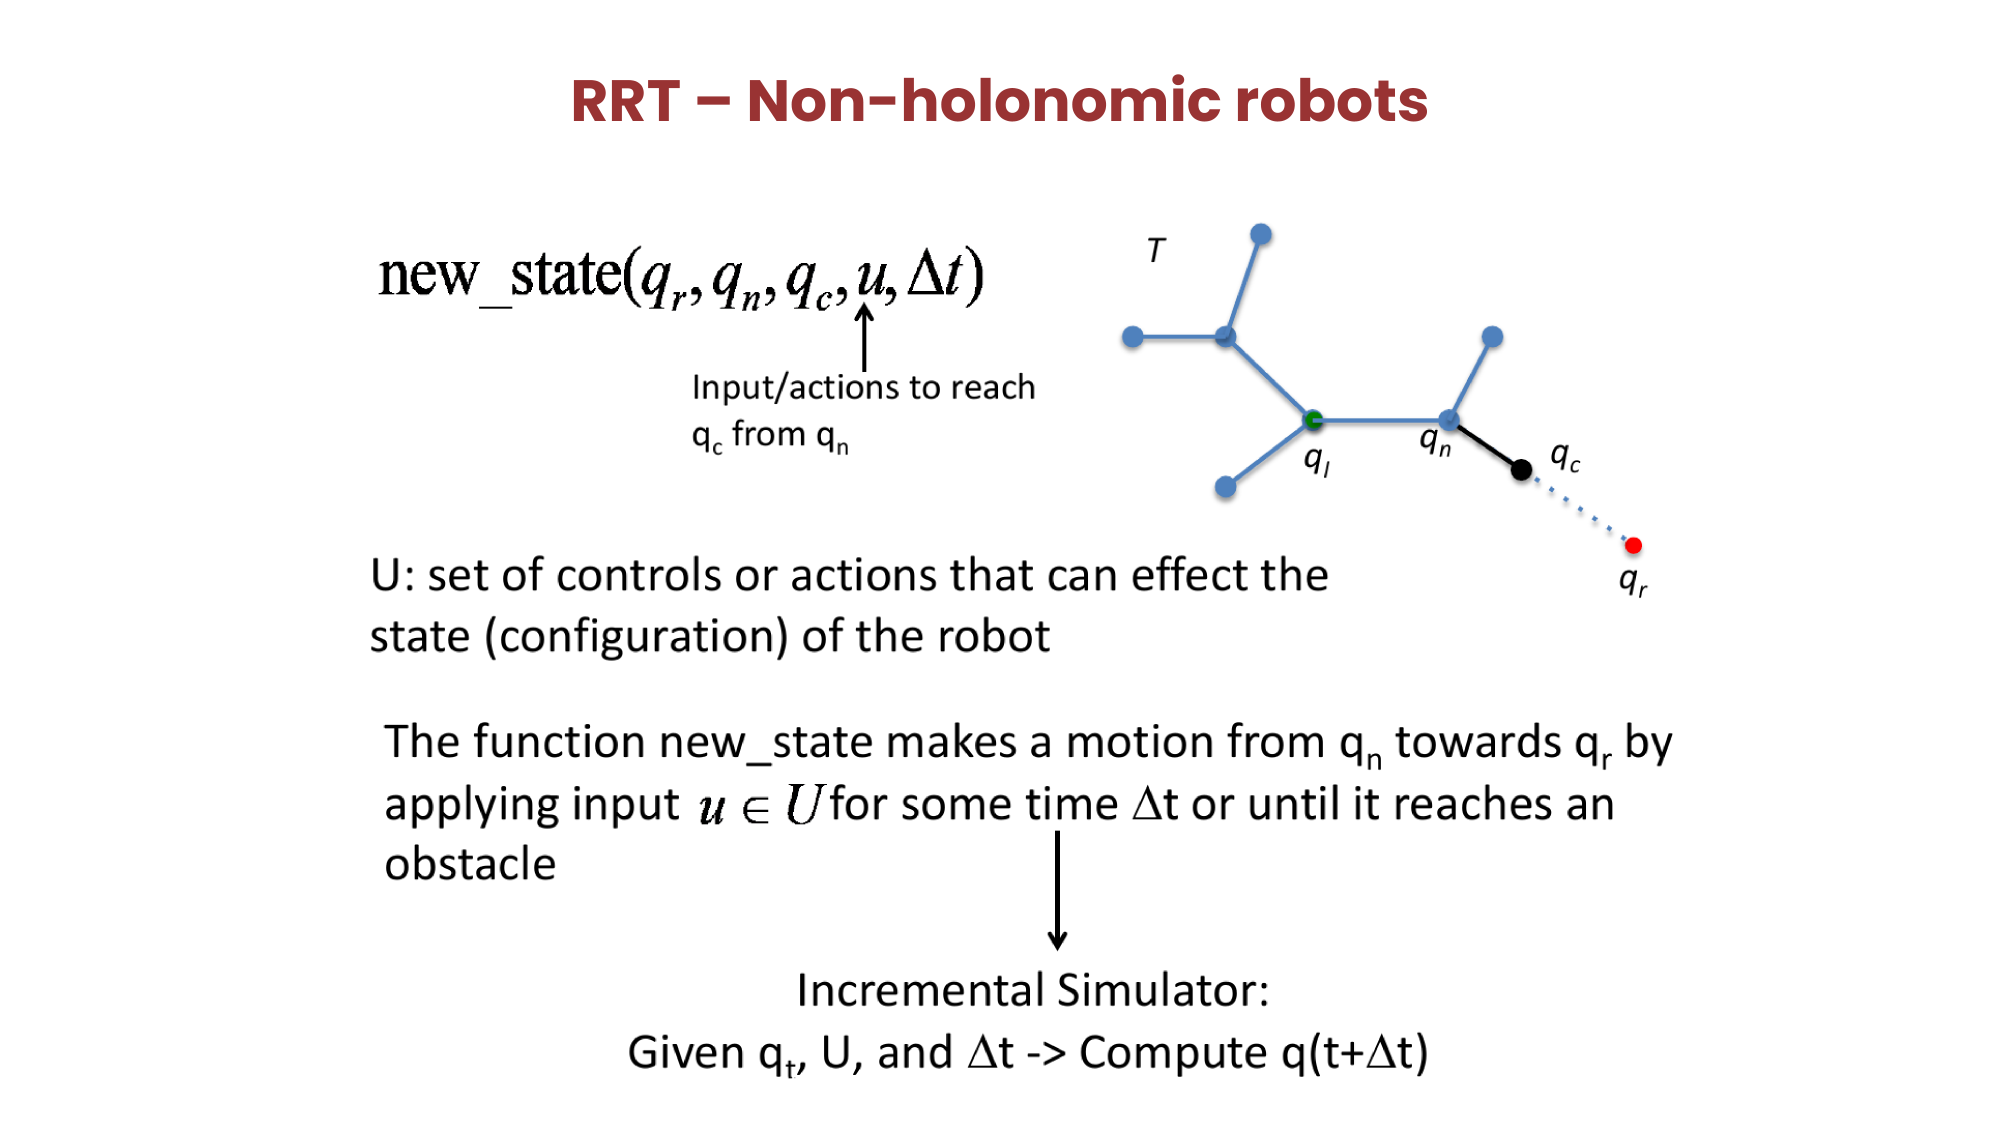
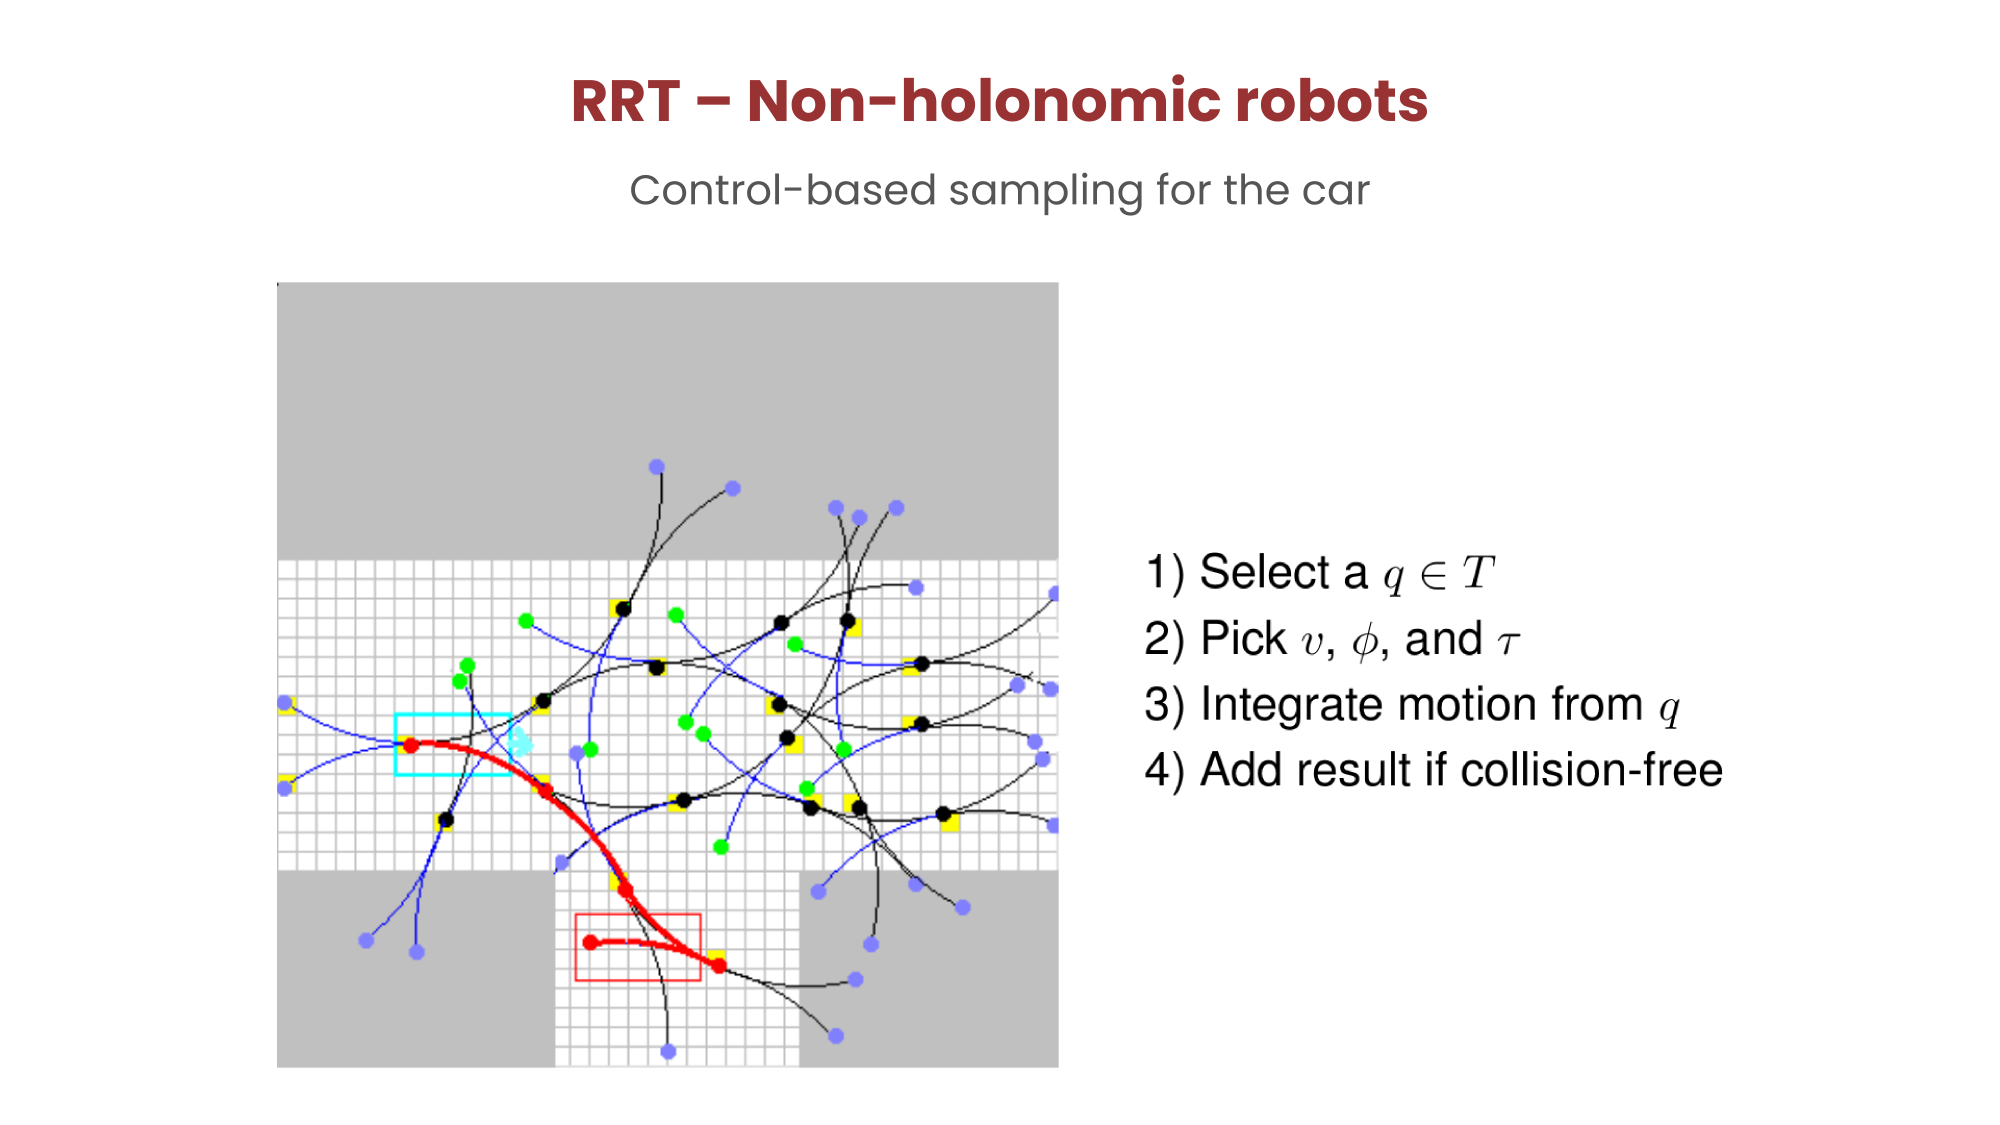
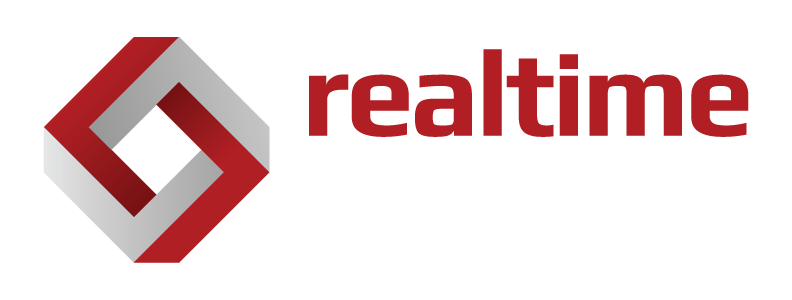
Hardware assist - 2016
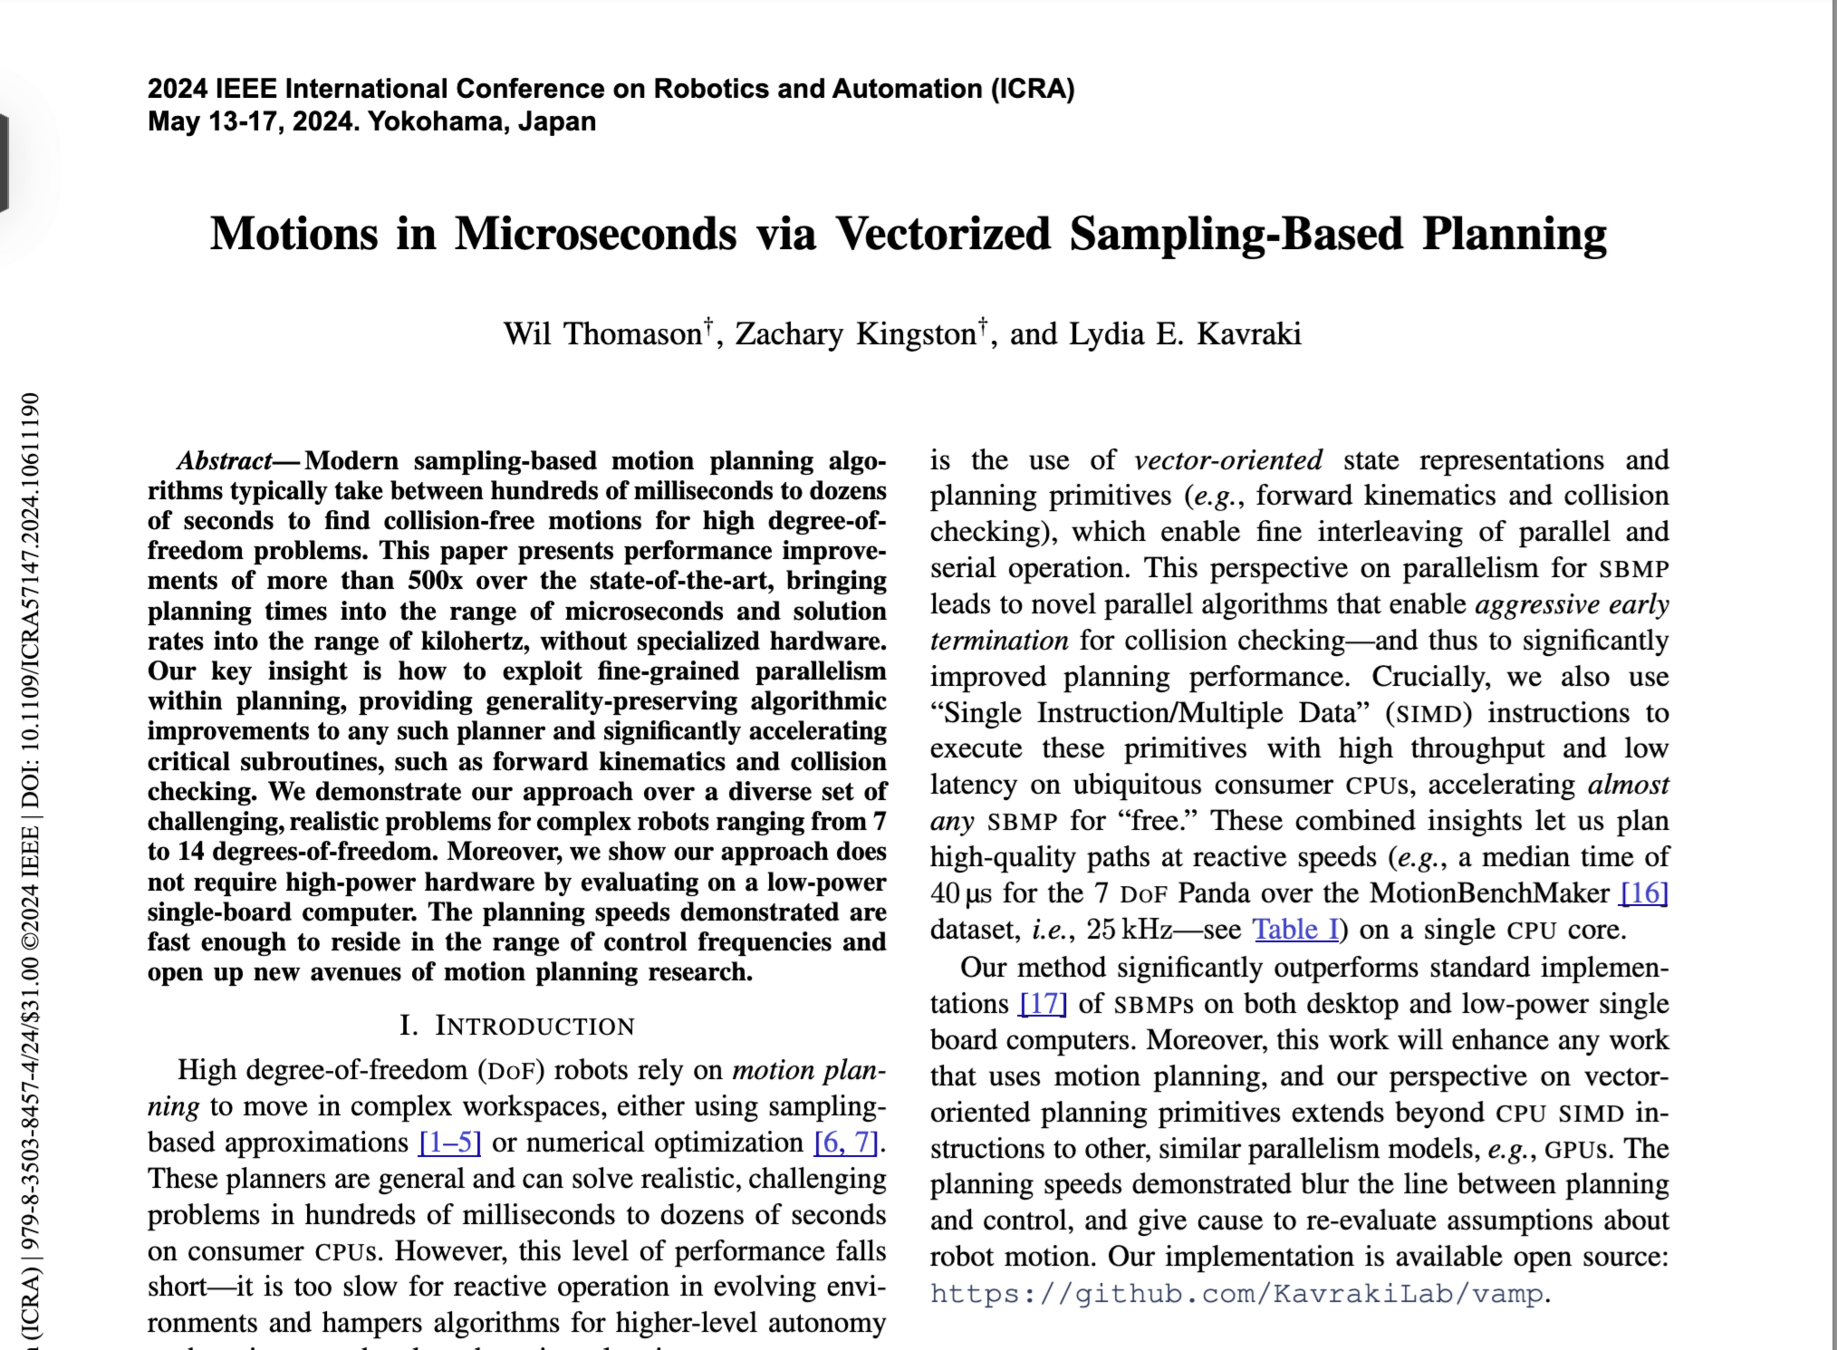
https://github.com/KavrakiLab/vamp
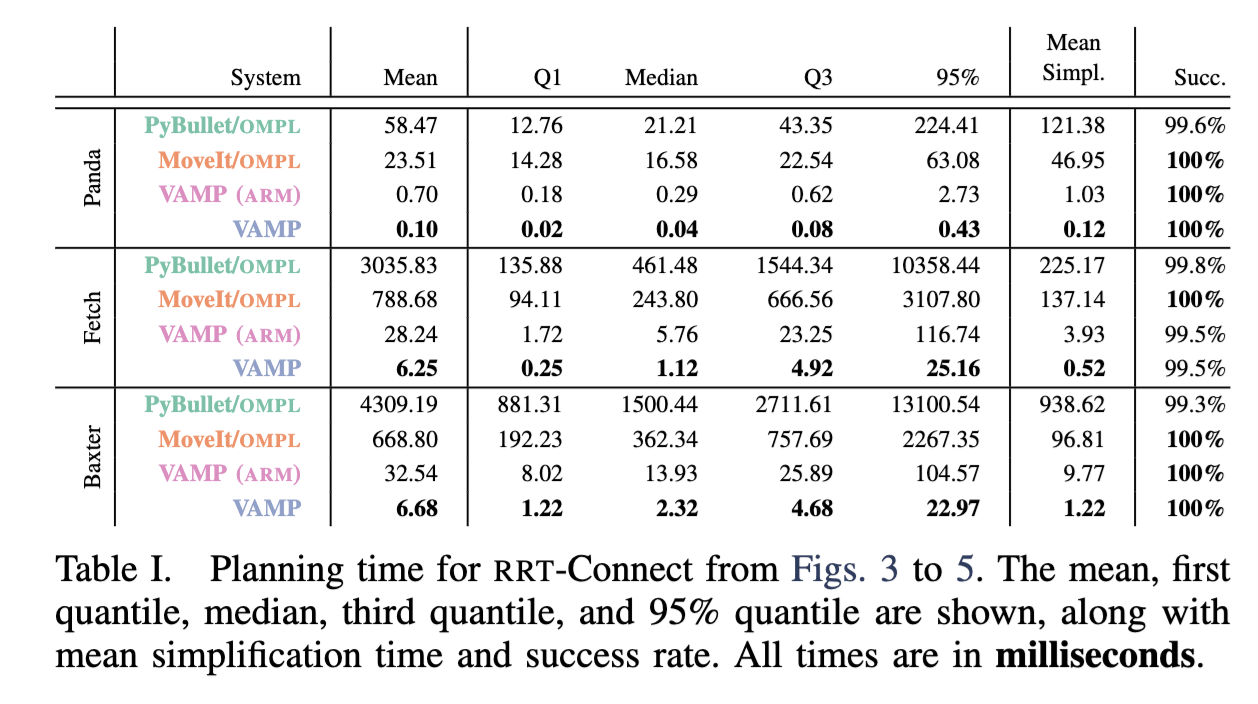
CUDA-Accelerated Robot Motion Generation in Milliseconds with NVIDIA cuRobo
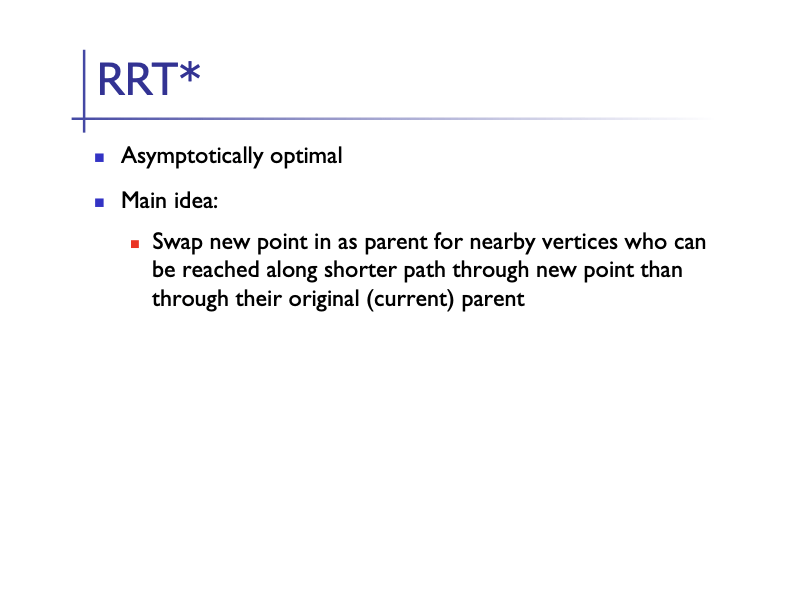
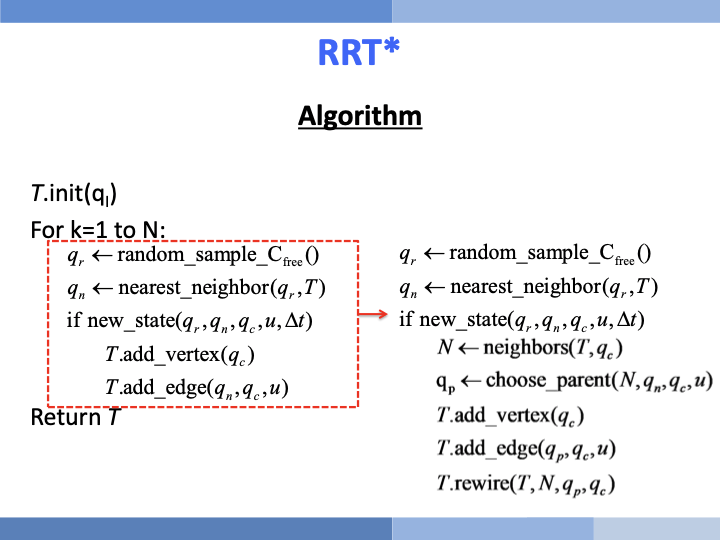
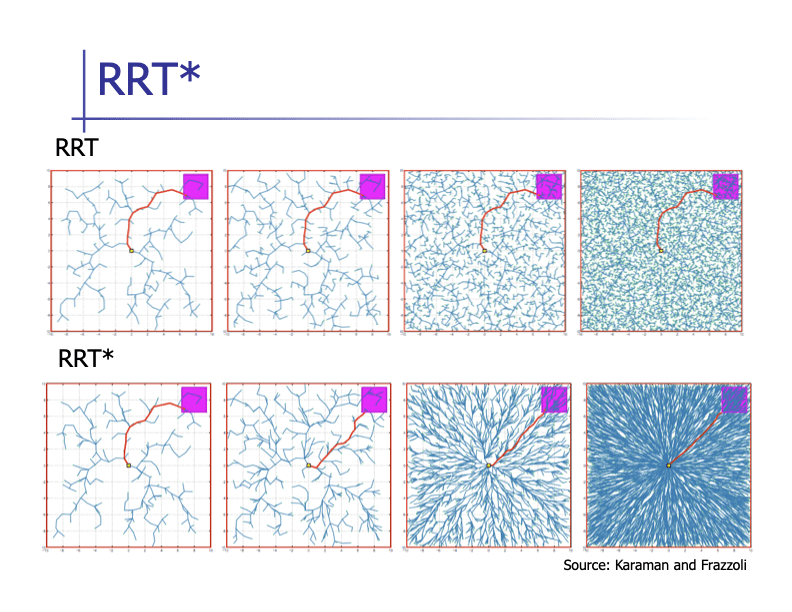
Asymptotically Optimal Sampling Based Planners
Global optimization-based planning
Motion planning as a (nonconvex) optimization
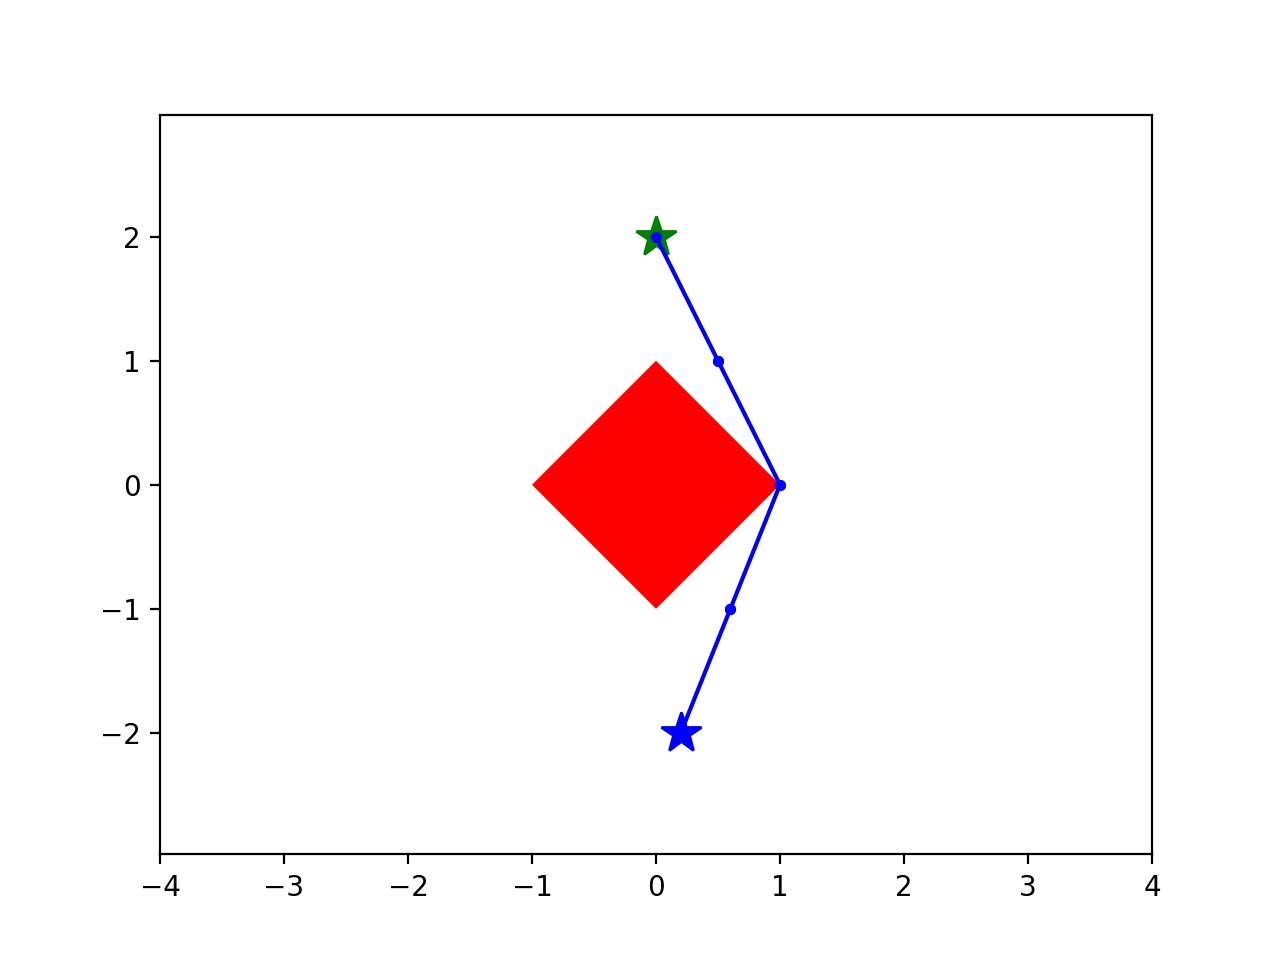
start
goal
fixed number of samples
collision-avoidance
(outside the \(L^1\) ball)
nonconvex
Motion Planning around Obstacles with Convex Optimization.
Tobia Marcucci, Mark Petersen, David von Wrangel, Russ Tedrake.
Available at: https://arxiv.org/abs/2205.04422
Accepted for publication in Science Robotics
Motion planning with Graphs of Convex Sets (GCS)
Claims:
- Find better plans faster than sampling-based planners
- Avoid local minima from trajectory optimization
- Can guarantee paths are collision-free
- Naturally handles dynamic limits/constraints
- Scales to big problems (e.g. multiple arms)
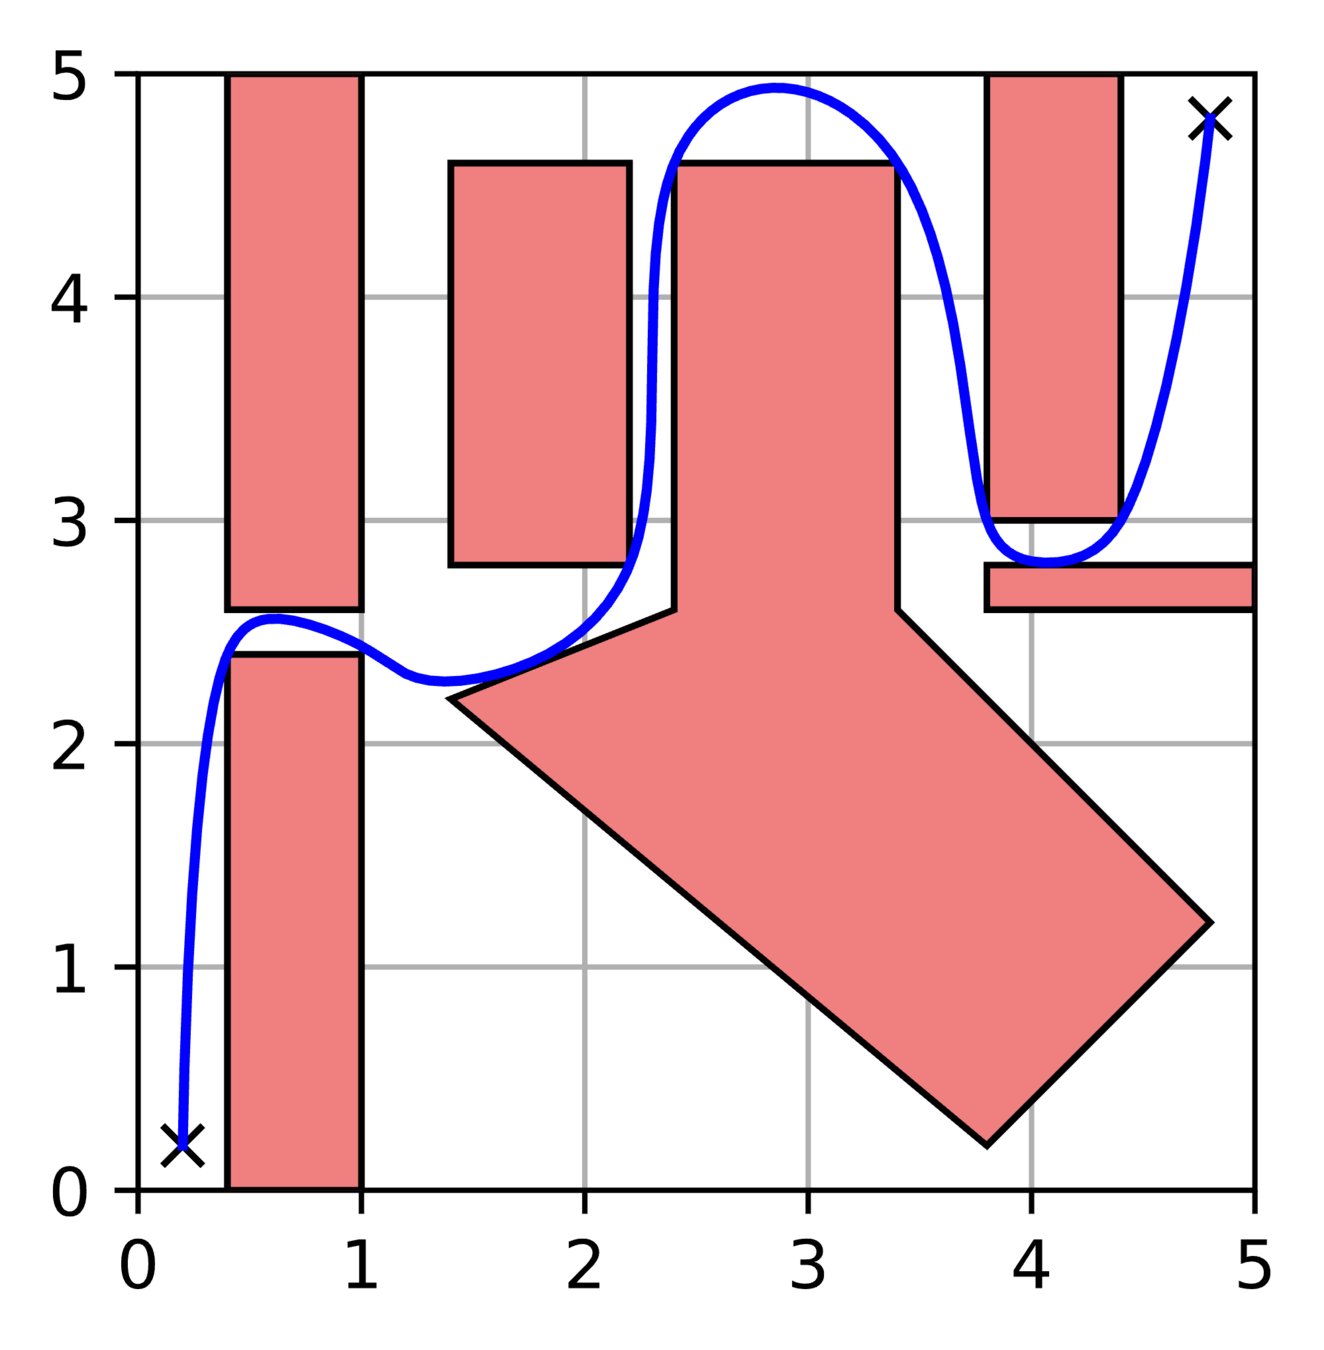
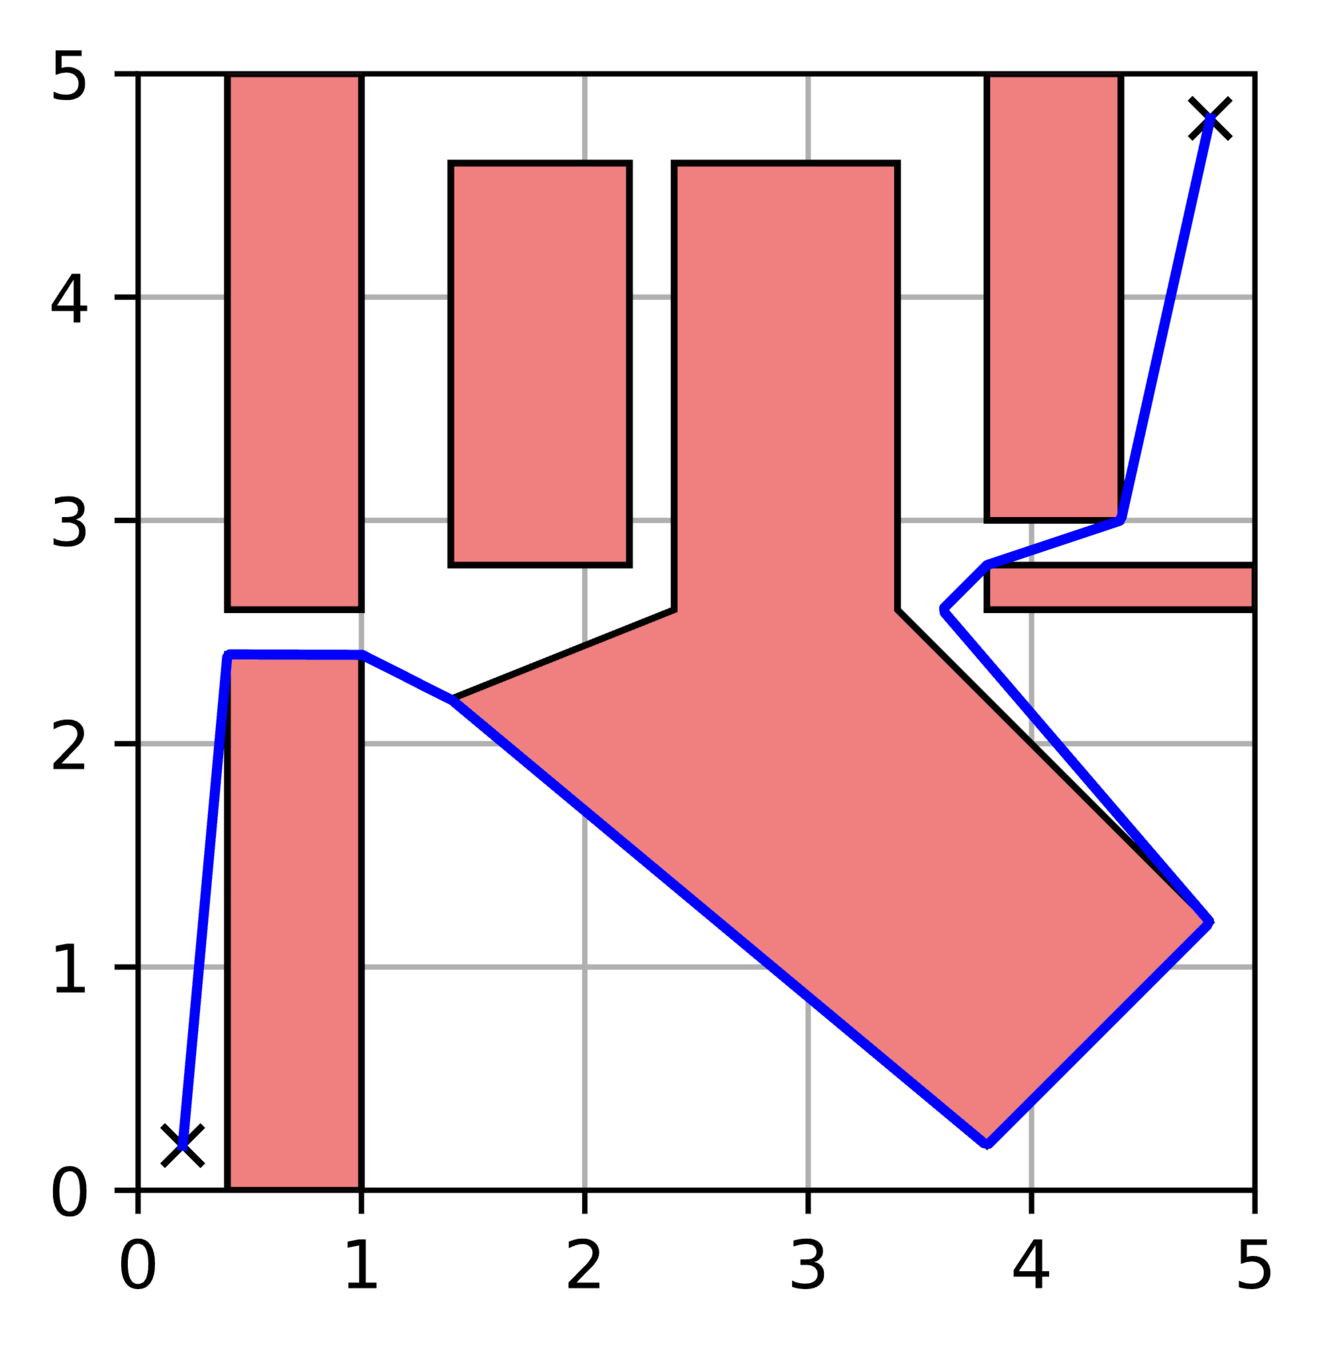
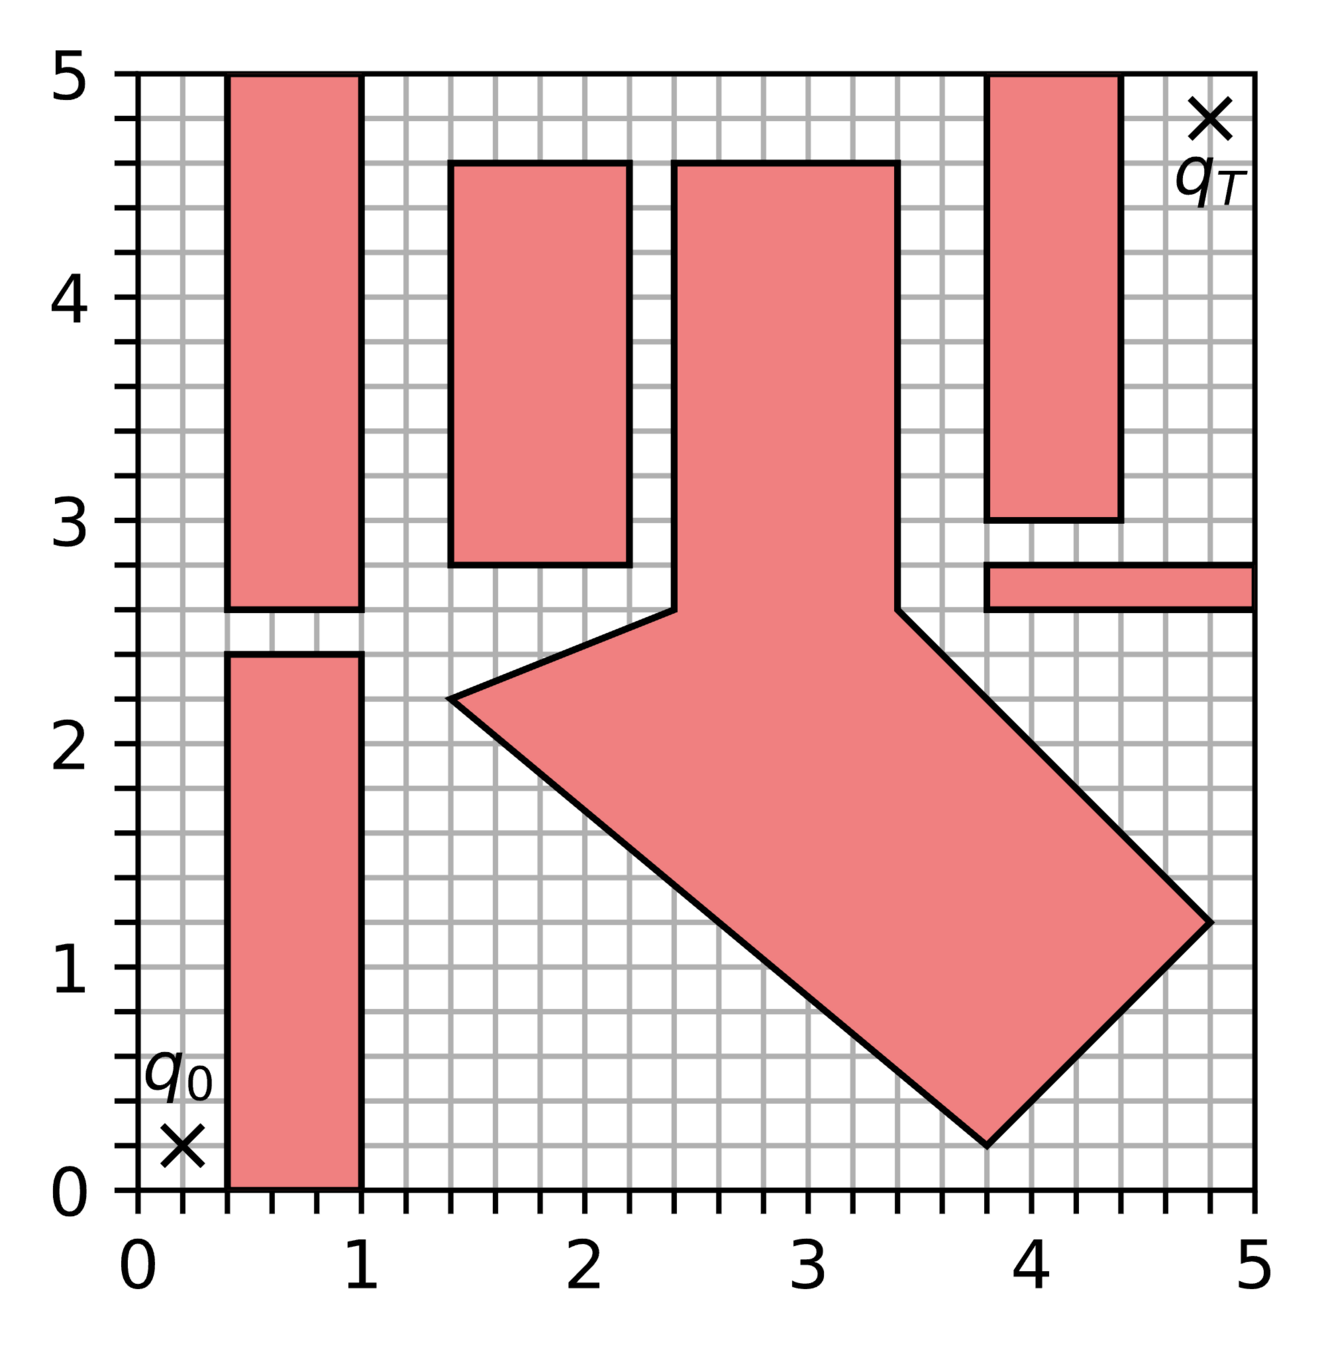
GCS Trajectory Optimization
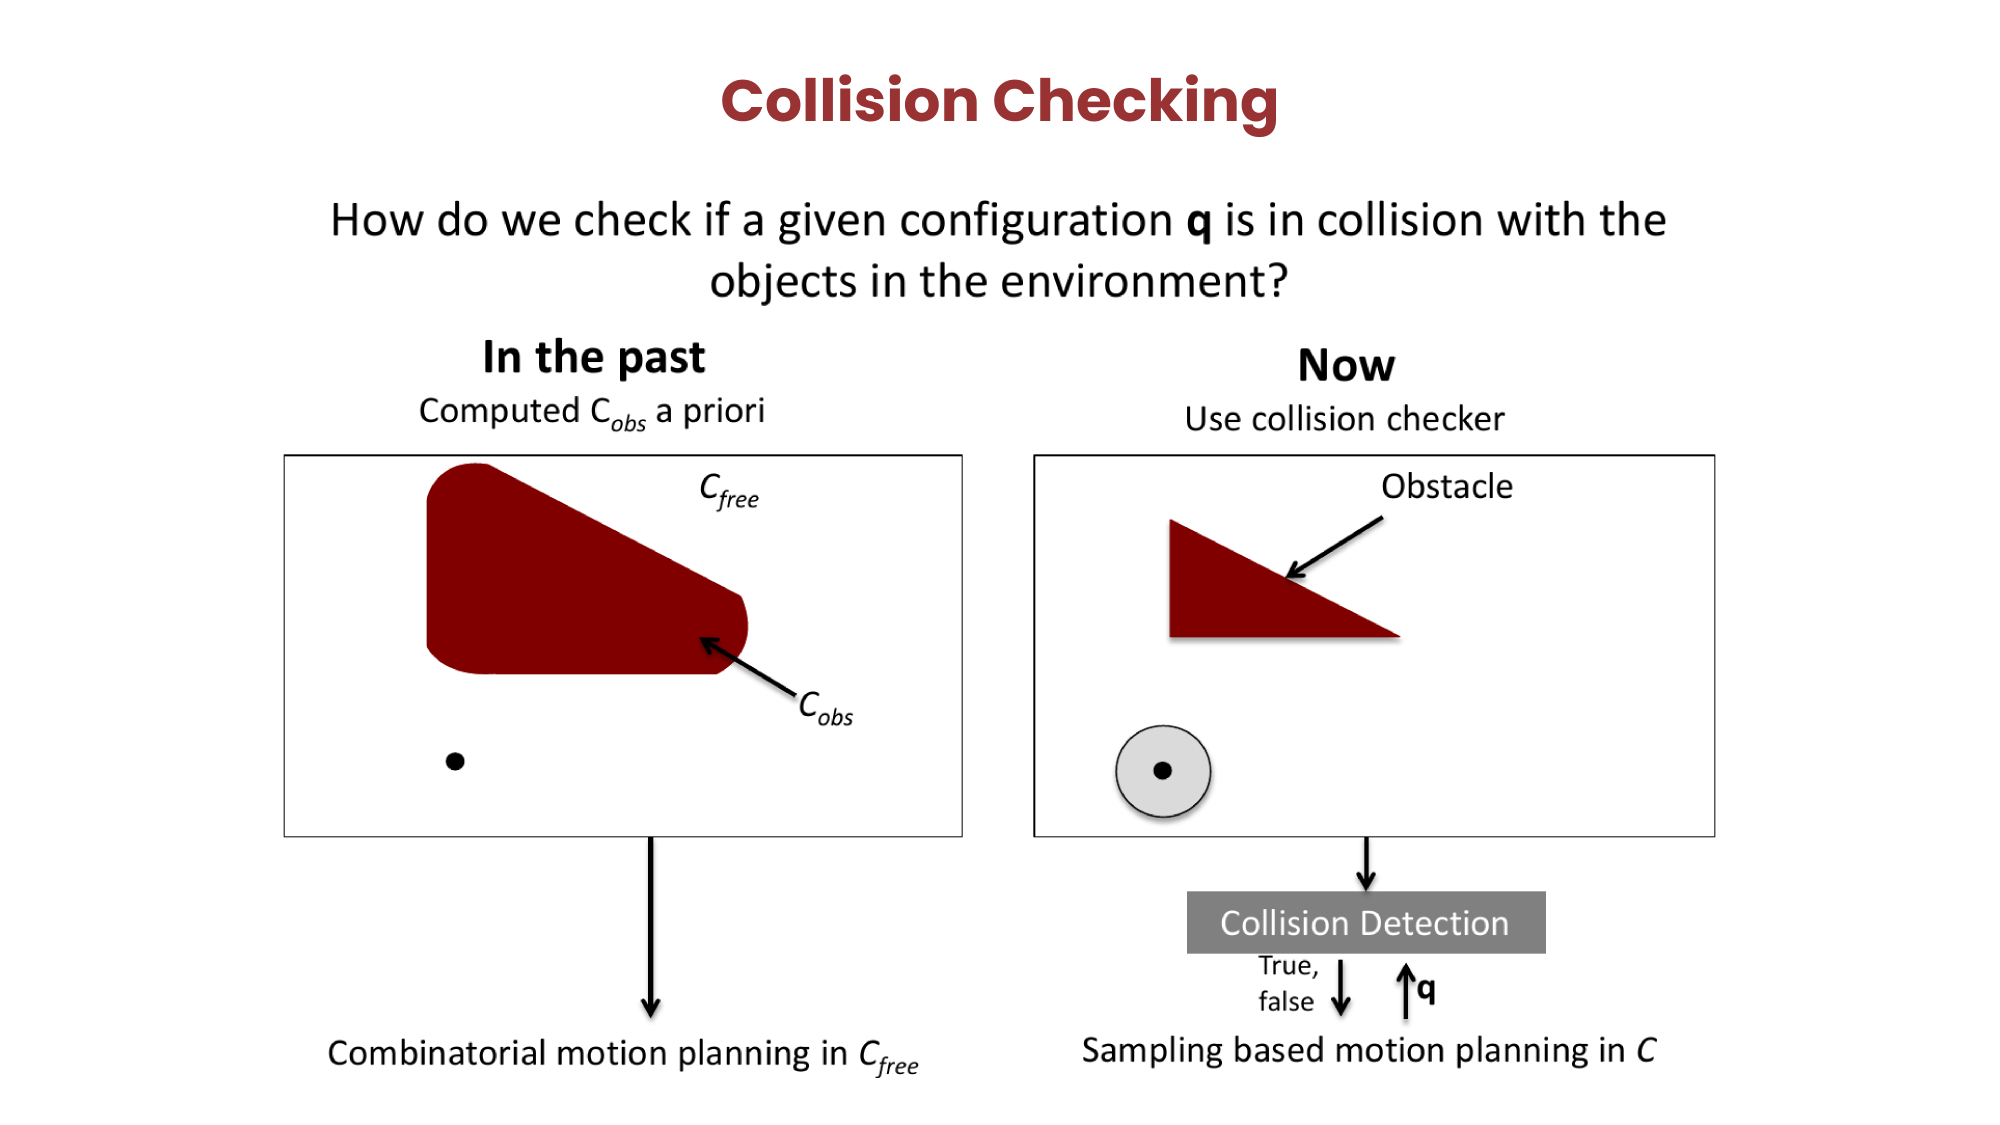
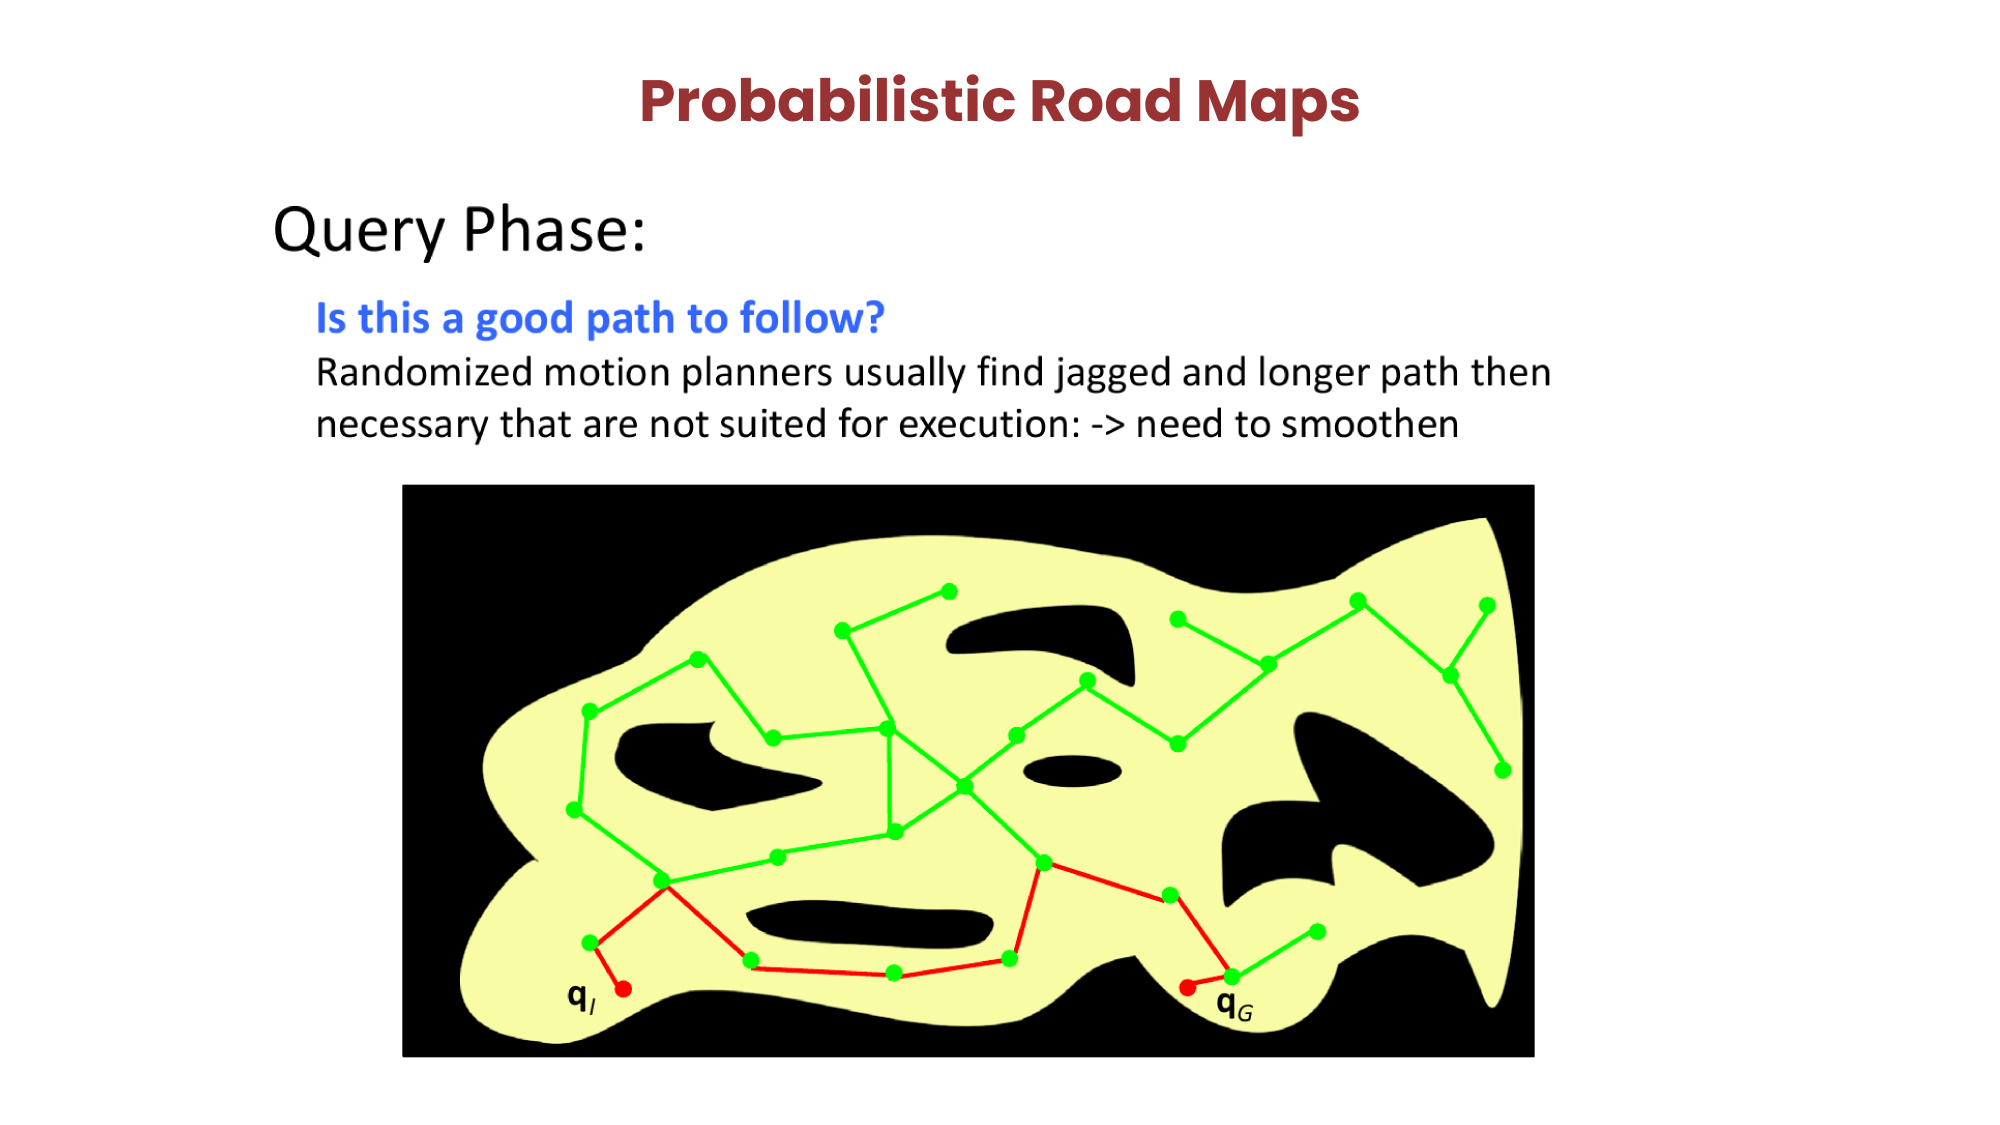
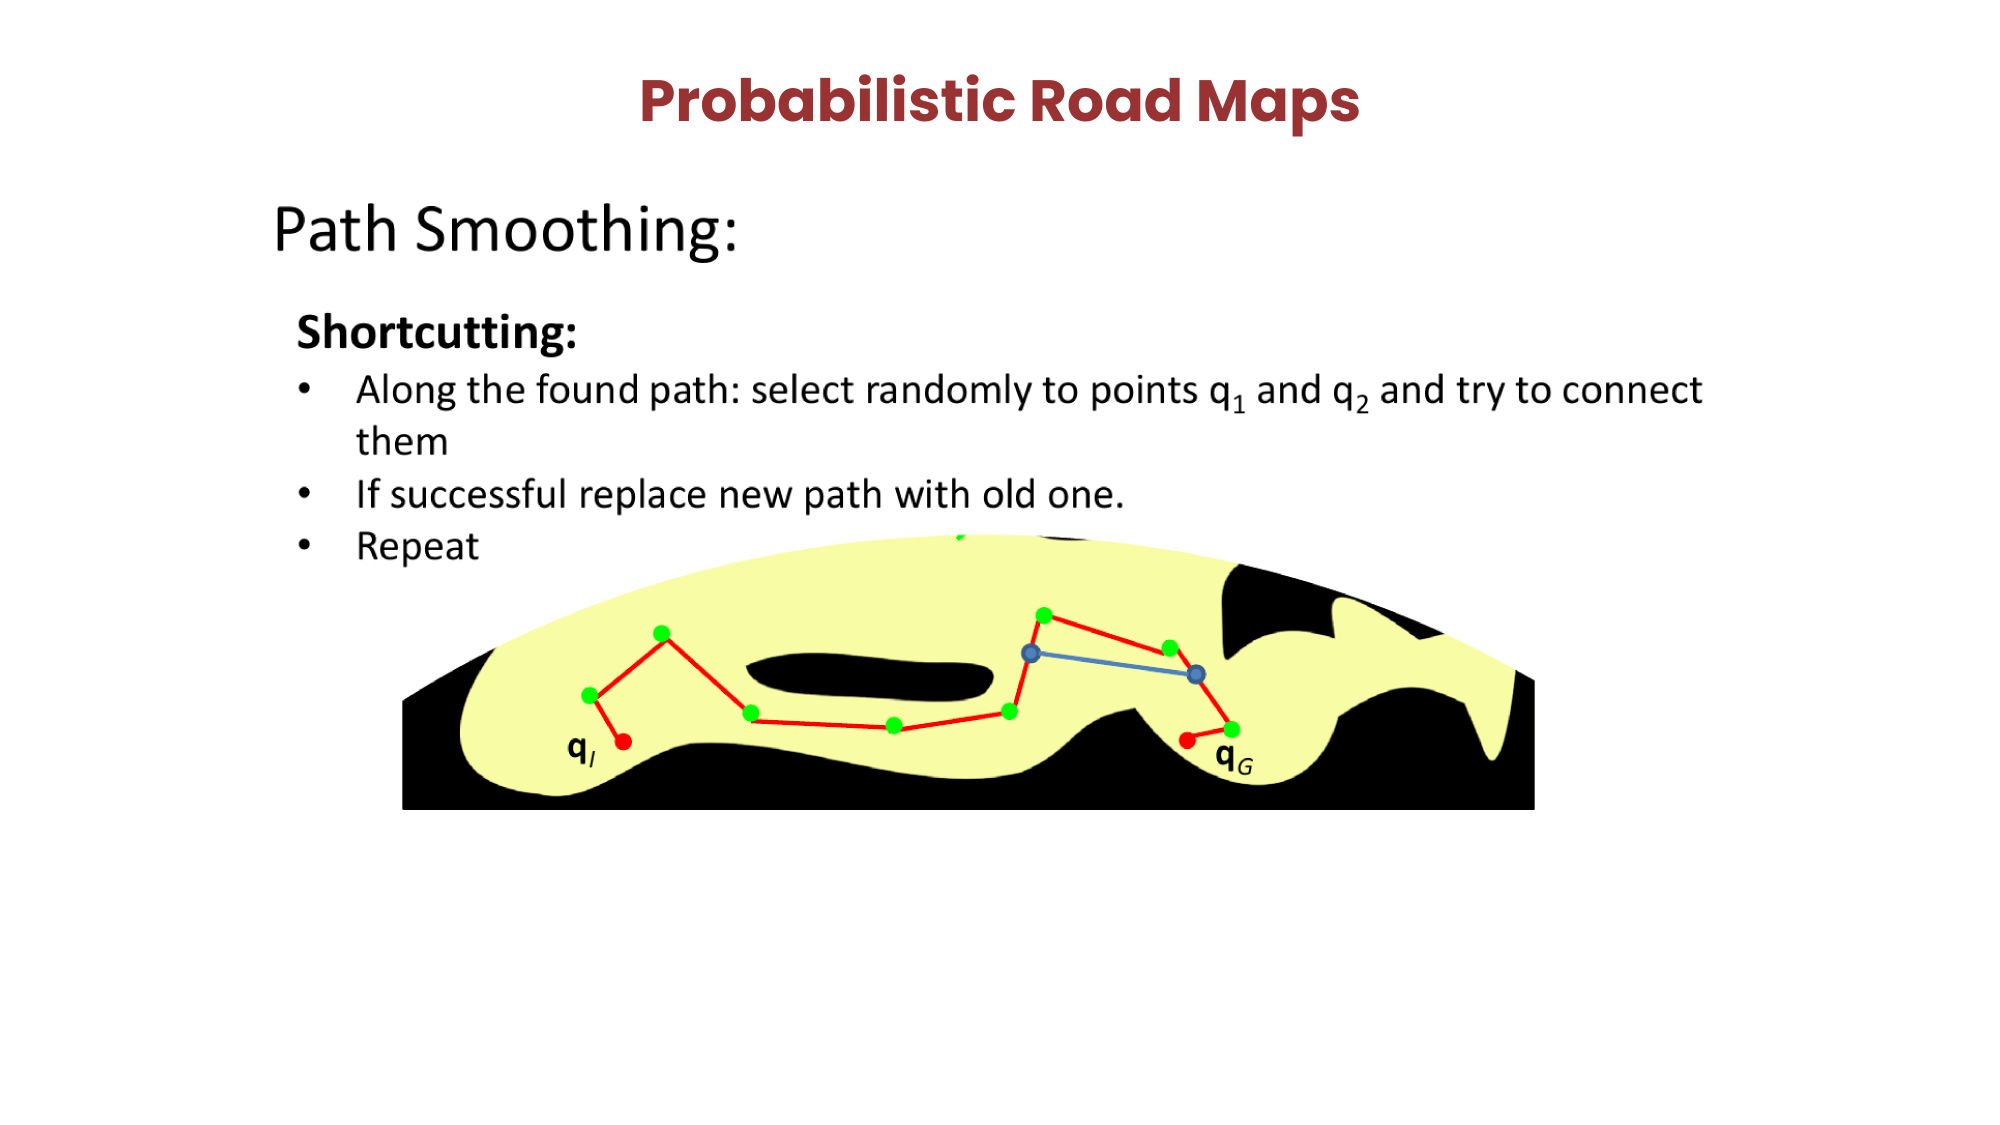
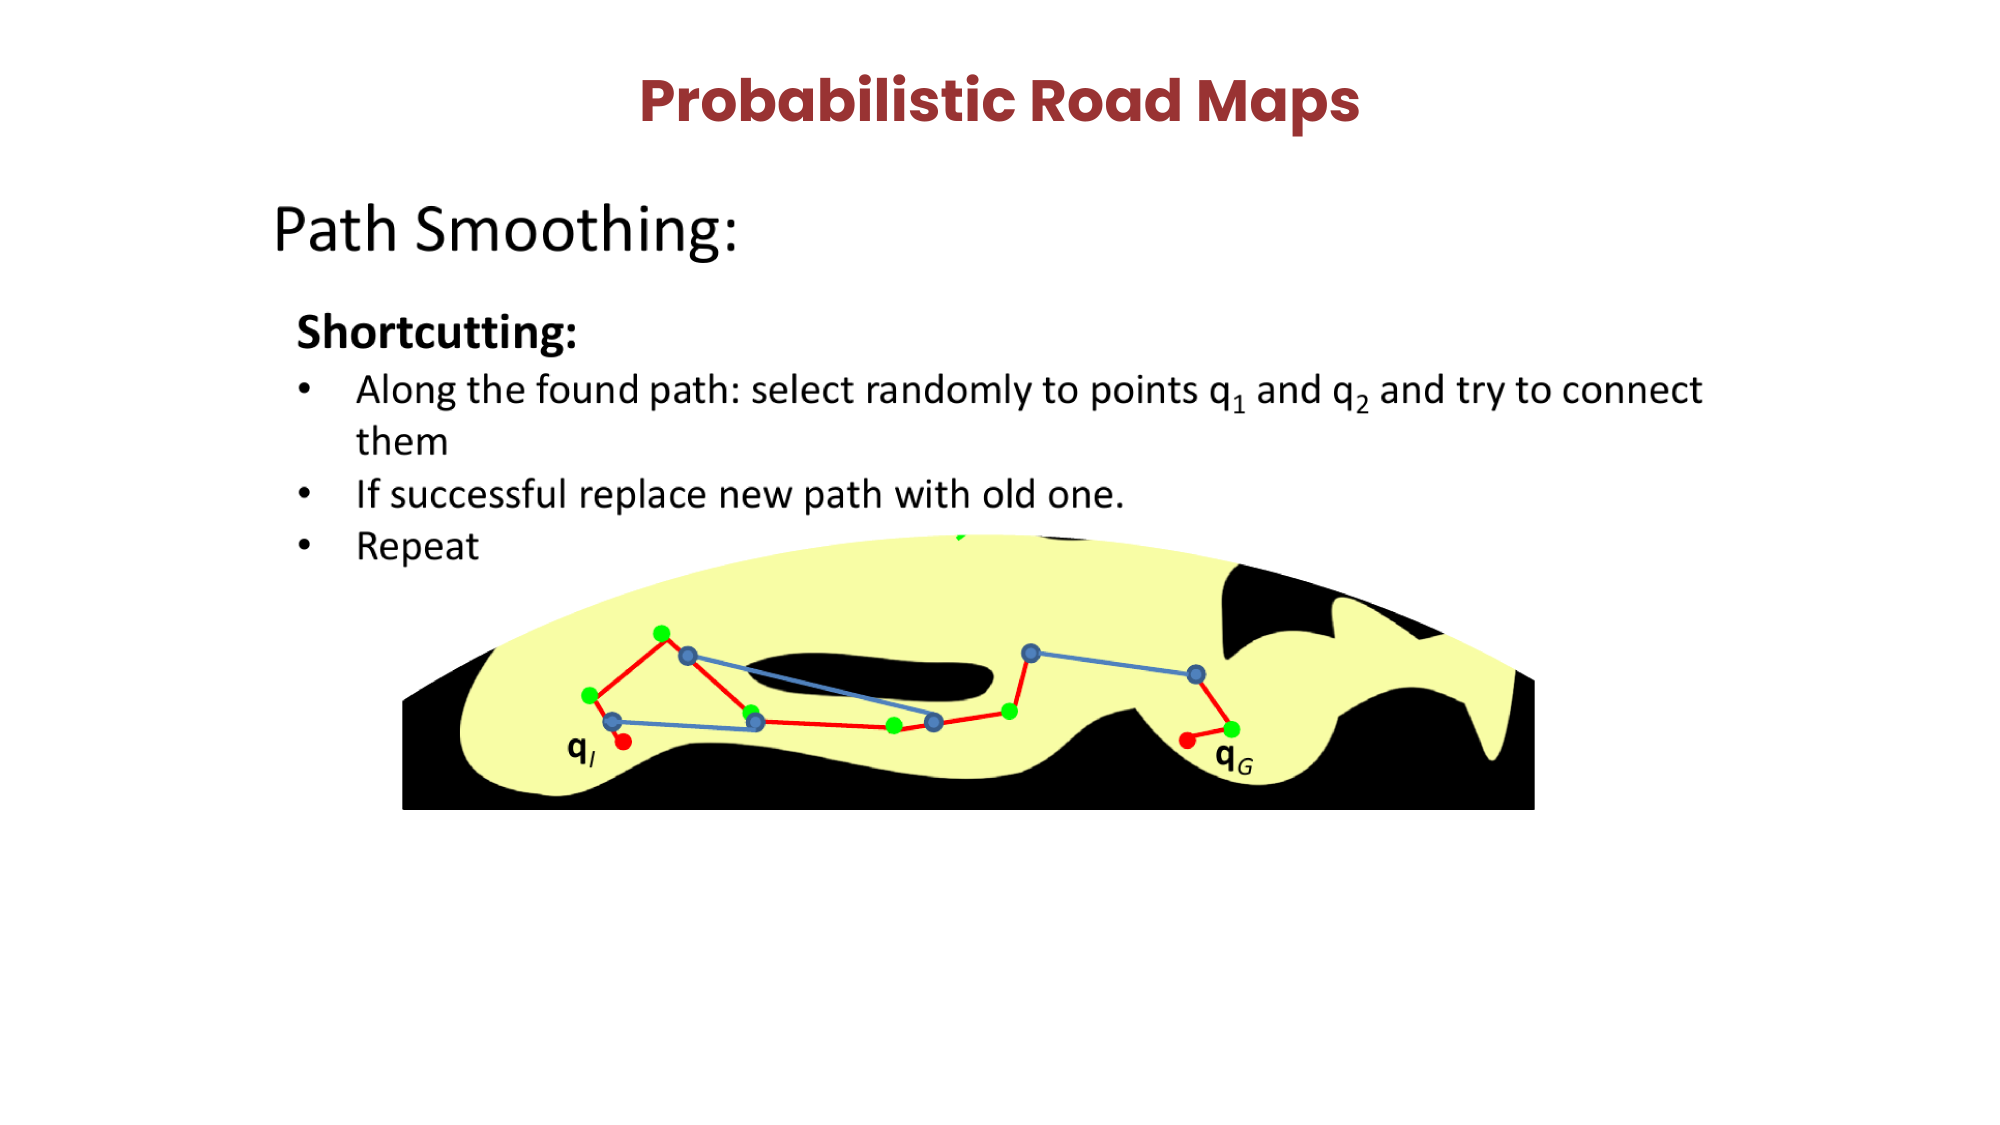
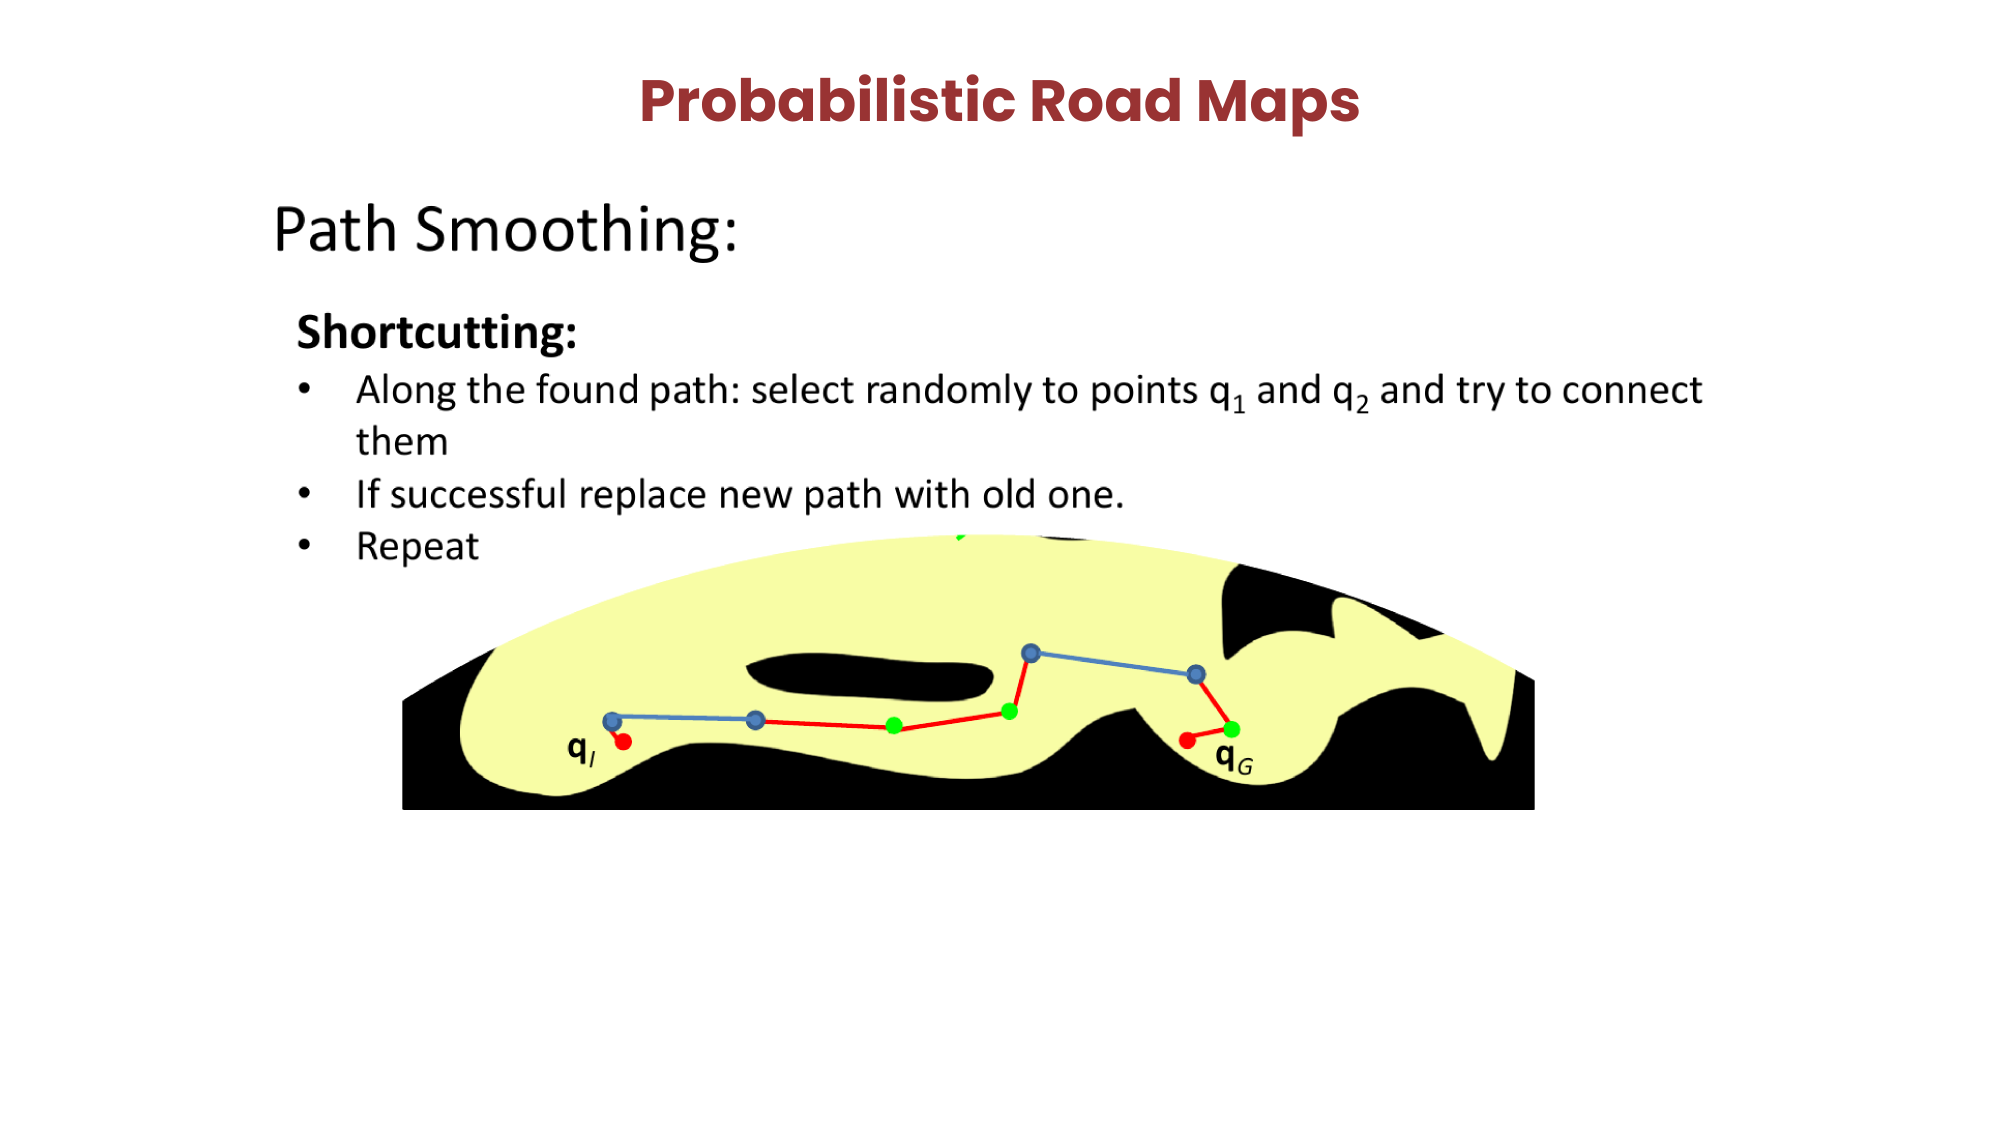
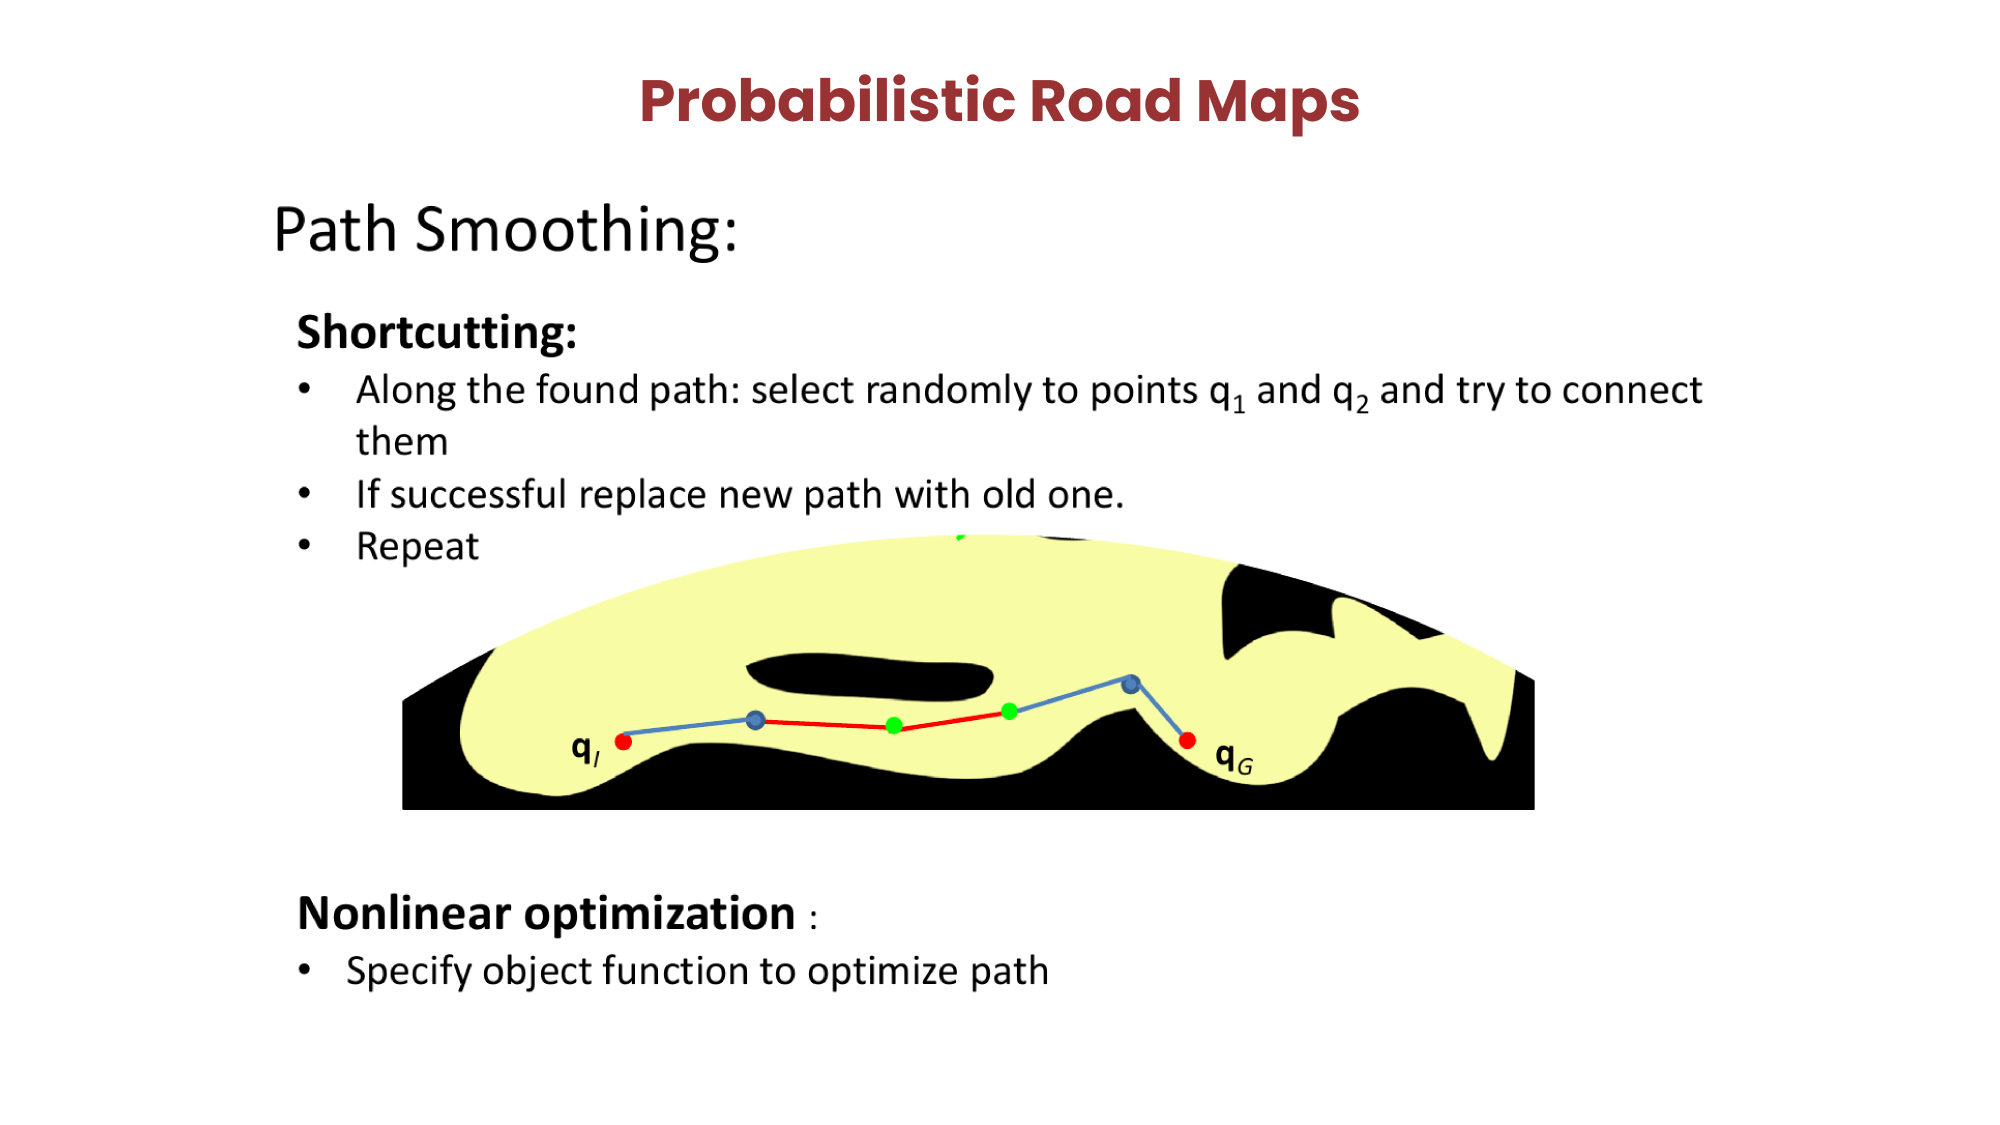
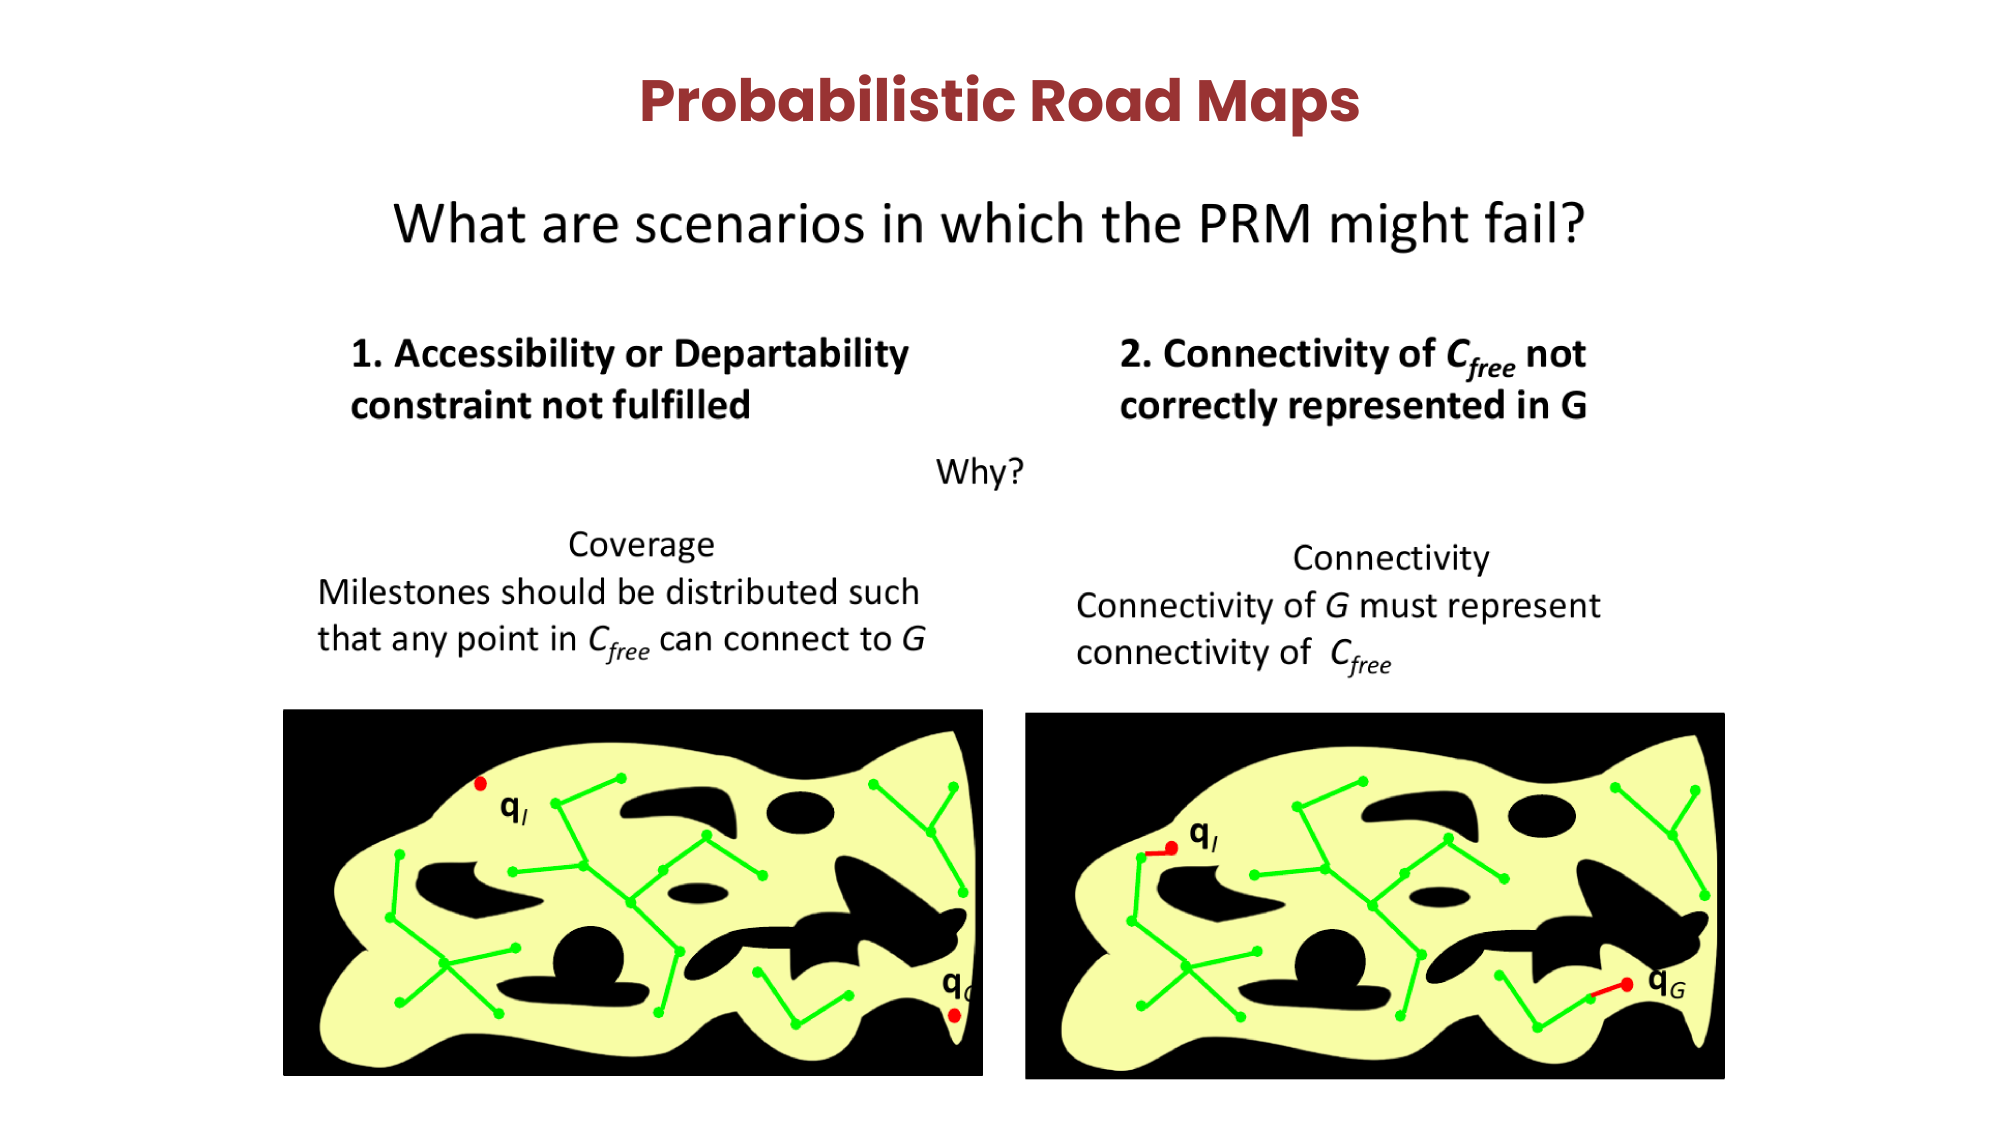
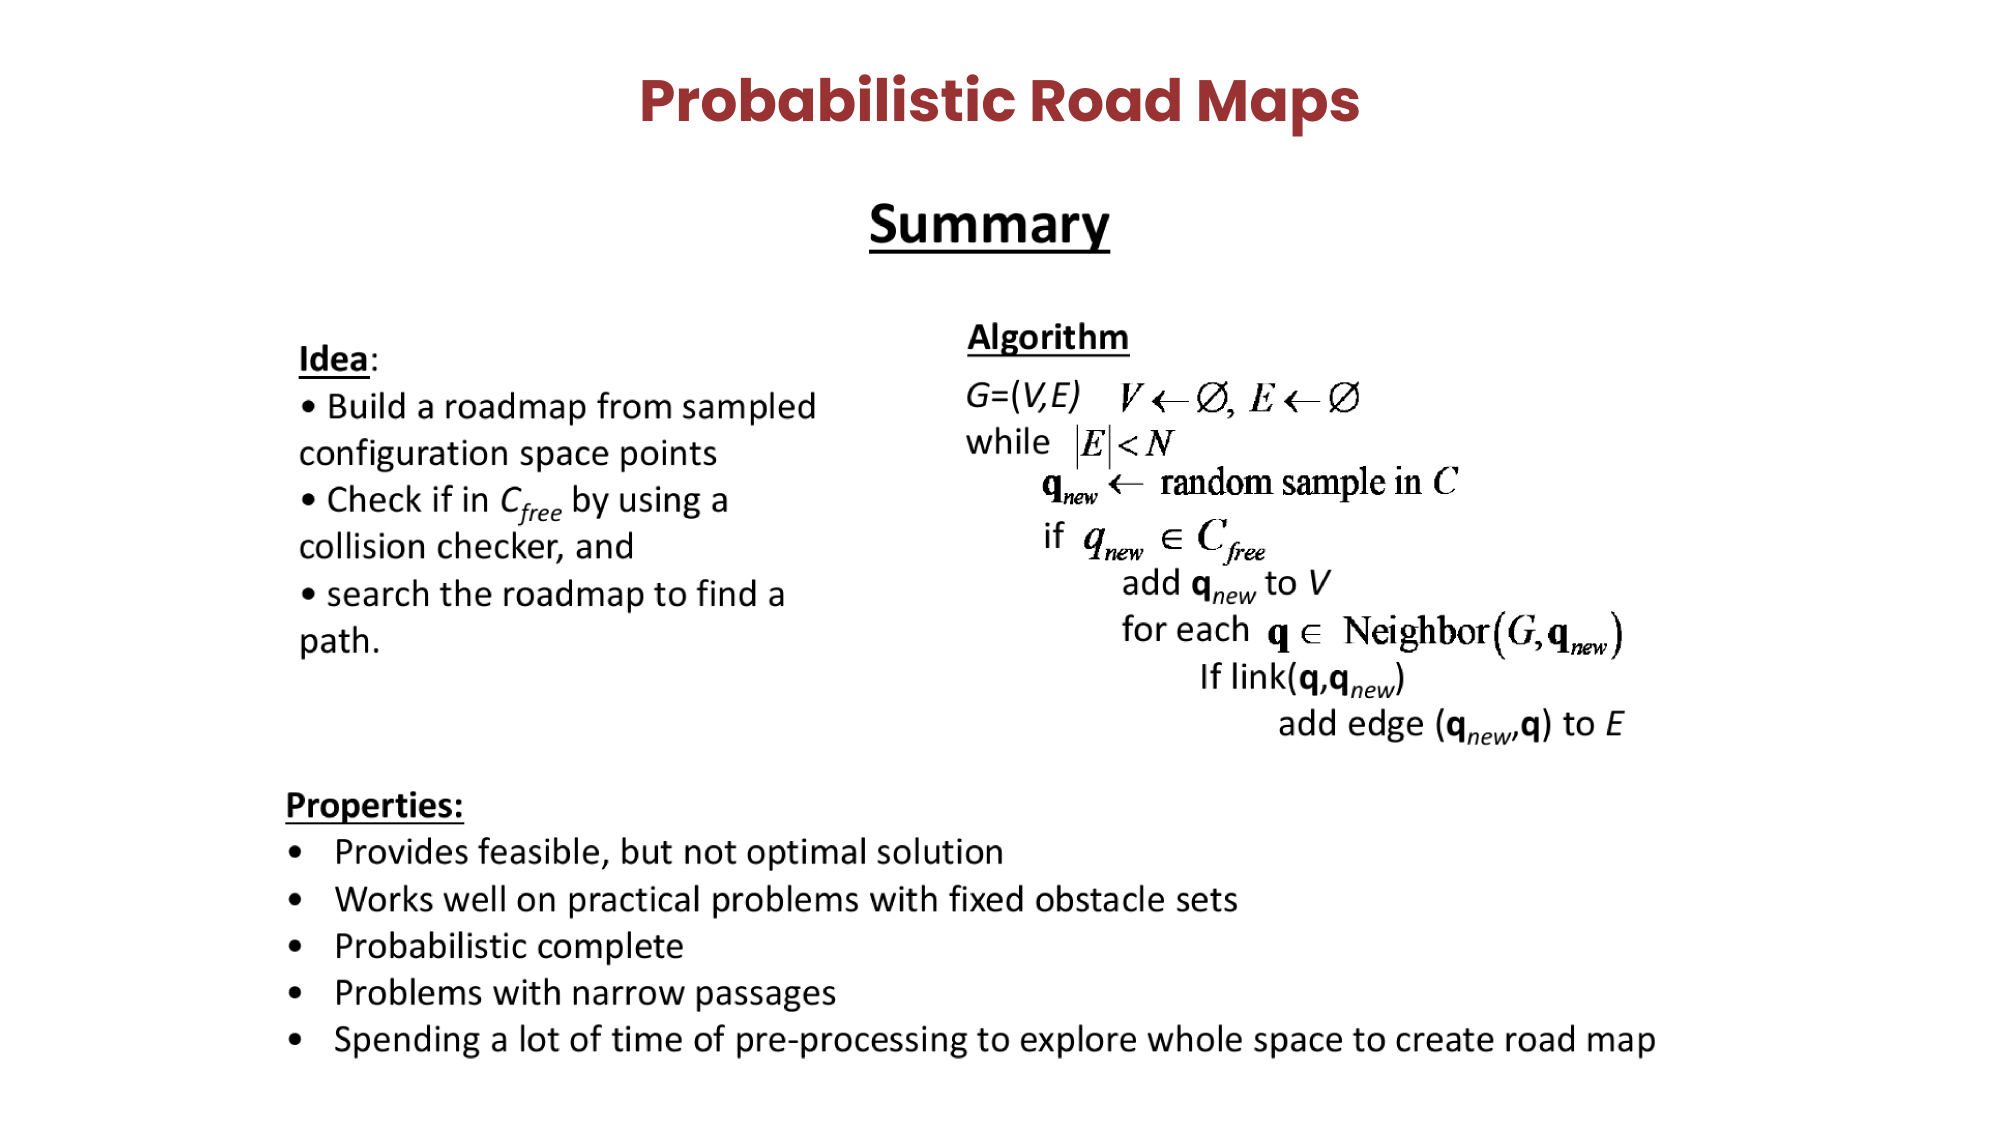
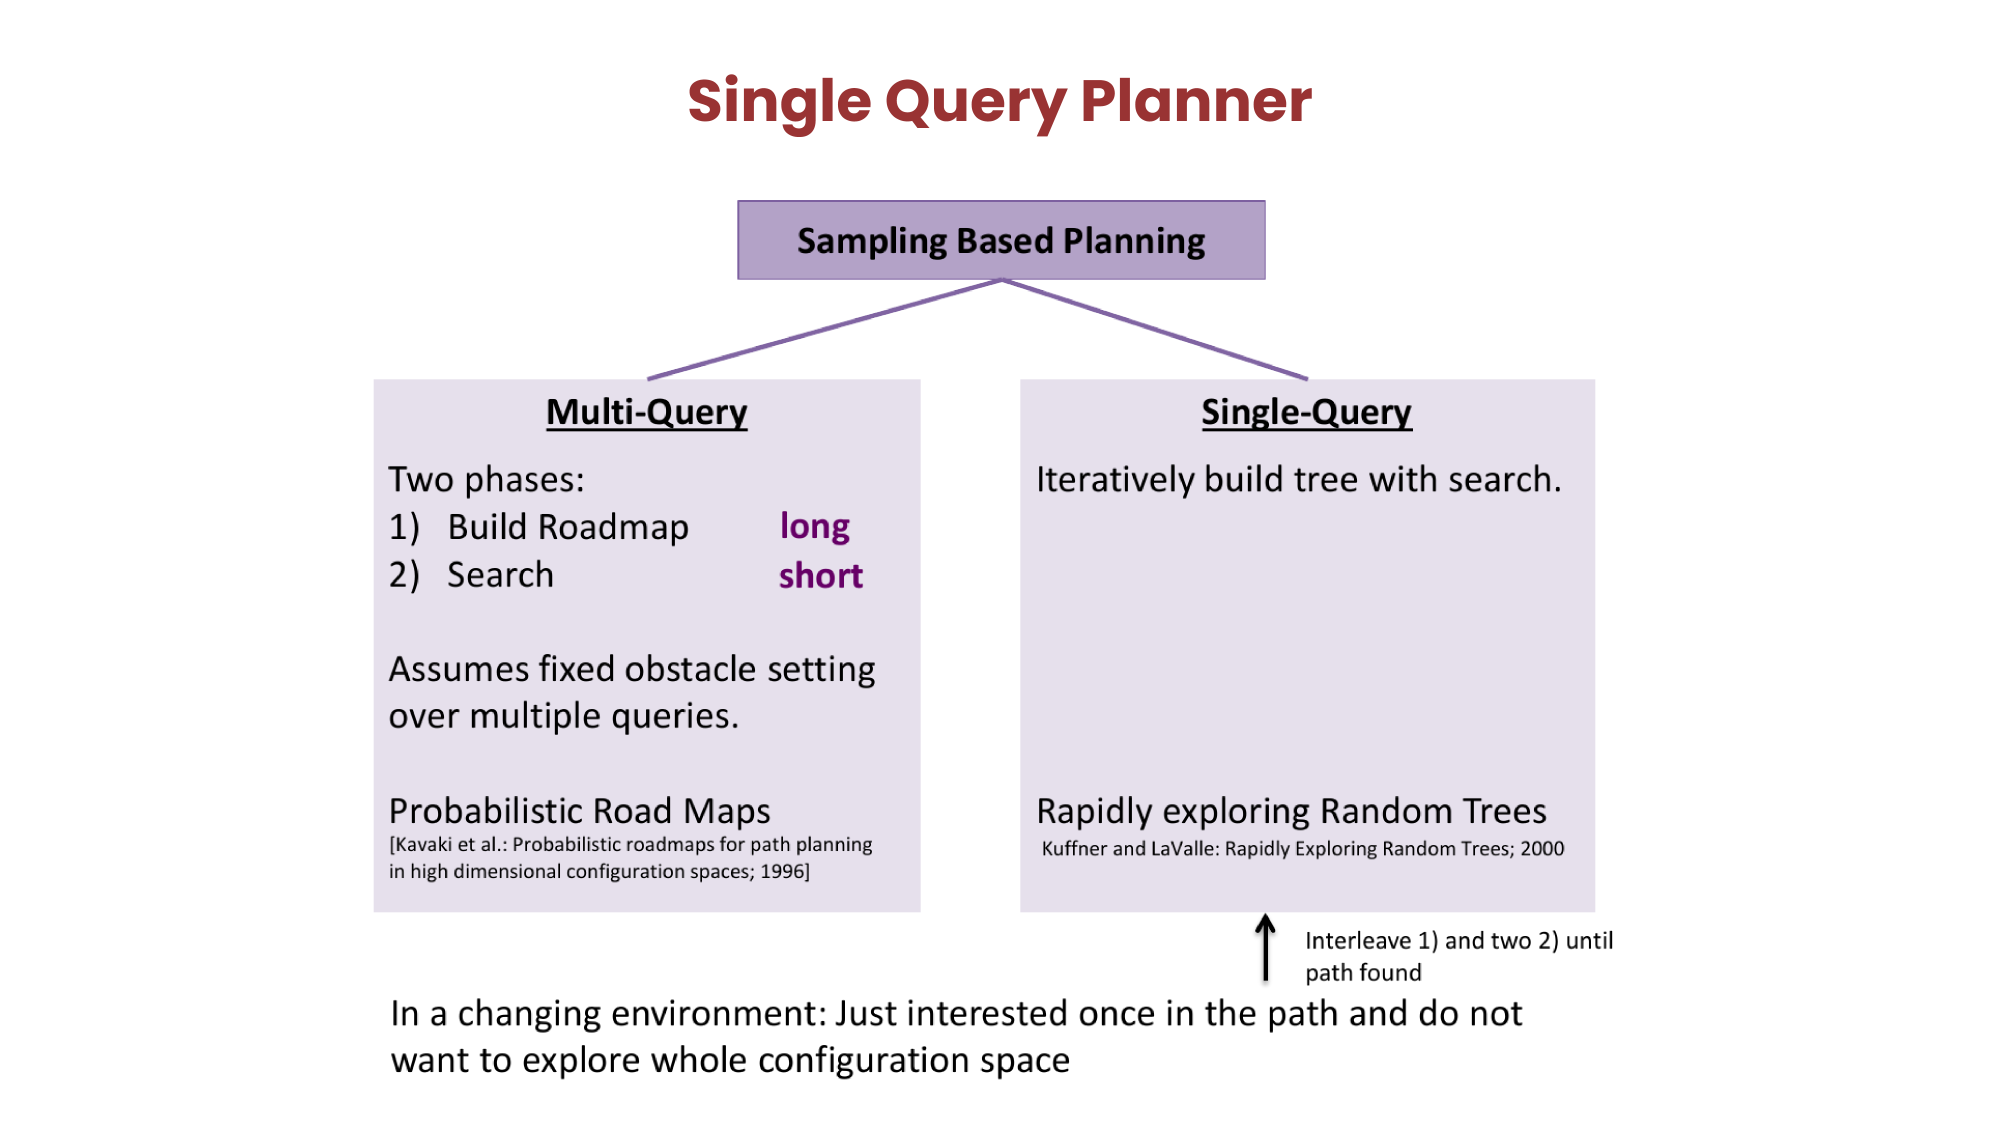
Sampling-based motion planning
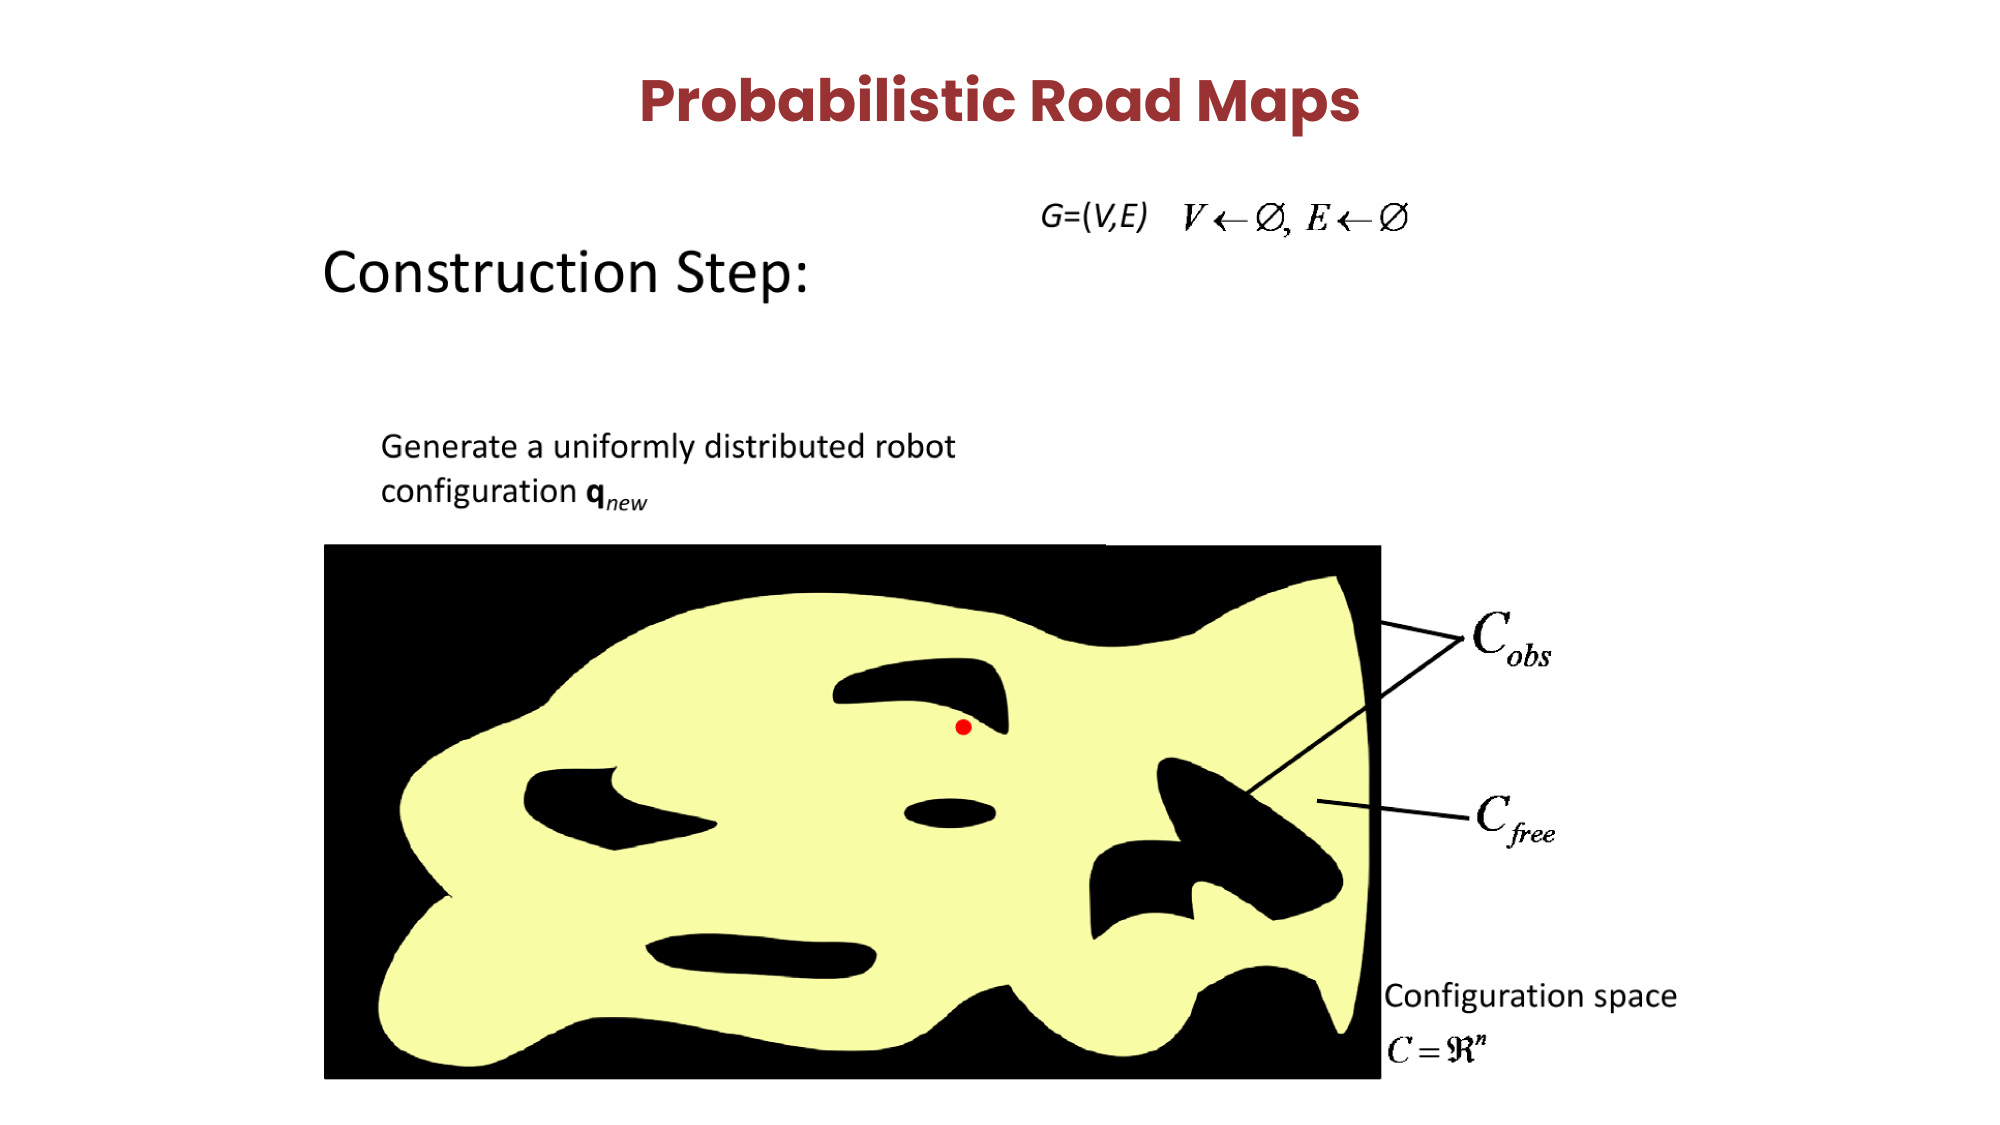
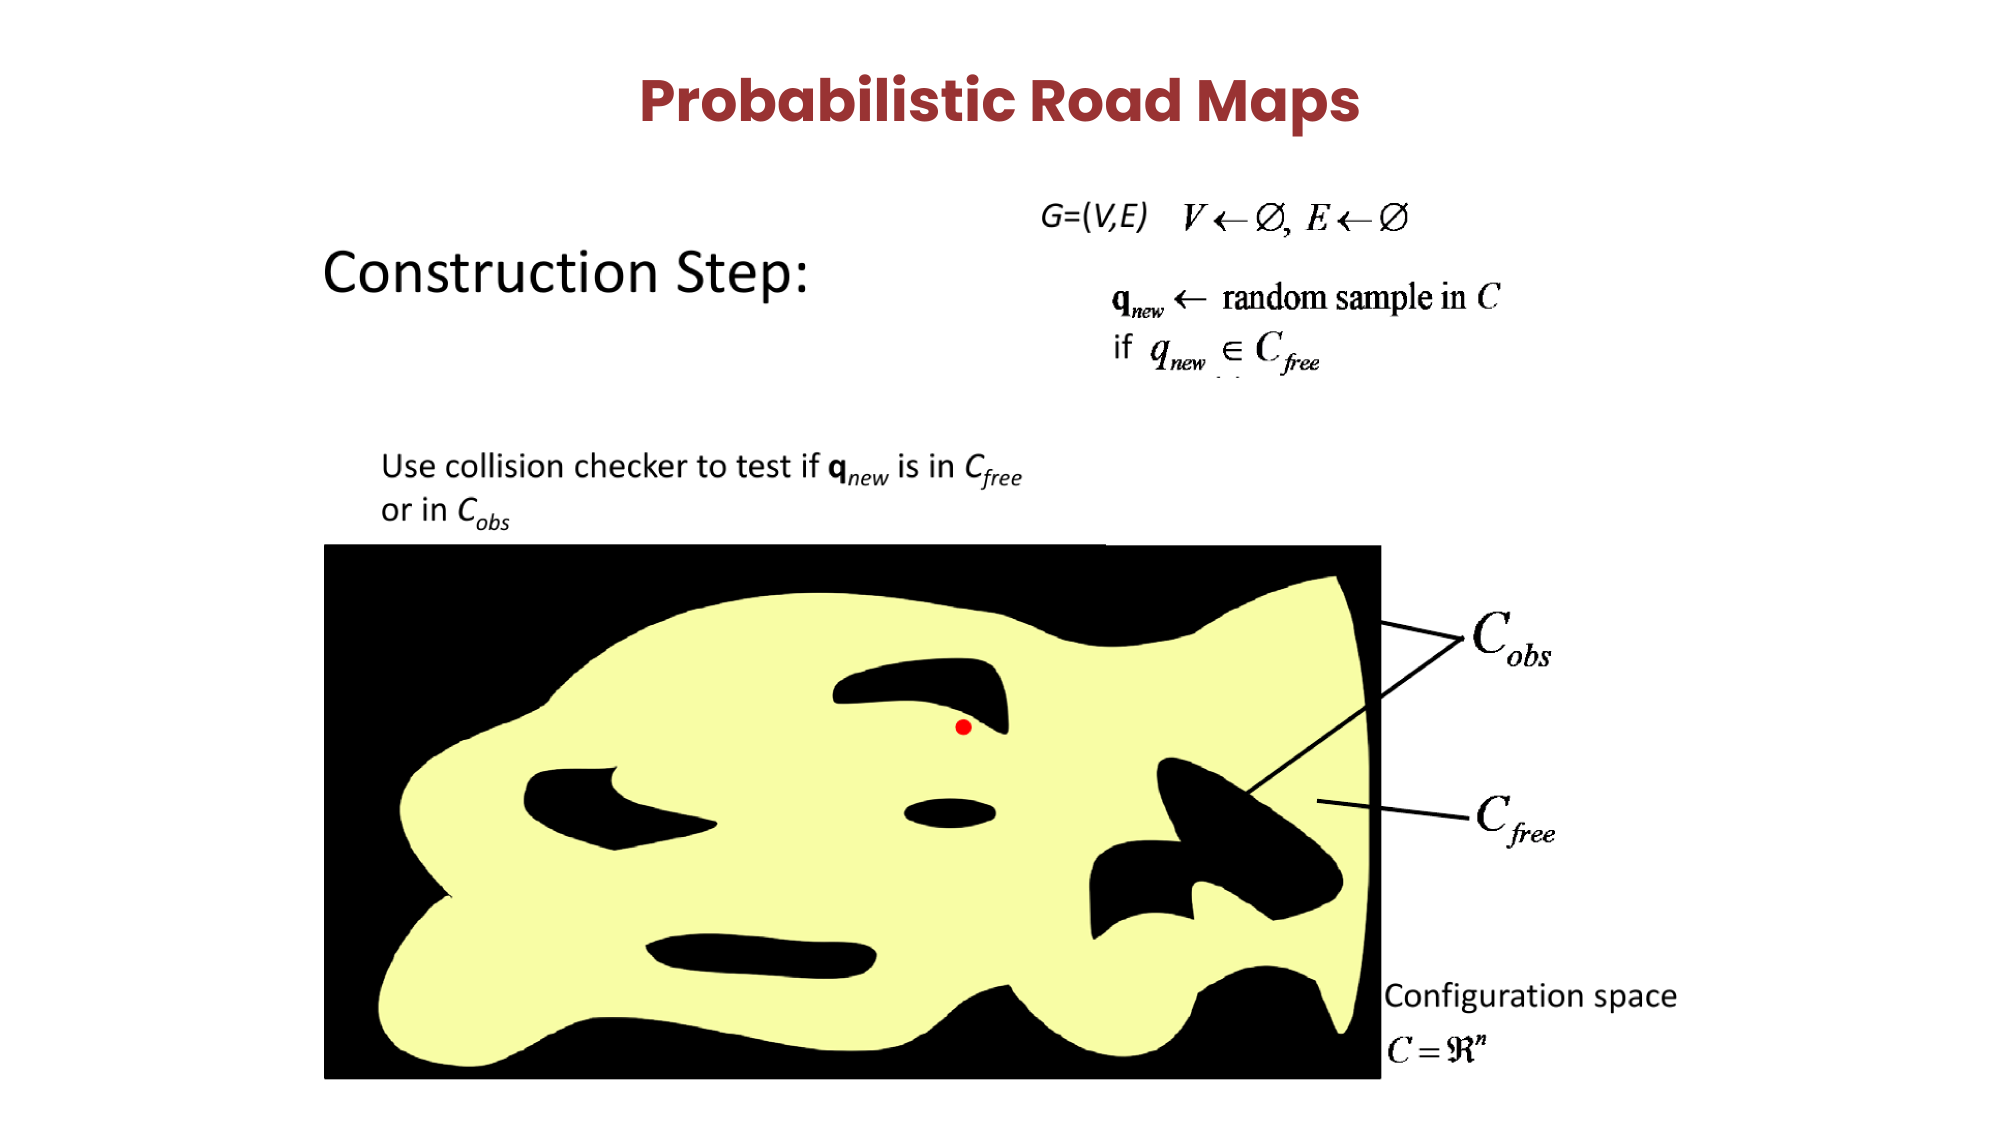
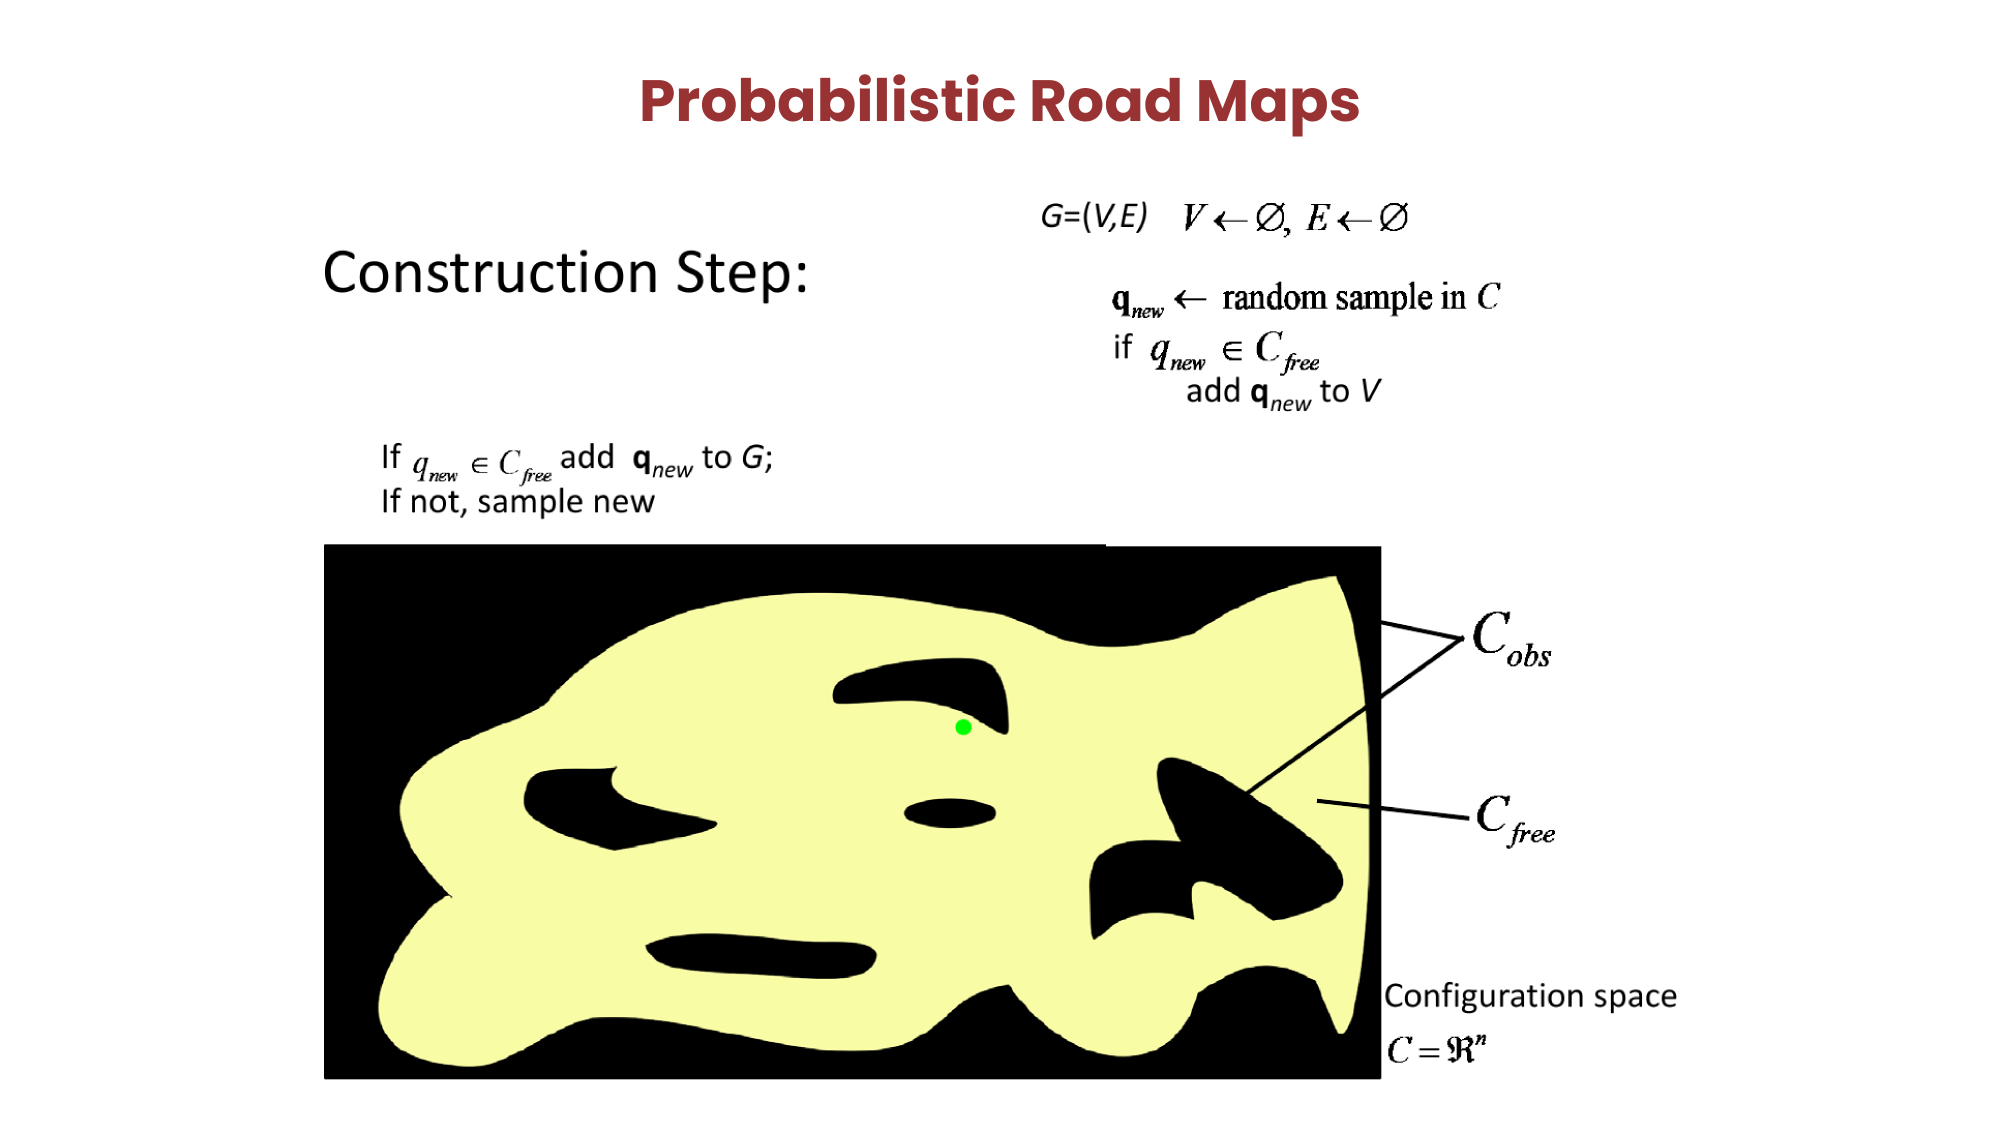
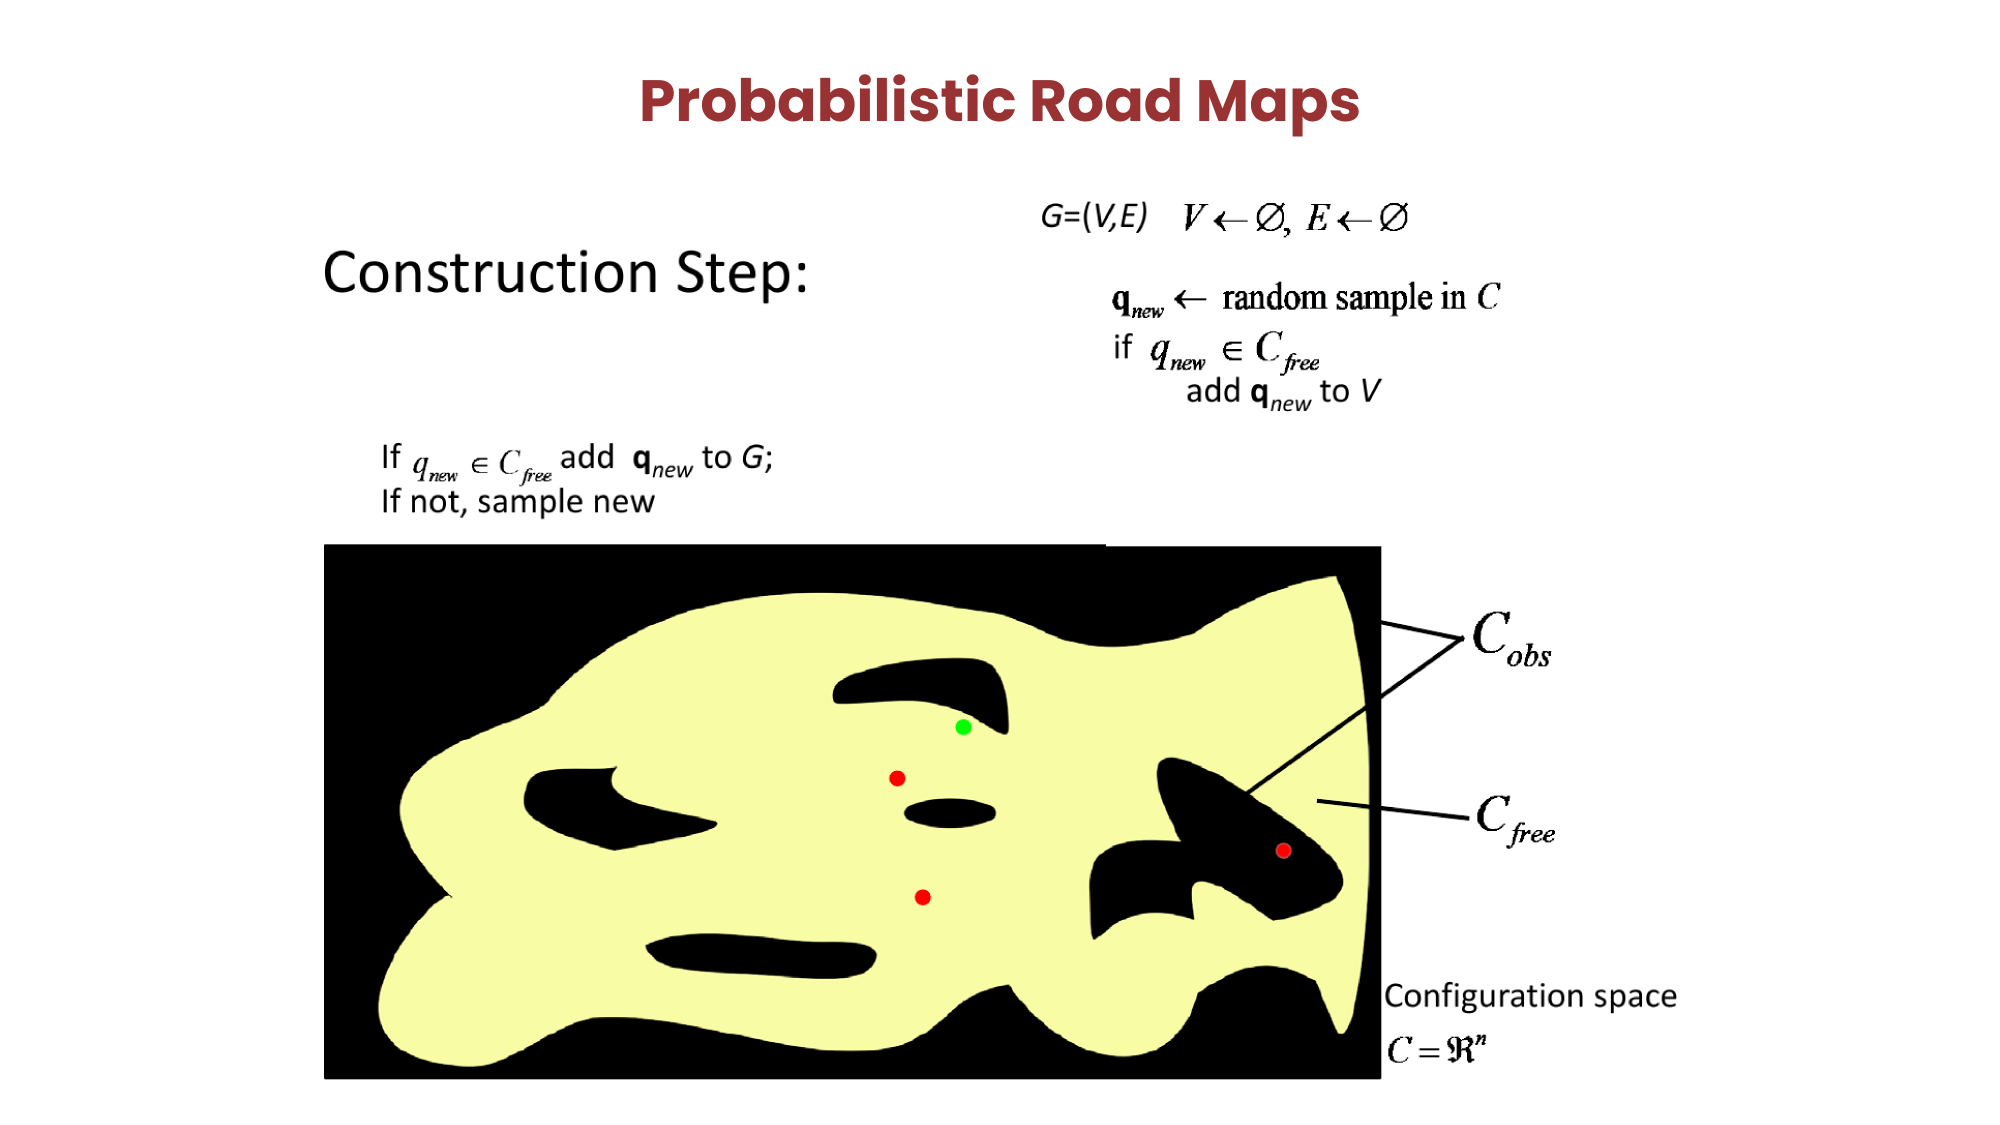
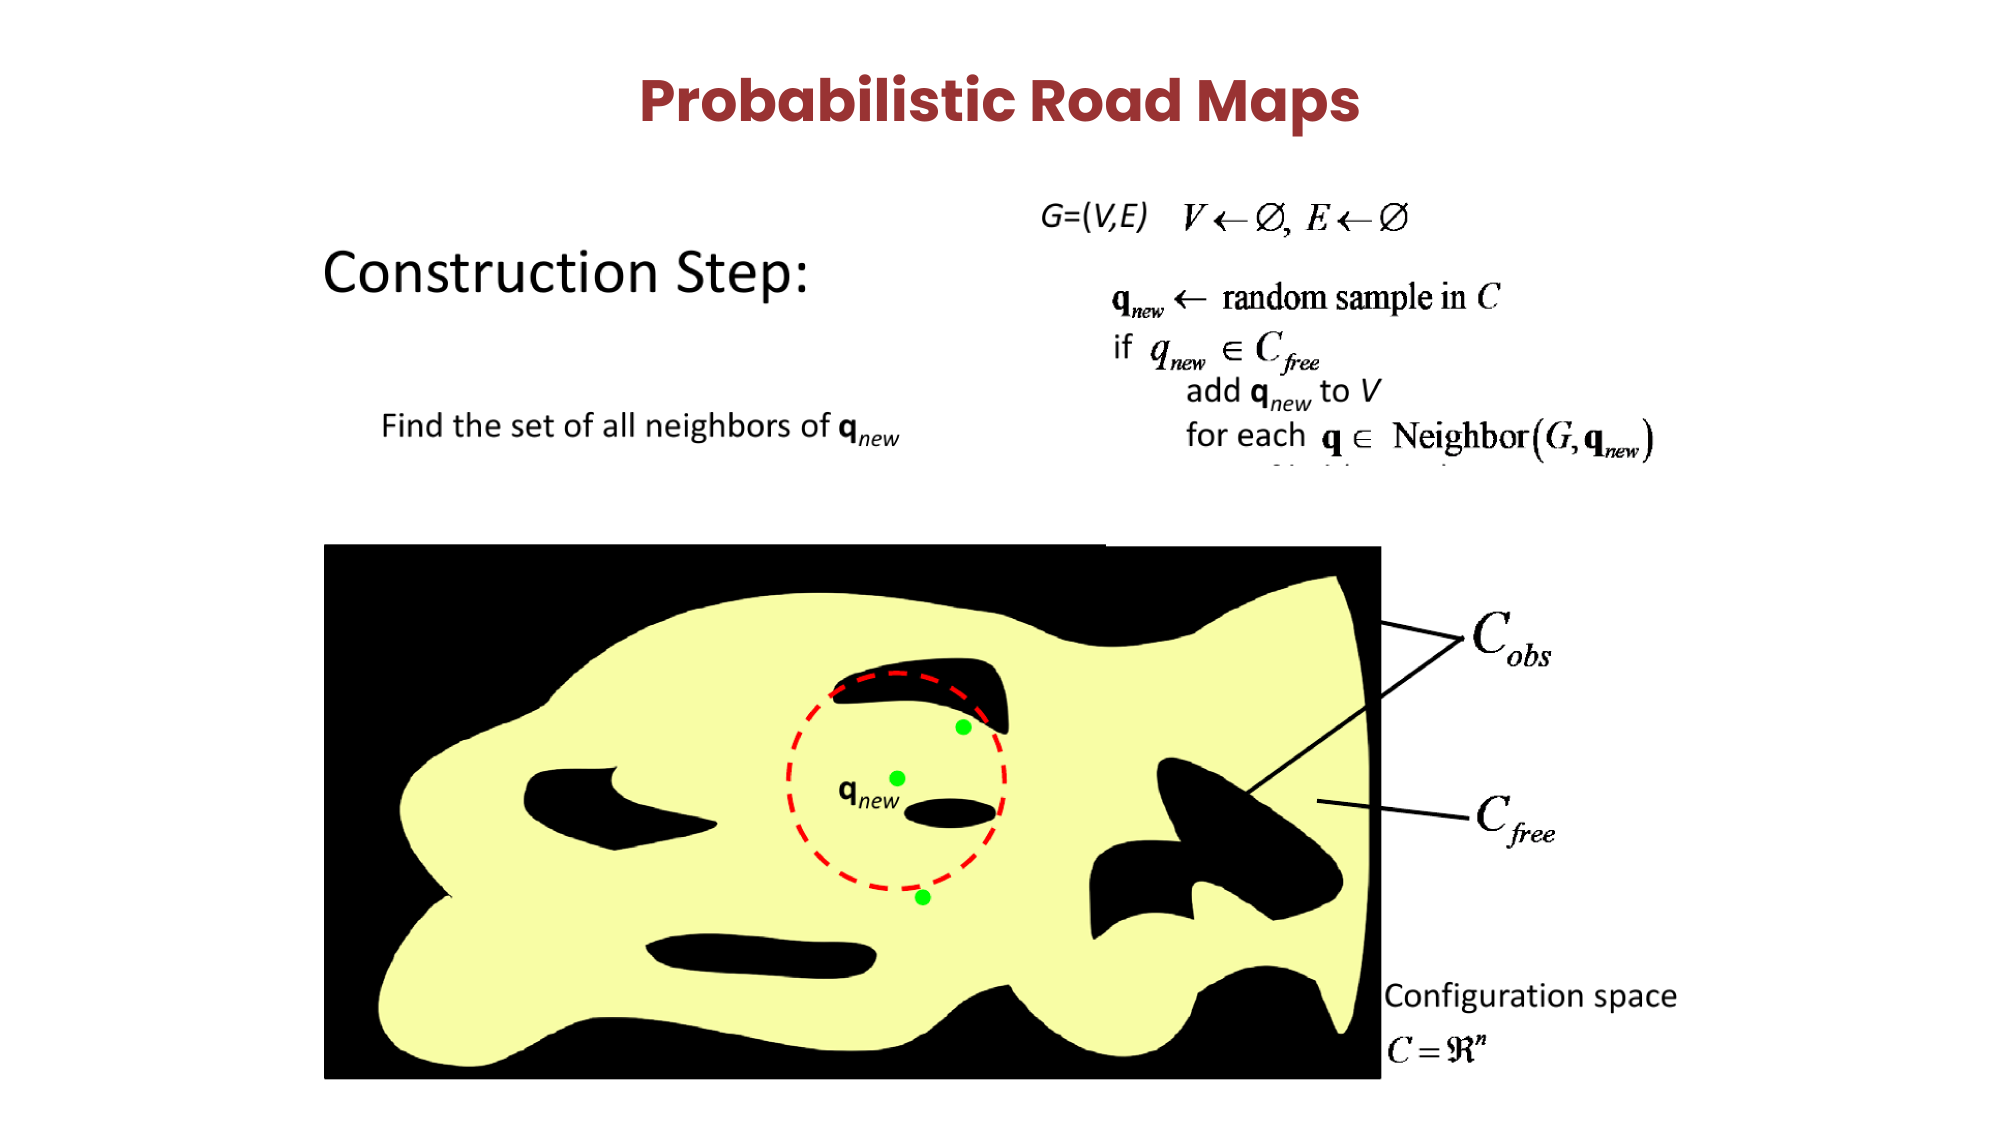
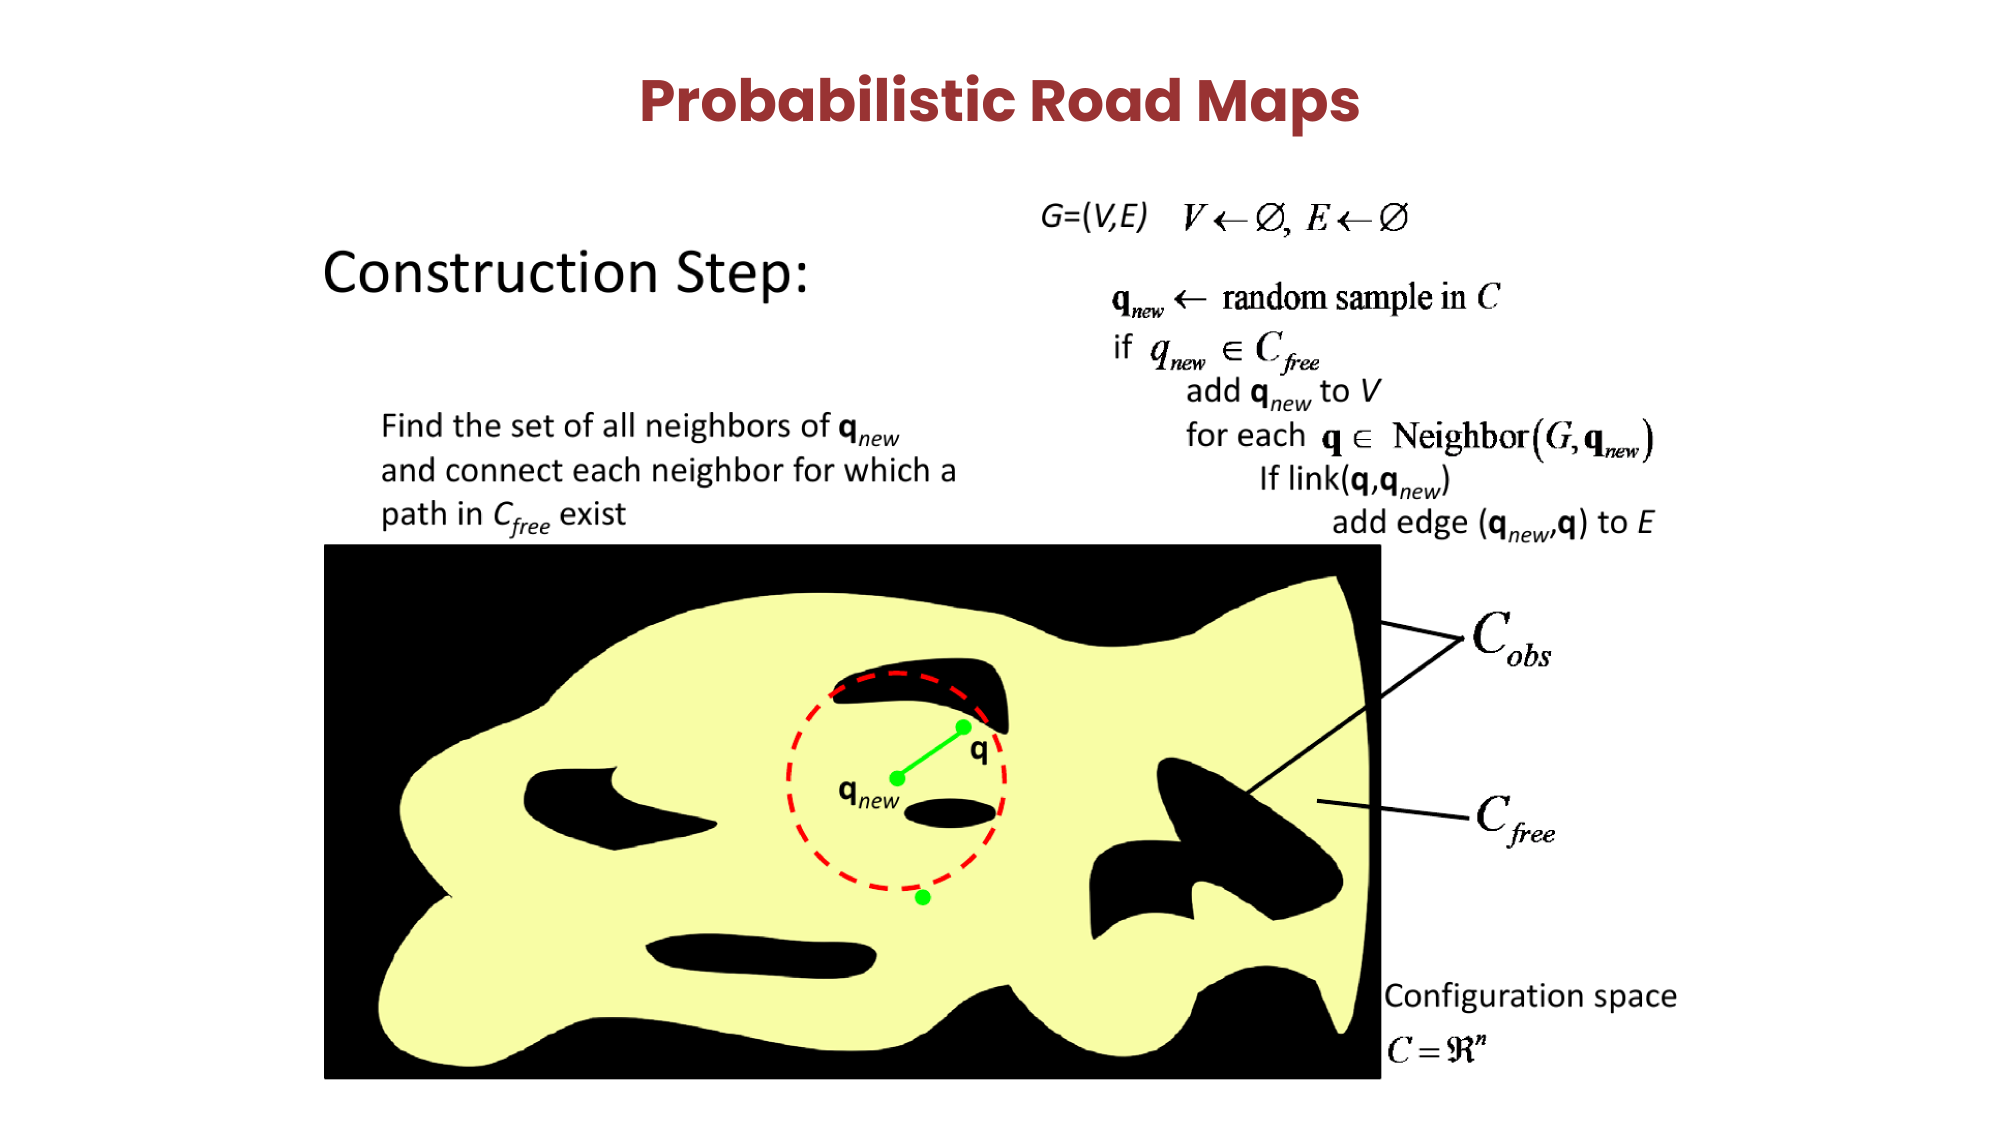
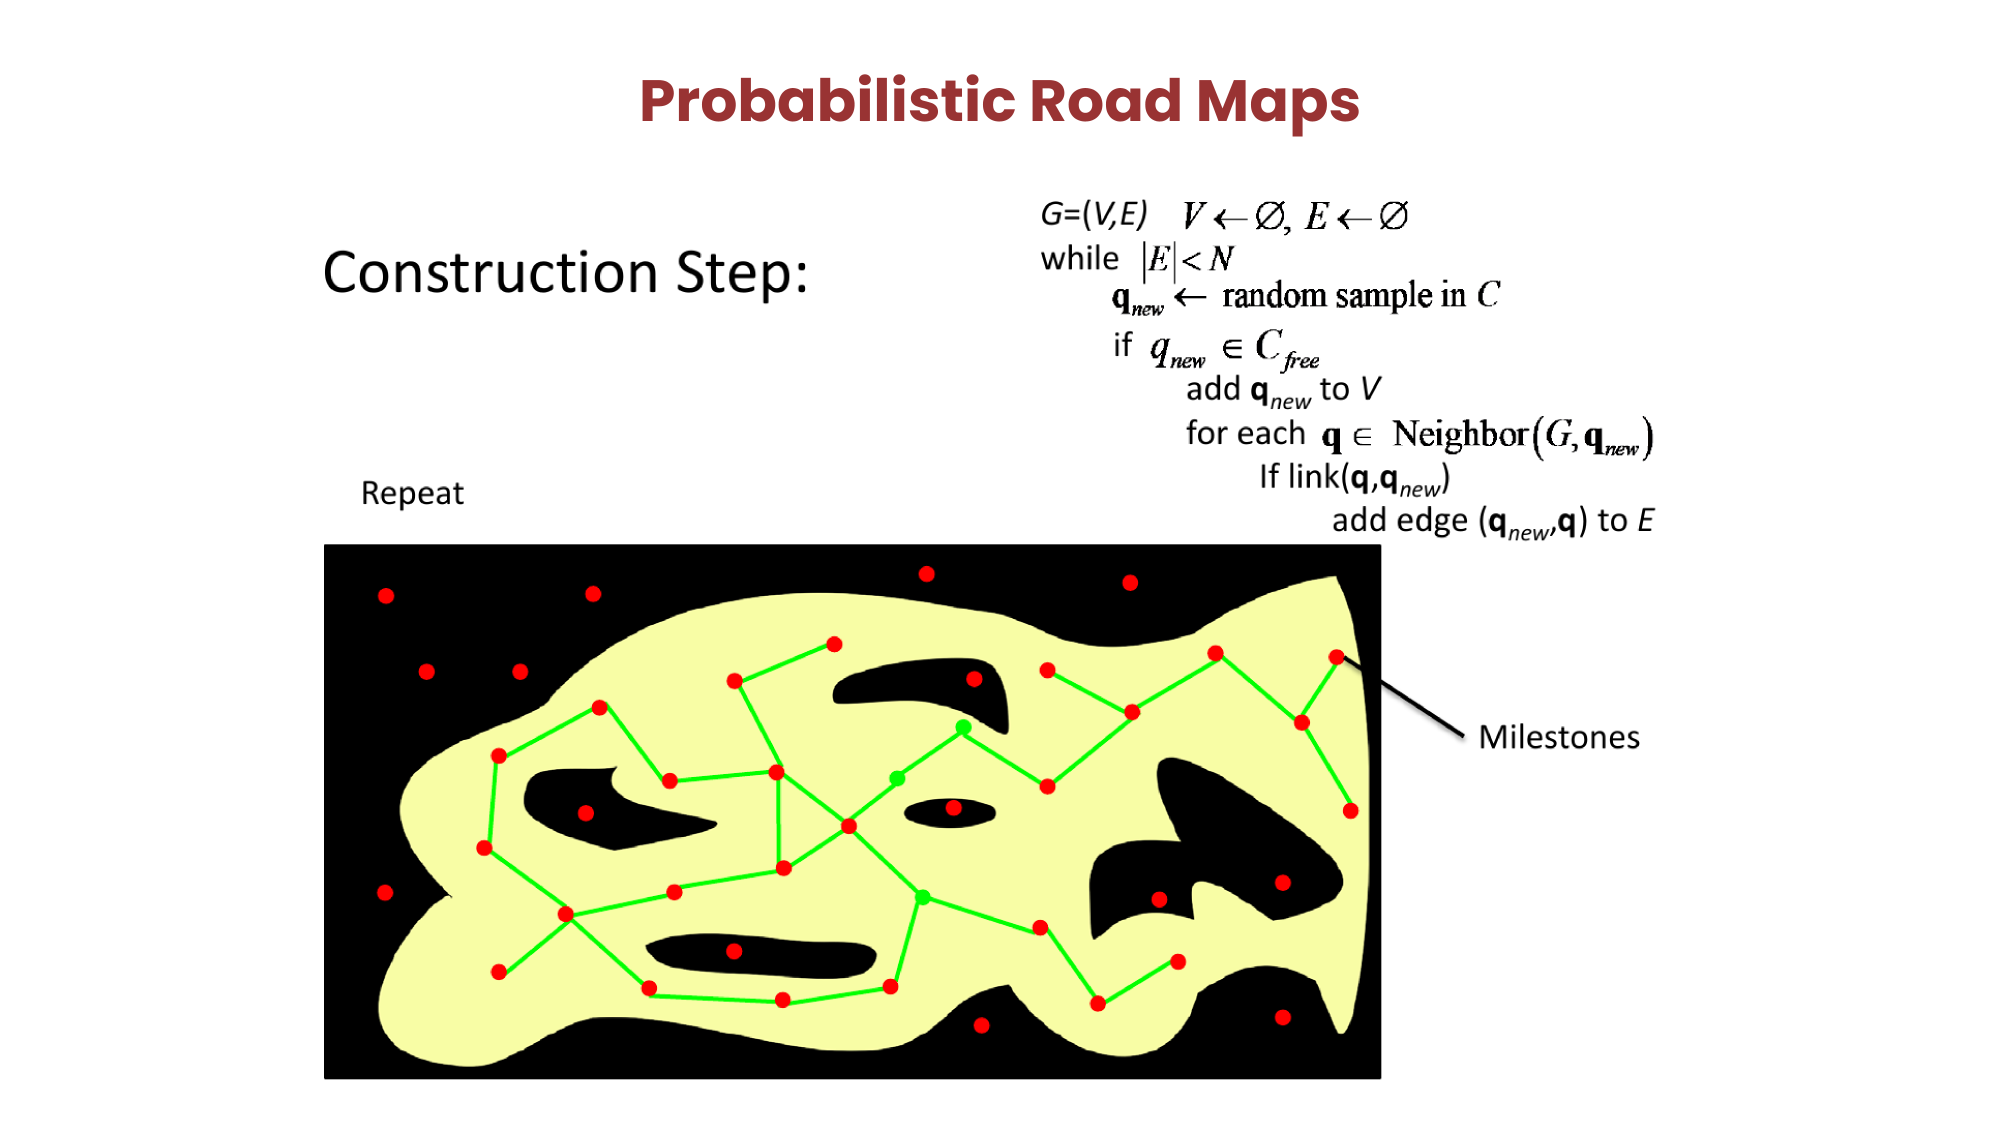
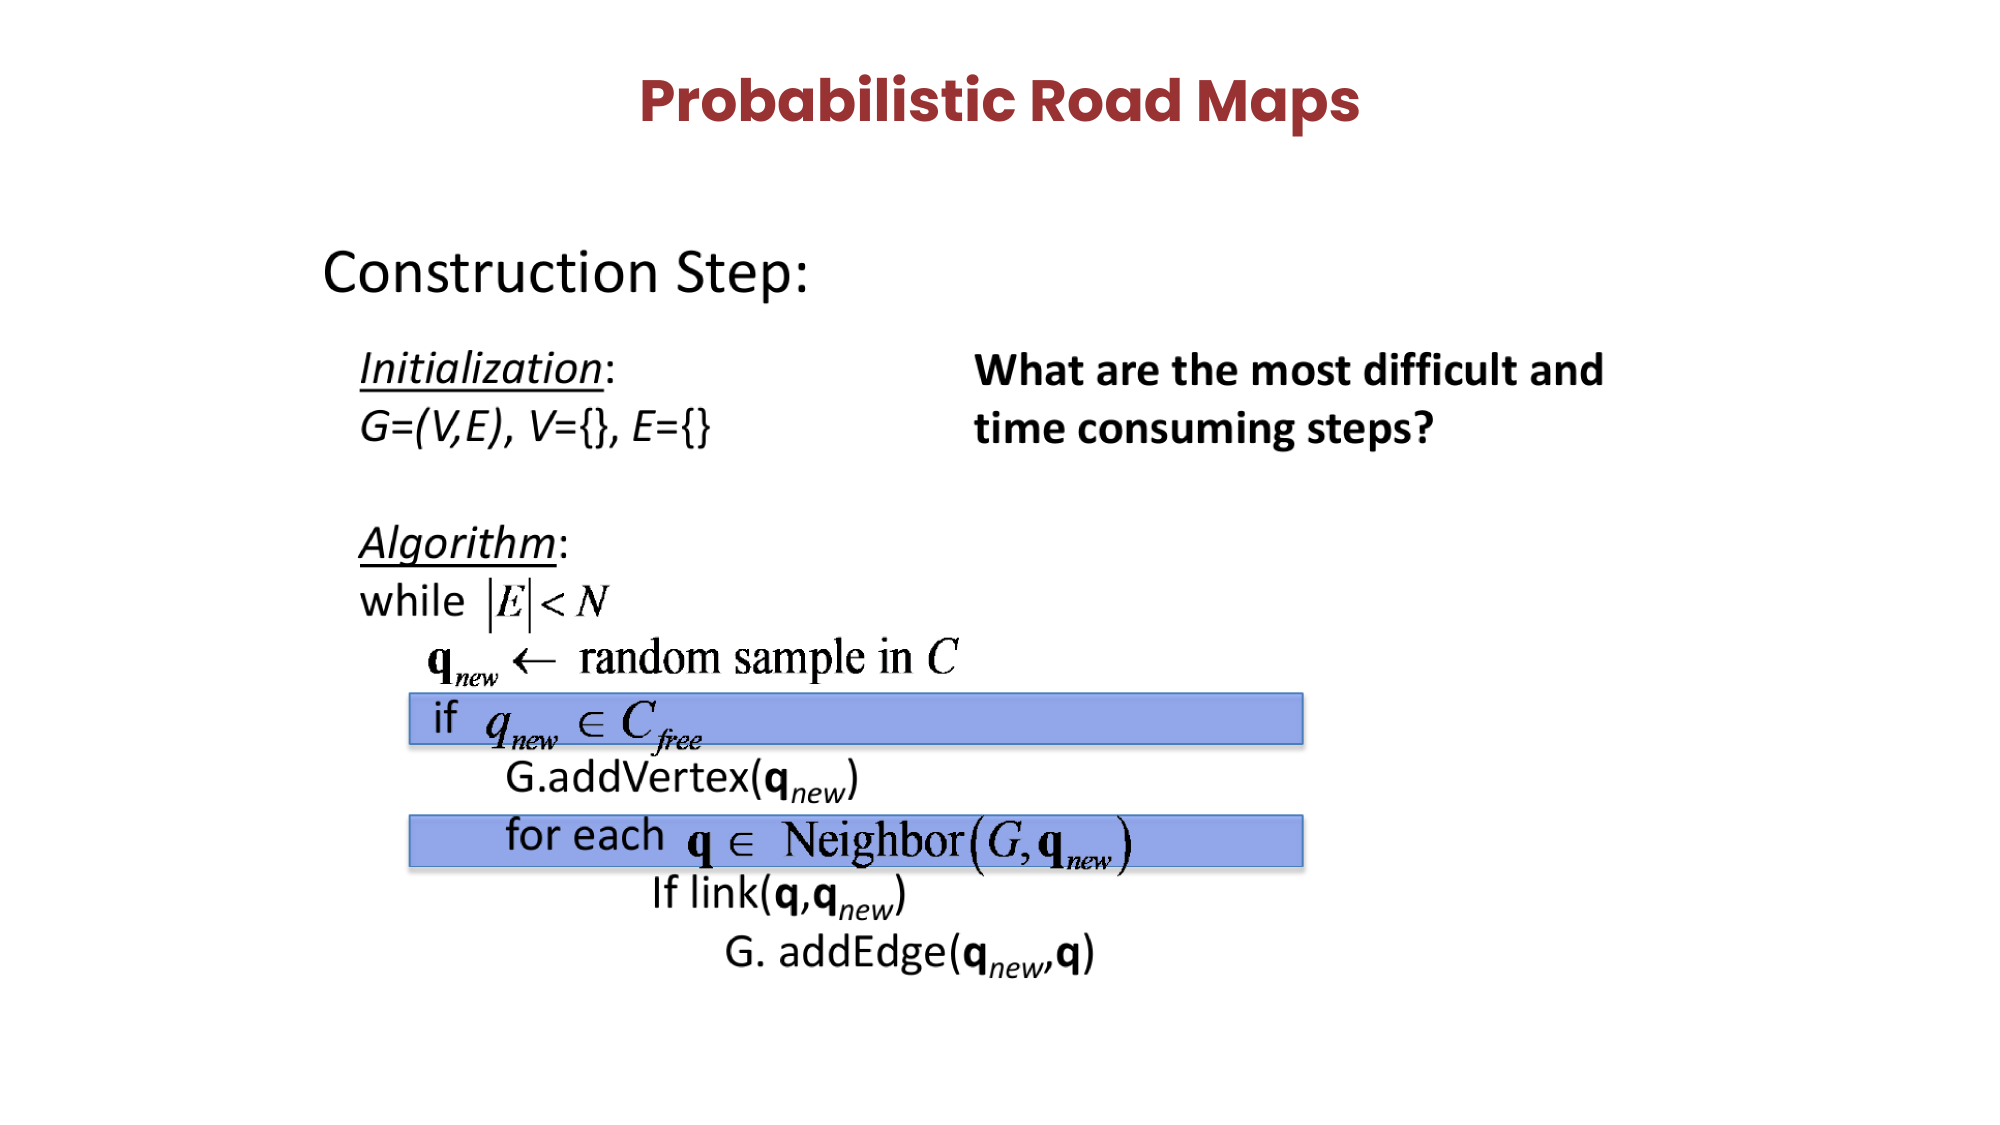
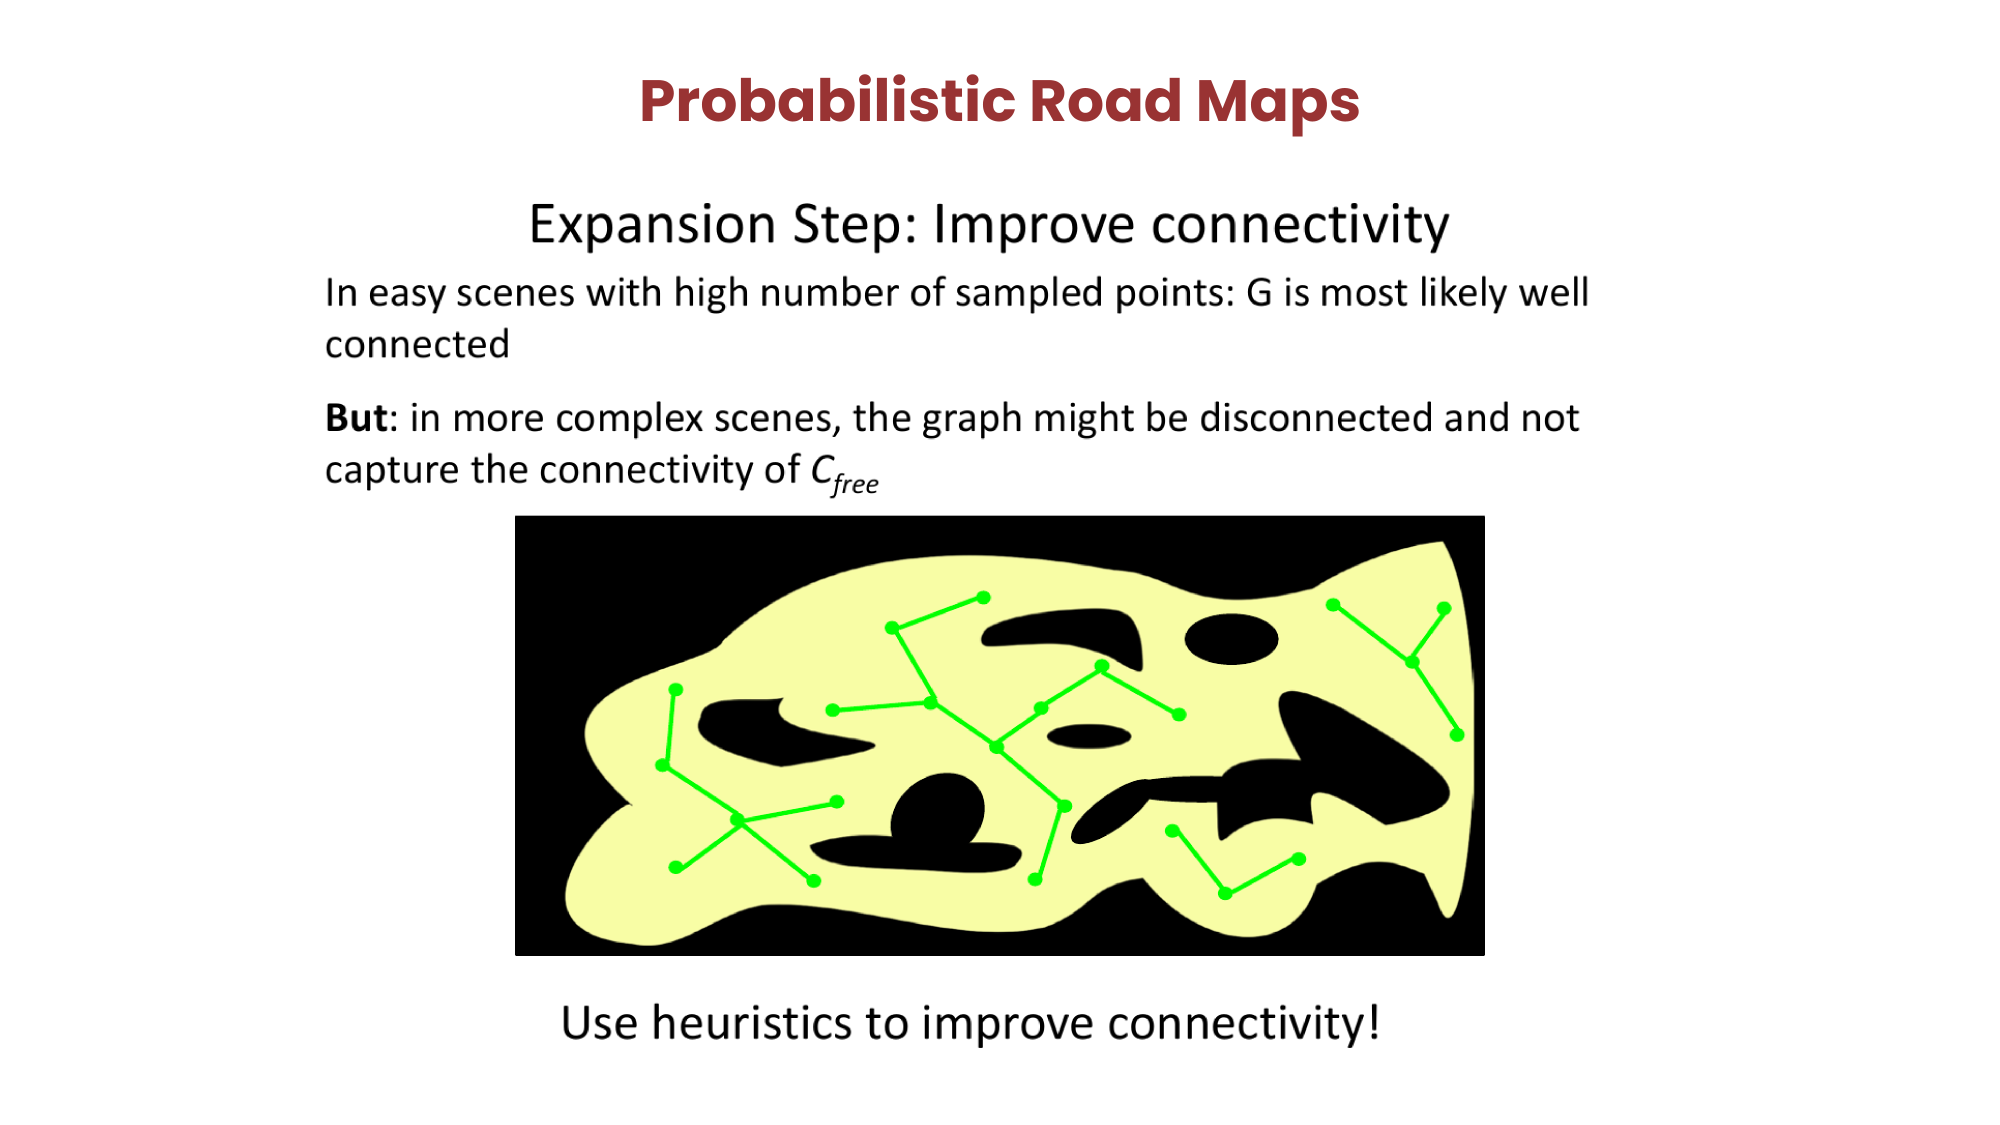
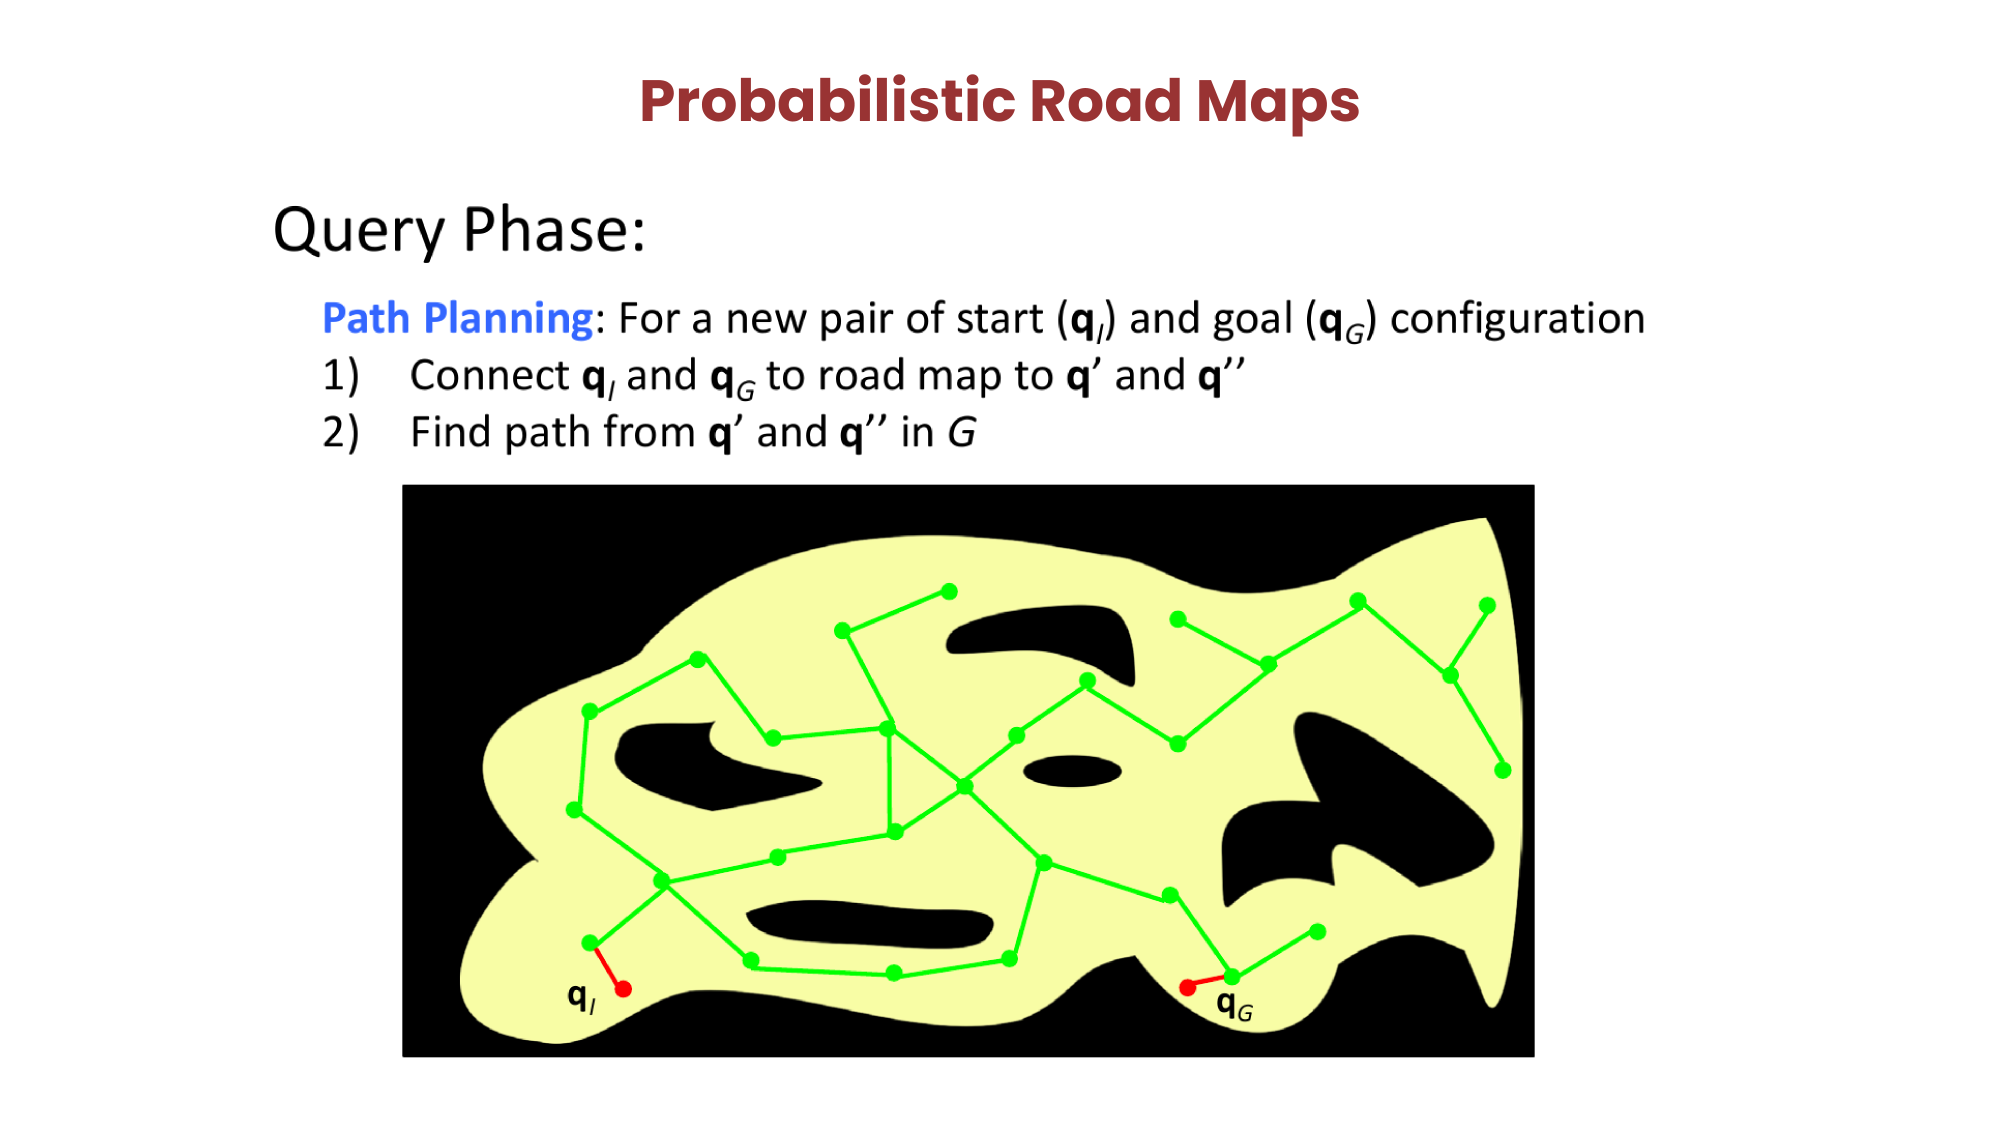
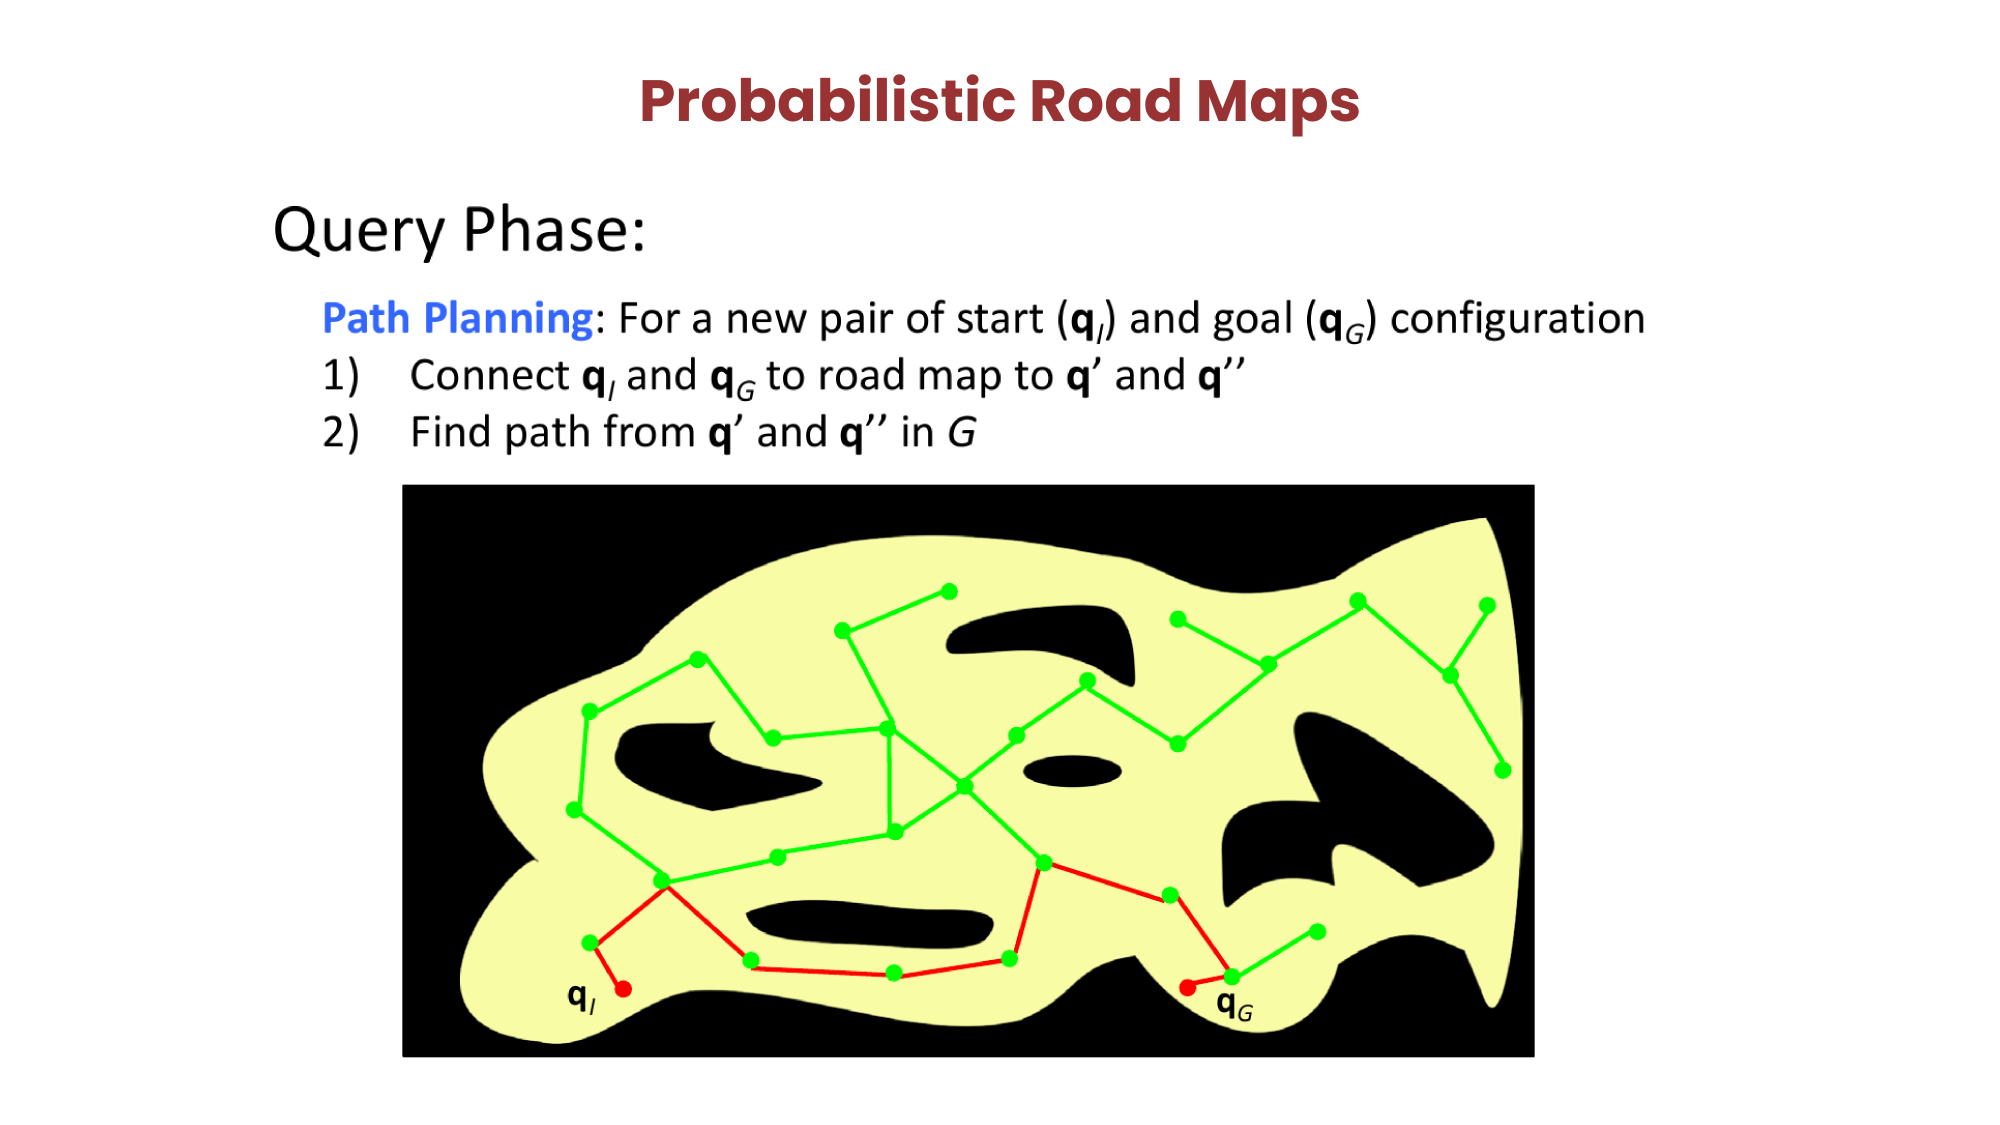
The Probabilistic Roadmap (PRM)
from Choset, Howie M., et al. Principles of robot motion: theory, algorithms, and implementation. MIT press, 2005.
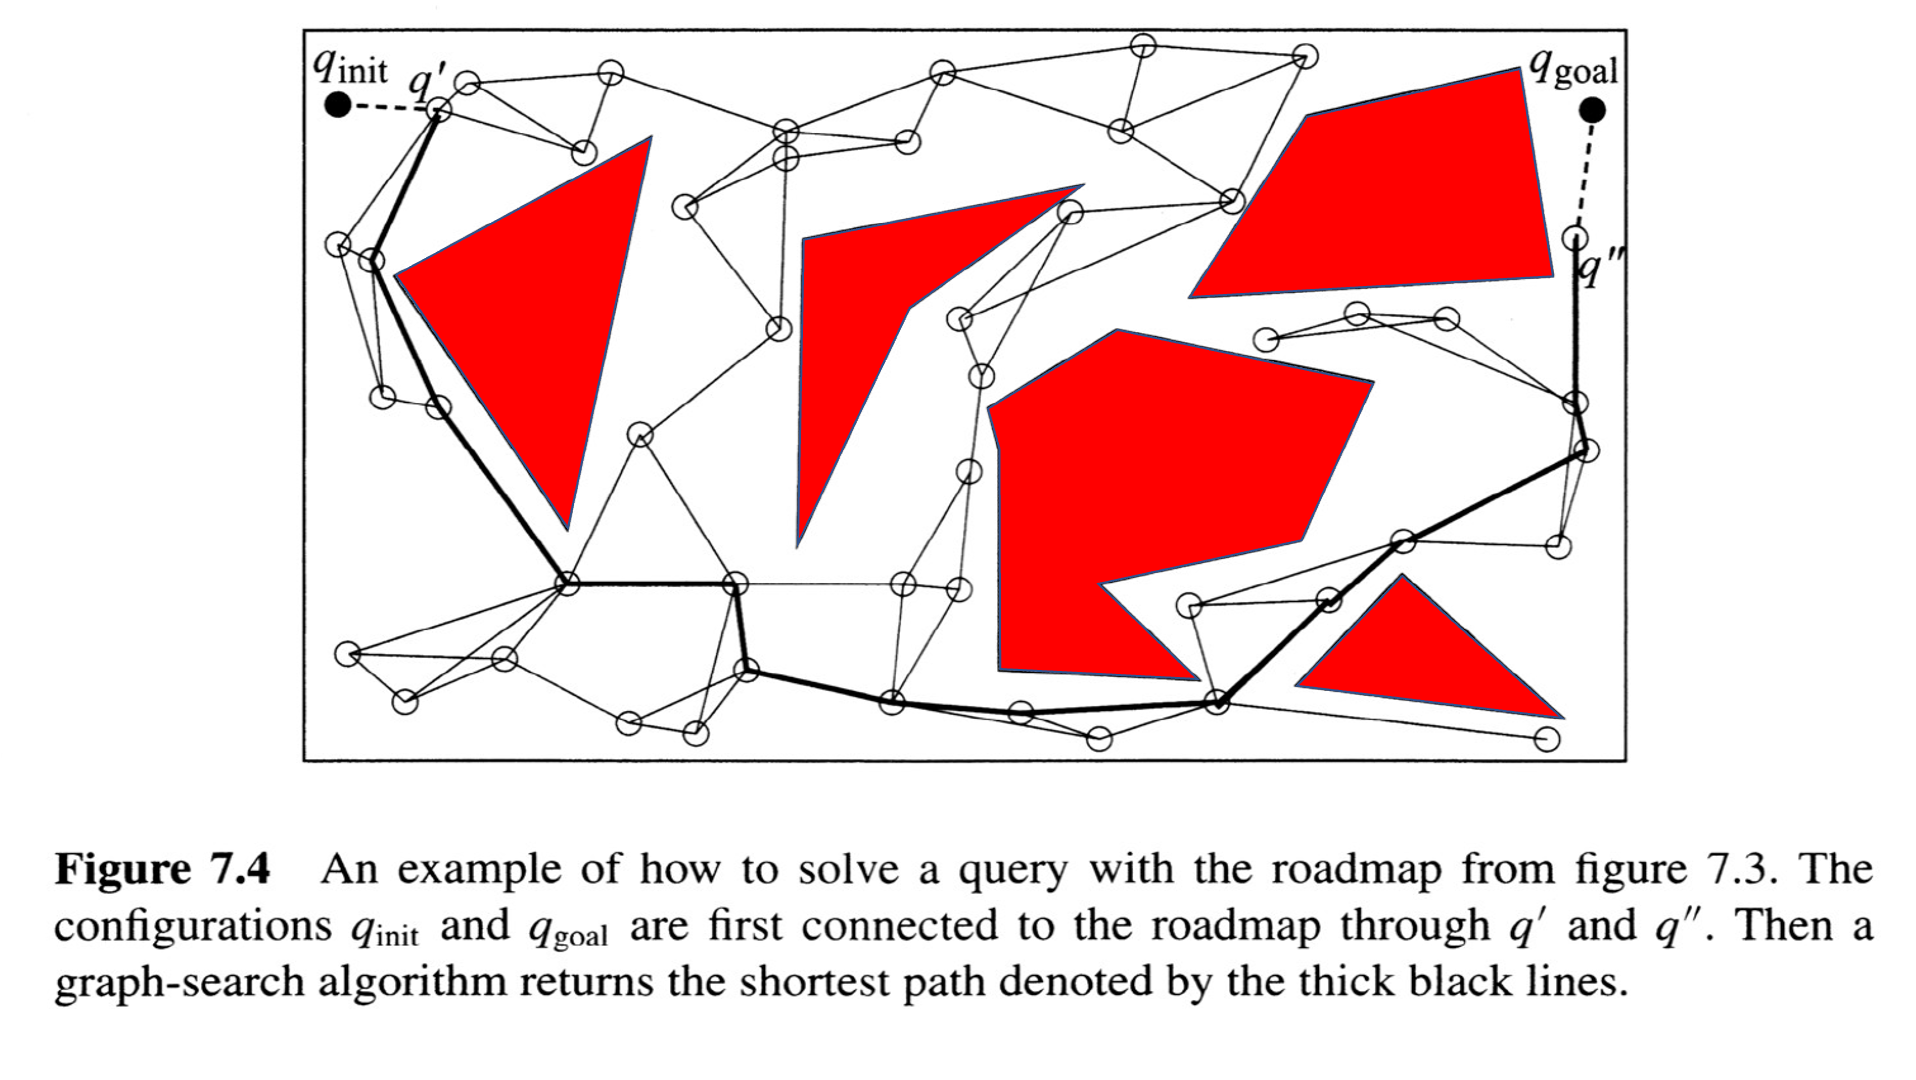
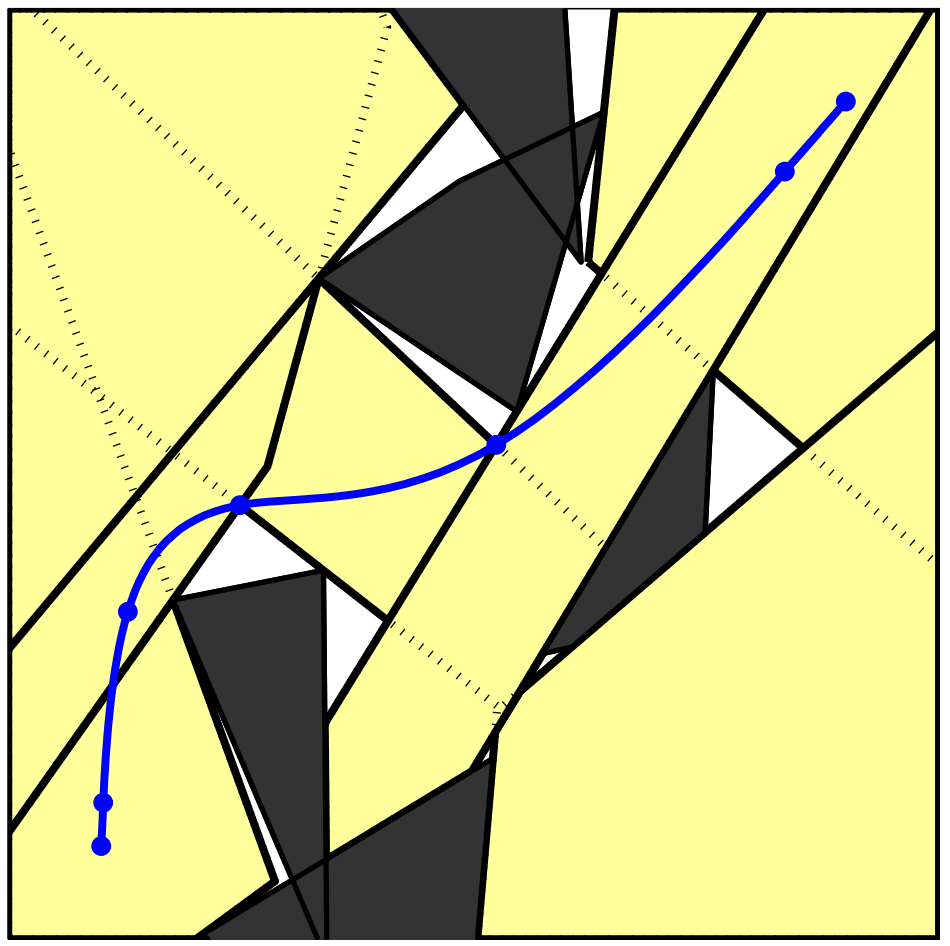
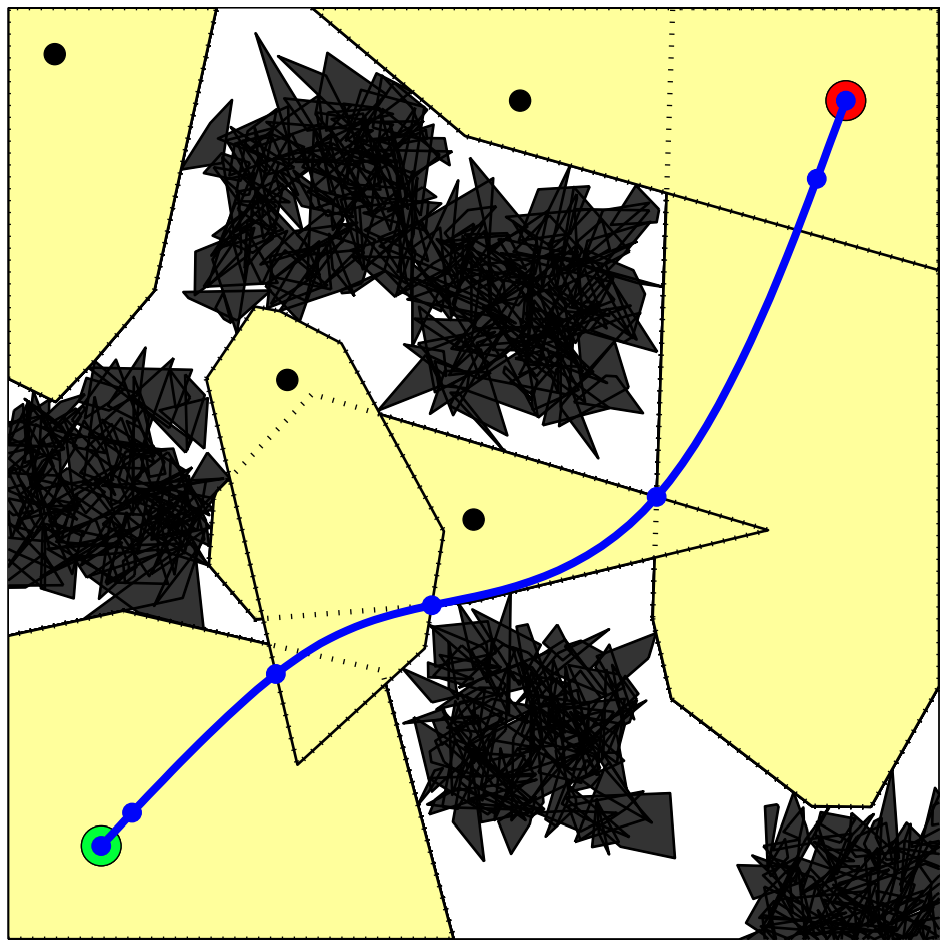
- PRM: A roadmap of points (vertices) connected by line segments
- GCS: A roadmap of convex sets (vertices) of continuous curves connected by continuity constraints
Key ingredients
- (Approximate) convex decomposition of collision-free configuration space. (aka "IRIS")
- Efficient algorithms for solving shortest paths on "Graphs of Convex Sets" (aka "GCS")
- Convex optimization over continuous curves w/ time scaling (\(\Rightarrow\) "GCS Trajectory Optimization")
IRIS for Configuration-space regions
- IRIS (Fast approximate convex segmentation). Deits and Tedrake, 2014
- New versions work in configuration space:
- Nonlinear optimization for speed. IRIS-NP
- Sums-of-squares for rigorous certification. C-IRIS
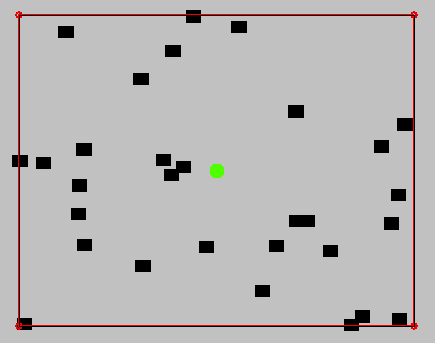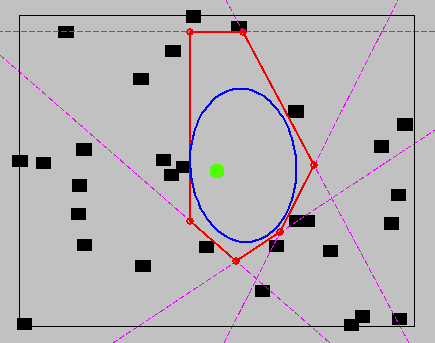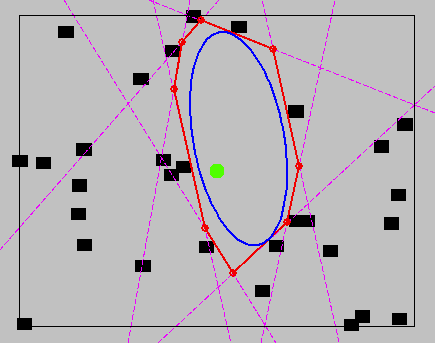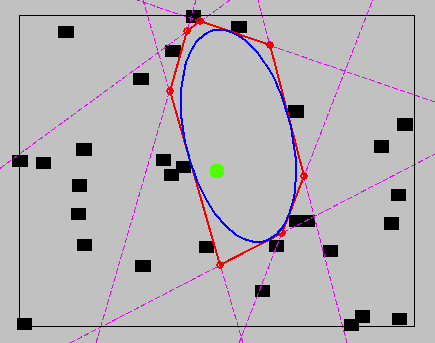
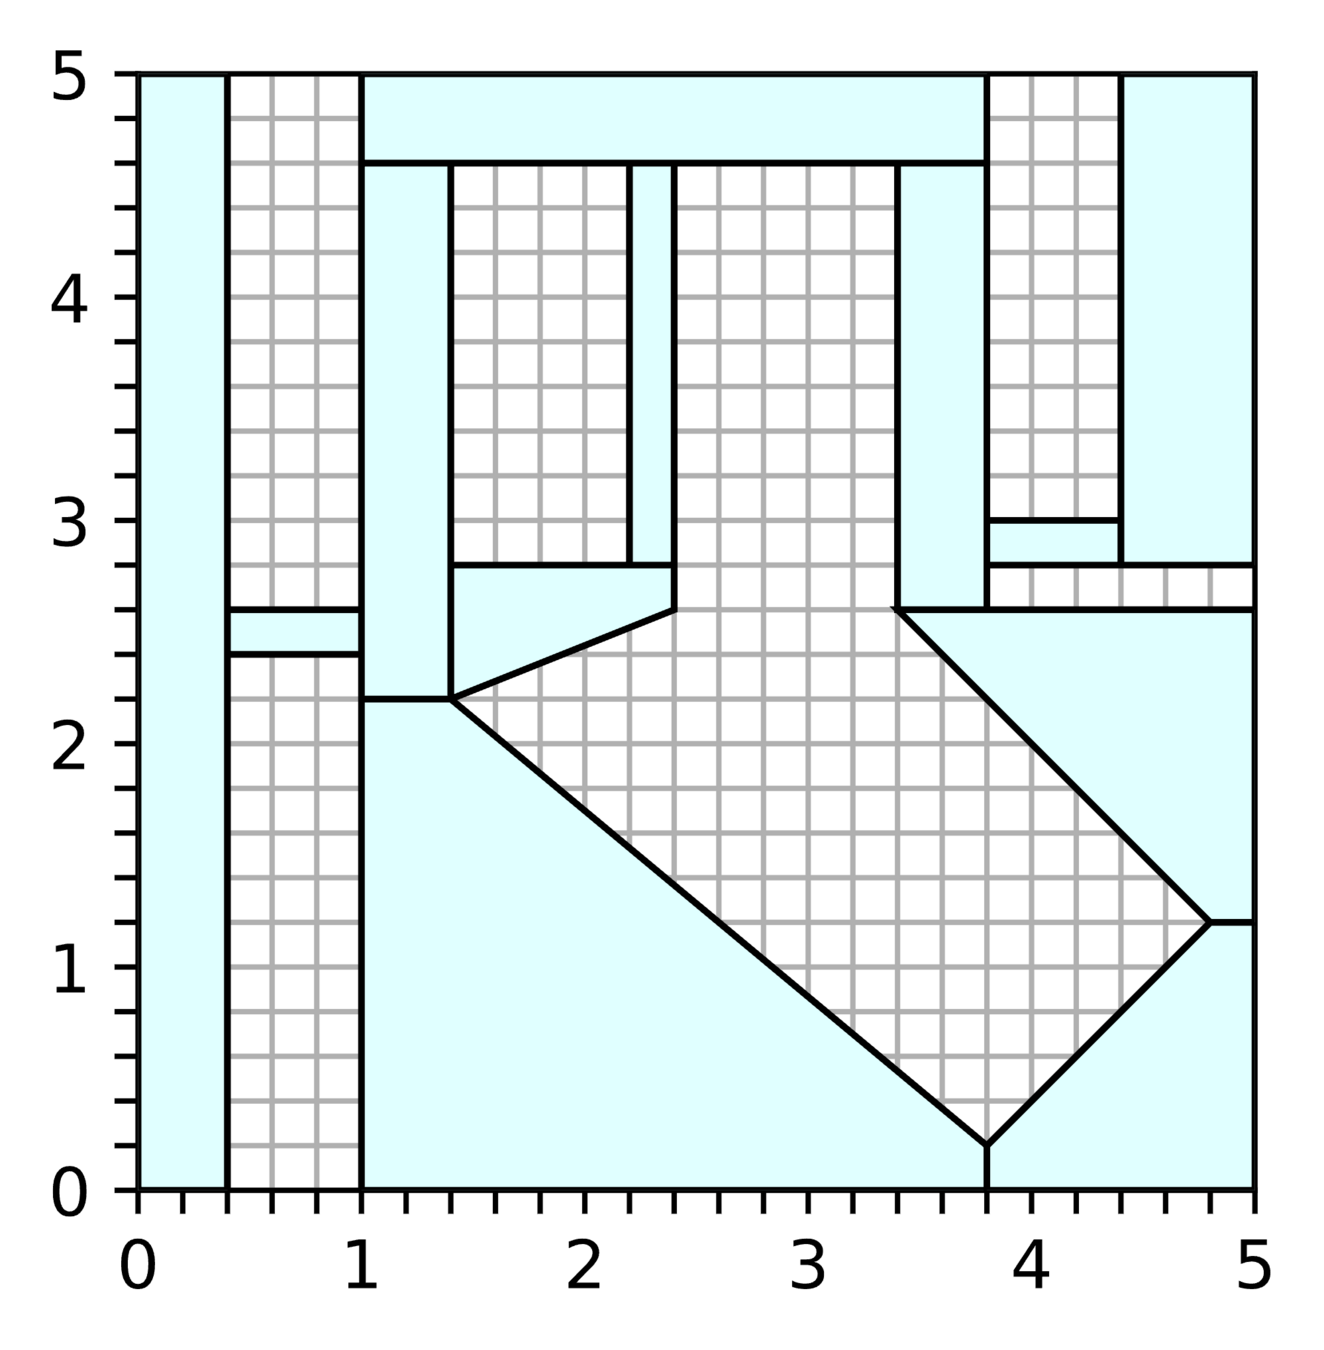
Graphs of Convex Sets


Note: The blue regions are not obstacles.
Graphs of Convex Sets
Mixed-integer formulation with a very tight convex relaxation
- Efficient branch and bound, or
- In practice we only solve the convex relaxation and round
Main idea: Multiply constraints + Perspective function machinery


+ time-rescaling
GCS Trajectory Optimization