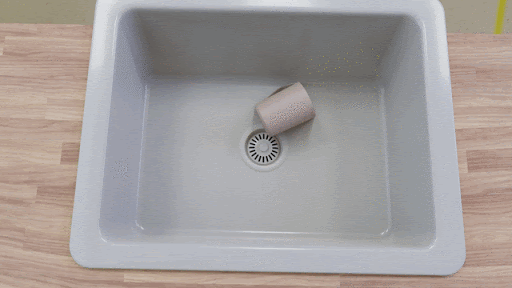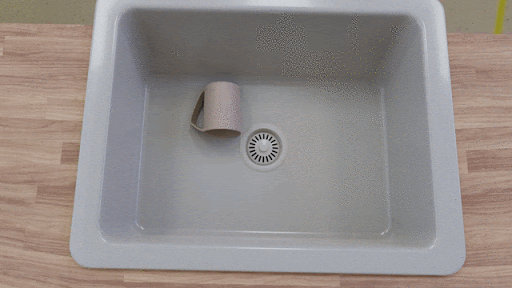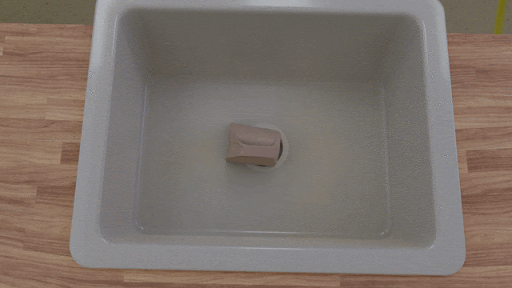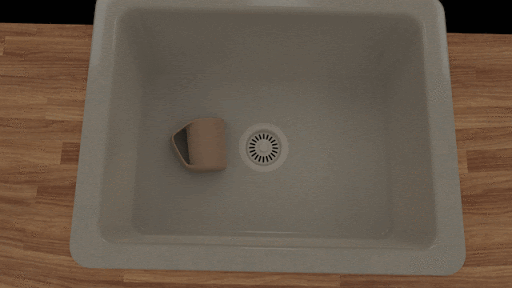
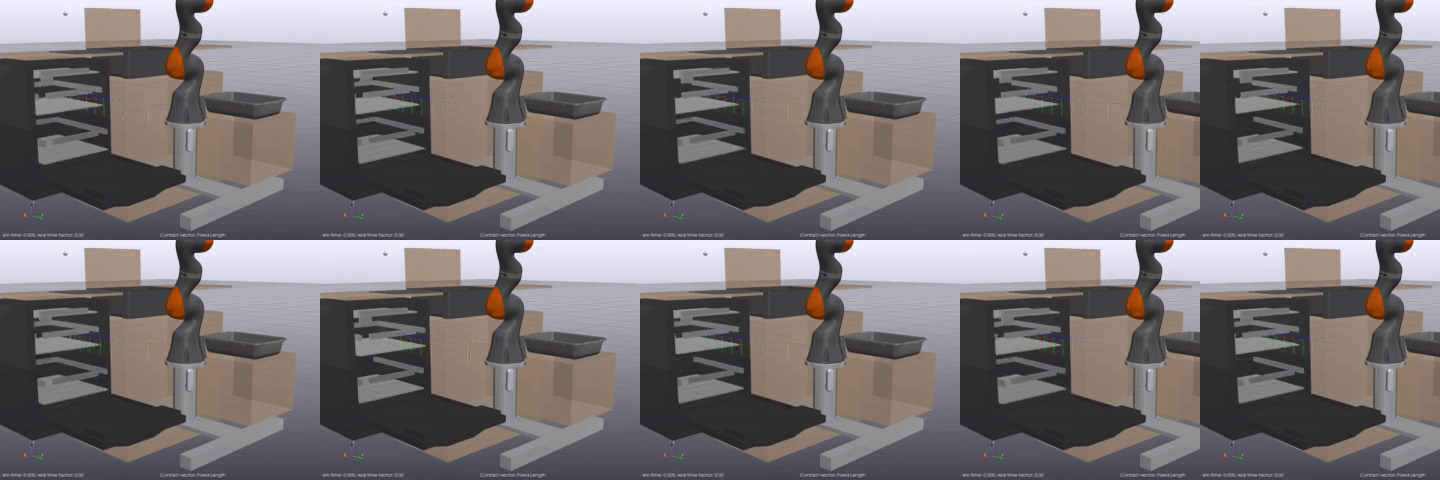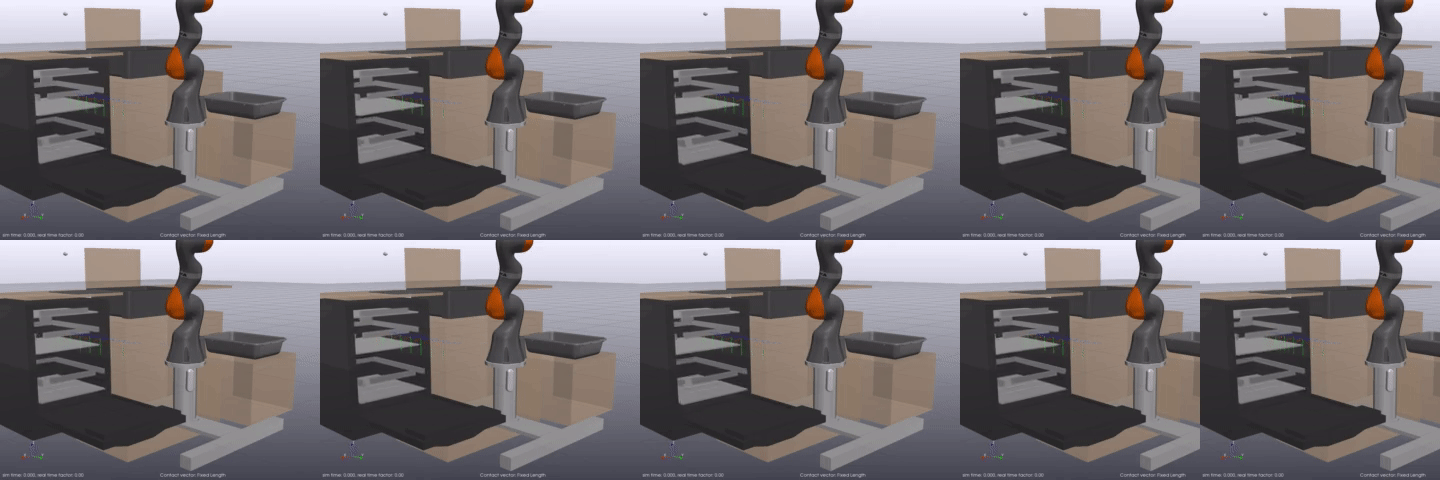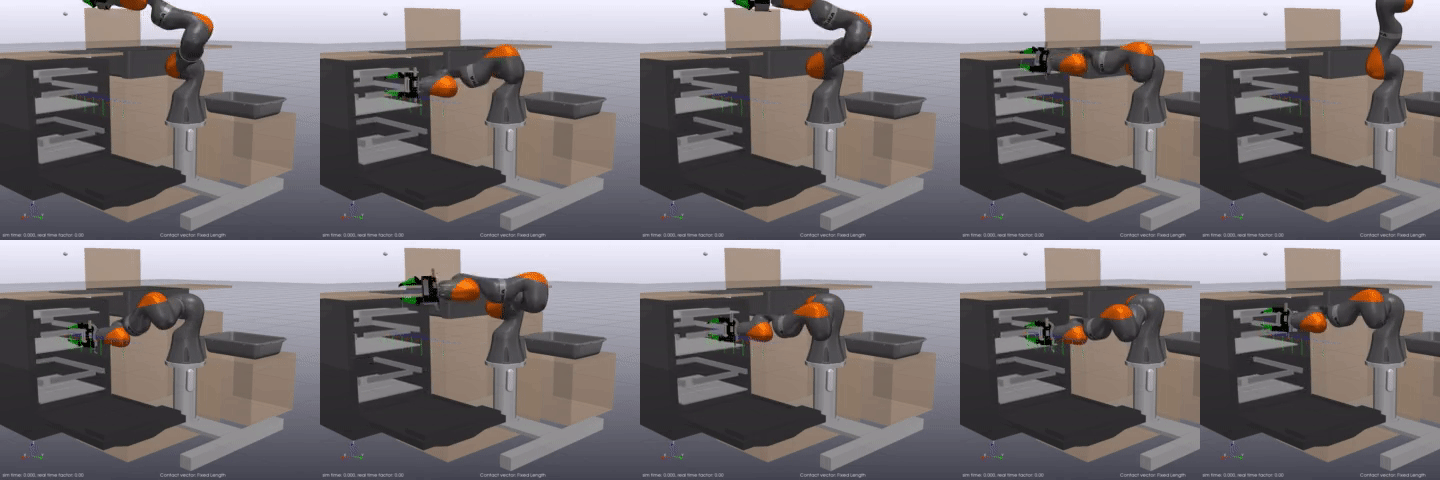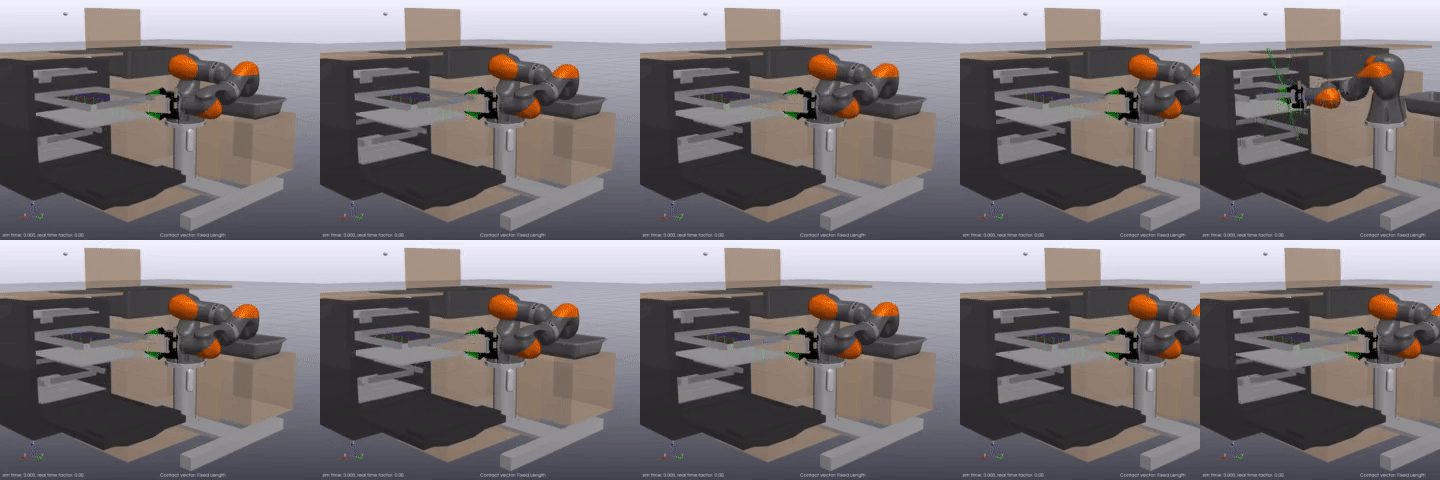
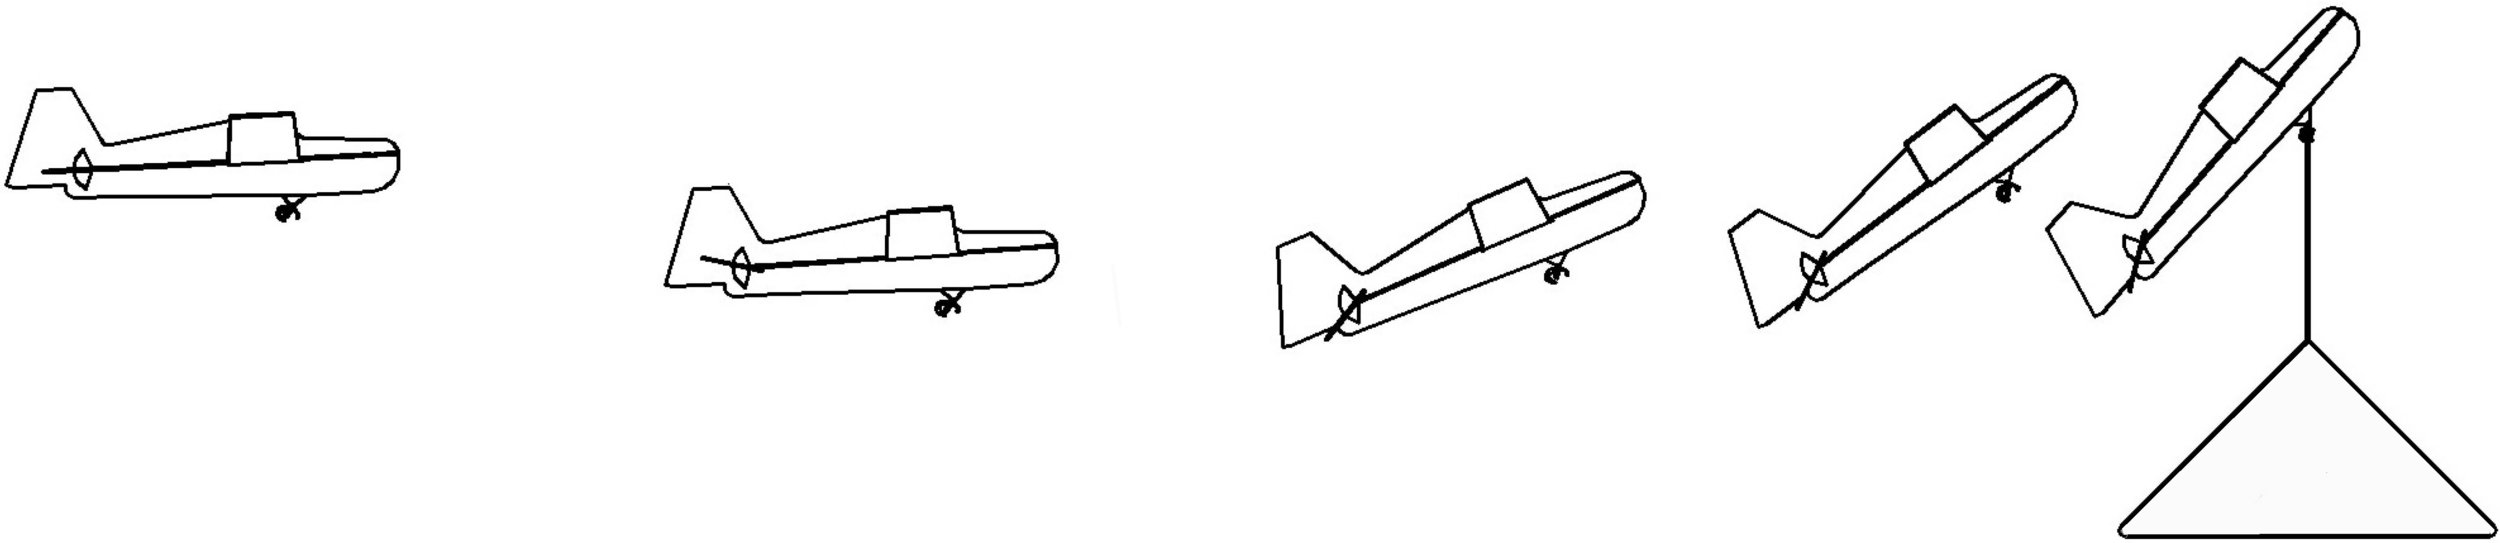
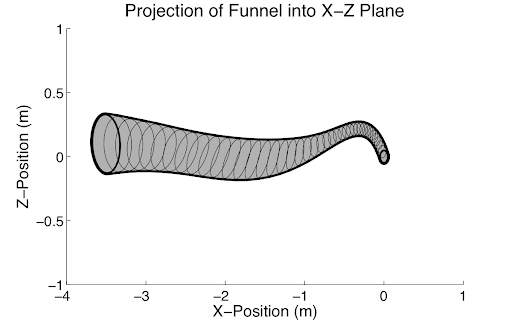
Different views on robustness

Robust Control to Foundation Models

Russ Tedrake

November 6, 2023

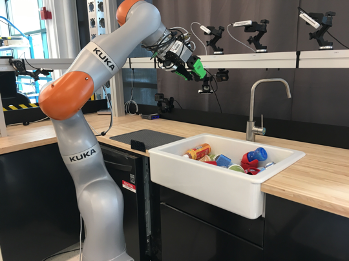
"Dexterous Manipulation" Team

(founded in 2016)

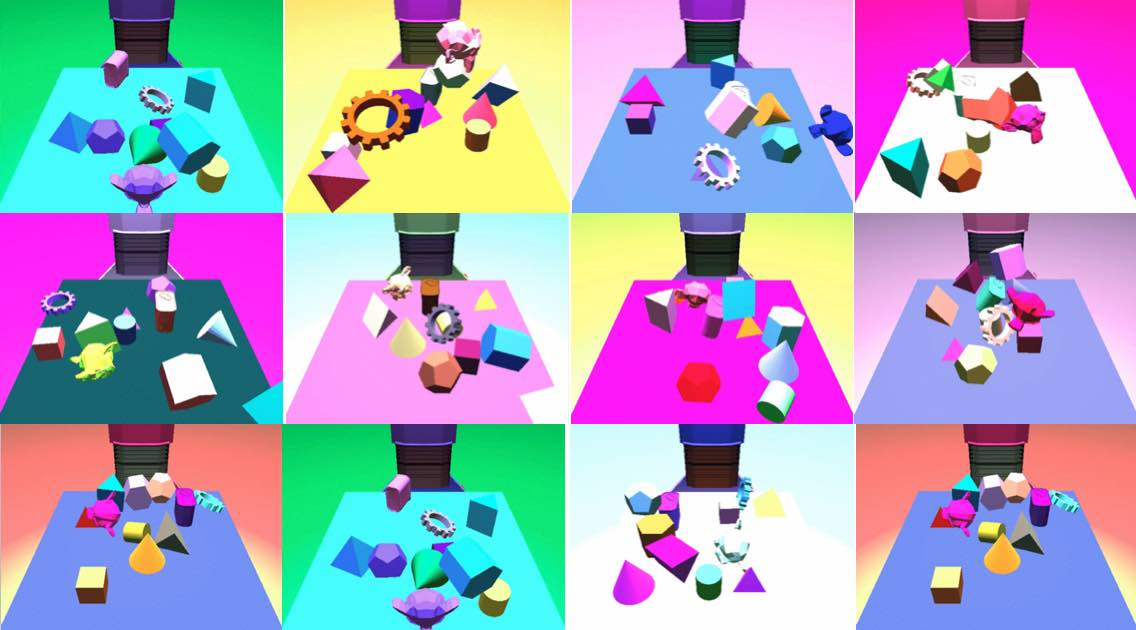
Distributions over manipulation scenarios

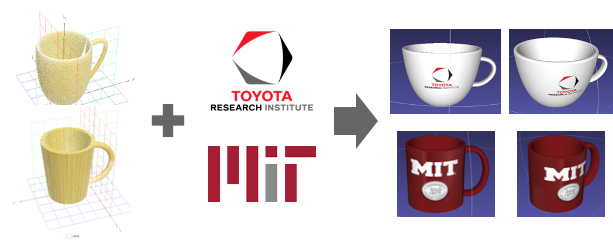
  • Parameterized procedural mugs, even vegetables!
  • Parameterized environments (lighting conditions, etc), ...

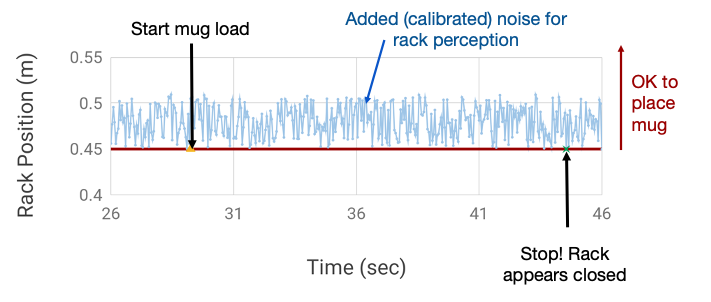
Finding subtle bugs w/ Monte-Carlo testing

For the next challenge:

Good control when we don't have useful models?

For the next challenge:

Good control when we don't have useful models?

  • Rules out:
    • (Multibody) Simulation
    • Simulation-based reinforcement learning (RL)
    • State estimation / model-based control
  • My top choices:
    • Learn a dynamics model
    • Behavior cloning (imitation learning)

I was forced to reflect on my core beliefs...

  • The value of using RGB (at control rates) as a sensor is undeniable.  I must not ignore this going forward.
     
  • I don't love imitation learning (decision making \(\gg\) mimcry), but it's an awfully clever way to explore the space of policy representations
    • Don't need a model
    • Don't need an explicit state representation
      • (Not even to specify the objective!)

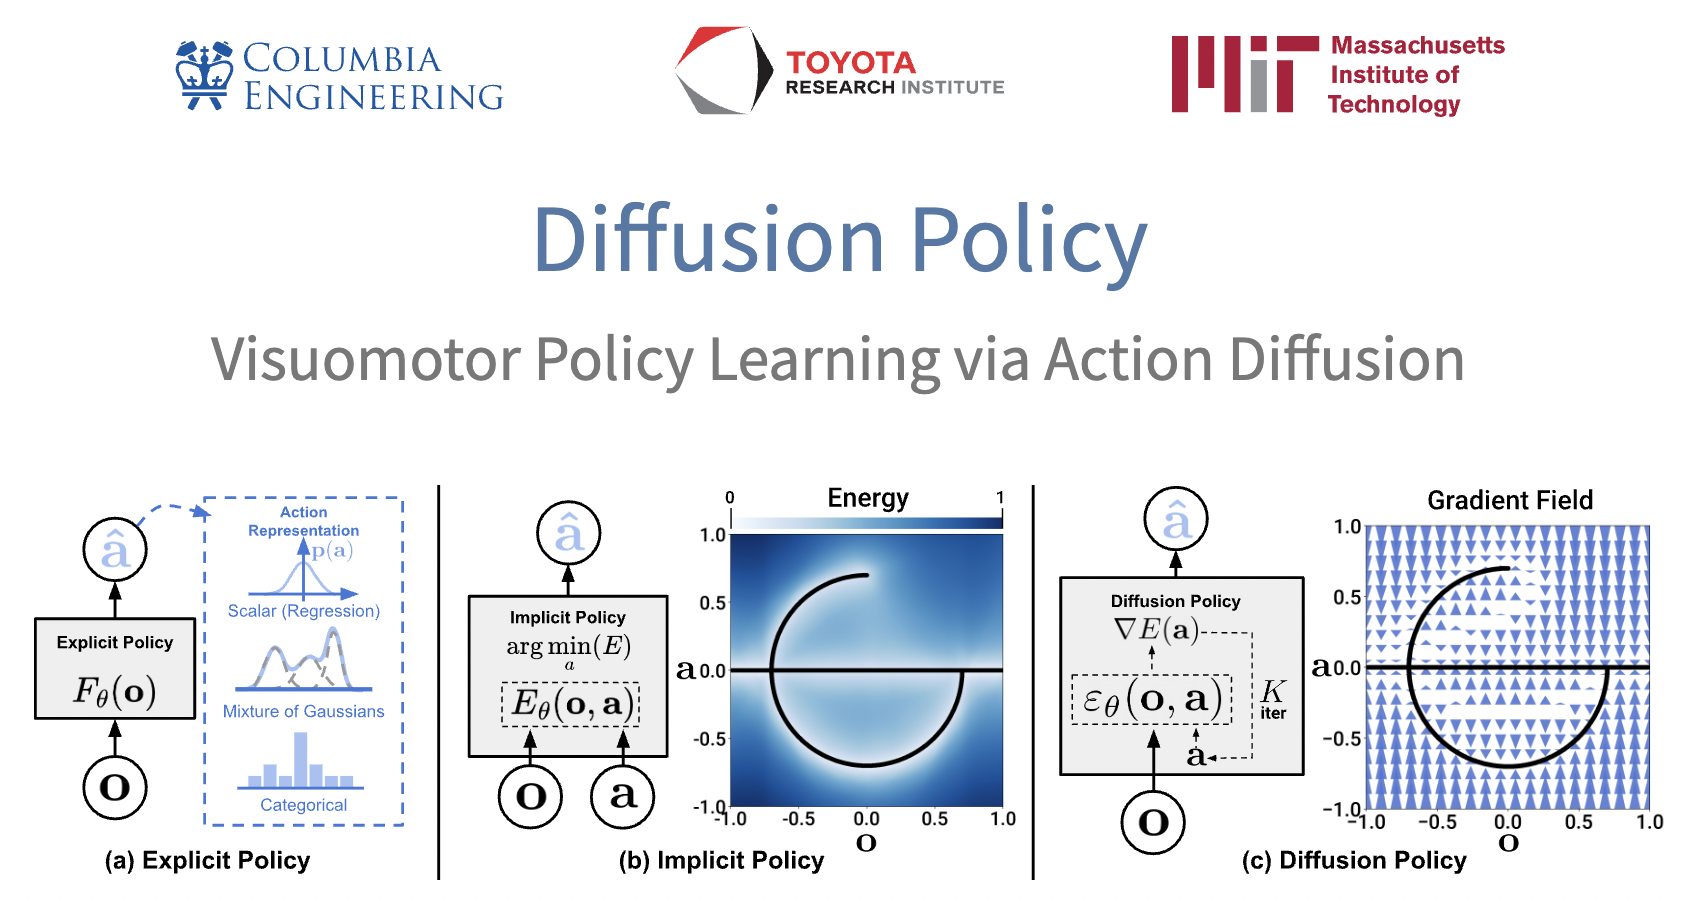
We've been exploring, and found something good in...

From Thursday...

Check out the TRI demo on Wednesday afternoon

Image backbone: ResNet-18 (pretrained on ImageNet)
Total: 110M-150M Parameters
Training Time: 3-6 GPU Days ($150-$300)

Why (Denoising) Diffusion Models?

  • High capacity + great performance
  • Small number of demonstrations (typically ~50)
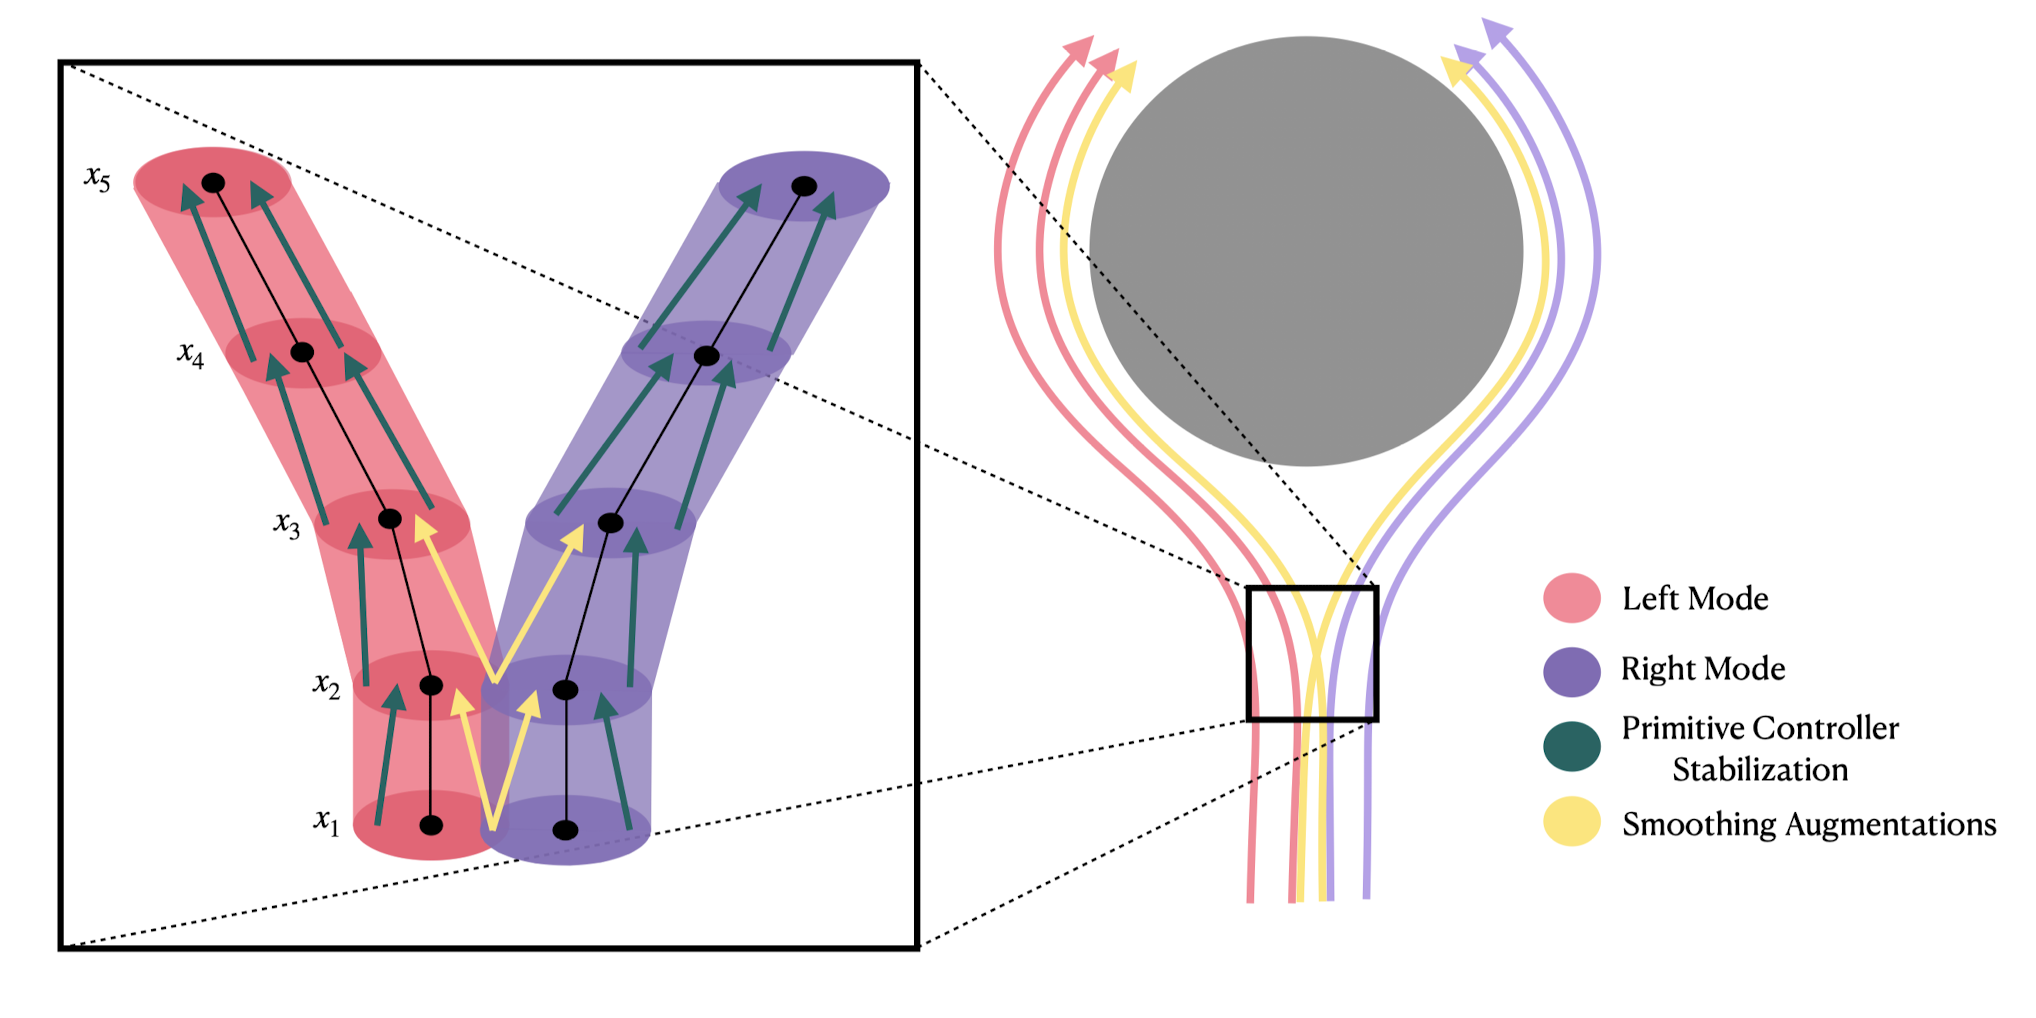
  • Multi-modal (non-expert) demonstrations
  • Training stability and consistency
    • no hyper-parameter tuning
  • Generates high-dimension continuous outputs
    • vs categorical distributions (e.g. RT-1, RT-2)
    • Action-chunking transformers (ACT)
  • Solid mathematical foundations (score functions)
  • Reduces nicely to the simple cases (e.g. LQG / Youla)

Dynamic output feedback

..., u_{-1}, u_0, u_1, ...
..., y_{-1}, y_0, y_1, ...

input

output

Control Policy
(as a dynamical system)

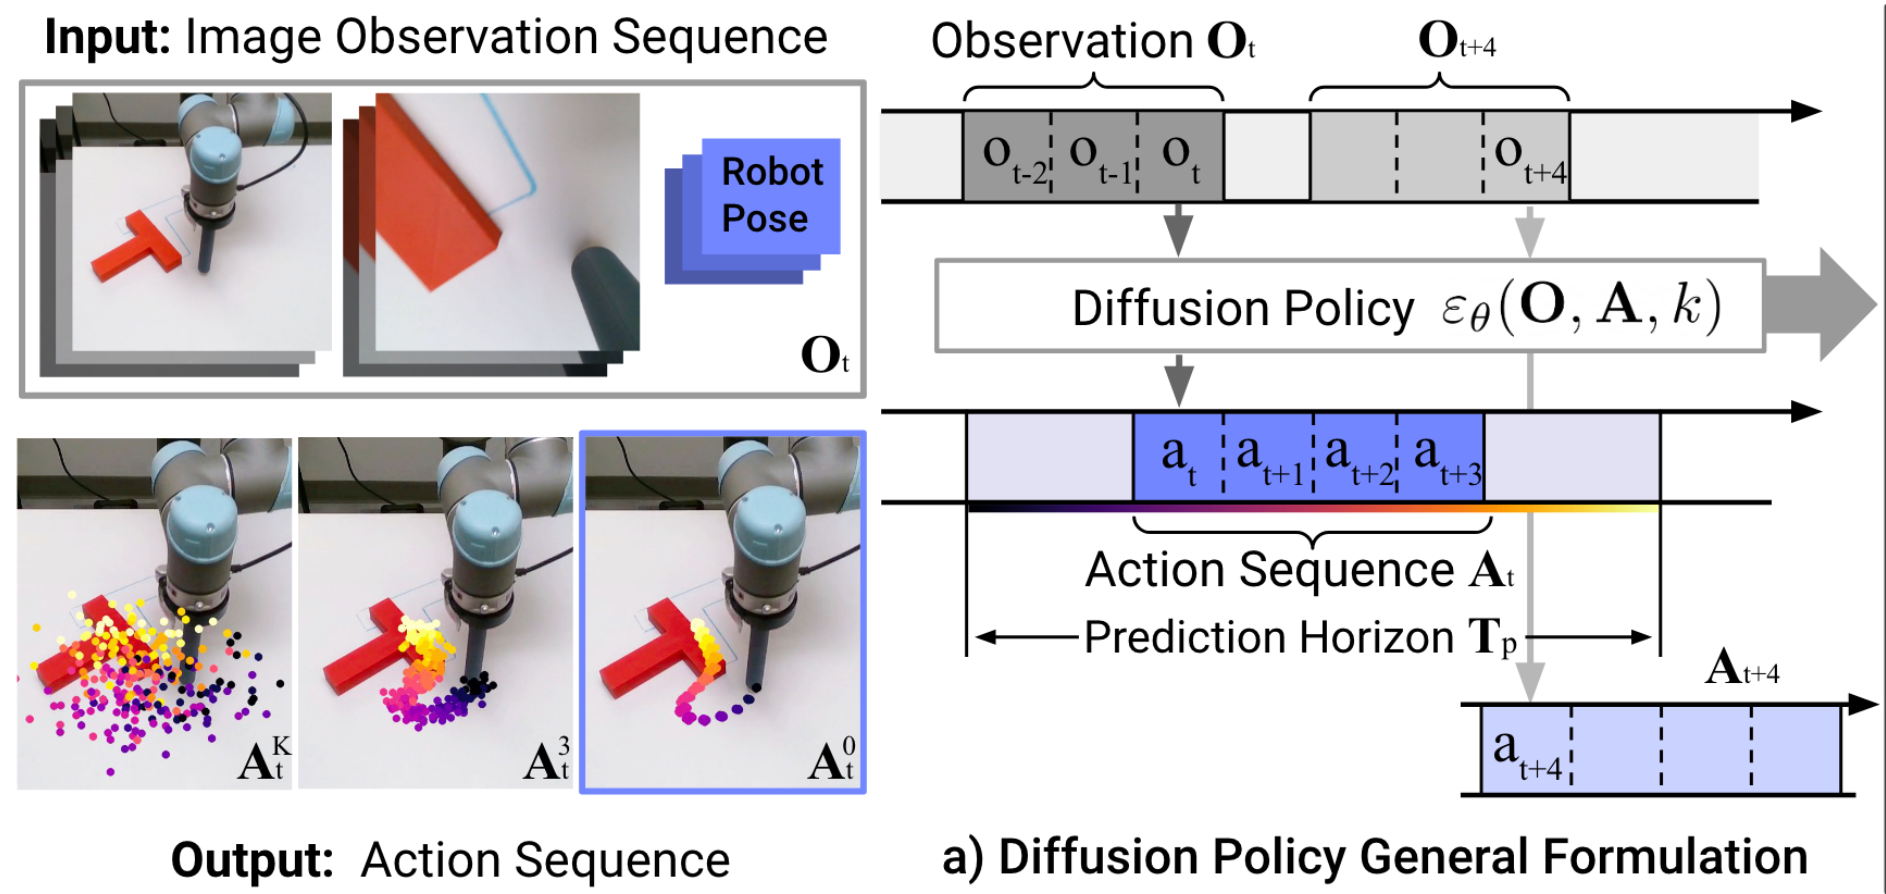
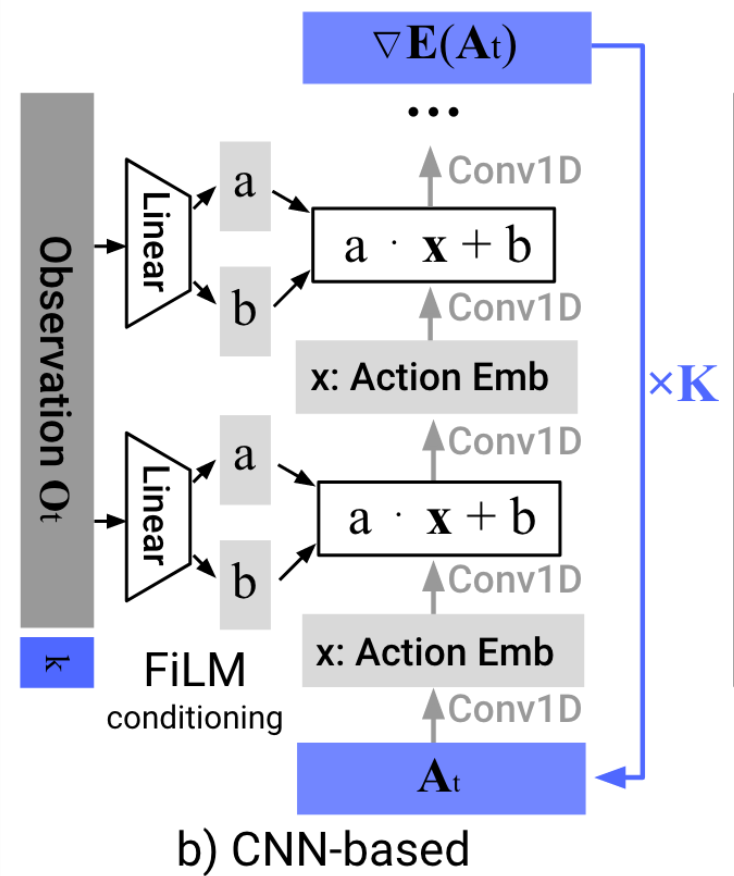
"Diffusion Policy" is an auto-regressive (ARX) model with forecasting

\begin{aligned} [y_{n+1}, ..., y_{n+P}] = f_\theta(&u_n, ..., u_{n-H} \\ &y_n, ..., y_{n-H} )\end{aligned}

\(H\) is the length of the history,

\(P\) is the length of the prediction

Conditional denoiser produces the forecast, conditional on the history

Enabling technologies

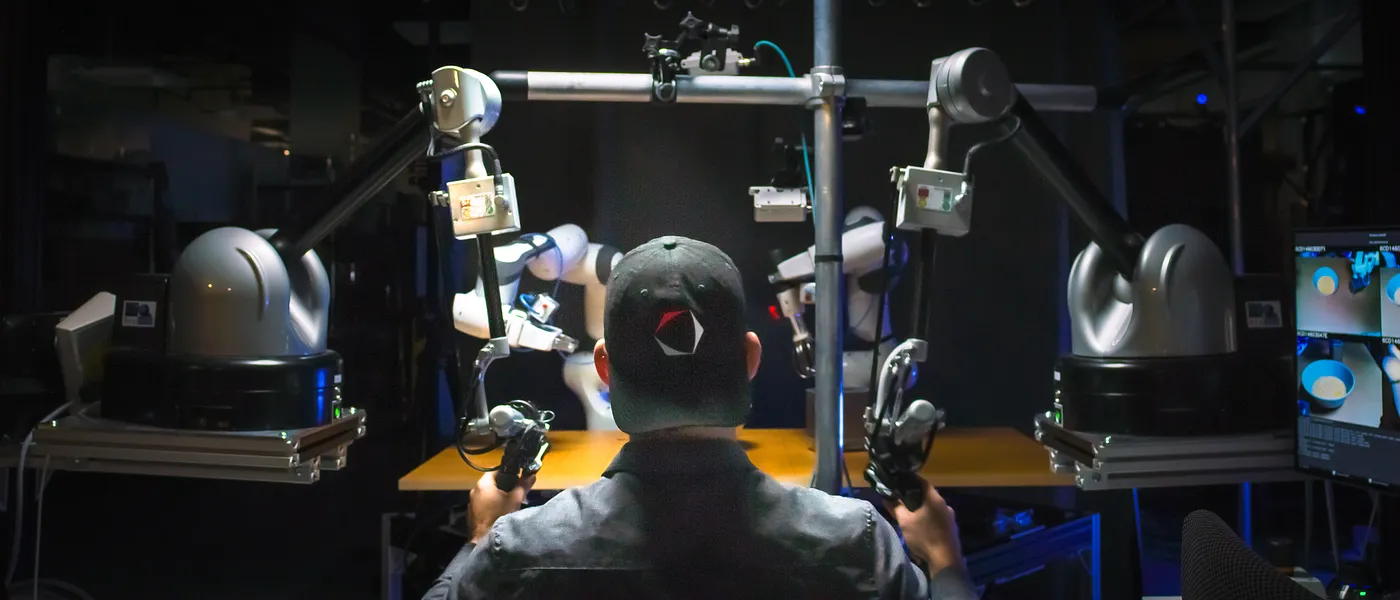
Haptic Teleop Interface

Excellent system identification / robot control

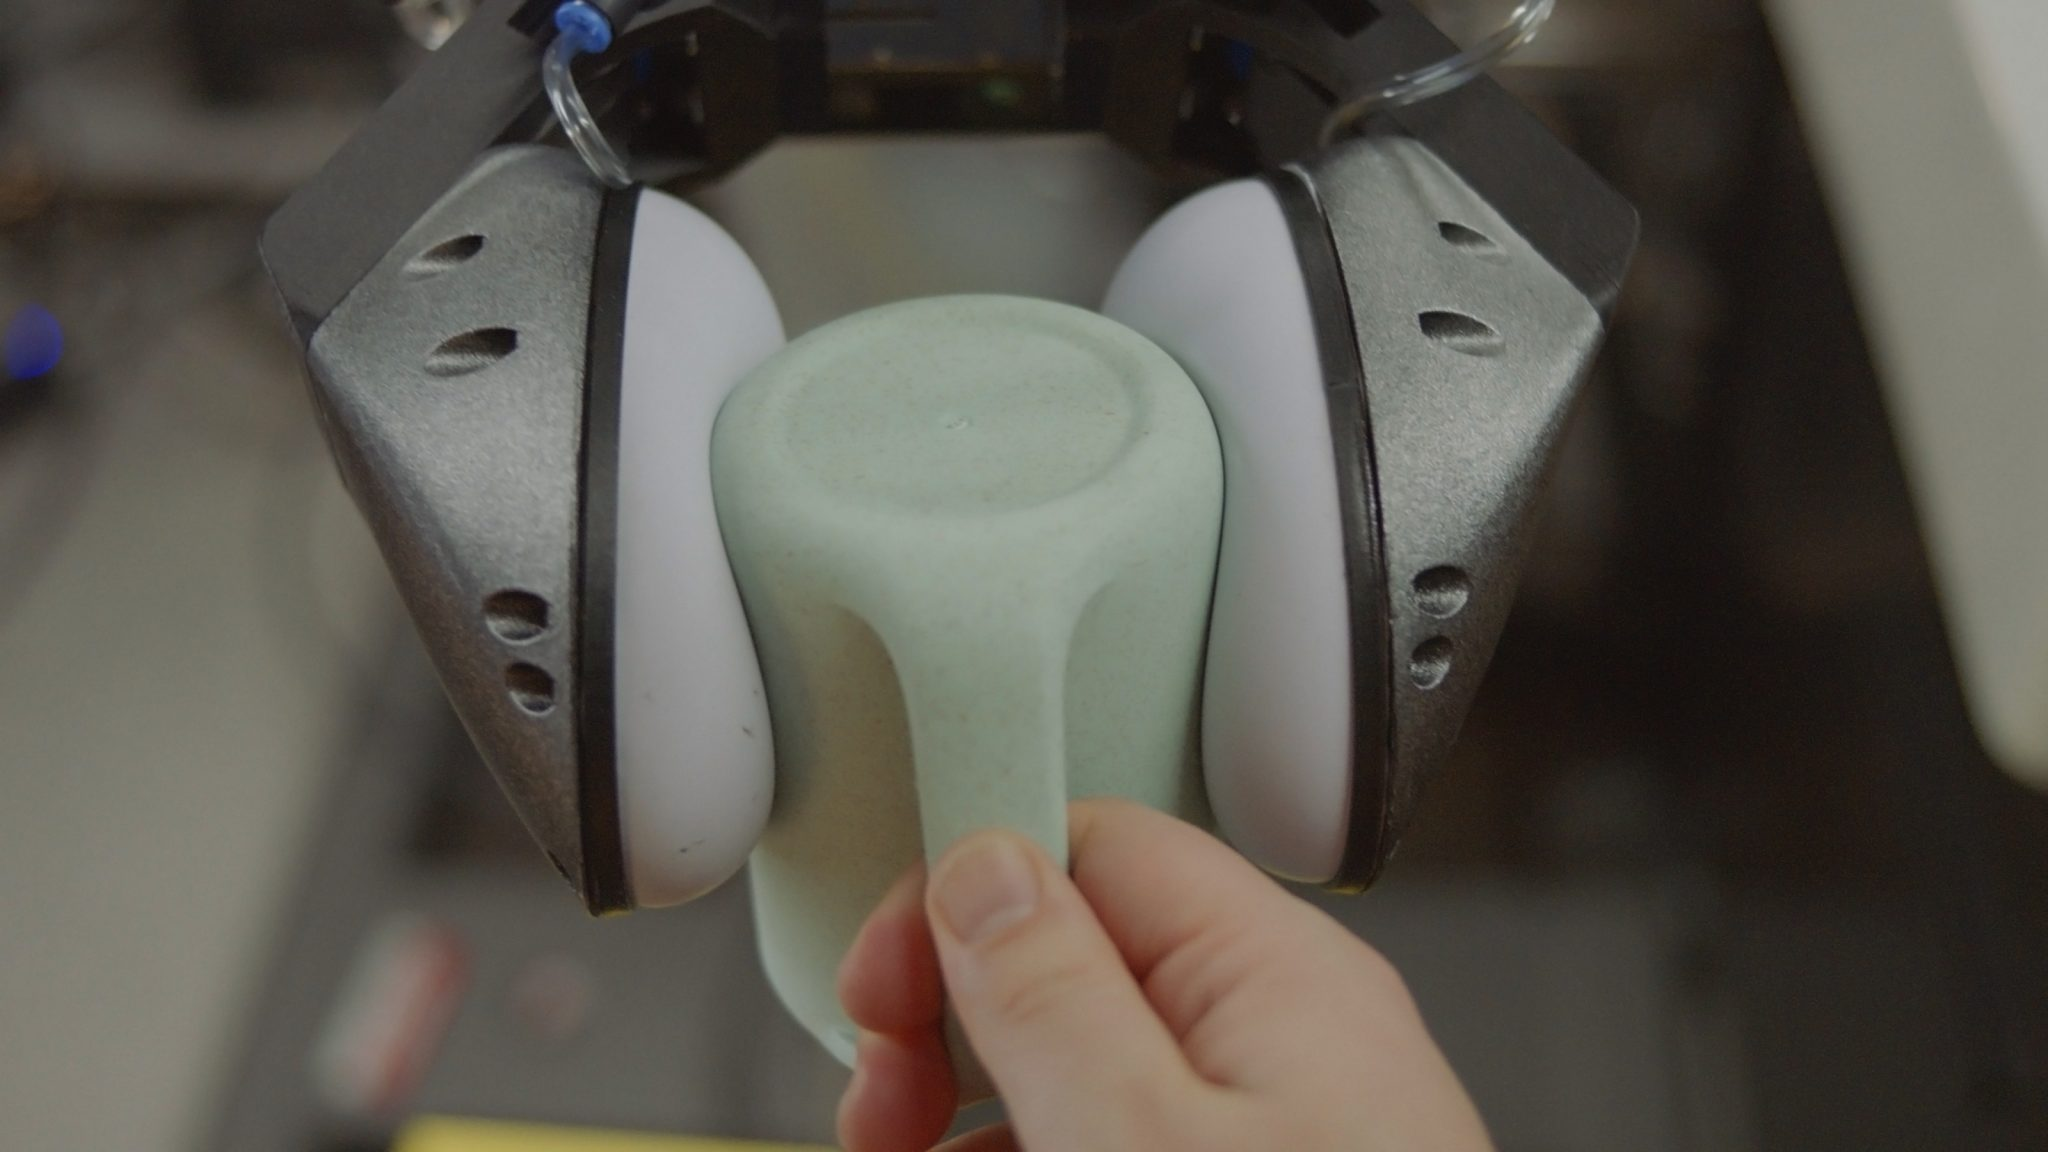
Visuotactile sensing

with TRI's Soft Bubble Gripper

Open source:

https://punyo.tech/

Scaling Up

  • I've discussed training one skill
  • Wanted: few shot generalization to new skills
    • multitask, language-conditioned policies
    • connects beautifully to internet-scale data


  • Big Questions:
    • How do we feed the data flywheel?
    • What are the scaling laws?


  • I don't see any immediate ceiling

Discussion

I do think there is something deep happening here...

  • Manipulation should be easy (from a controls perspective)
  • probably low dimensional?? (manifold hypothesis)
  • memorization can go a long way


Q: How should we think about deployability?

Aside: I still very much believe in and work on model-based control!

Let's remember some lessons from control...

Robust control

  • Nominal model + uncertainty model, e.g. 


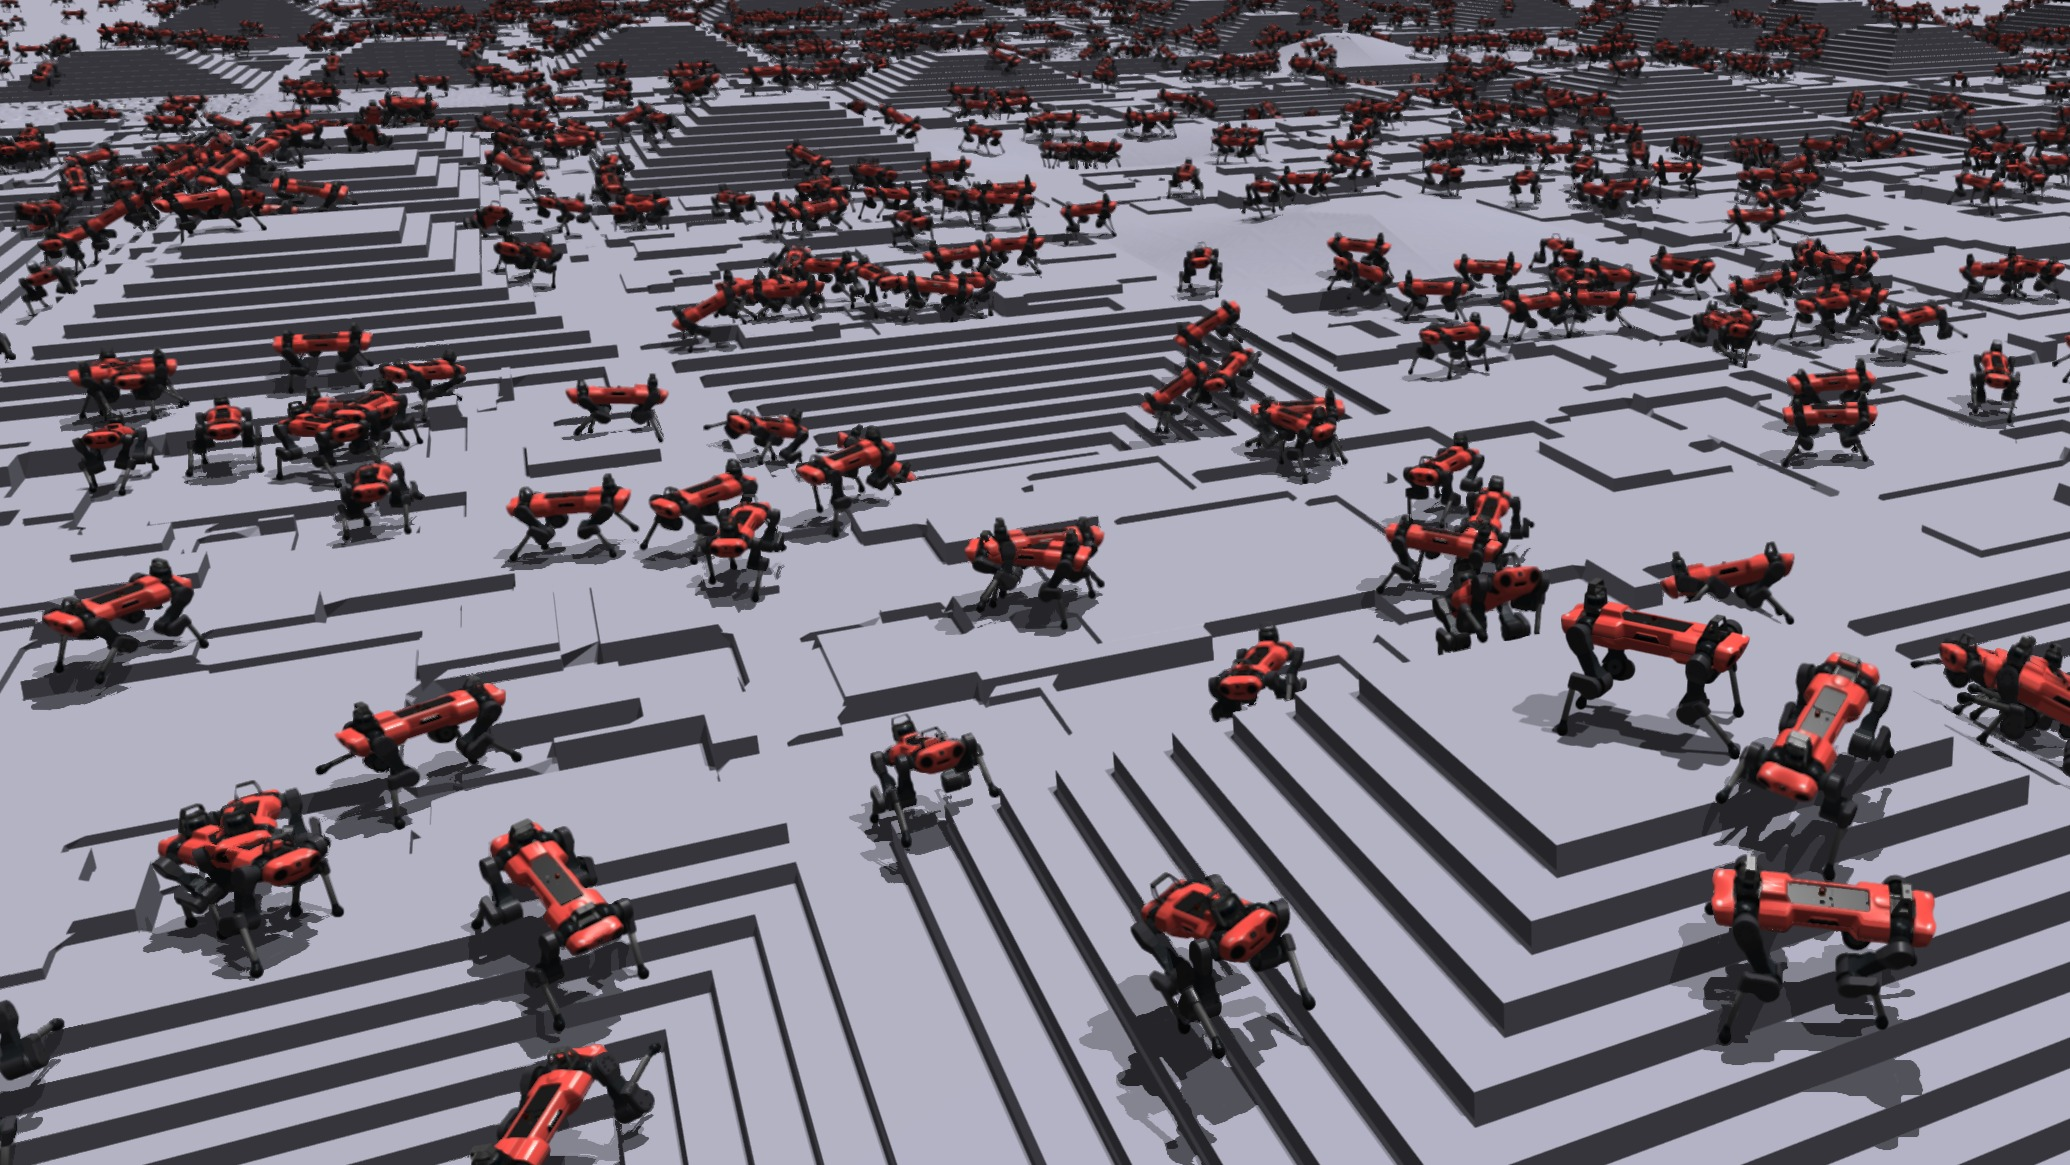
  • Domain randomization is choosing W


  • Optimize worst-case performance
    • But not because robust control folks are uber conservative
x_{n+1} = f(x_n, u_n, w_n), w_n \in W

Verification(?) in an open world...

Found surprisingly rare and diverse failures of the full comma.ai openpilot in the Carla simulator.

The risk-based verification framework

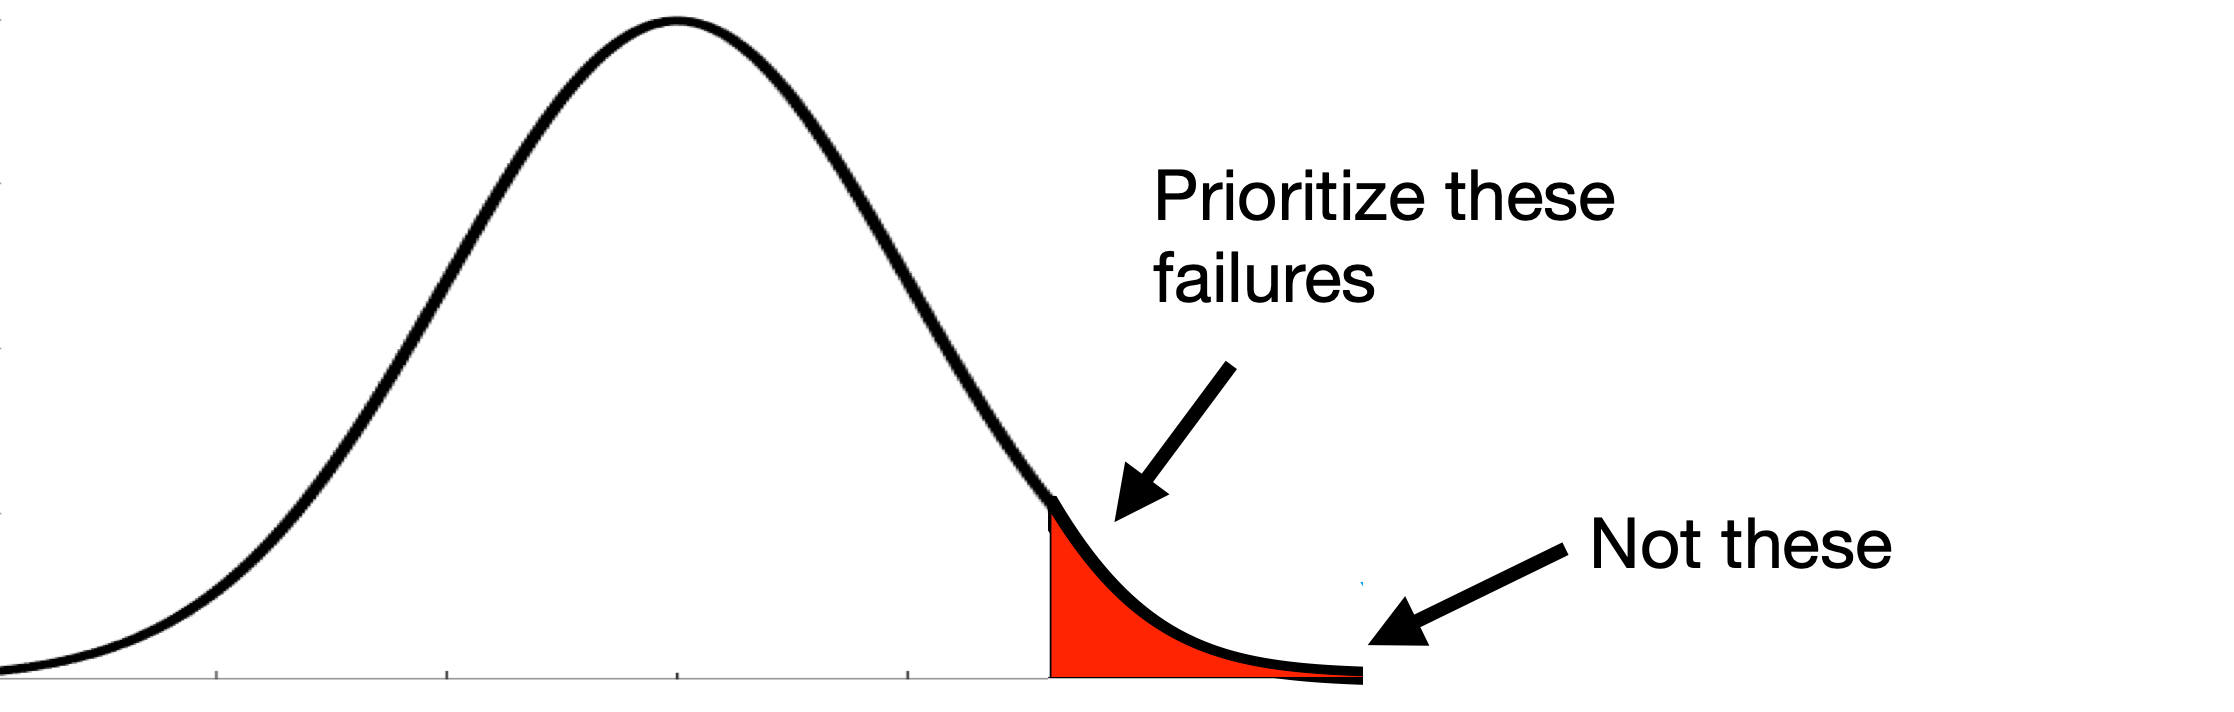
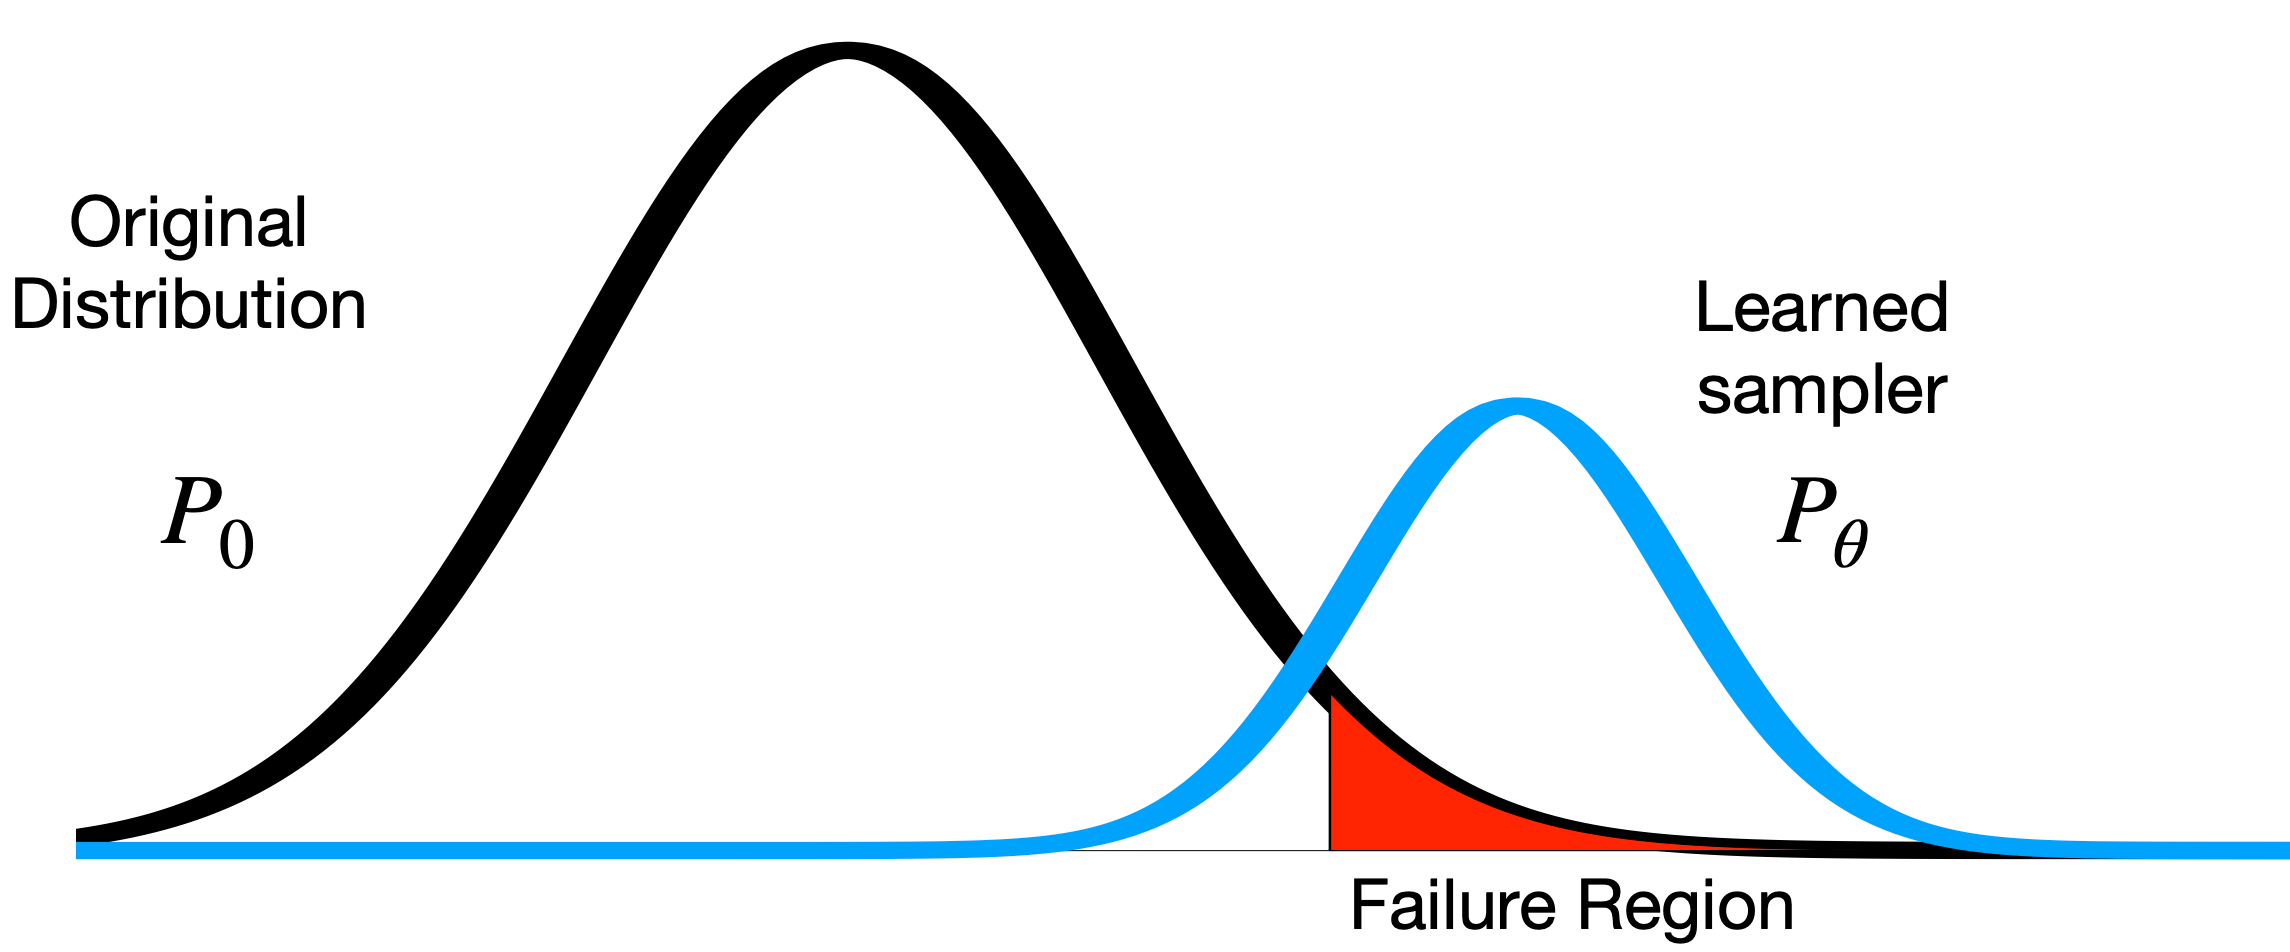
  • Key ideas:
    • Failure probability vs "falsification"
    • Rare-event methods
  • Uncertainty should excite all of the ways that the system can fail
  • When the distribution is too big, false positives are a pain

Essential point:

  • In both cases, I'm not trying to certify performance in the real world.


  • Being robust to my uncertainty spec, W, makes me more robust even to the unknown unknowns.


  • Foundation models take this to the next level.

The "foundation models for control" mentality

  • Grow dataset on real data until everything is "in distribution"


  • Essential point: "common-sense" robustness


  • (Non-catastrophic) failures are good, as long as we also show recovery.


  • We'll continue to capture/fix failures even after the system is deployed

So, how do we get to "deployable"?

  • We have not yet seen what "robustness" looks like when we get to the GPT moment for robotics.


  • I would bet it's deployable.

Deployable@CoRL2023

By russtedrake

Deployable@CoRL2023

Princeton Robotics Seminar

  • 7,580