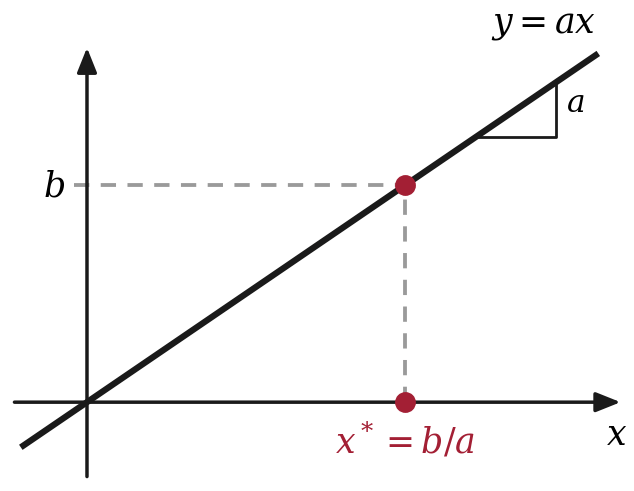
Tomas Lozano-Perez PRO
Roboticist at MIT
MIT 6.4210/2: Robotic Manipulation
Fall 2026, Lecture 5
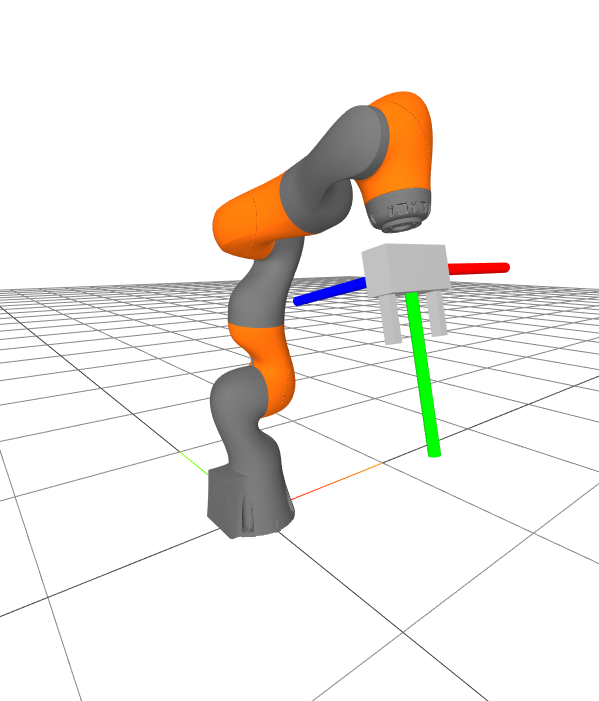
Kinematic Jacobian: \( {}^WV^G = J^{G}(q) v \)
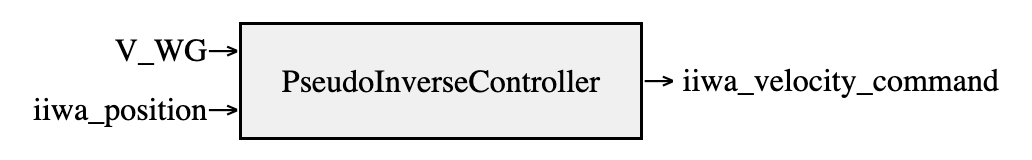
\( v = [J^{G}(q)]^{+} {}^WV^G \)
spatial velocity
generalized velocity
prog = MathematicalProgram()
x = prog.NewContinuousVariables(2)
prog.AddConstraint(x[0] + x[1] == 1)
prog.AddConstraint(x[0] <= x[1])
prog.AddCost(x[0] ** 2 + x[1] ** 2)
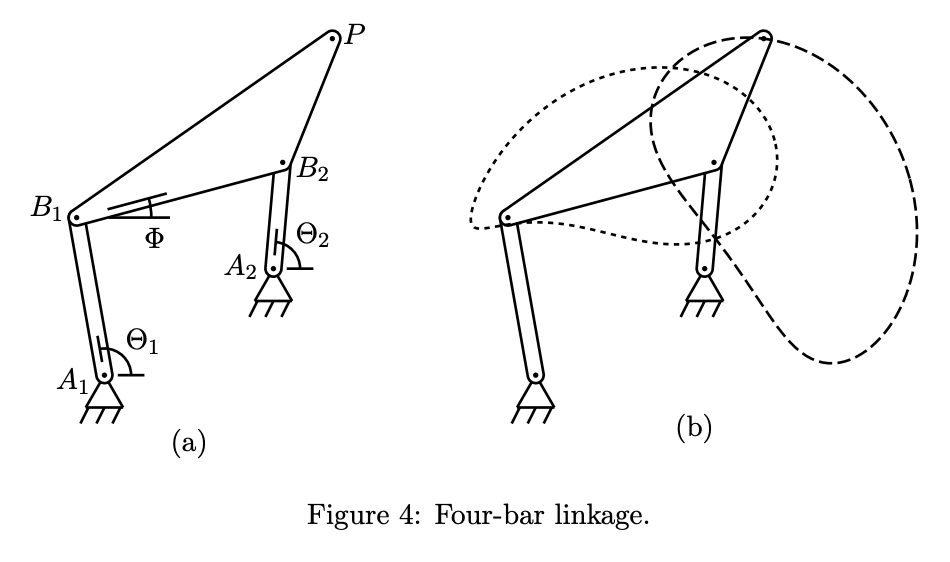
result = Solve(prog)Charles W. Wampler and Andrew J. Sommese. Numerical algebraic geometry and algebraic kinematics. Acta Numerica, 20:469-567, 2011.
subject to:
        ik = InverseKinematics(plant, plant_context)
        ik.AddPositionConstraint(
            gripper_frame,
            [0, 0, 0],
            plant.world_frame(),
            pose.translation(),
            pose.translation(),
        )
        ik.AddOrientationConstraint(
            gripper_frame,
            RotationMatrix(),
            plant.world_frame(),
            pose.rotation(),
            0.0,
        )
        prog = ik.get_mutable_prog()
        q = ik.q()
        prog.AddQuadraticErrorCost(np.identity(len(q)), q0, q)
        prog.SetInitialGuess(q, q0)
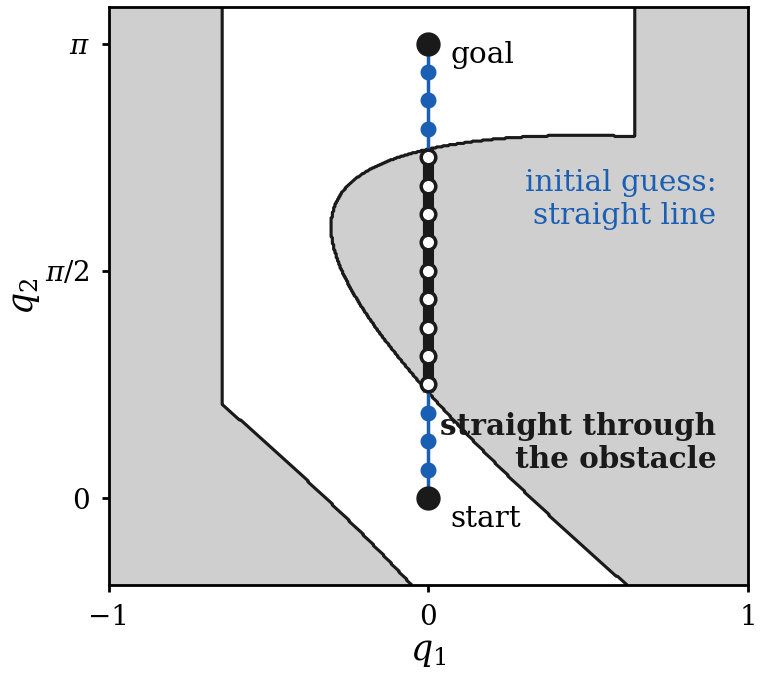
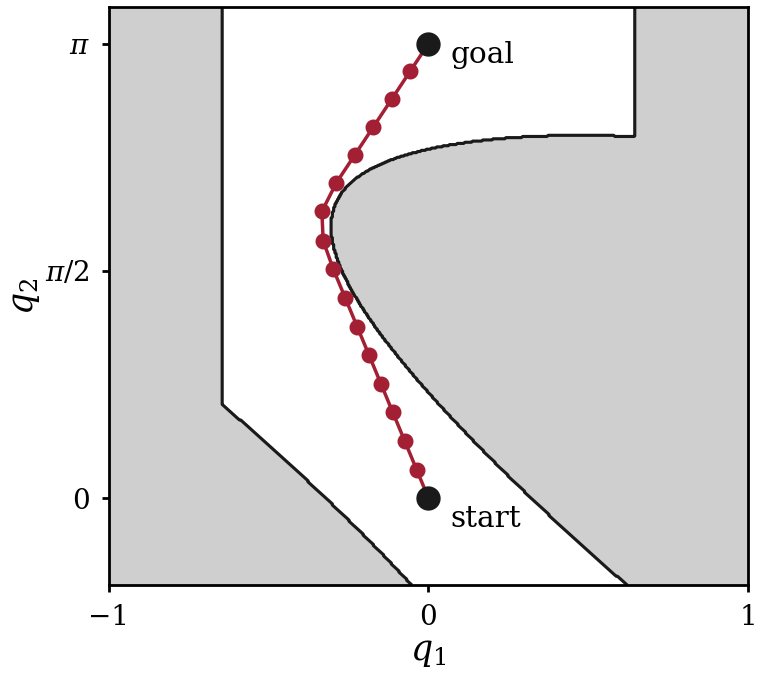
result = Solve(ik.prog())start
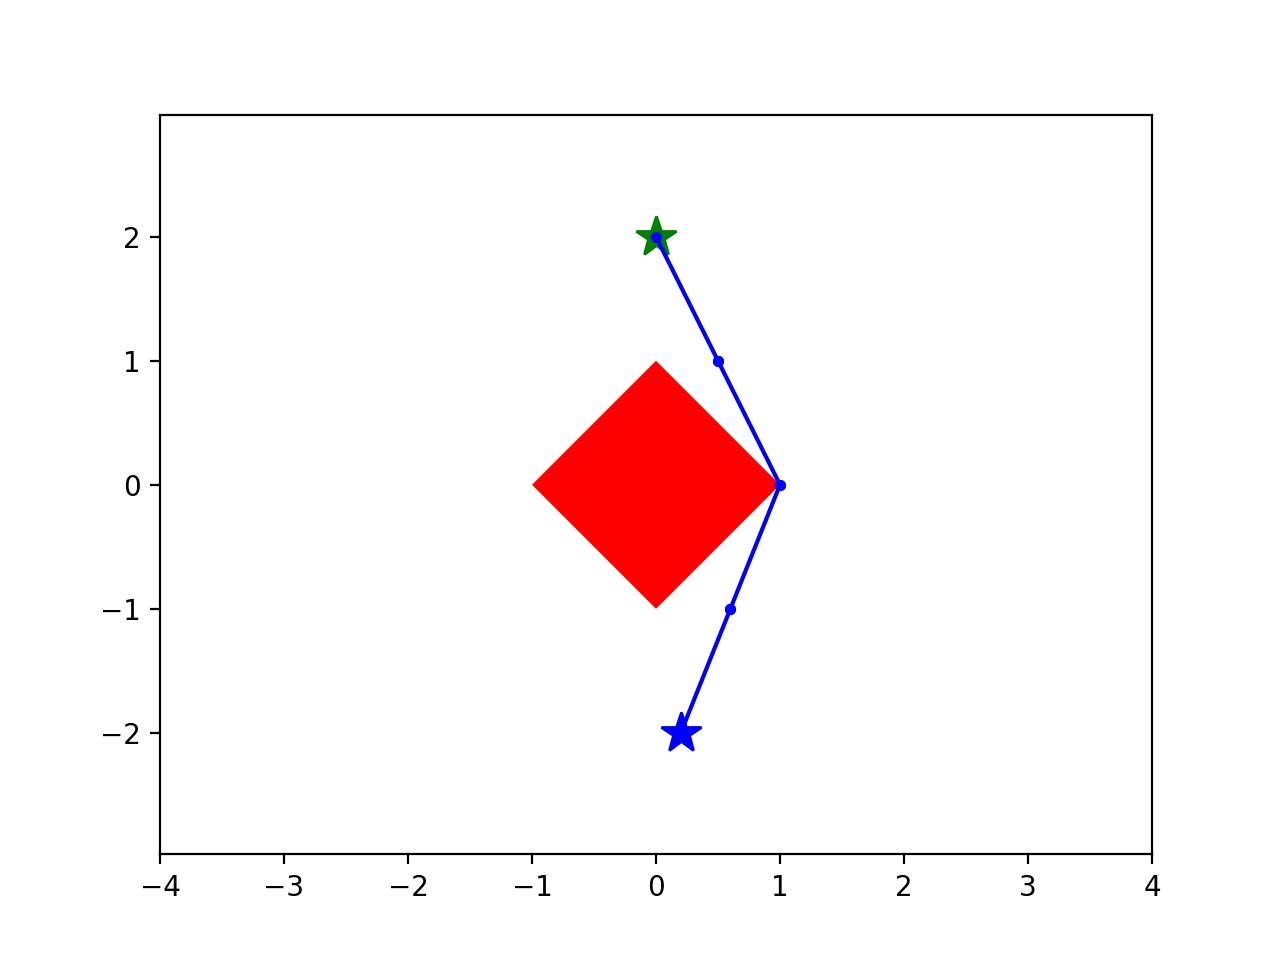
goal
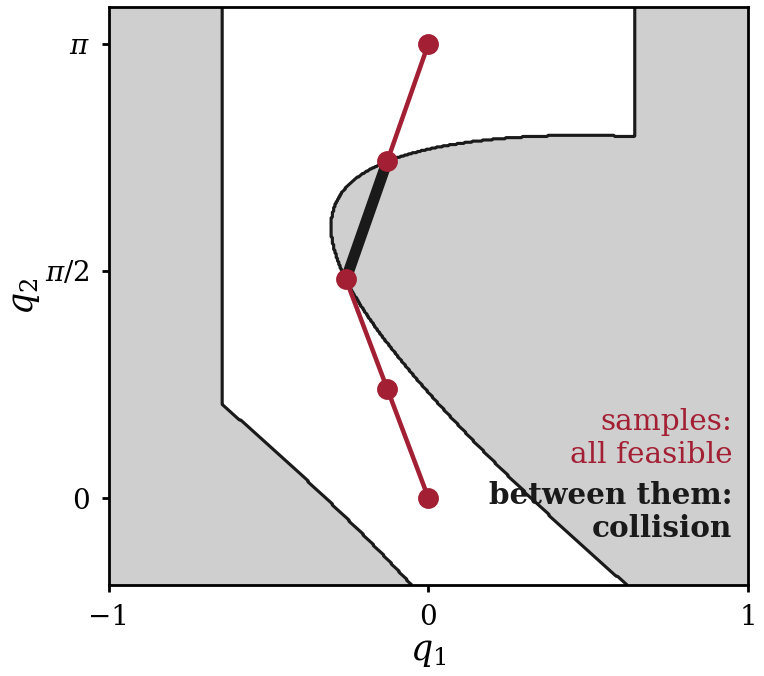
fixed number of samples
collision-avoidance
(outside the \(L^1\) ball)
nonconvex
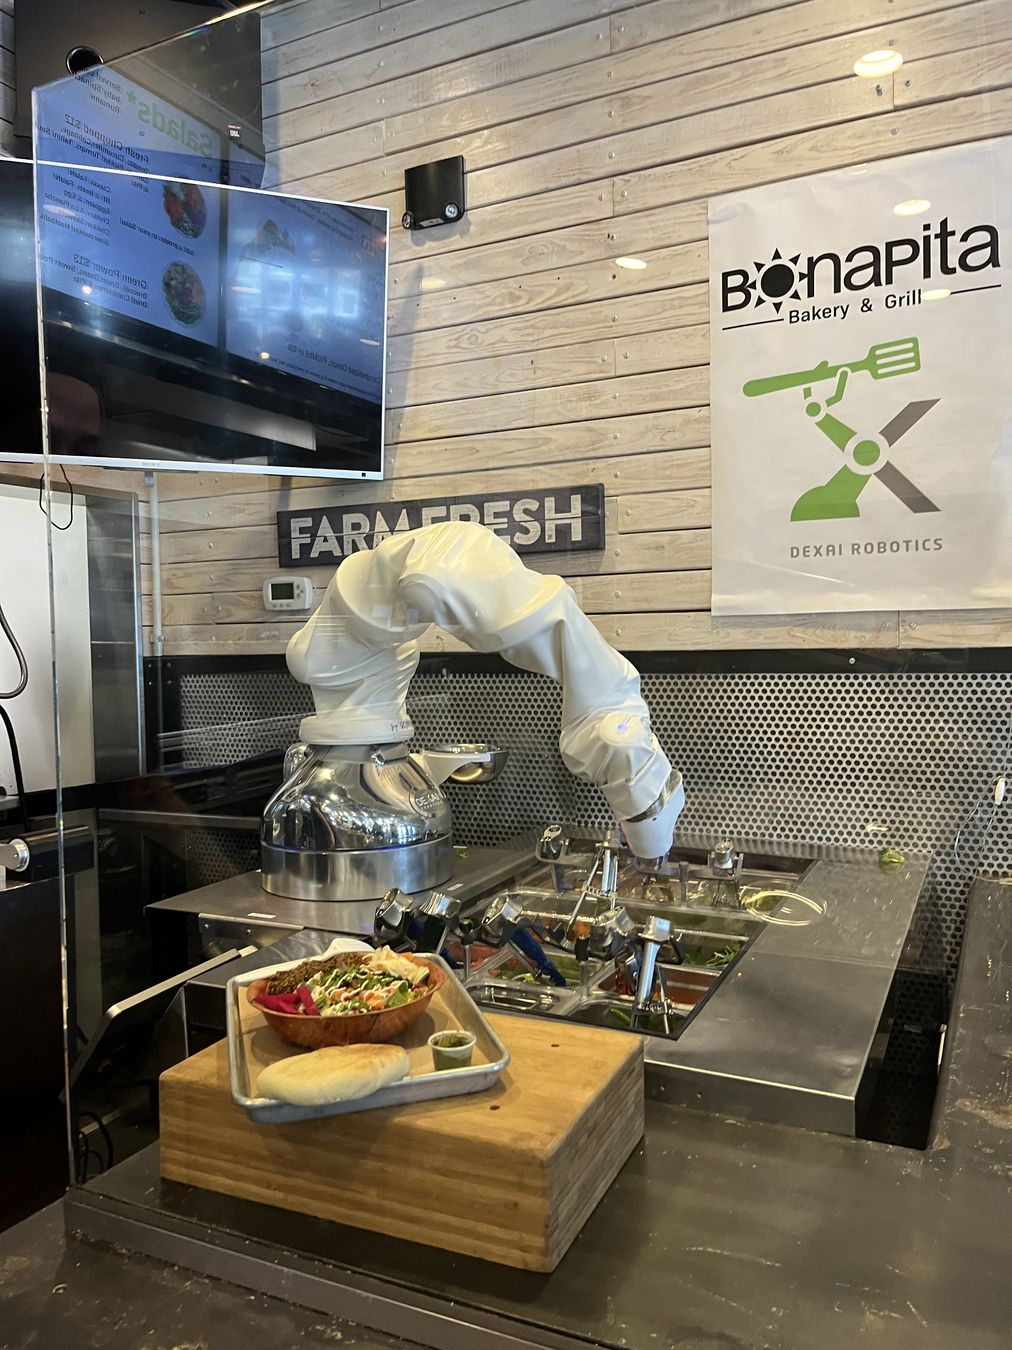
"Using trajectory optimization made scooping up to twice as fast"
credit:
By Tomas Lozano-Perez
MIT Robotic Manipulation Fall 2026 http://manipulation.csail.mit.edu