BayesContact: Uncertain Pose Estimation via Visuo-Tactile Proposals and Simulation-based Inference
Motivation
Problem: Partial Observability in Contact-rich Manipulation settings
Goal: Improve Partial Observability using Contact information
* Robot data
Missing information \( {}^{*} \)
Robot/Env Occlusions \( {}^{*} \)
Ambiguous geometry
Motivation
Problem: Partial Observability in Contact-rich Manipulation settings
Goal: Improve Partial Observability using Contact information
Insertion attempt\({}^+\) at FoundationPose pose estimate
Insertion attempt\({}^+\) at ICP\({}^*\) pose estimate
3x
3x
* Best of 10 initialisations, \({}^+\) All insertions are performed with the same controller
BayesContact
Key Insight: Geometry conditioned Force Likelihoods improve pose estimate for fine manipulation
Insertion attempt\({}^+\) at pose estimate from Vision
Insertion attempt\({}^+\) at pose estimate from Vision and Contact
3x
3x
\({}^+\) All insertions are performed with the same controller
System Overview
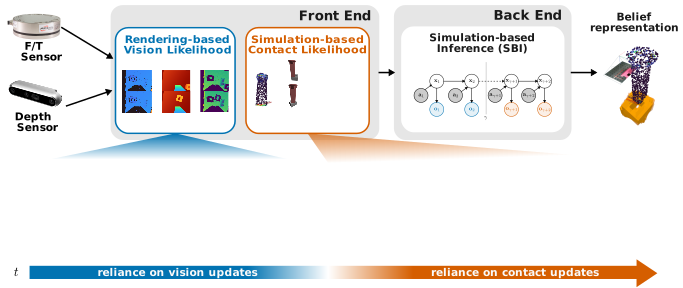
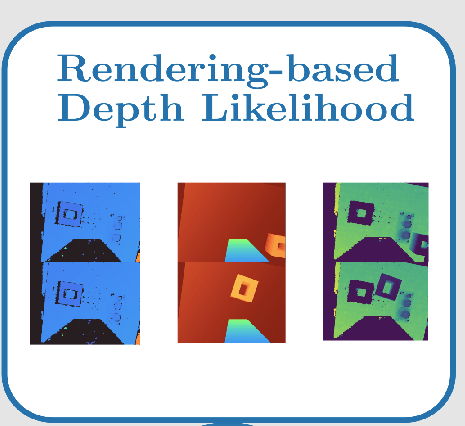
Depth Likelihood
Depth, RGB
Pixelwise Likelihood
Sampled Image
Ground Truth
Vision Particle
Depth Likelihood
Pixelwise Likelihood
Sampled Image
Robust to missing information from noisy depth sensing
Robust to environment and robot induced occlusion
Geometry-Conditioning of F/T signals
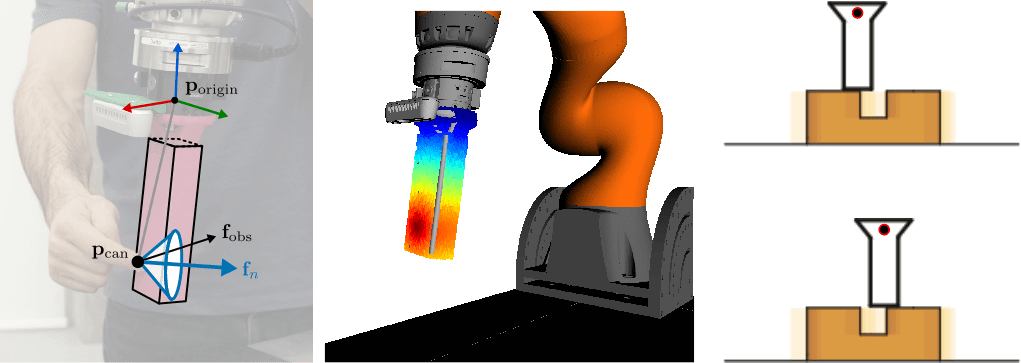
Generate contact hypothesis for a hand desgined guarded probe using a simulator \( \mathcal{S}\). \( \mathcal{L}_{\text{joint}}\) computes the likelihood of observed and contact hypotheses.
Ground Truth
Simulation-based Contact Likelihood
Contact Particle
Evaluate contact probe locations for \( N \) particles per measurement.
Evaluate \( K \) contact measurements sequentially, extracting local contact information.
Results
Improved Pose Estimates \( \rightarrow \) Improved Insertion
Insertion attempts\({}^+\) with FoundationPose (FP), ICP, BayesContact Vision (BCv)
Robust to missing information from noisy depth sensing
Insertion attempts\({}^+\) with BayesContact
FP
BCv
ICP
BCv
\({}^+\) All insertions are performed with the same controller
BayesContact
By Aditya Kamireddypalli