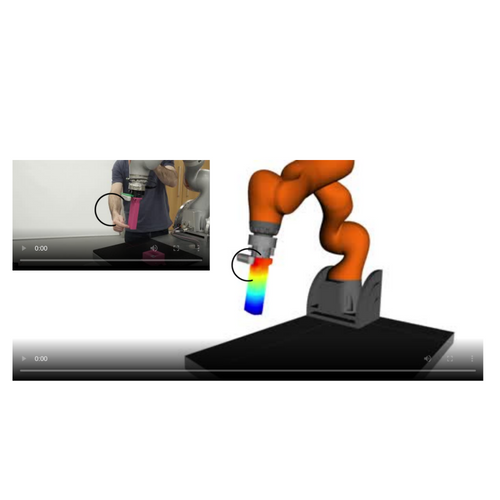
Reactive and Adaptive Control Strategies for Robot Assembly
Initial Infrastructure updates
Aditya Kamireddypalli
Sprint 1
Simulation
- Drake and MujoCo
- State Estimation loop
- Motion planning
- Each action as a controller
- Base Impedance Control
- Traj Opt
Real Robot
- Peg-insert on existing gear setup, Panda
- State Estimation Loop
- Motion Planning
- Impedance Control set-point
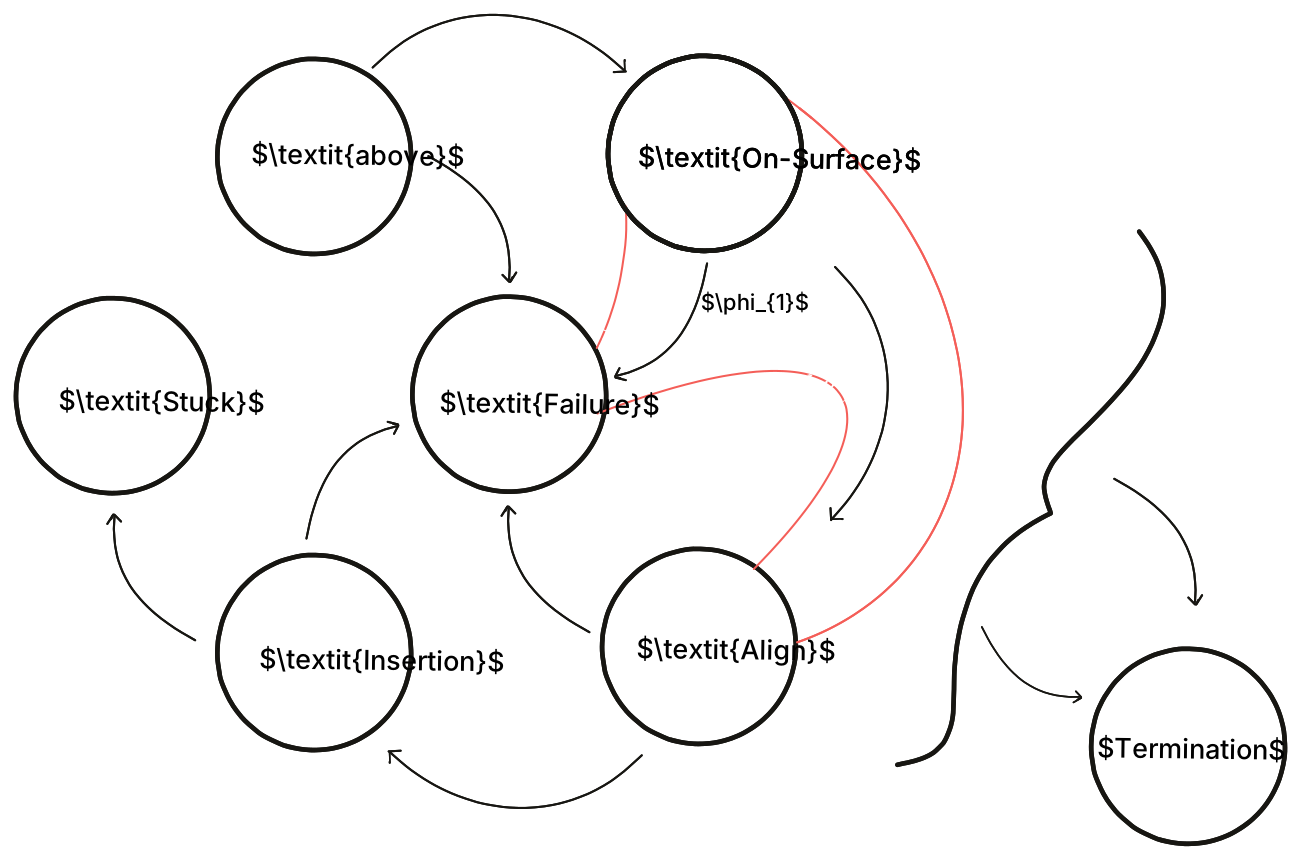
Sprint 1 - retrospective
Simulation
- Drake Peg-insertion Finite State Machine
- State Estimation loop
- Particle Filter - doubtful implementation.
- Motion planning
- Set point control of Stiffness Controller
- Symbolic State Estimation
- Termination Predicates
- Time based, local disk based (squared error)
- State Estimation loop
- Real Robot
- Experimental infra design
- No real robot experiments yet
Controller Switching
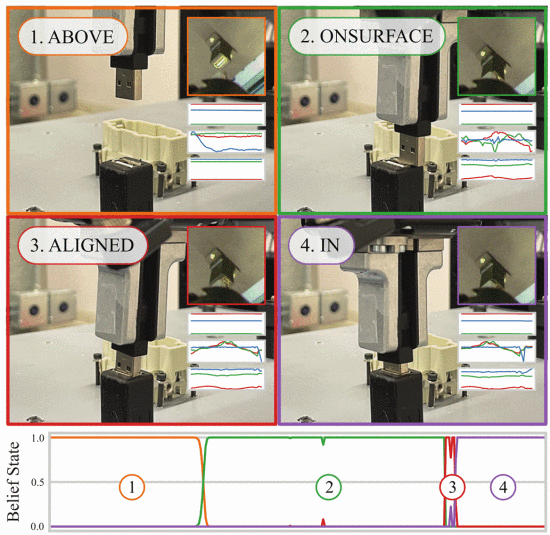
Sprint 2
Simulation
- Polish the low level State estimation loop
- Experiment with GTSAM and other code bases
- Motion planning
- Set point Stiffness Control
- Traj Opt
- Predicate engineering
Real Robot
- Peg-insert on existing gear setup, Panda
- Motion Planning
- All sim controllers can be used with Real Robot, courtesy
drake_ros
- All sim controllers can be used with Real Robot, courtesy
Sprint 2
Simulation
Predicate Engineering
- Simple Force based classifiers - baselines
- Composition of multiple predicates. Gaussian Mixture Models
- Action sensors
- Model based controllers
- Use feedback and construct local disks around EEF. Use Intersection between ideal disk and estimated disk as a sensor.
- Propagate this as a component into the Gaussian Mixture
Stretch
- Connect up the software with real robot and demonstrate.
research_update
By Aditya Kamireddypalli