Weekly Updates
Aditya Kamireddypalli
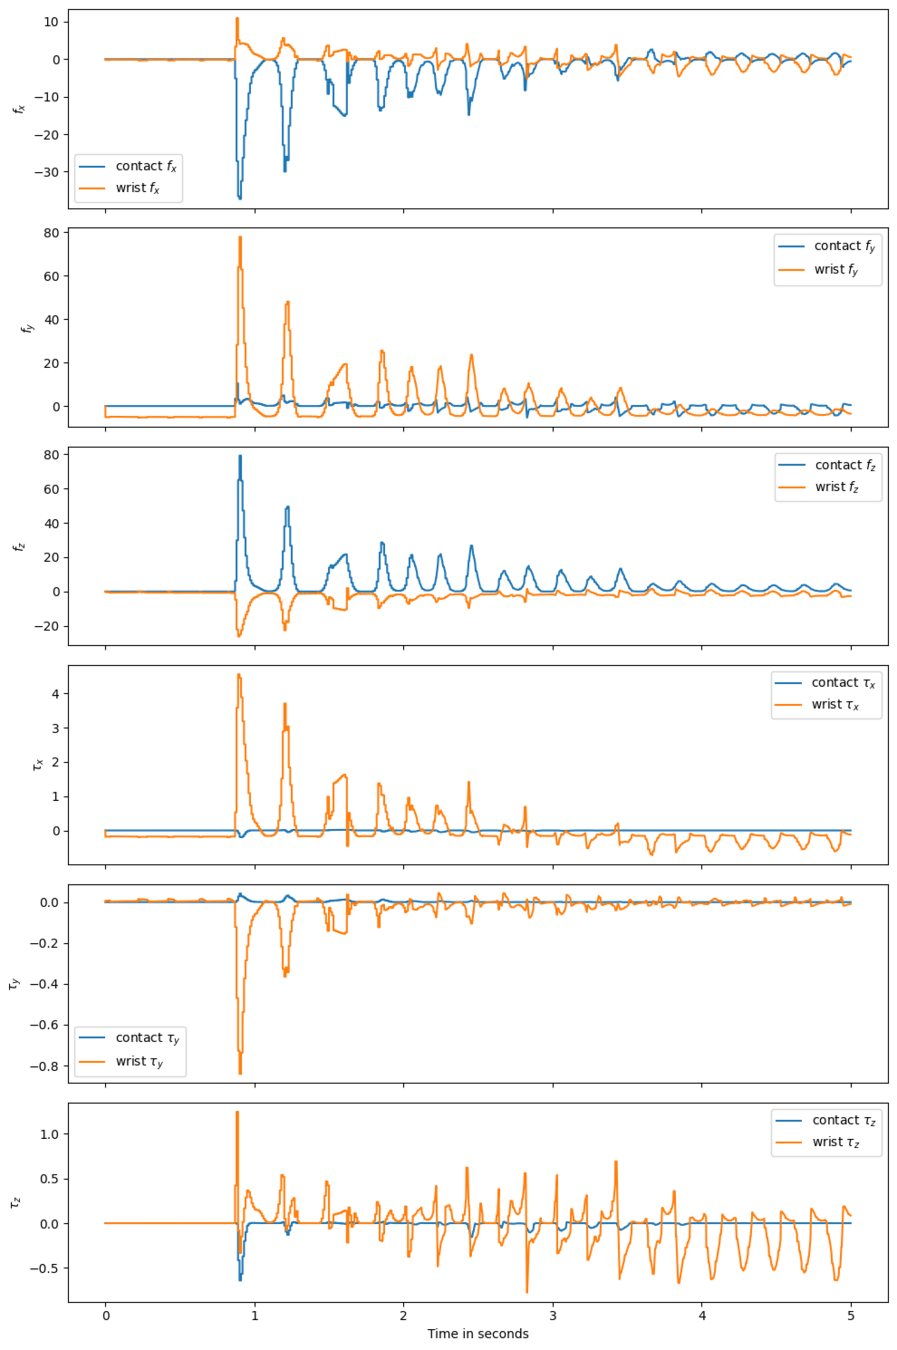
Contact Sensor
Nov 22nd
- Diwali break
- Roscon 2024
Research
- Report statistics on existing system, scripted patterns and LfD
- voxblox and trajectory synthesis
- update voxblox with contact information.
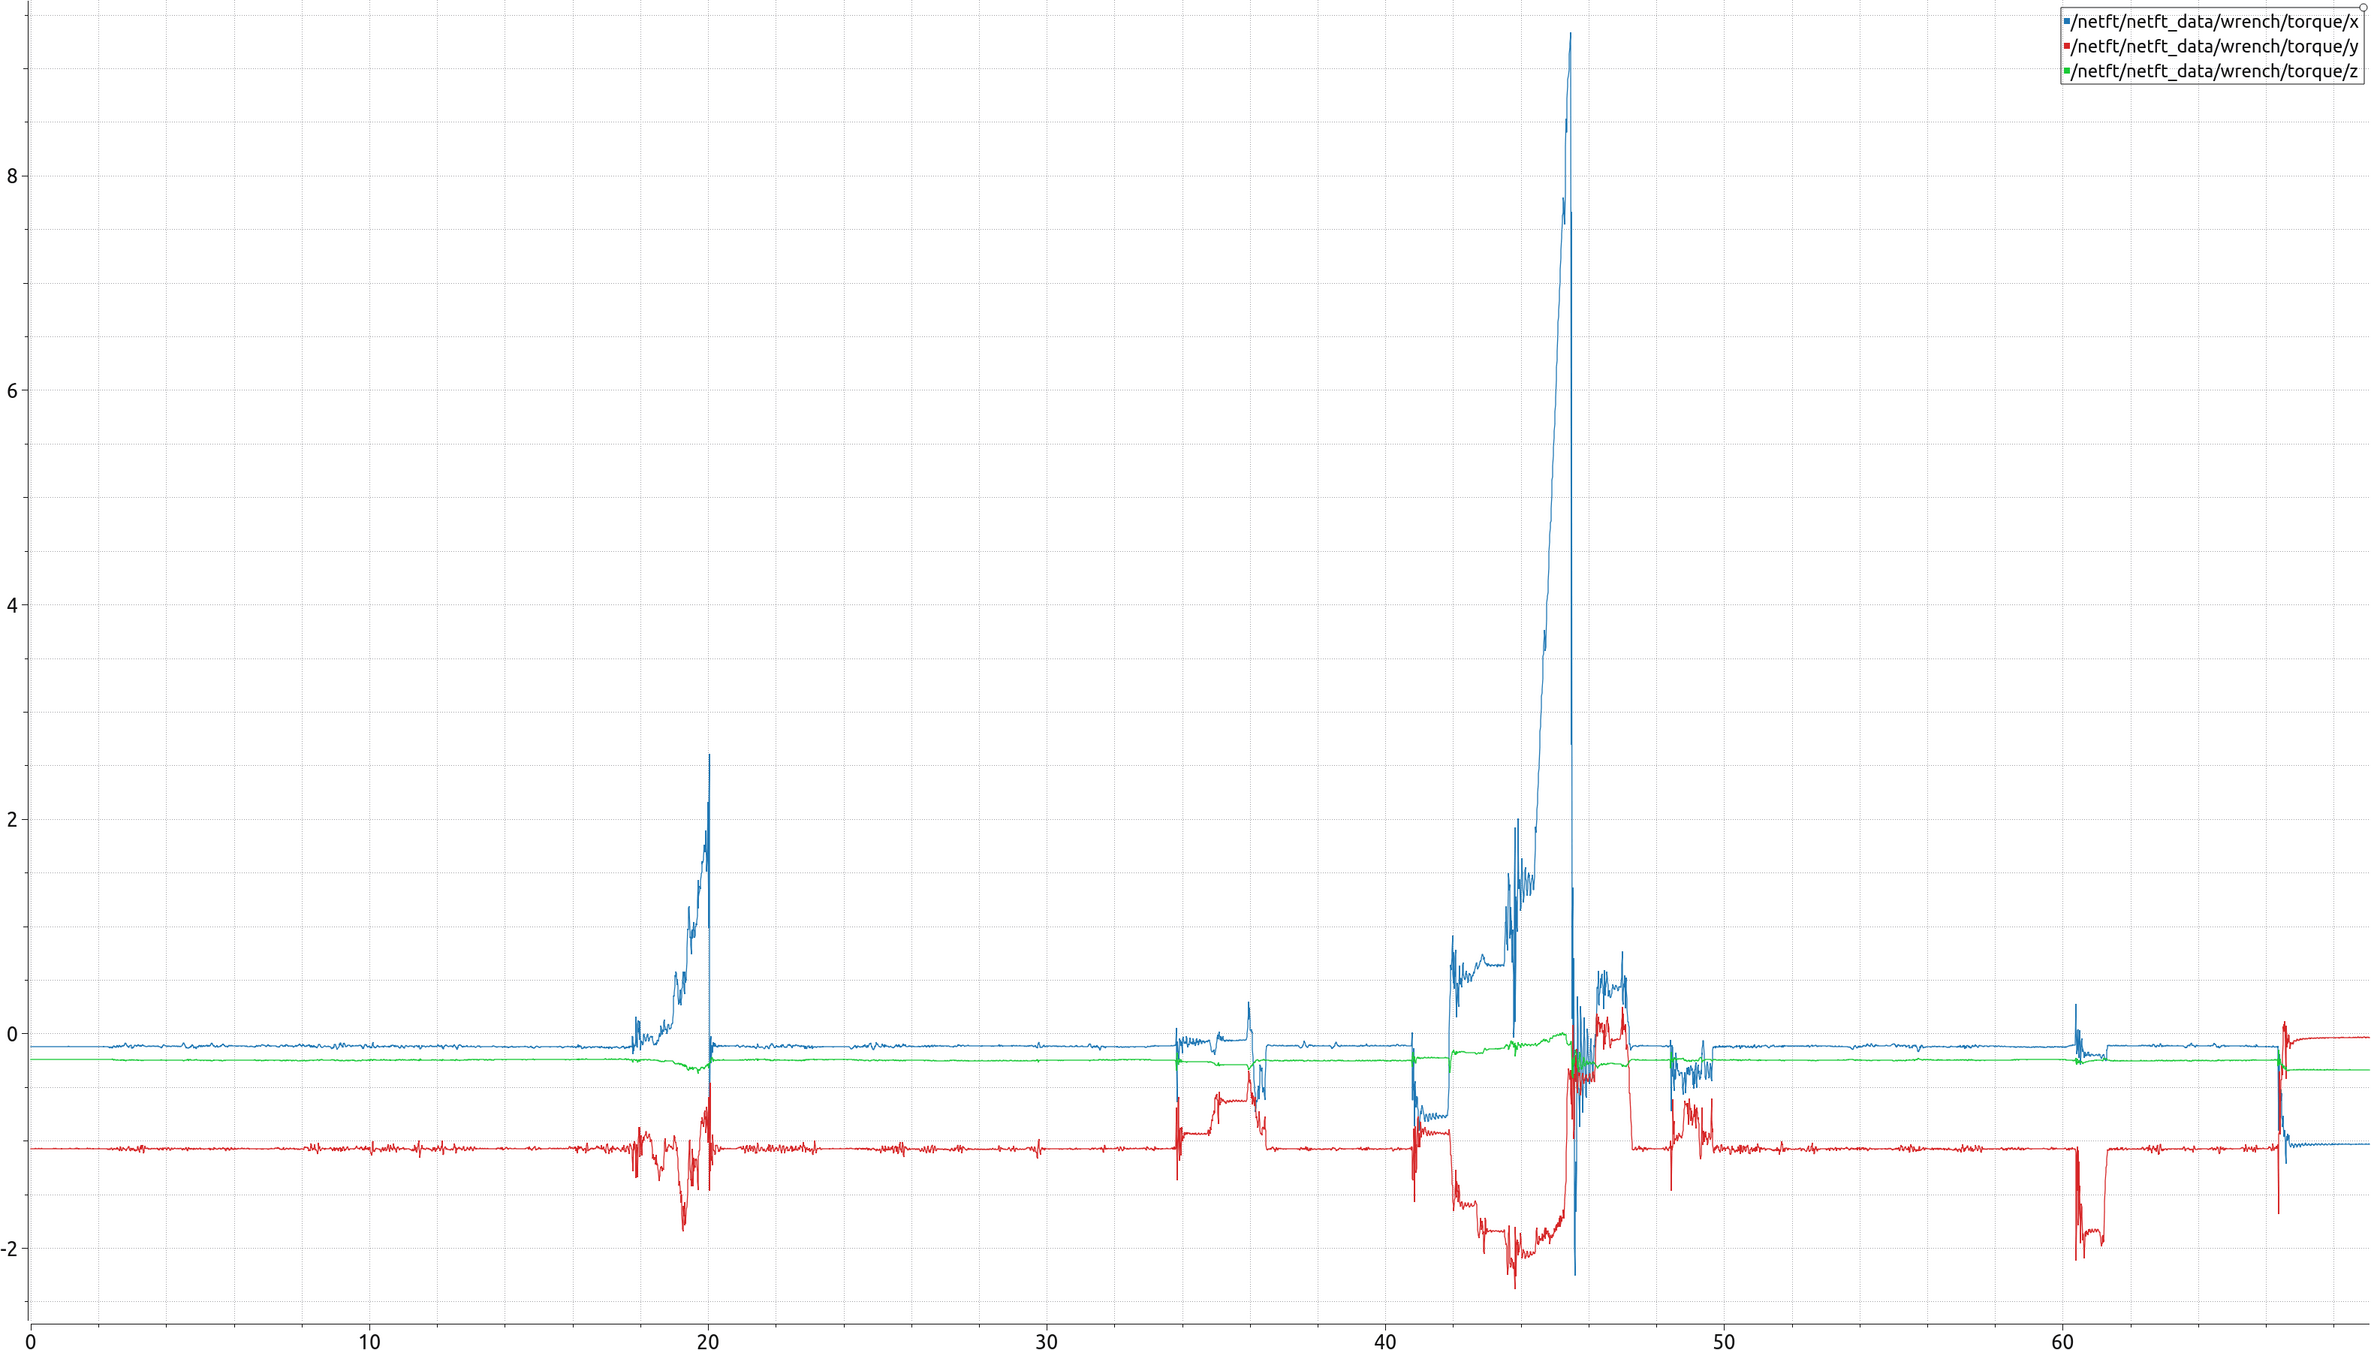
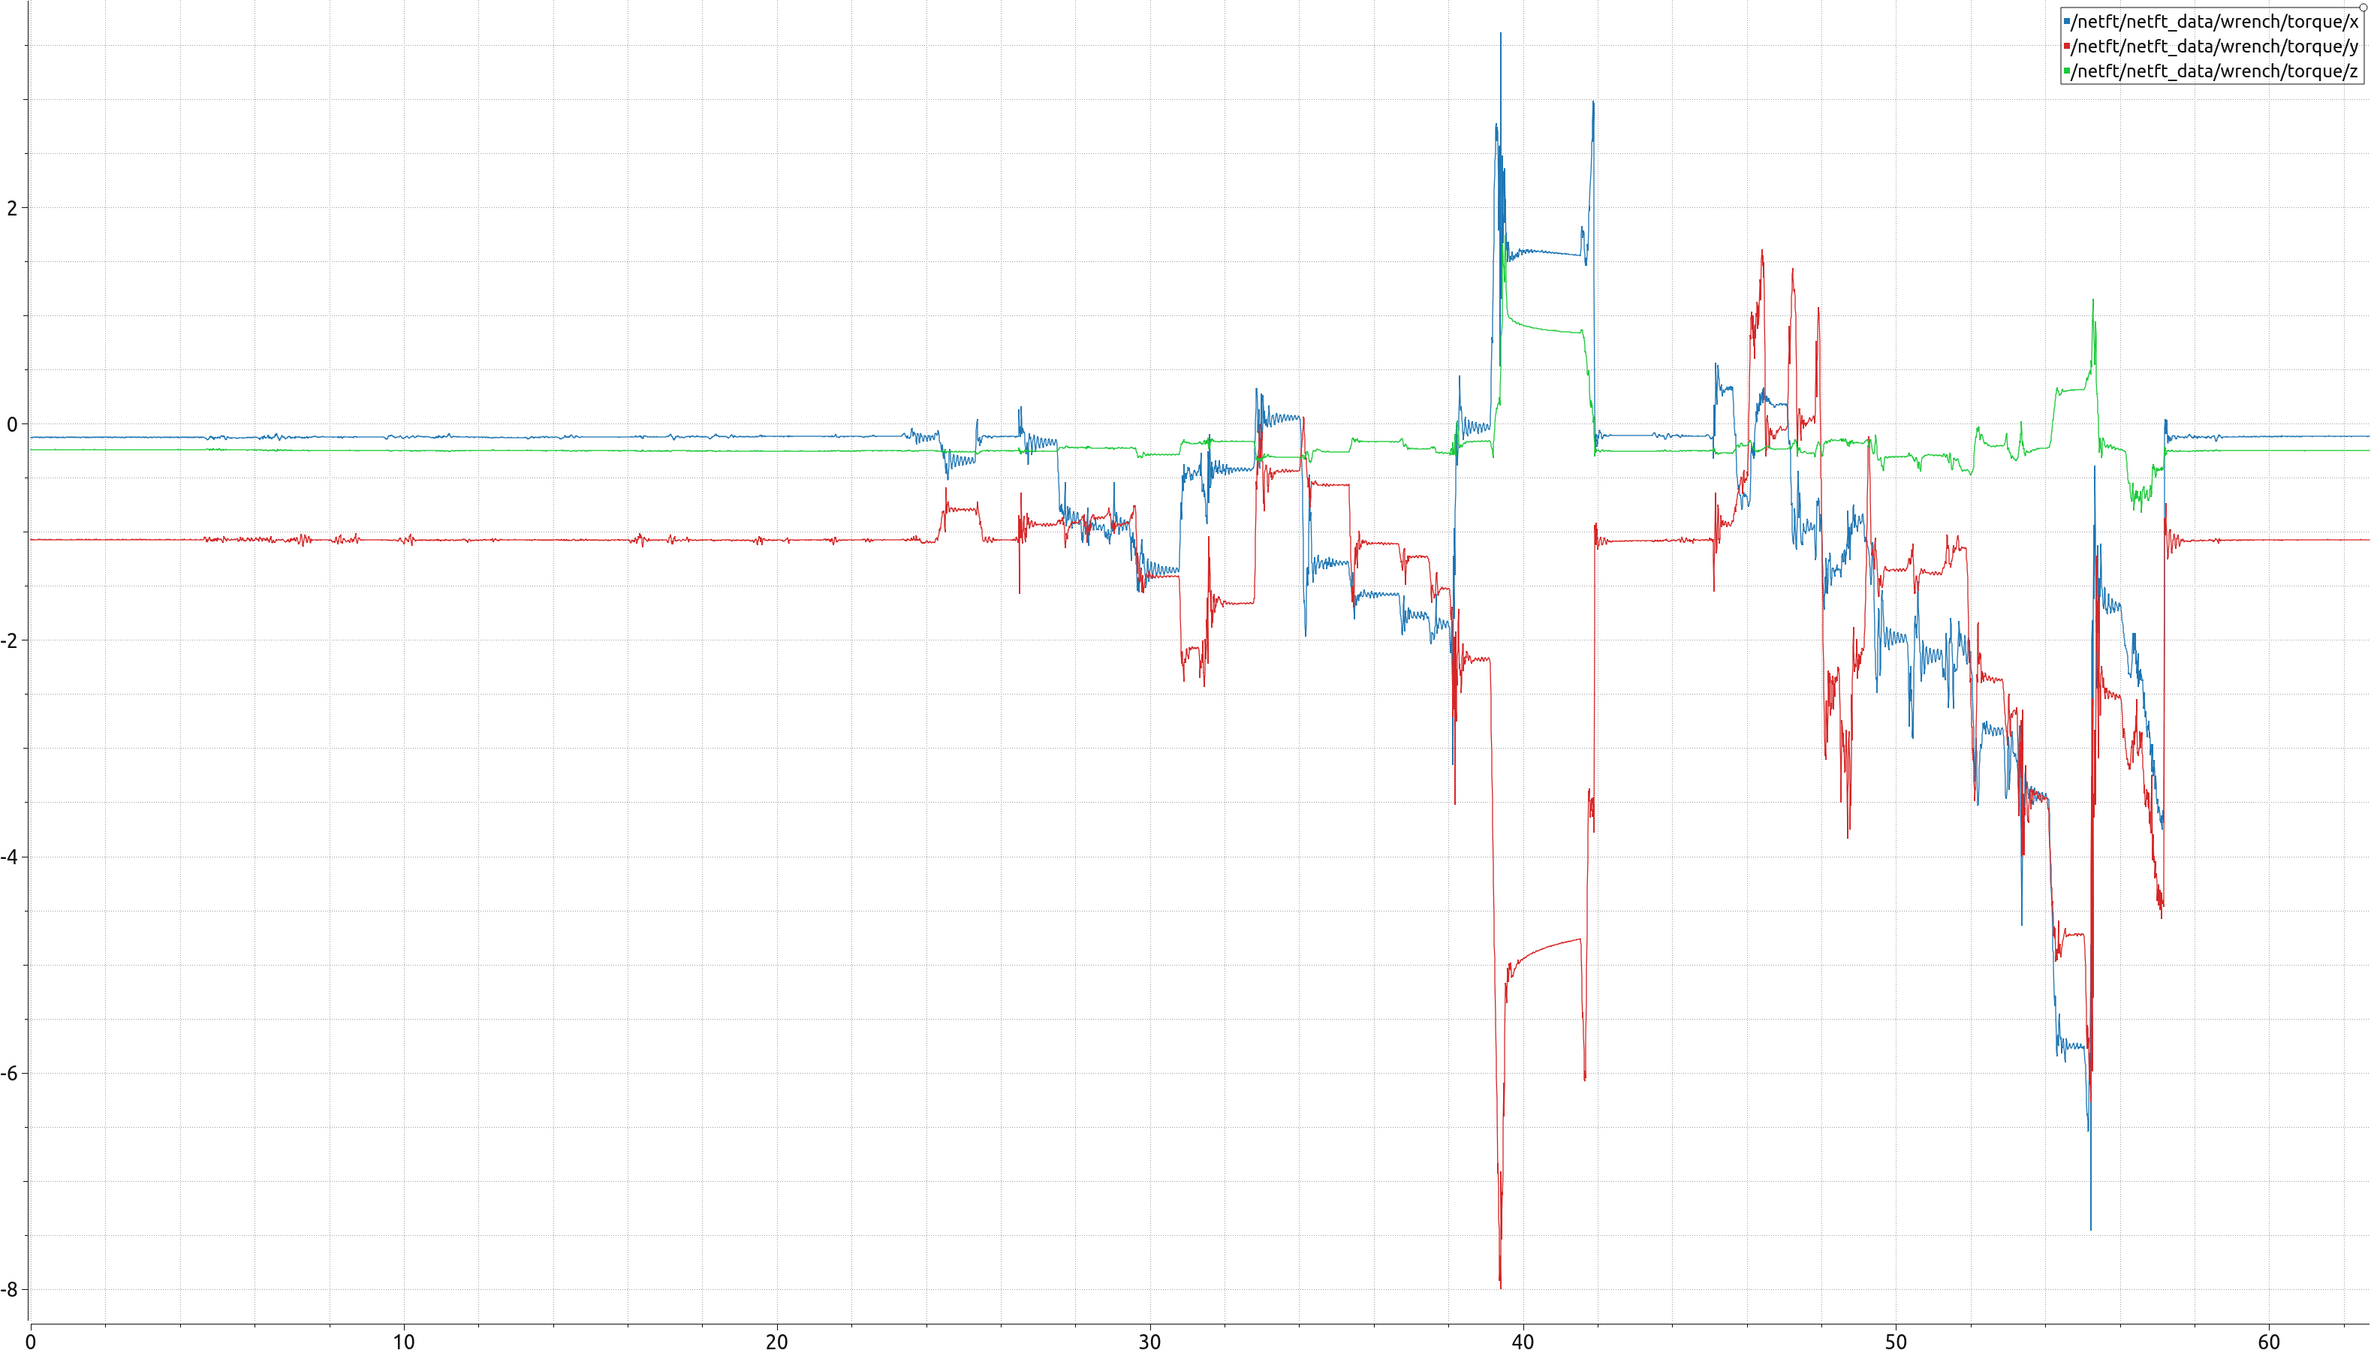
Progress Oct 17th
- Real Robot setup - Done
- LfD Setup - Done
- Formulation
- Scene Reprenstation
- Scene Estimation
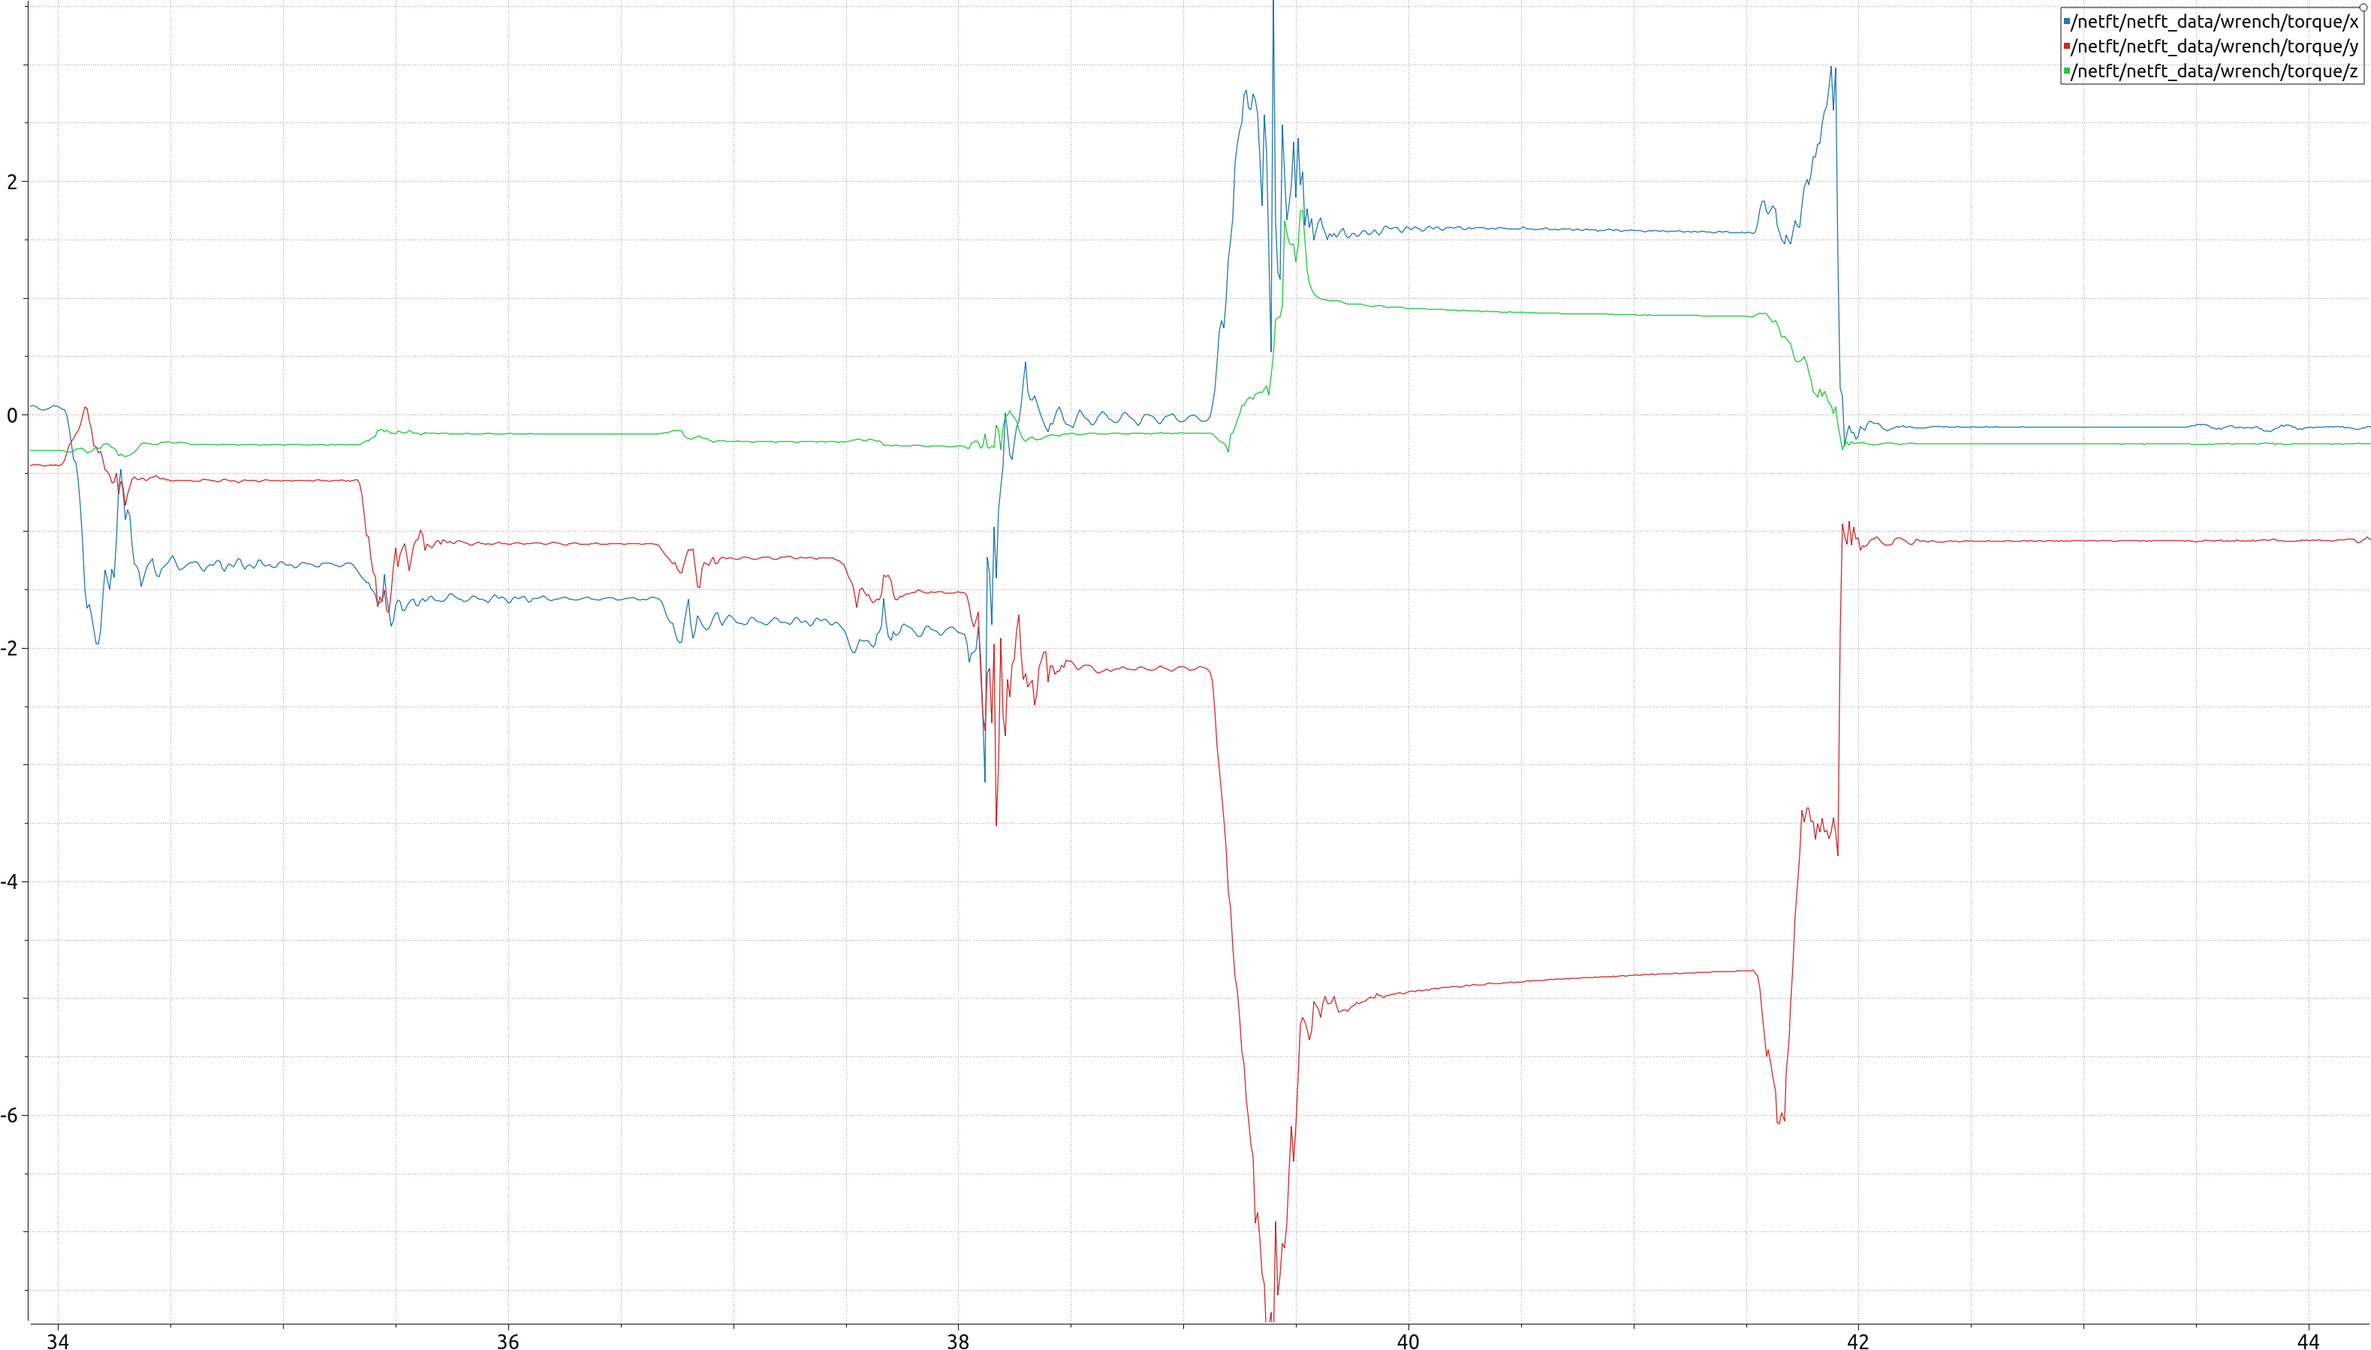
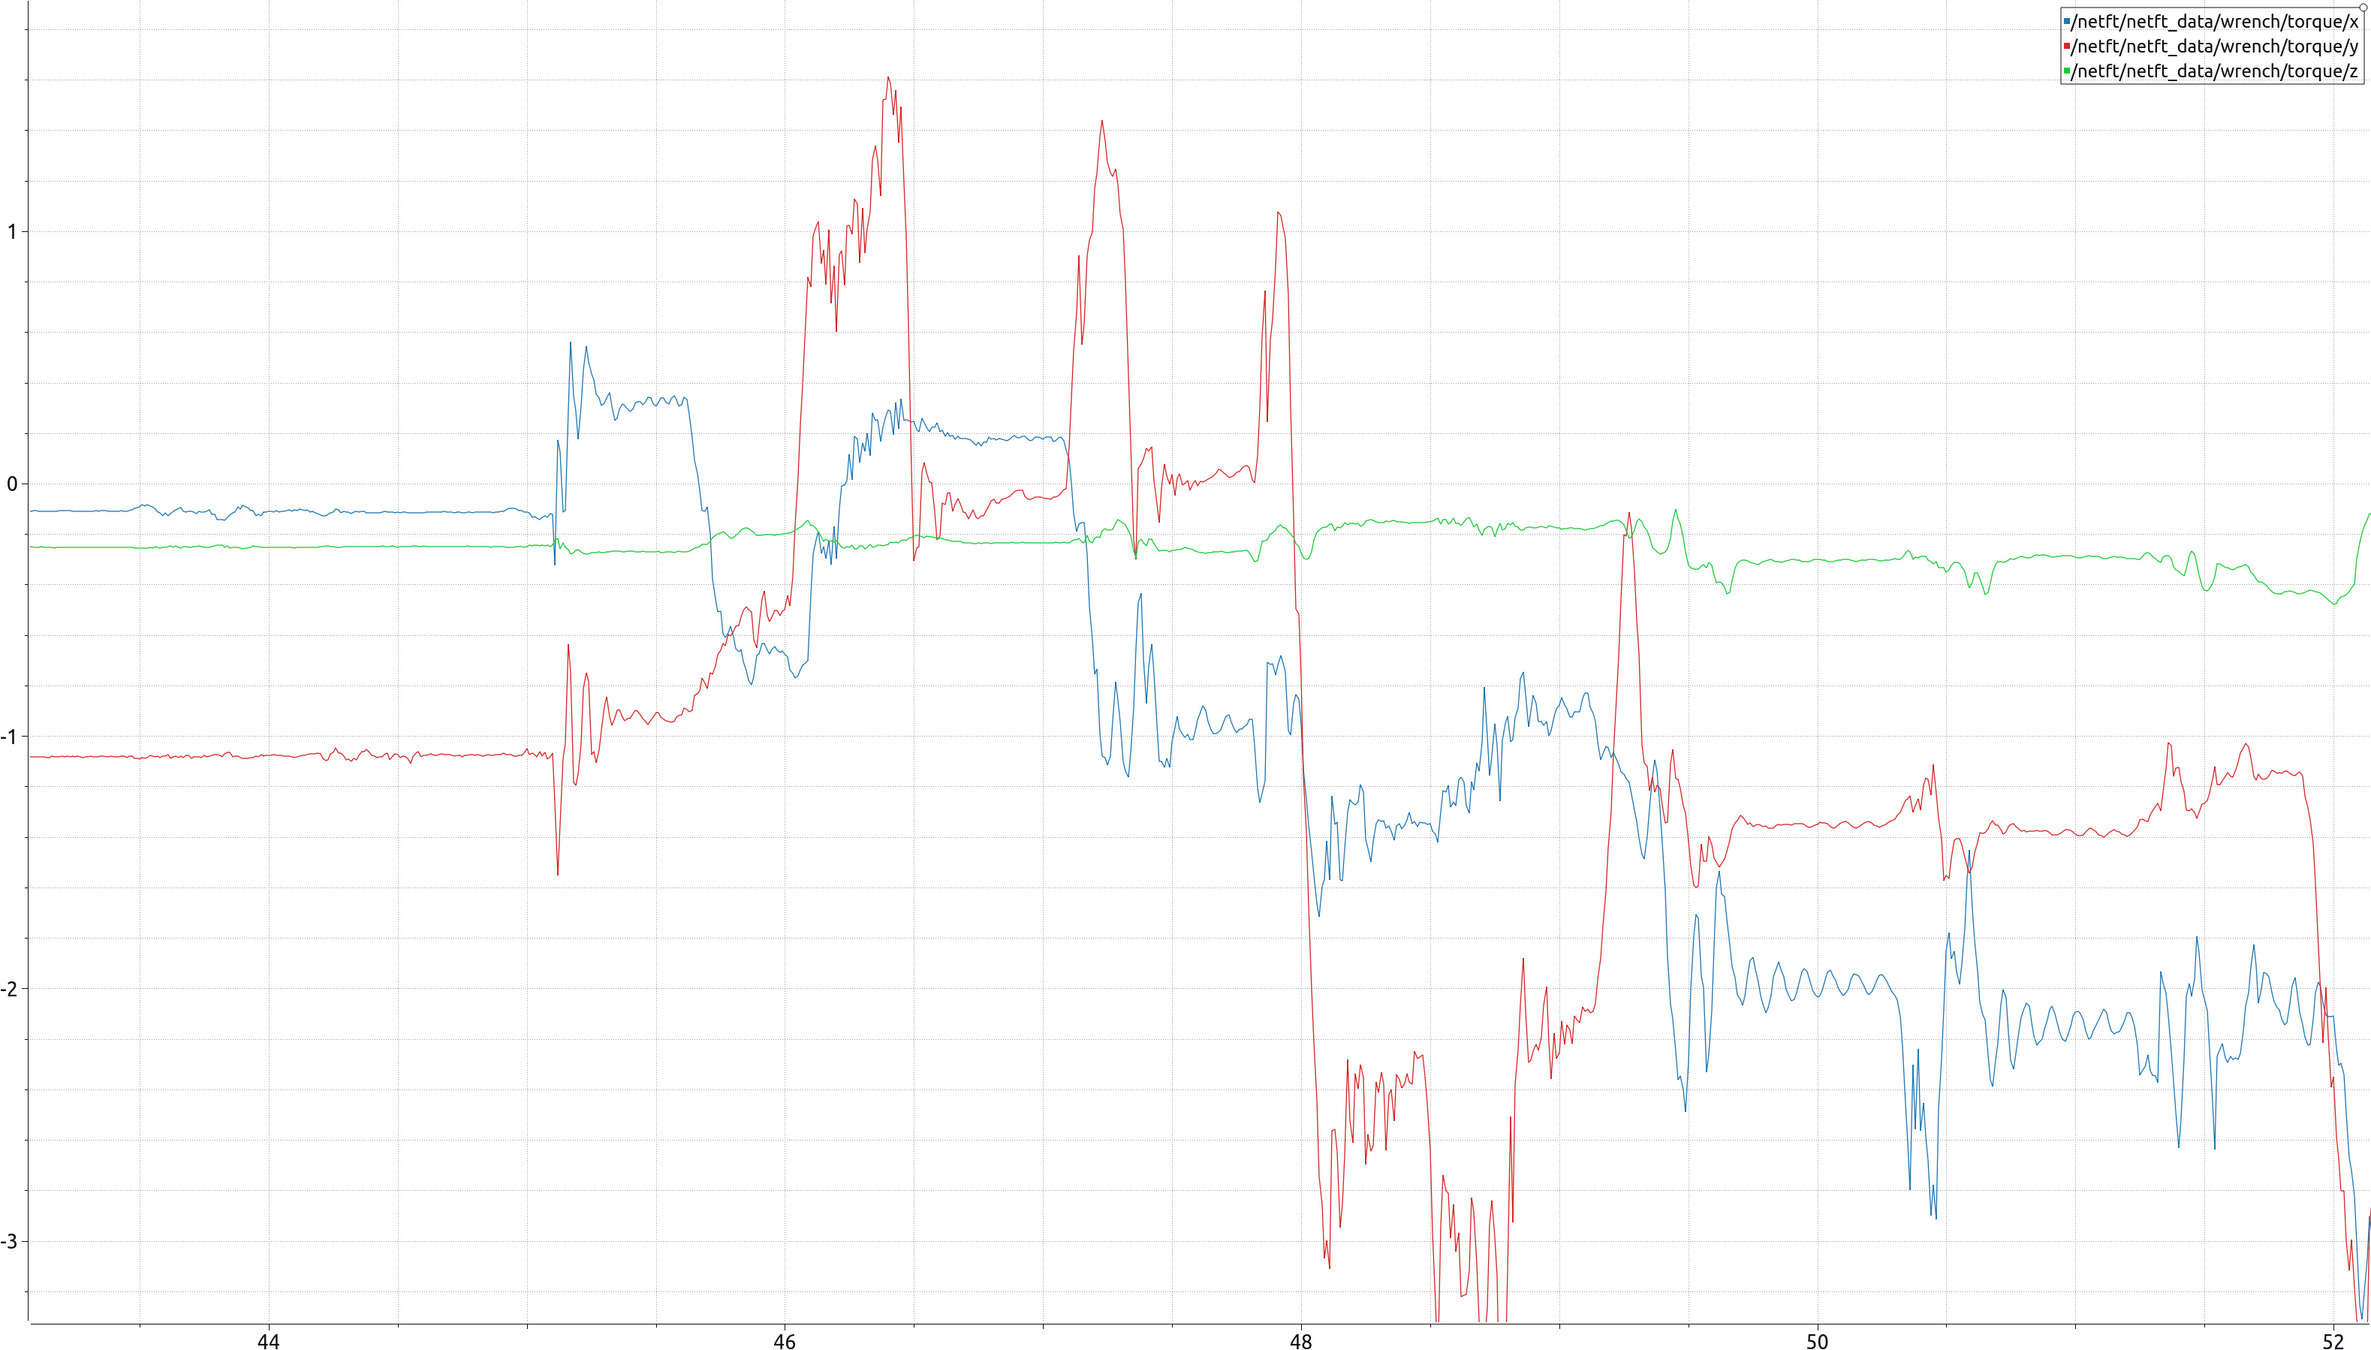
Progress Oct 3rd
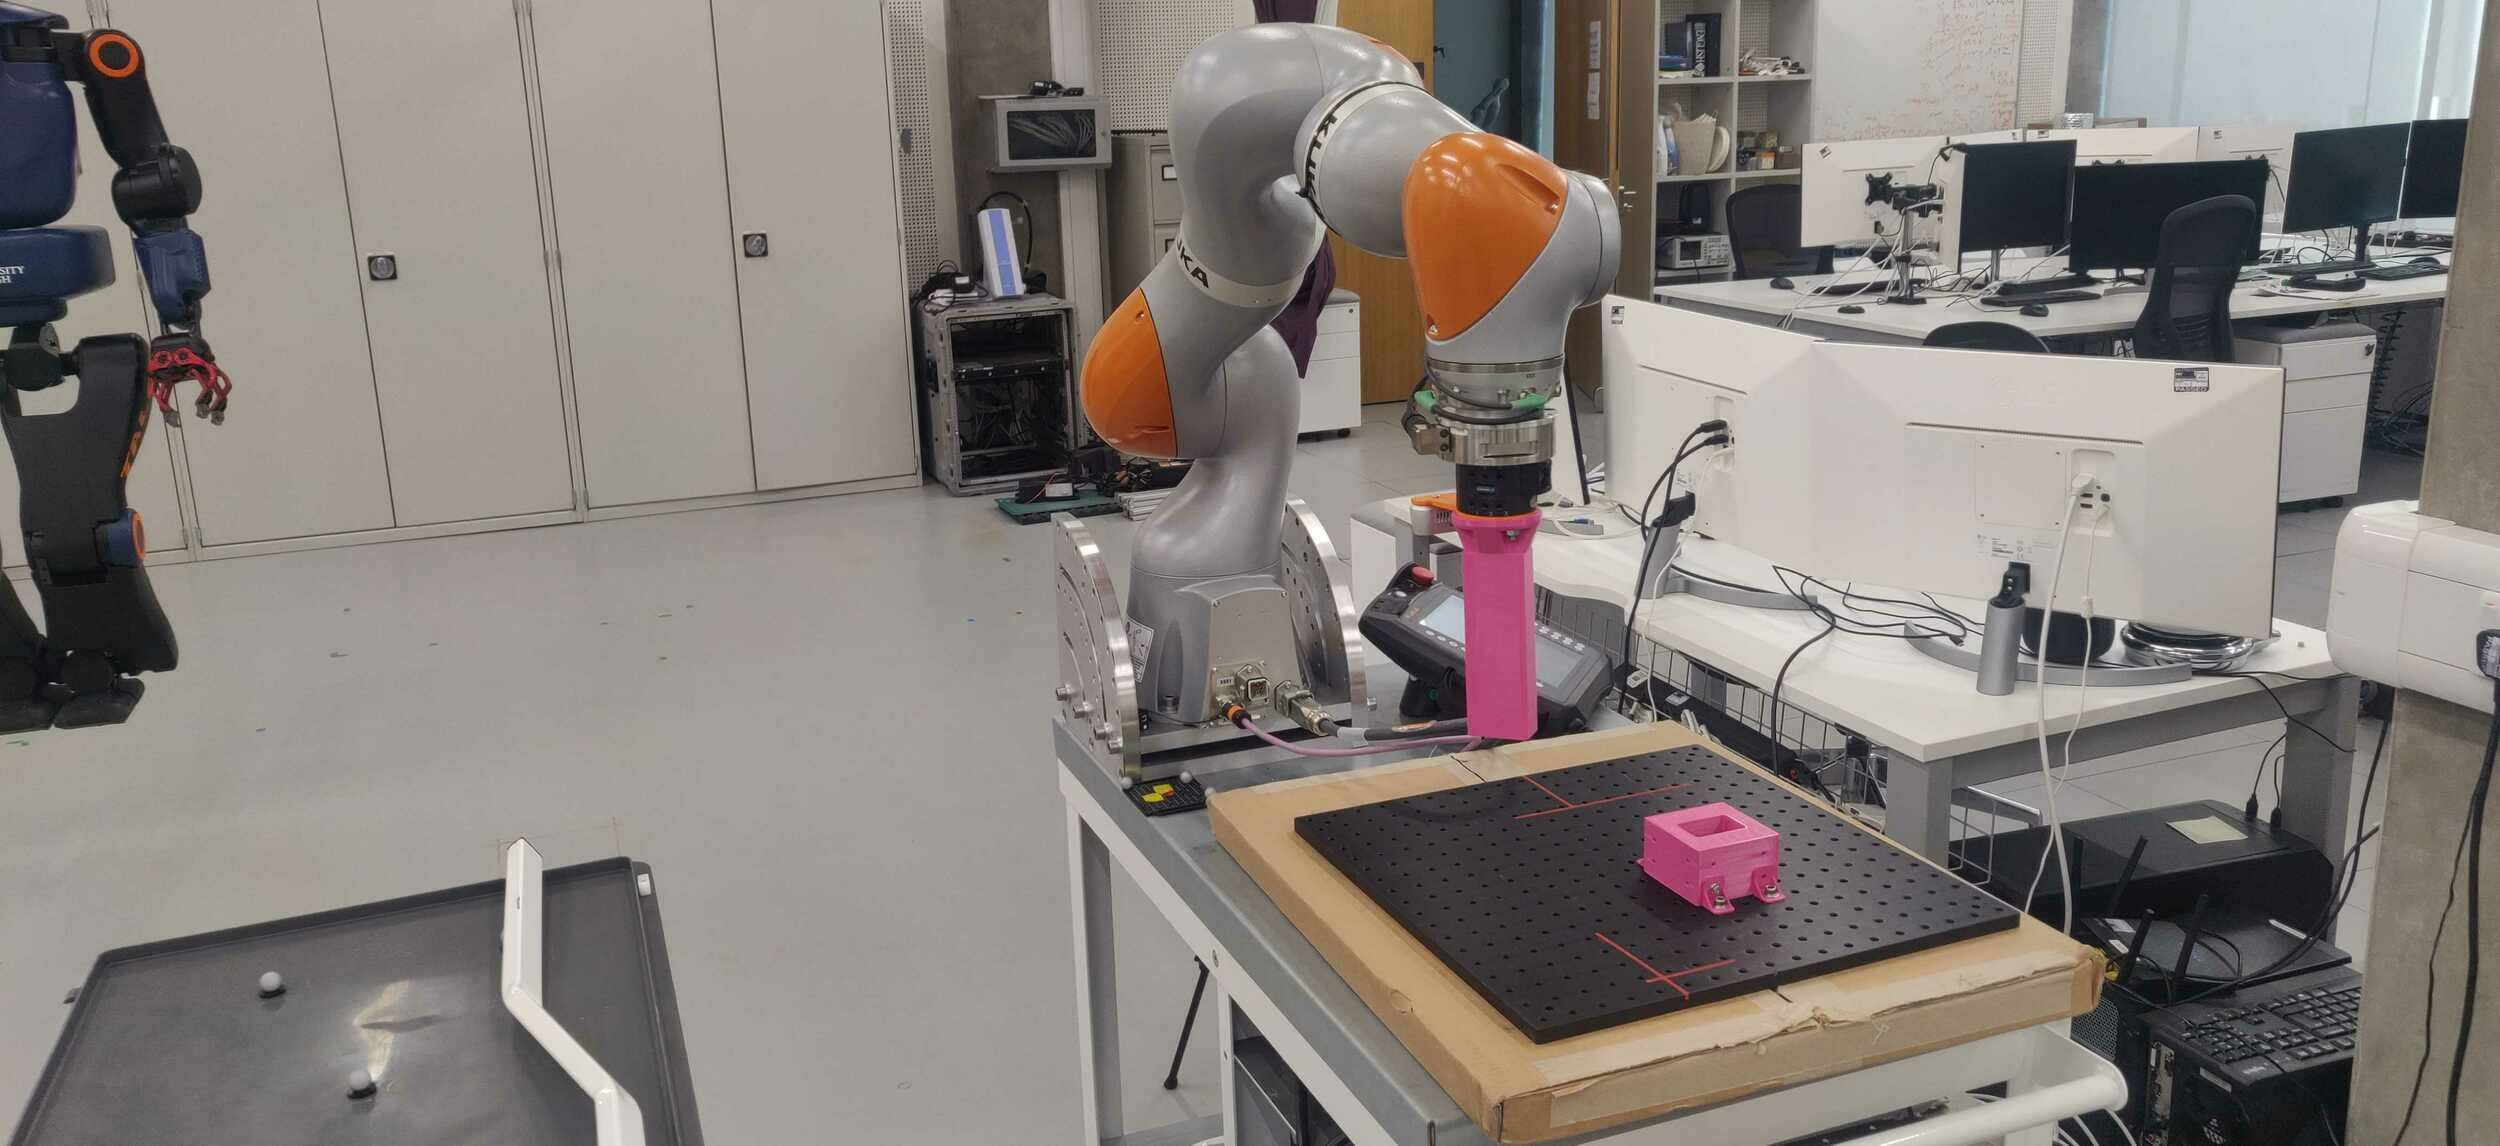
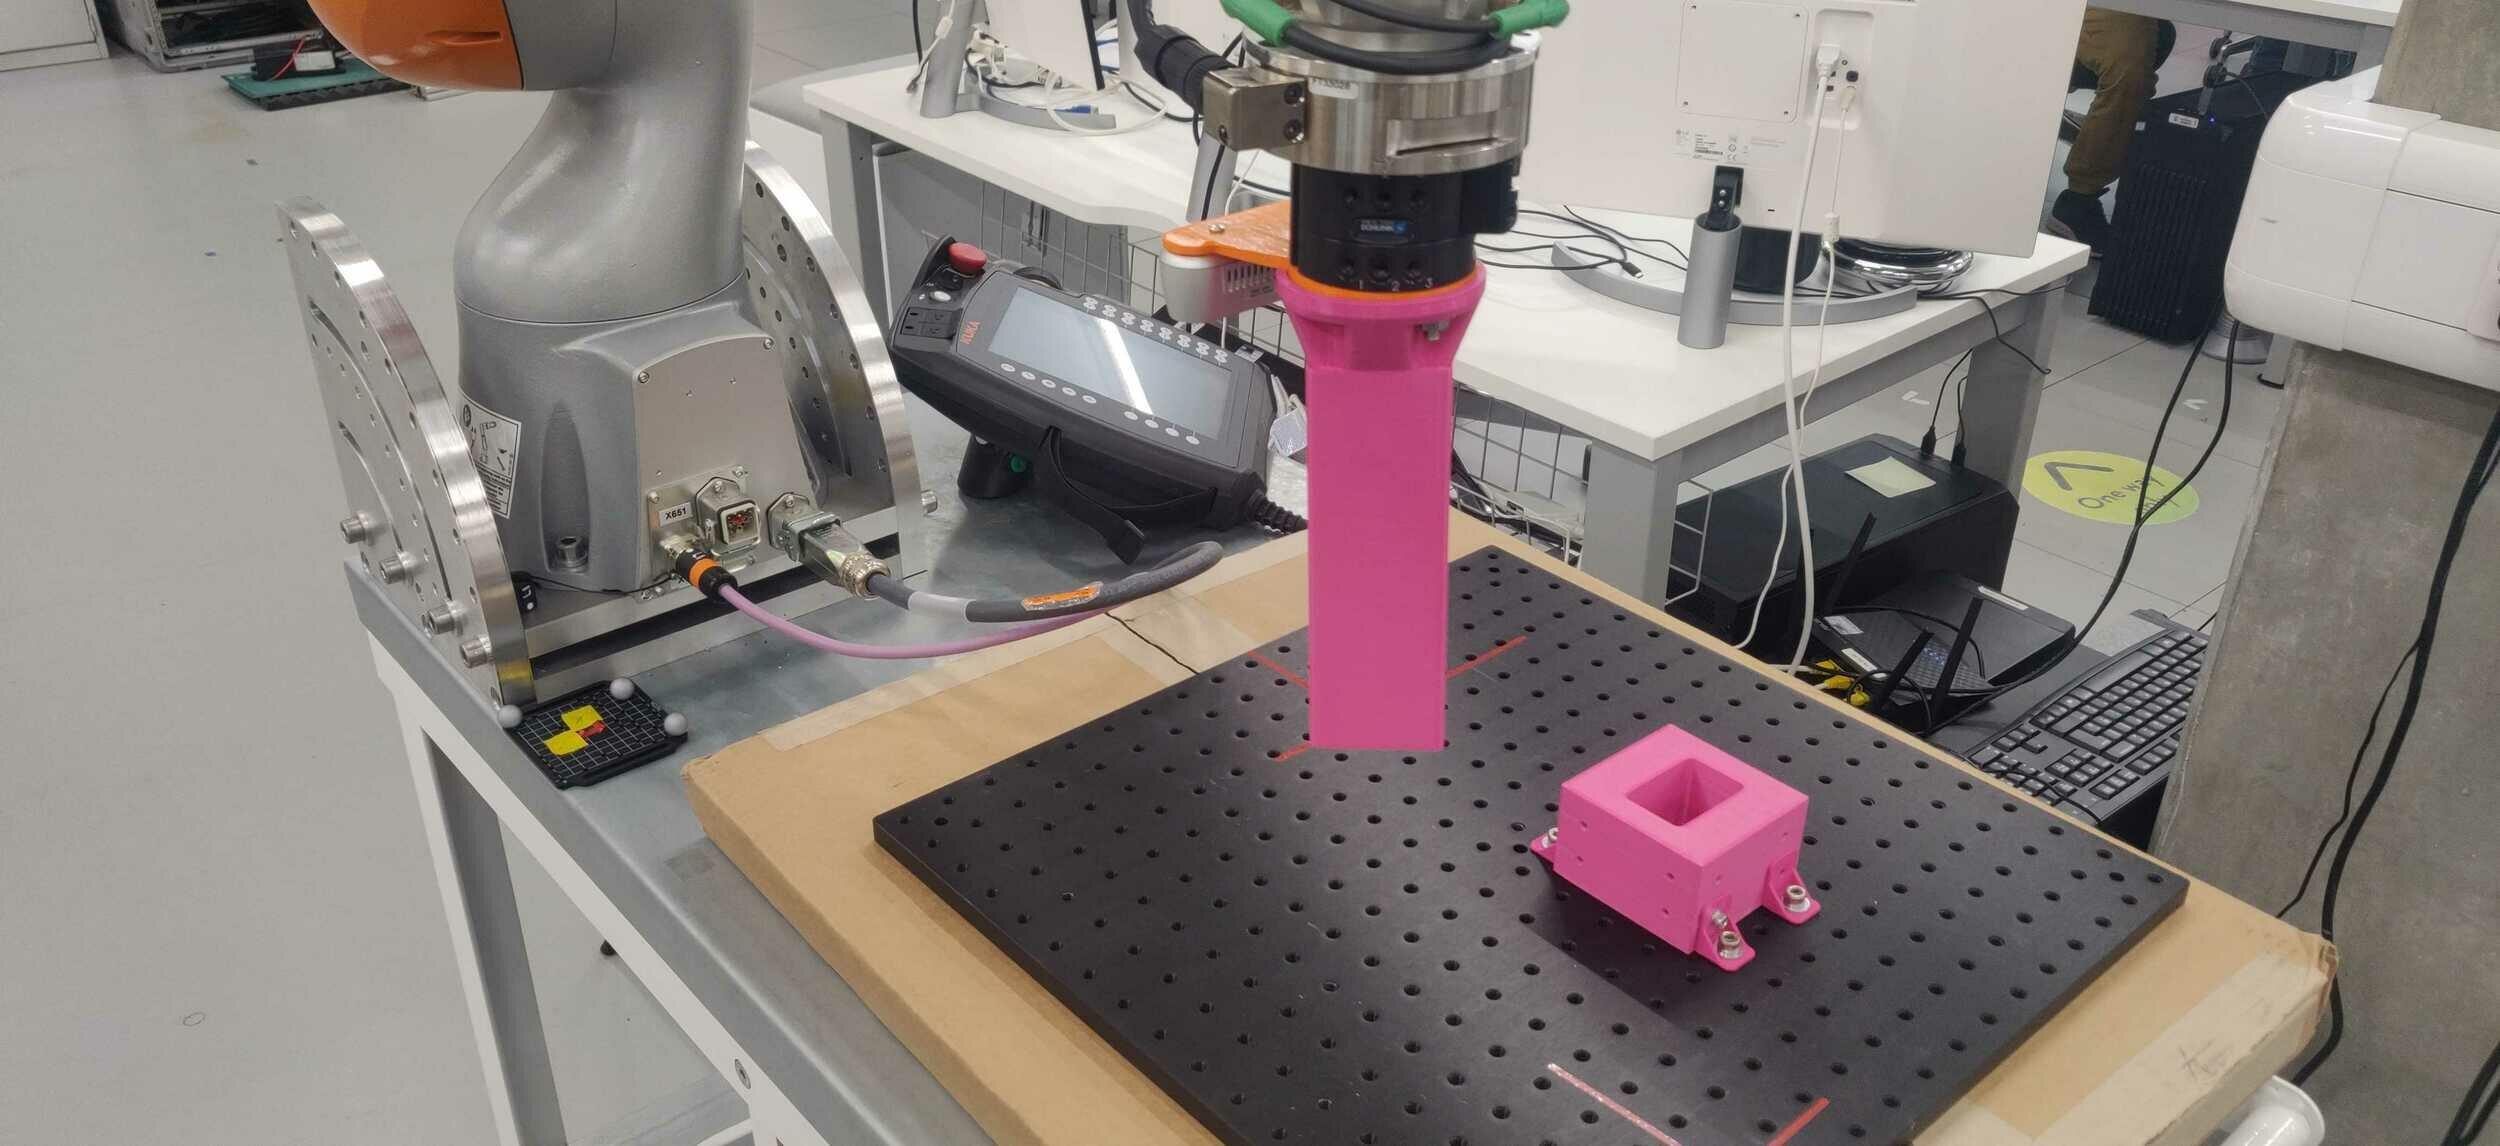
- Real Robot setup
- LfD Setup
- Formulation
- Scene Reprenstation
- Scene Estimation
Progress May 31st
Peg Insertion System - P1
- Integrated MultiDiGraph instead of the Queue representation inside the BT.
Working on
- Force thresholding for prismatic motion
- Failure reacrtivity within BT
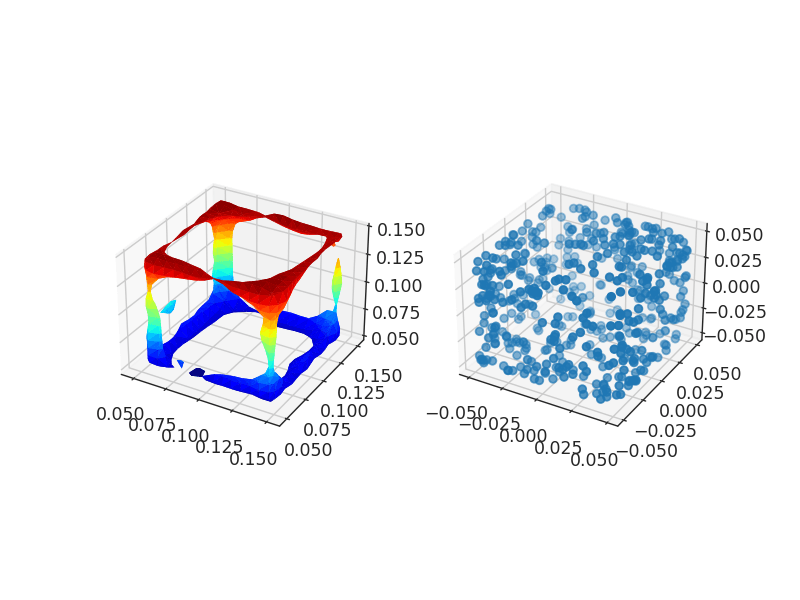
- Local search - Utilising Implicit Surfaces
Force reasoning formulation - P2
- Writing and reading
- Forceful Kinematic Chain
Baselines - P3
- Sequential dexterity
- SERL
Progress July 18th
Peg Insertion System
- What do I have? - Factor Graph integration with real robot.
Working on
- Setting up search problem. This will be with force reasoning
- Real Robot infrastructure - F/T sensors - using onRobot sensors until ATI arrive
Force reasoning formulation - P2
- Forceful Kinematic Chain - using analytical model limit surfaces. Motivating data driven models.
Baselines - P3
- SERL
Progress May 9th
Peg Insertion Demo - P1
- Integrating Behaviour Tree and Factor Graph for Kinematic Guard Conditions.
Force reasoning formulation
- Writing and reading
- Forceful Kinematic Chain
Baselines - P2
- Sequential dexterity
- SERL
Teleop
BT-KM-FG
Progress May 9th
Teleop
Progress May 9th
Teleop
BT-KM-FG
Open Loop
Progress May 9th
Teleop
BT-KM-FG
Progress May 1st
Peg Insertion Demo - P1
- Space mouse for teleoperation data collection - Done
- Factor Graph Inference of free space kinematic motion - Done.
- Integrating Behaviour Tree and Factor Graph as Guard Conditions - Todo
Force reasoning
- Fleshing out ideas on Dynamics Factor Graph
- Planning through contact vs. Forceful Manipulation
- "Robust Planning for Multi-stage Forceful Manipulation" - Holladay et al.
- Forceful Kinematic Chain
Baselines - P2
Update April 24th
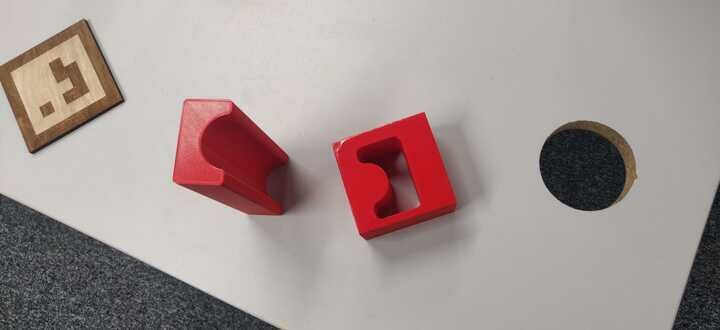
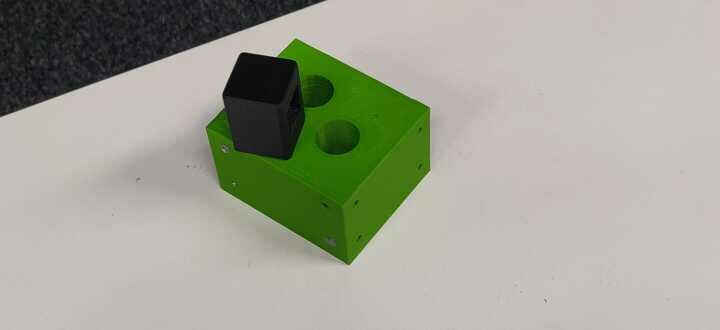
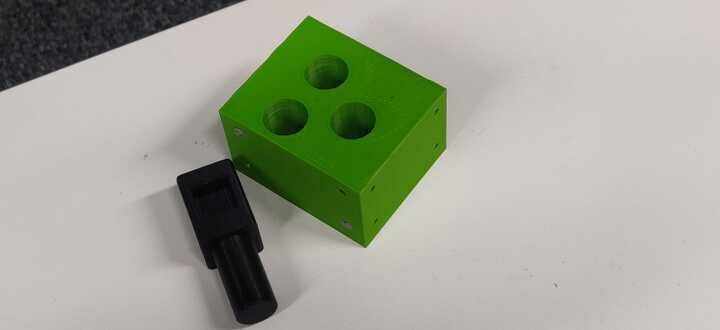
Peg Insertion task - P1
- Space mouse for teleoperation data collection
- Collect data for Kinematic Factor Graph - Kinesthetic Demonstrations
- Fleshing out ideas on Dynamics Factor Graph
- Planning through contact vs. Forceful Manipulation
- "Robust Planning for Multi-stage Forceful Manipulation" - Holladay et al.
- Forceful Kinematic Chain
Baselines - P2
- Same setup to be used for collecting data
- Train DrQ on Peg Insertion Task
- Todo:
- Gpu inference during deployment.
- Camera setup for training and deployment.
Update April 19th
Work past weeks:
-
SERL control stack ROS1
-
Variable Impedance Control ROS1
Work upcoming week
-
Basic demonstration of Factor Graph reasoning
- Pick a low stiffness controller for
approach - Pick a higher stiffness controller for
insert - Show switching behaviour after kinematic alignment
- Write up
- Pick a low stiffness controller for
- Policy baselines
VIC - ROS1
Gravity Compensation
Cartesian Stiffness Controller
Translation - H.stiff
Rotation - L.stiff
Rotation stiffness
Update Slides
By Aditya Kamireddypalli