Solving cubic matrix equations arising in conservative dynamics
Milo Viviani
(joint work with prof. Michele Benzi)
Scuola Normale Superiore - Pisa
Due Giorni di Algebra Lineare Numerica e Applicazioni
Napoli, 14-15 Febbraio 2022
Introduction
Isospectral flows
\dot{Y} = [\mathcal{L} Y,Y]\\
Y(0)=Y_0
- \(Y_0\in \mathbb{M}(N,\mathbb{C})\), \(\mathcal{L}:\mathbb{M}(N,\mathbb{C})\rightarrow\mathbb{M}(N,\mathbb{C})\) linear
- \([A,B] = AB - BA\)
- The spectrum of \(Y\) is time-invariant
- \(\mathcal{L}\) self-adjoint w.r.t. Frobenious inner product \(\Rightarrow\) flow Hamiltonian w.r.t. \(H=\frac{1}{2}Tr(\mathcal{L}YY^*)\)
Geometric integration of isospectral flows
(I - h \mathcal{L} X_n)X_n(I + h \mathcal{L} X_n) := Y_n\\
(I + h \mathcal{L} X_n)X_n(I - h \mathcal{L} X_n) =: Y_{n+1}
- Second order in time (\(h\) is the time-step)
- Spectrum of \(Y\) exactly preserved
- Hamiltonian conserved up to \(\mathcal{O}(h^2)\)
Cubic equation
(I - h\mathcal{L} X)X(I + h \mathcal{L}X) = Y \ \ (*)
- \(X\) unknown
- \(Y\in \mathbb{M}(N,\mathbb{R}) \ or \ \mathbb{M}(N,\mathbb{C})\) given
Thm. Given \(Y\in\mathbb{M}(N,\mathbb{C})\), equation (*) has a unique solution for sufficiently small \(h>0\) in some neighbourhood of \(Y\).
Furthermore, when equation (*) takes place in \(\mathfrak{su}(N)\), there exists such a neighbourhood for any \(h\leq\frac{1}{3\|\mathcal{L}\|_{op}\|Y\|}\).
Numerical schemes
Explicit fixed point iteration
X_{k+1}:=Y + h[\mathcal{L} X_k,X_k] + h^2\mathcal{L} X_k X_k \mathcal{L}X_k
- Convergence is guaranteed by the Theorem above, for \(h\) sufficiently small and \(X_0:=Y\)
- The complexity is \(\mathcal{O}(N^3)\)
- Only two matrices multiplications are required when working in \(\mathfrak{su}(N)\)
Linear iteration
P_k := \mathcal{L}X_k\\
(I - hP_k)X_{k+1}(I + h P_k) := Y
- Convergence can be derived by the Theorem above, for \(h\) sufficiently small and \(X_0:=Y\)
- The complexity is \(\mathcal{O}(N^3)\)
- To solve the second equation we take the LU-factorization of \(I\pm hP_k\)
Inexact Newton iteration
G(X)=0
\(G(X):=X - h[\mathcal{L} X,X]- h^2(\mathcal{L} X)X(\mathcal{L} X) - Y\)
\(DG(X)=I - h(\mathcal{B}_1 + h\mathcal{B}_2)\)
\(\mathcal{B}_2=(\mathcal{L}\cdot)X(\mathcal{L}X)+(\mathcal{L}X)\cdot(\mathcal{L}X)+(\mathcal{L}X)X(\mathcal{L}\cdot)\)
\(\mathcal{B}_1=[\mathcal{L}\cdot,X]+[\mathcal{L}X,\cdot]\)
Inexact Newton iteration
Need an approximation for \(DG(X)^{-1}\)
- \(DG(X)^{-1}\approx I + h\mathcal{B}_1\) [Exact 1st order]
- \(DG(X)^{-1}\approx I + h\mathcal{B}_1 + h^2\mathcal{B}_2\)
- \(DG(X)^{-1}\approx I + h\mathcal{B}_1 + h^2\mathcal{B}_1^2\)
- \(DG(X)^{-1}\approx I + h\mathcal{B}_1 + h^2(\mathcal{B}_1^2+\mathcal{B}_2)\) [Exact 2nd order]
Rmk. the second one is the best compromise between exactness and computational cost
- The total complexity is \(\mathcal{O}(N^3)\)
Numerical experiments
Euler Equations
Spatial semidiscretization of the Euler equations on a compact orientable surface \(S\), \(\omega_t\in C^\infty(S)\)
\(\dot{\omega}=\nabla\omega\cdot\nabla^\perp\Delta^{-1}\omega\)
Give the Hamiltonian isospectral flow on \(\mathfrak{su}(N)\), for \(N\geq 1\)
\(\dot{W}=[W,\Delta_N^{-1}W]\)
Rmk. \(\Delta_N\) is tridiagonal, the evaluation of \(\Delta_N^{-1}W\) (via LU-factorization done once) requires \(\mathcal{O}(N^2)\) operations
Euler Equations
Time-step \(h=0.5\), normalized initial data
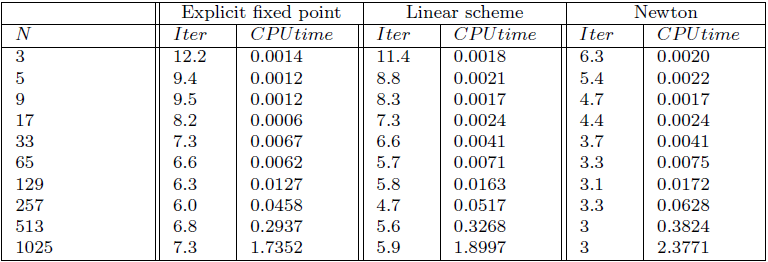
Rmk. Explicit fixed point performs the best in terms of CPU time
Heisenberg spin chain
Spatial semidiscretization of the Landau–Lifshitz–Gilbert Hamiltonian PDE, \(\sigma_t:S^1\rightarrow S^2\)
\(\dot{\sigma}=\sigma\times\partial_{xx}\sigma\)
Give the Hamiltonian isospectral flow on \(\mathfrak{su}(2)^{\oplus_N}\), for \(N\geq 1\)
\(\dot{S}_i=[S_i,S_{i-1}+S_{i+1}]\)
for \(i=1,...,N\) with \(S_1\equiv S_N\)
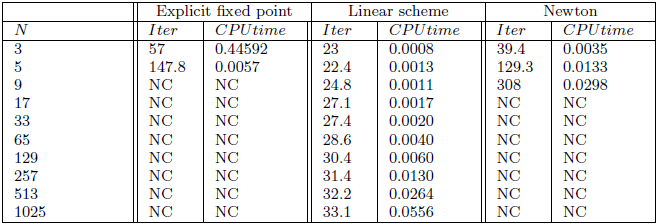
Time-step \(h=0.5\), normalized initial data
Rmk. Explicit fixed point performs the best in terms of stabilty and CPU time.
Heisenberg spin chain
An unpractical scheme
Quadratic iteration
(I - h P_k)X_k(I + h P_k) := Y\\
\mathcal{L} X_{k+1} := P_k
-
The first equation is CARE (Continuous Algebraic Riccati Equation) in \(P_k\)
- Non-uniqueness issues
h^2PXP + h[P,X] + Y - X = 0
Conclusions
Conclusions
- Iterative schemes for the solution of cubic matrix equations arising in the numerical solution of certain conservative PDEs
- Geometrical integrators: preservation of important physical features
- Both fixed point iterations and inexact Newton work well
- Fixed point iterations more efficient for large time-step and large dimensions
- Implicit fixed point iteration is more stable
Thanks for your attention
Solving cubic matrix equations arising in conservative dynamics_short
By Milo Viviani


