Sarah Dean PRO
asst prof in CS at Cornell
Prof. Sarah Dean
MW 1:25-2:40pm
155 Olin Hall
*accommodations possible, email me ASAP
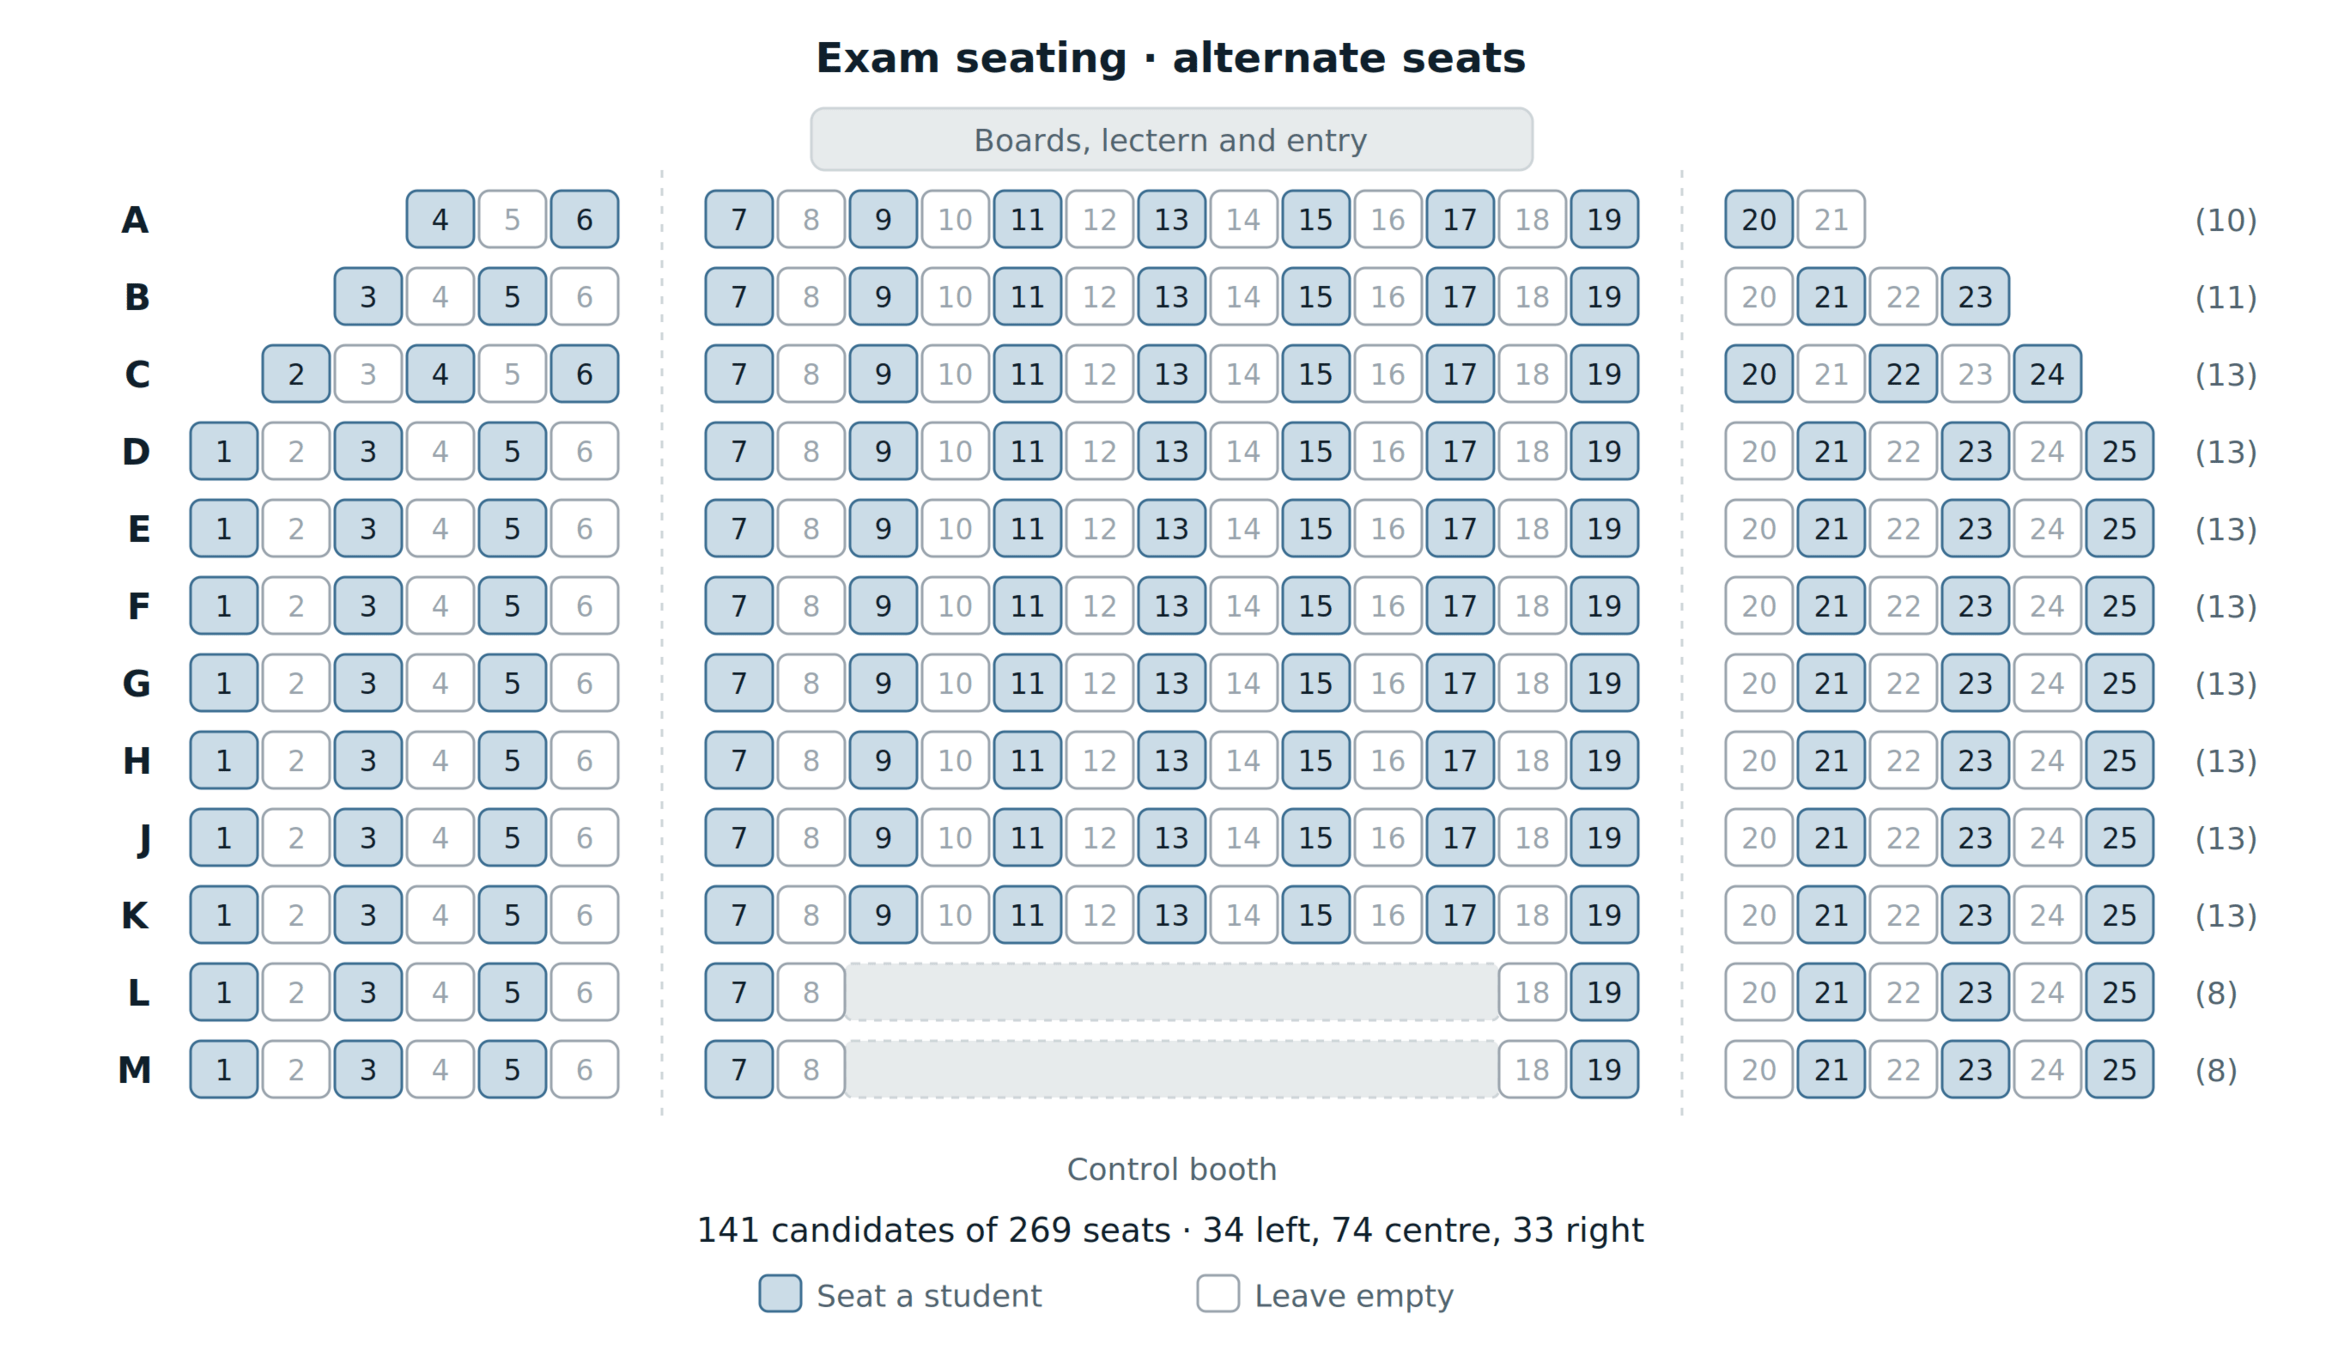
Help me check the seat map!
How can we evaluate policies over indefinite horizons?
Suppose our policy always takes a fixed action \(a\).
Define a vector \(U\in\mathbb R^{|\mathcal S|}\) such that $$\mathbb E_{s'\sim P(\cdot|s,a)}[V(s')] = U^\top V$$
Given a policy \(\pi(\cdot)\) and a transition function \(P(\cdot\mid \cdot,\cdot)\)
\(P_{\pi}=\)
\(s\)
\(s'\)
\(\mathbb E_{a\sim\pi(s)}[P(s'\mid s,a)]\)
\(s\)
\(s'\)
\(P(s'\mid s,\pi(s))\)
\(V^\pi(s)\)
\(r(s,\pi(s))\)
By Sarah Dean