Modern problems in Biomedical Imaging
2026 Workshop on MR Phase, Magnetic Susceptibility and Electrical Properties Mapping
Jeremias Sulam
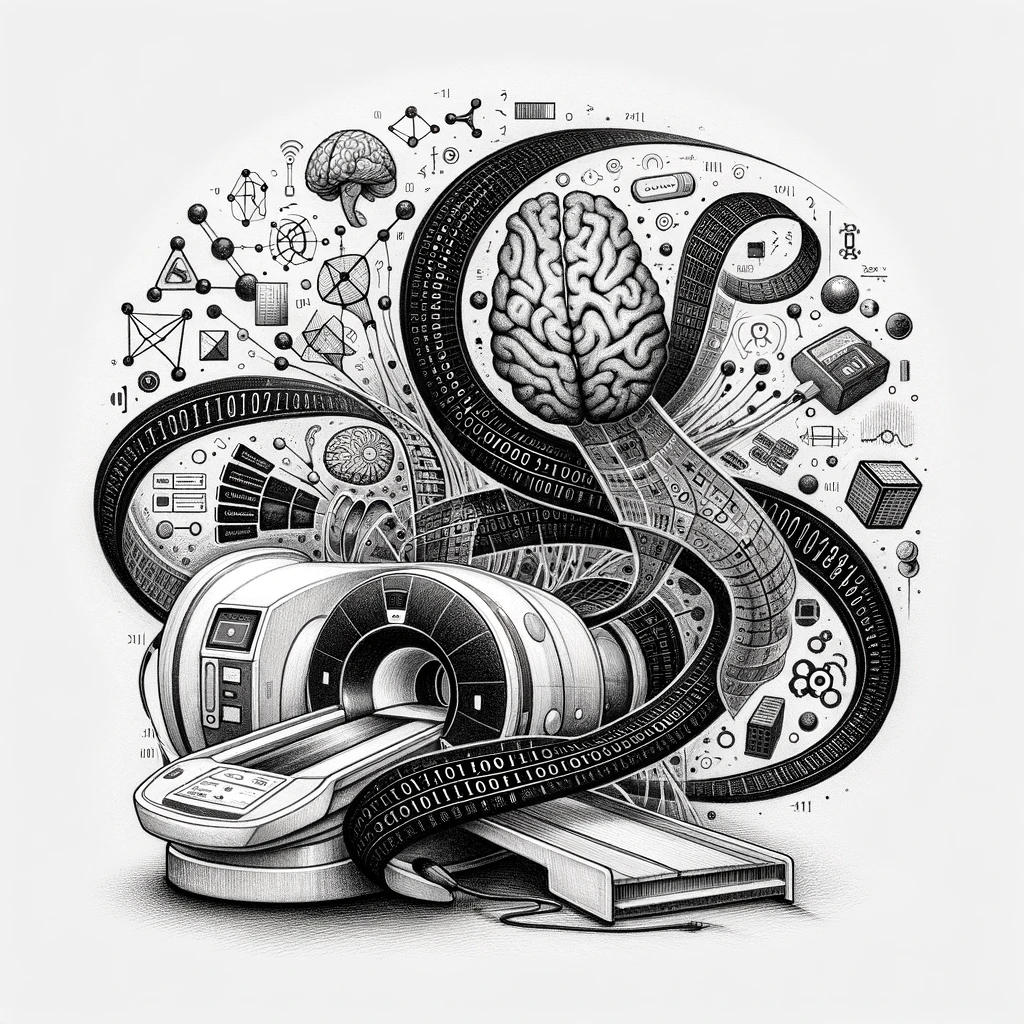
50 years ago ...
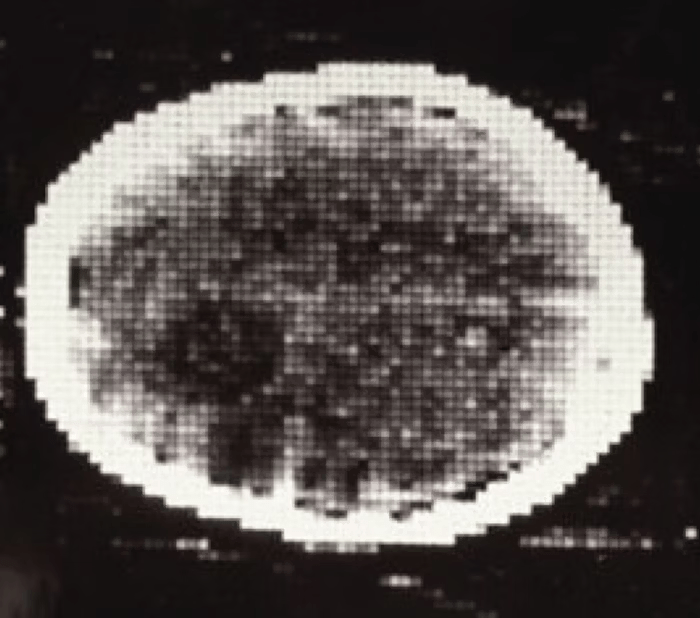
first CT scan
ELECTRIC & MUSICAL INDUSTRIES
50 years ago ...
imaging
diagnostics
complete hardware & software description
human expert diagnosis and recommendations
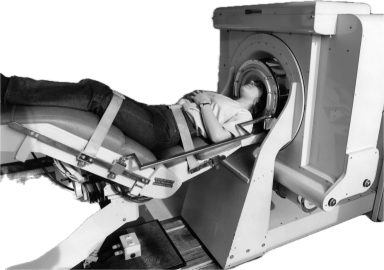
imaging was "simple"
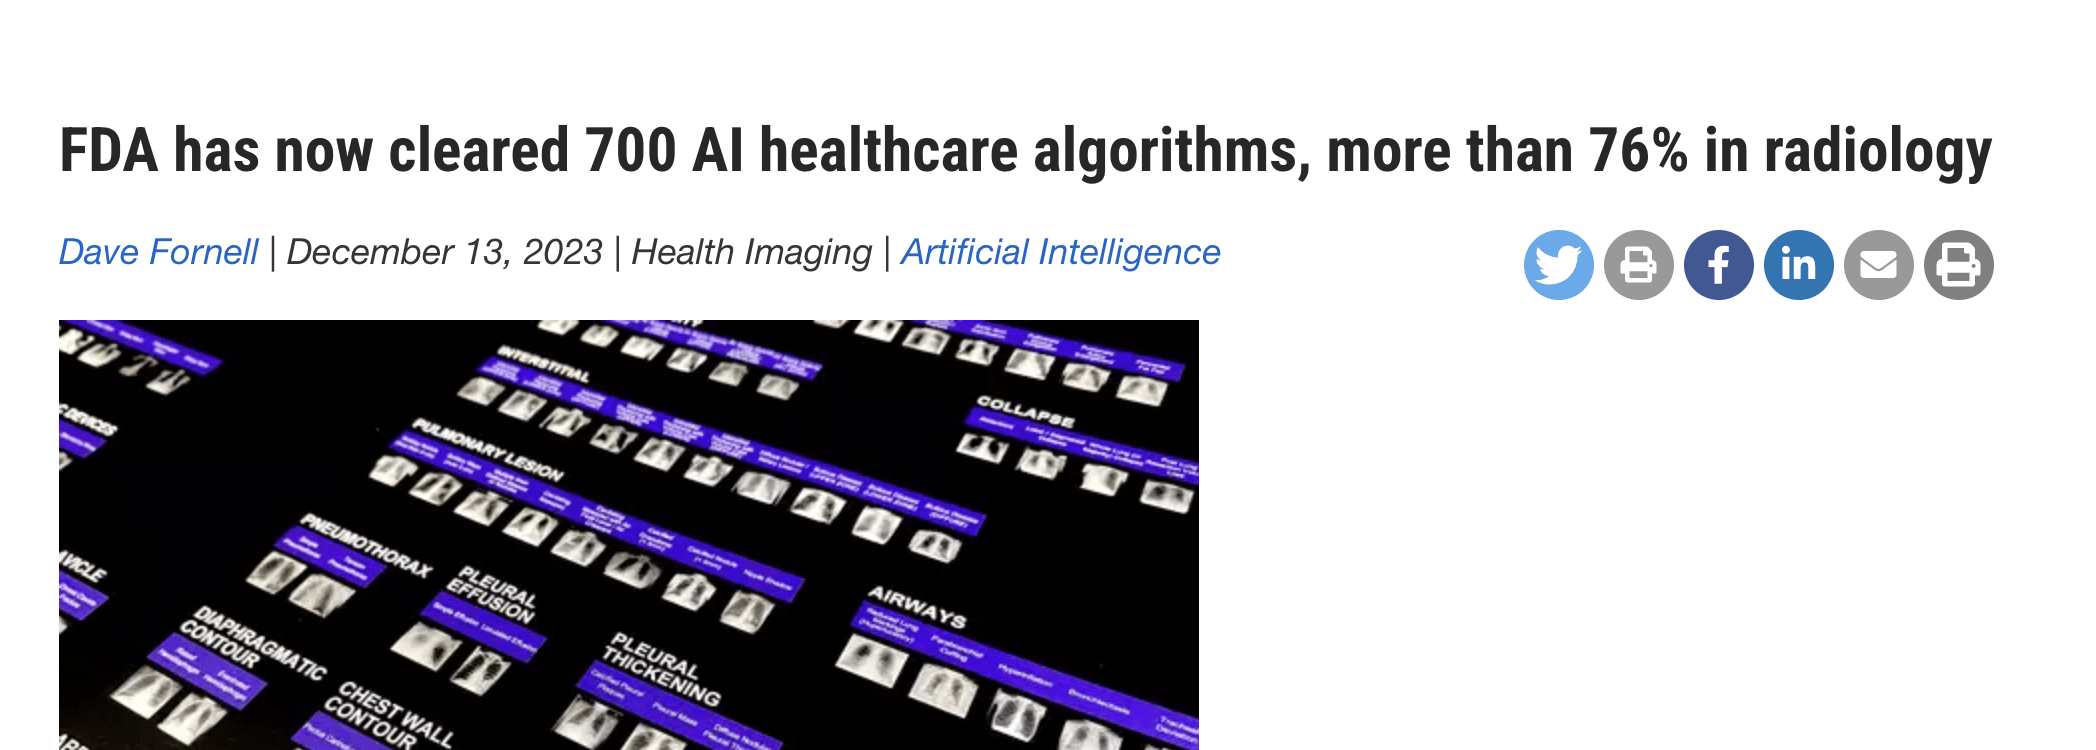
... 50 years forward
Data
Compute & Hardware
Sensors & Connectivity
Research & Engineering
... 50 years forward
data-driven imaging
automatic analysis and rec.
societal implicationsData
Compute & Hardware
Sensors & Connectivity
Research & Engineering
data-driven imagingautomatic analysis and rec.societal implicationsProblems in trustworthy biomedical imaging
inverse problems
uncertainty quantification
robustness
generalization
demographic fairness
hardware & protocol optimization
model-agnostic interpretability
policy & regulation
monitoring & auditing
data-driven imagingautomatic analysis and rec.societal implicationsProblems in trustworthy biomedical imaging
inverse problems
uncertainty quantification
robustness
generalization
demographic fairness
hardware & protocol optimization
model-agnostic interpretability
policy & regulation
monitoring & auditing
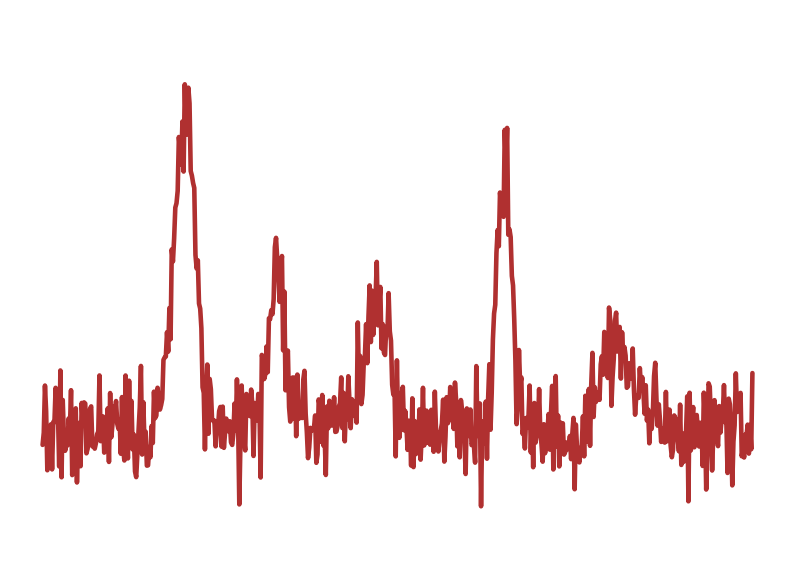
=
+
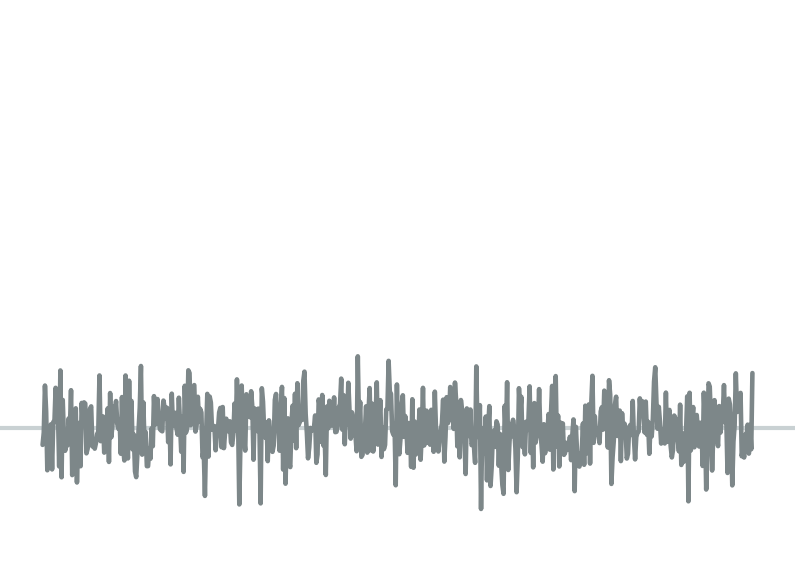
\(x\sim p_x\)
\(z\sim \mathcal N(0,\sigma^2 I)\)
\(y = x + z\)
=
\(x\sim p_x\)
+
\(z\sim \mathcal N(0,\sigma^2 I)\)
\(A~\cdot\)
\(y = Ax + z\)
estimate
Inverse Problems
\(= \underset{x}{\arg\max} ~~~ p(y|x)p_x(x)\)
\(= \underset{x}{\arg\min} ~ -\log p(y|x) - \log p_x(x)\)
\(= \underset{x}{\arg\min} ~ \frac{1}{2\sigma^2} \|y-x\|^2_2 - \log p_x(x)\)
\(\hat{x} = \underset{x}{\arg\max} ~ p(x|y)\)
Maximum a
Posteriori
estimator
MAP
likelihood
prior
\(= \text{prox}_{-\sigma^2 \log p_x}(y)\)
Inverse Problems
=
+
\(x\sim p_x\)
\(z\sim \mathcal N(0,\sigma^2 I)\)
\(y = x + z\)
Inverse Problems
=
\(x\sim p_x\)
+
\(z\sim \mathcal N(0,\sigma^2 I)\)
\(y = A x + z\)
\(A~ \cdot\)
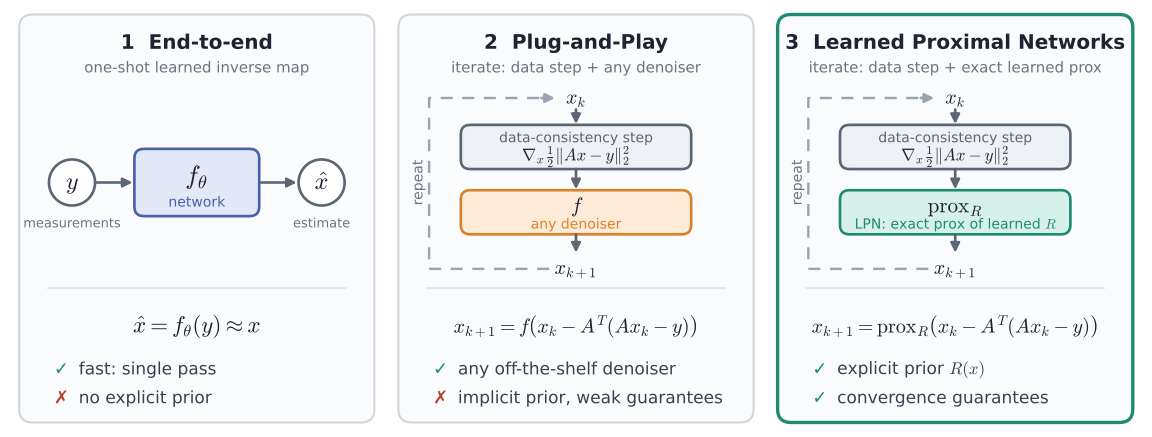
Inverse Problems
=
\(x\sim p_x\)
+
\(z\sim \mathcal N(0,\sigma^2 I)\)
\(y = A x + z\)
\(A~ \cdot\)
Inverse Problems
=
\(x\sim p_x\)
+
\(z\sim \mathcal N(0,\sigma^2 I)\)
\(y = A x + z\)
\(A~ \cdot\)
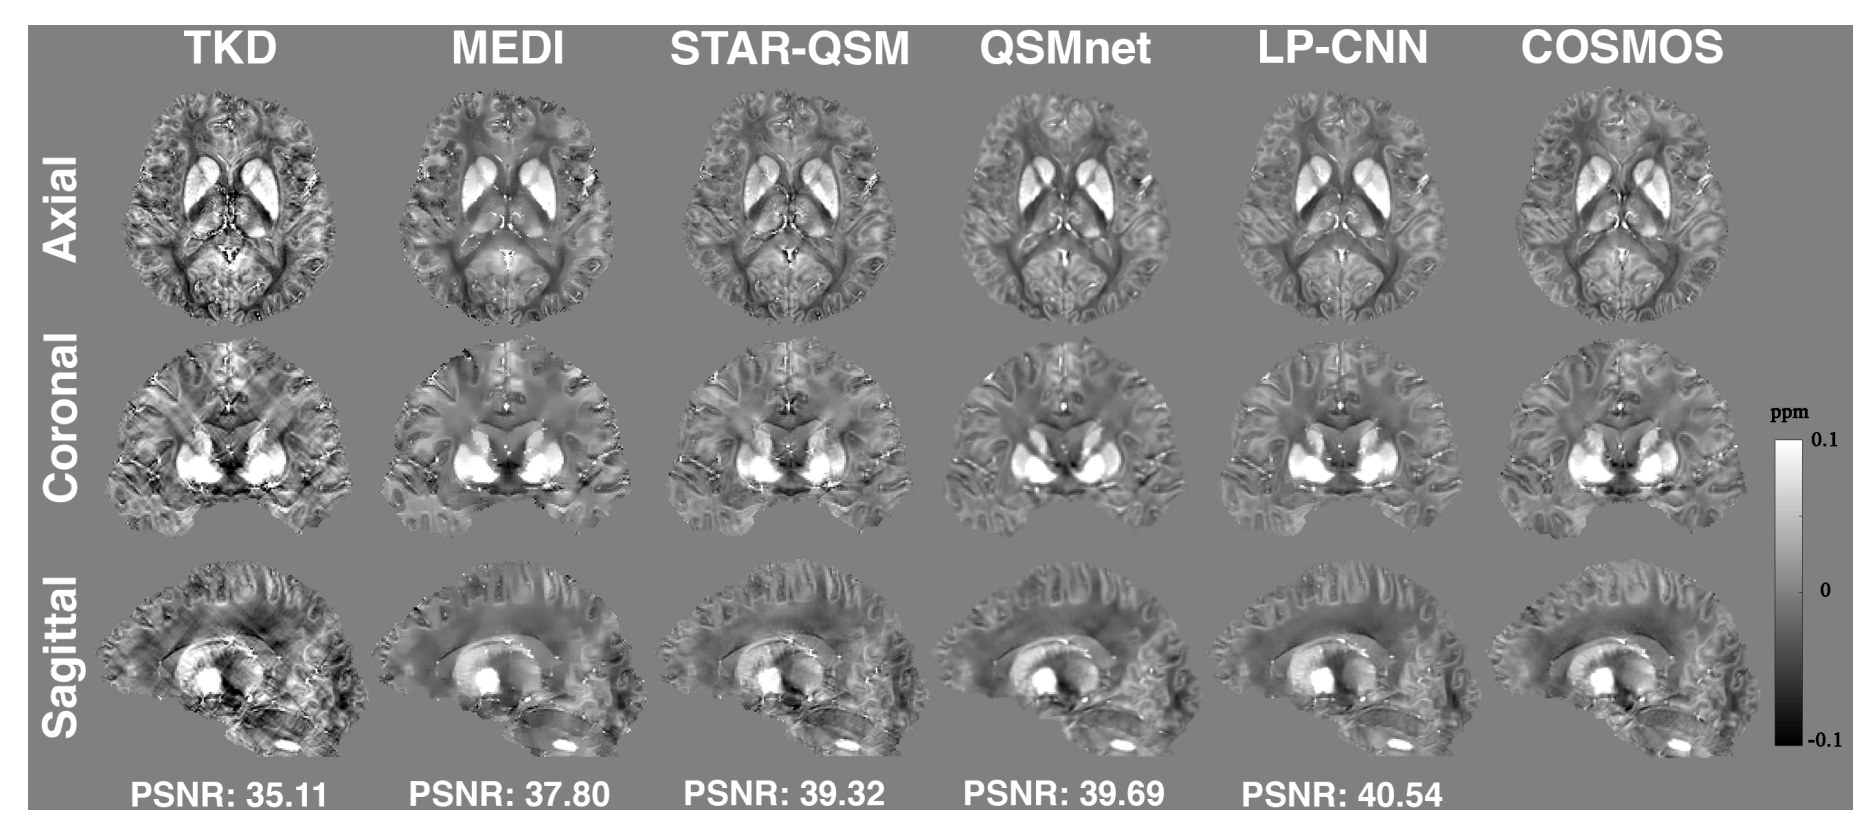
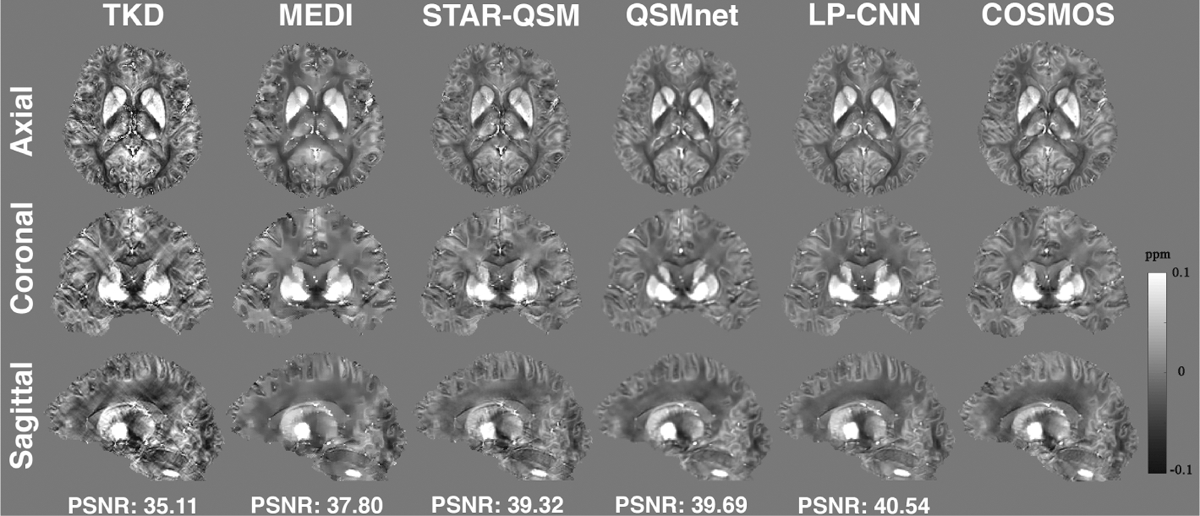
Quantitative Susceptibility Mapping
[Lai, Kuo-Wei, et al. "Learned proximal networks for quantitative susceptibility mapping." International Conference on Medical Image Computing and Computer-Assisted Intervention. Cham: Springer International Publishing, 2020.]
[Fang, Zhenghan, et al. "DeepSTI: Towards tensor reconstruction using fewer orientations in susceptibility tensor imaging." Medical image analysis 87 (2023): 102829.]
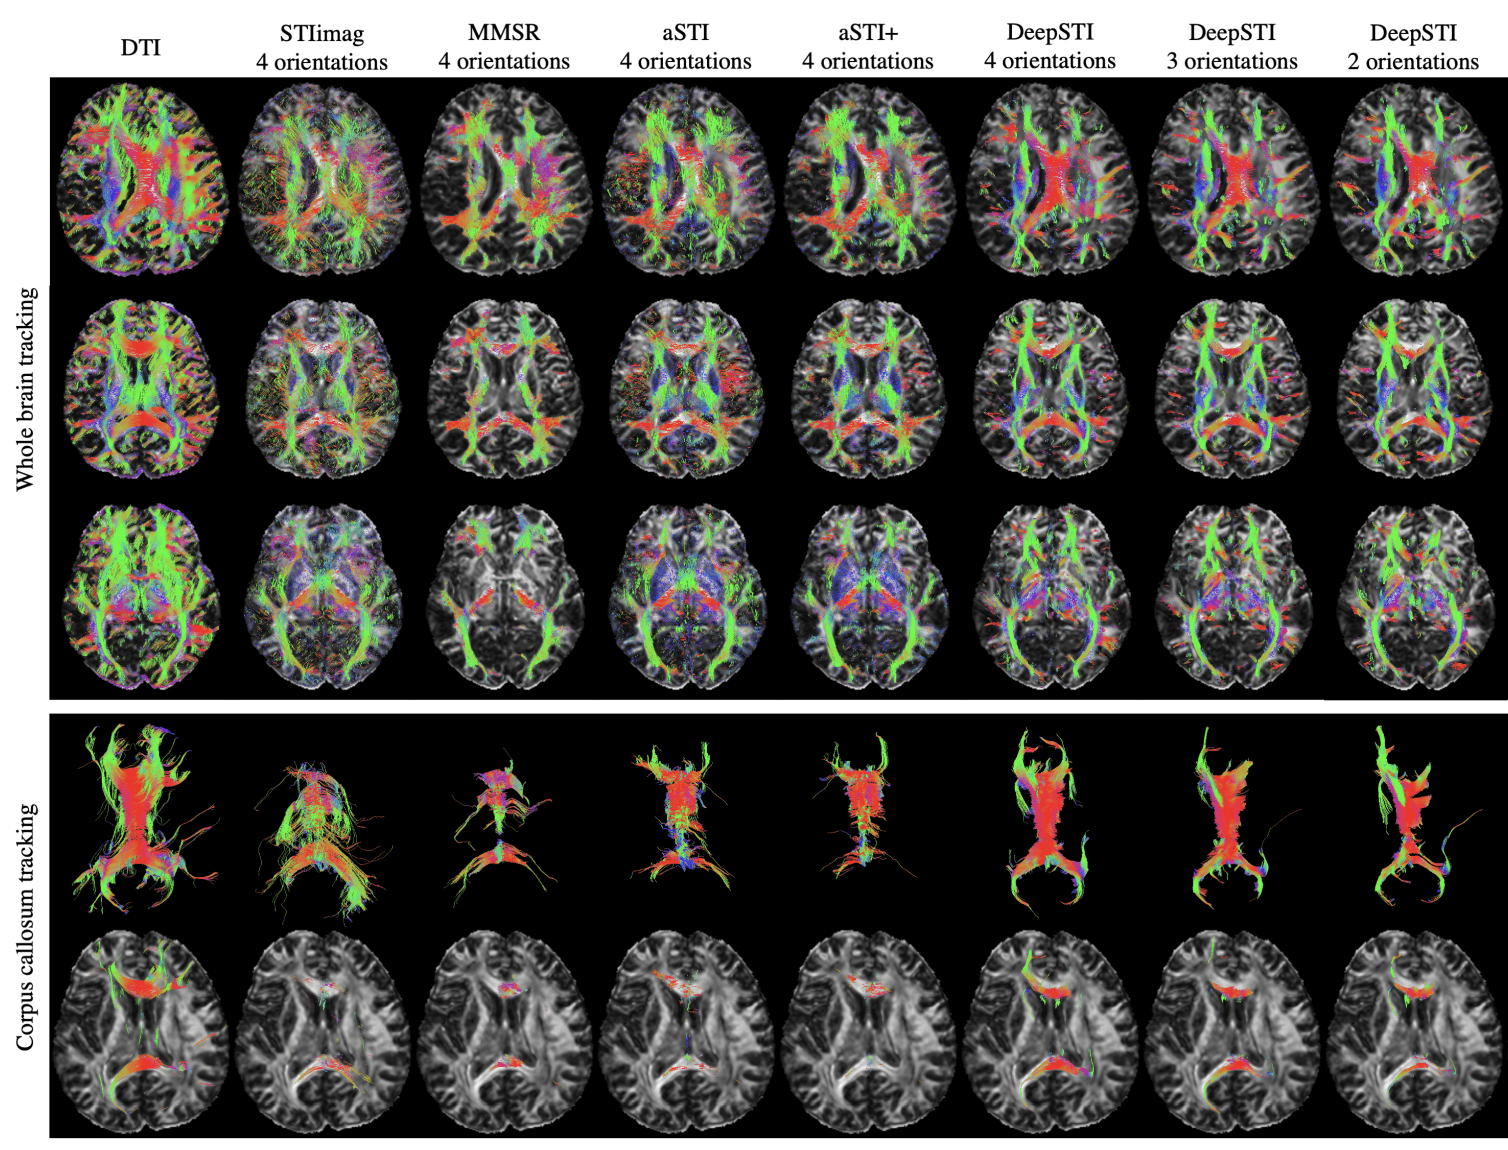
Susceptibility Tensor Imaging
[Fang, Zhenghan, et al. "DeepSTI: Towards tensor reconstruction using fewer orientations in susceptibility tensor imaging." Medical image analysis 87 (2023): 102829.]
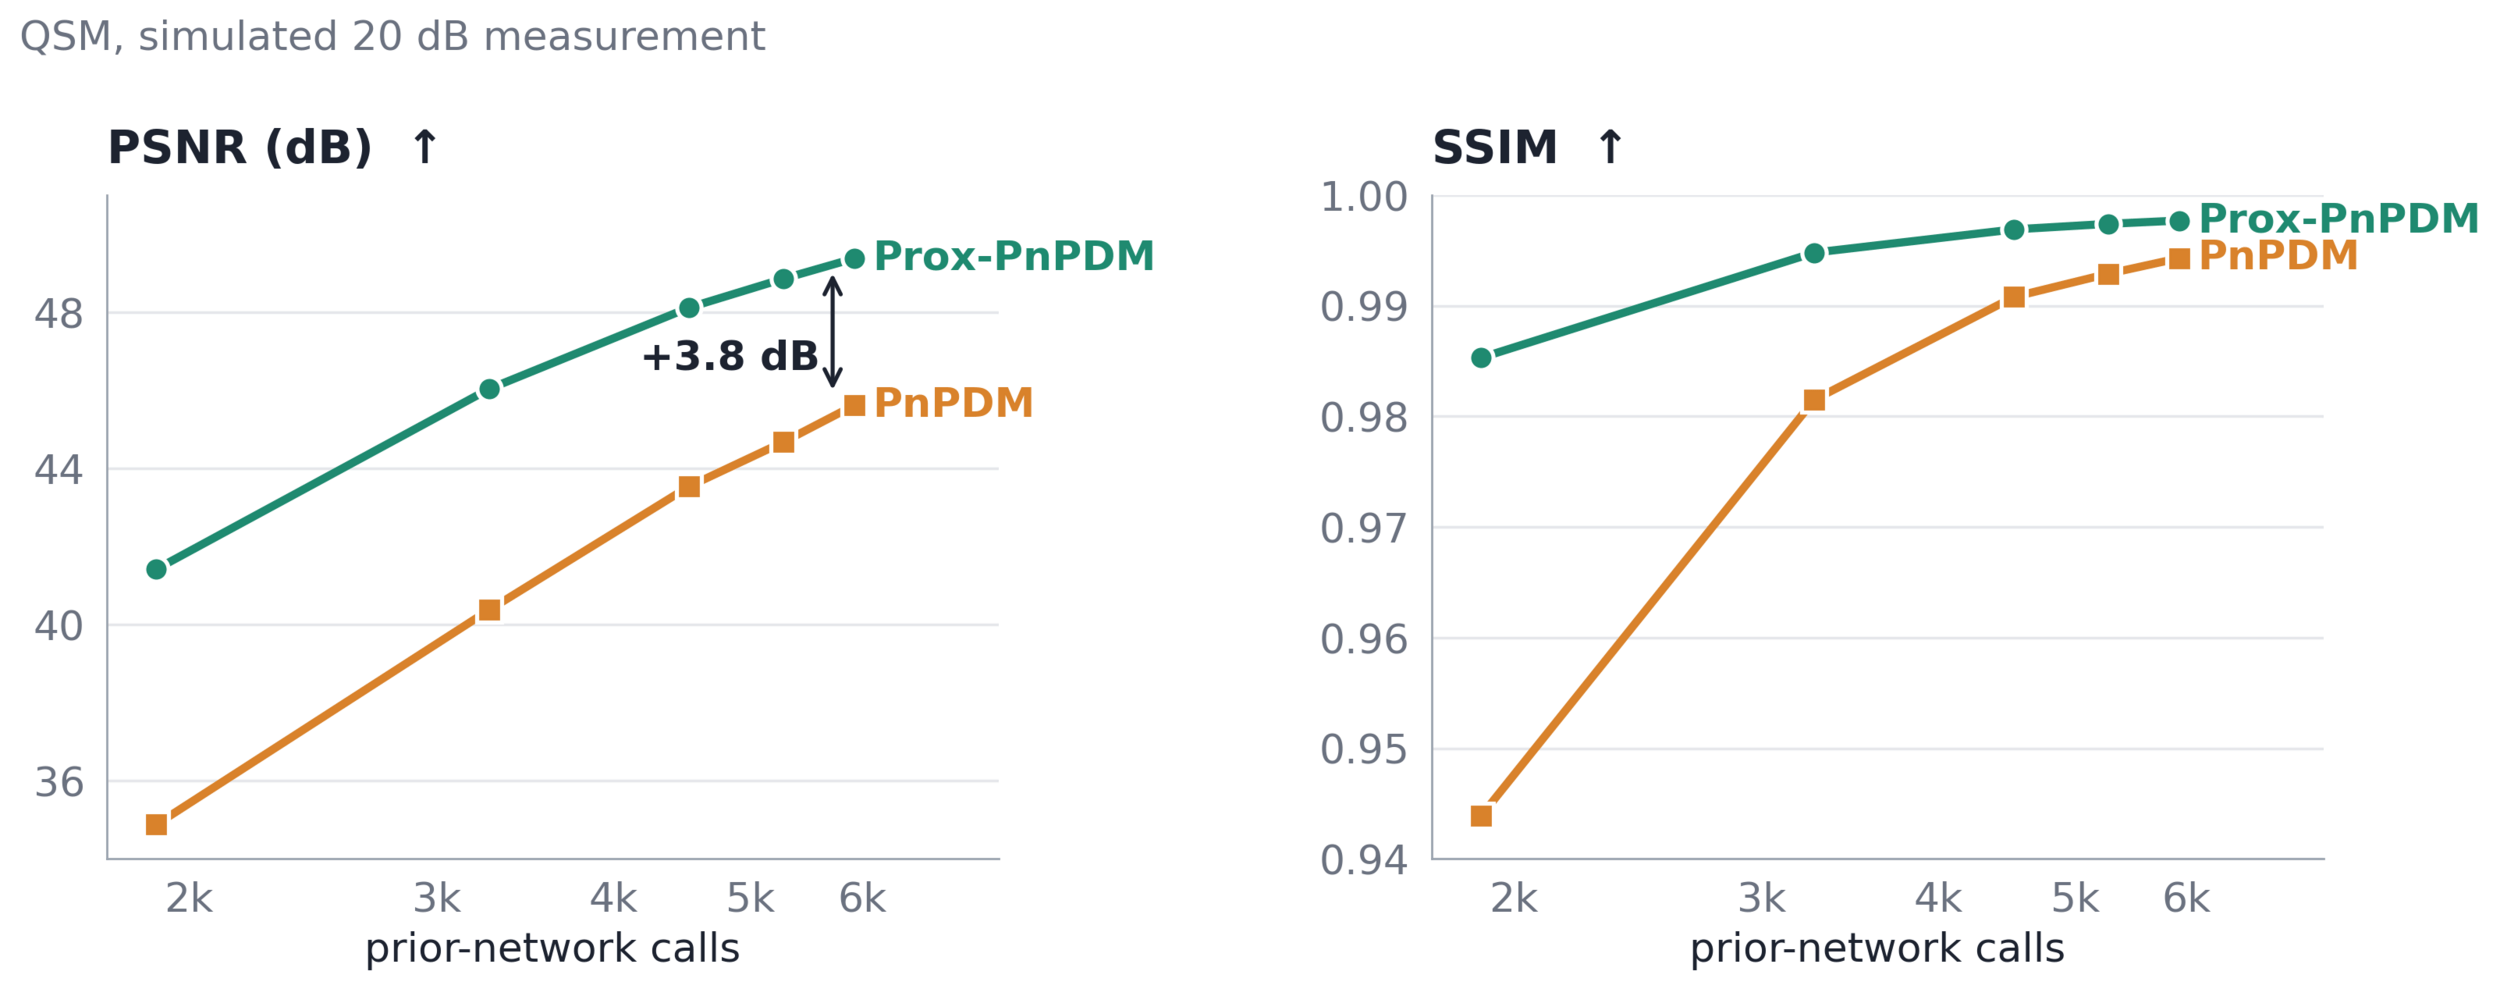
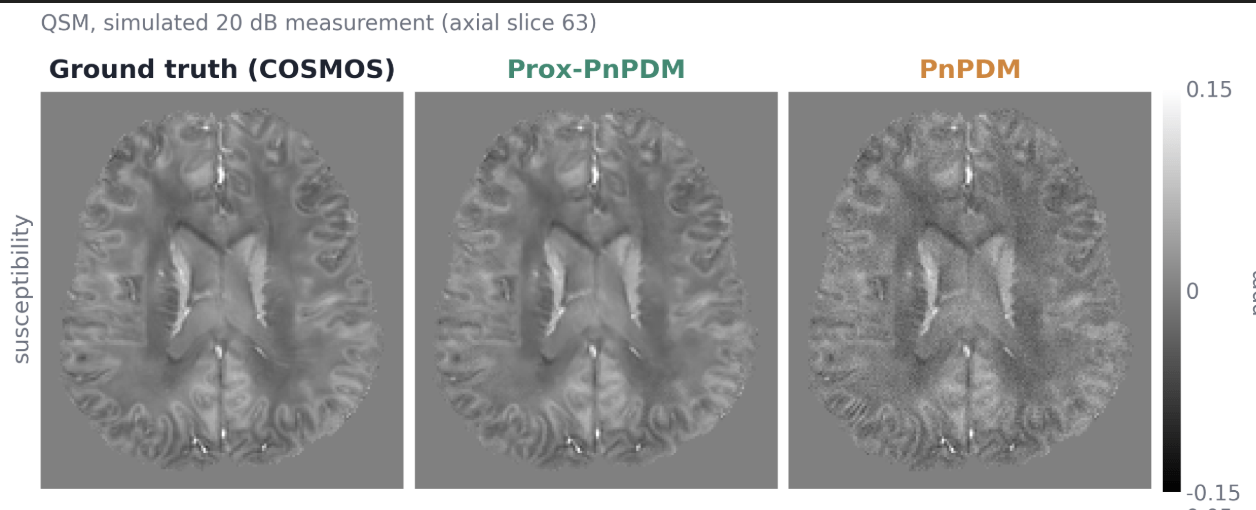
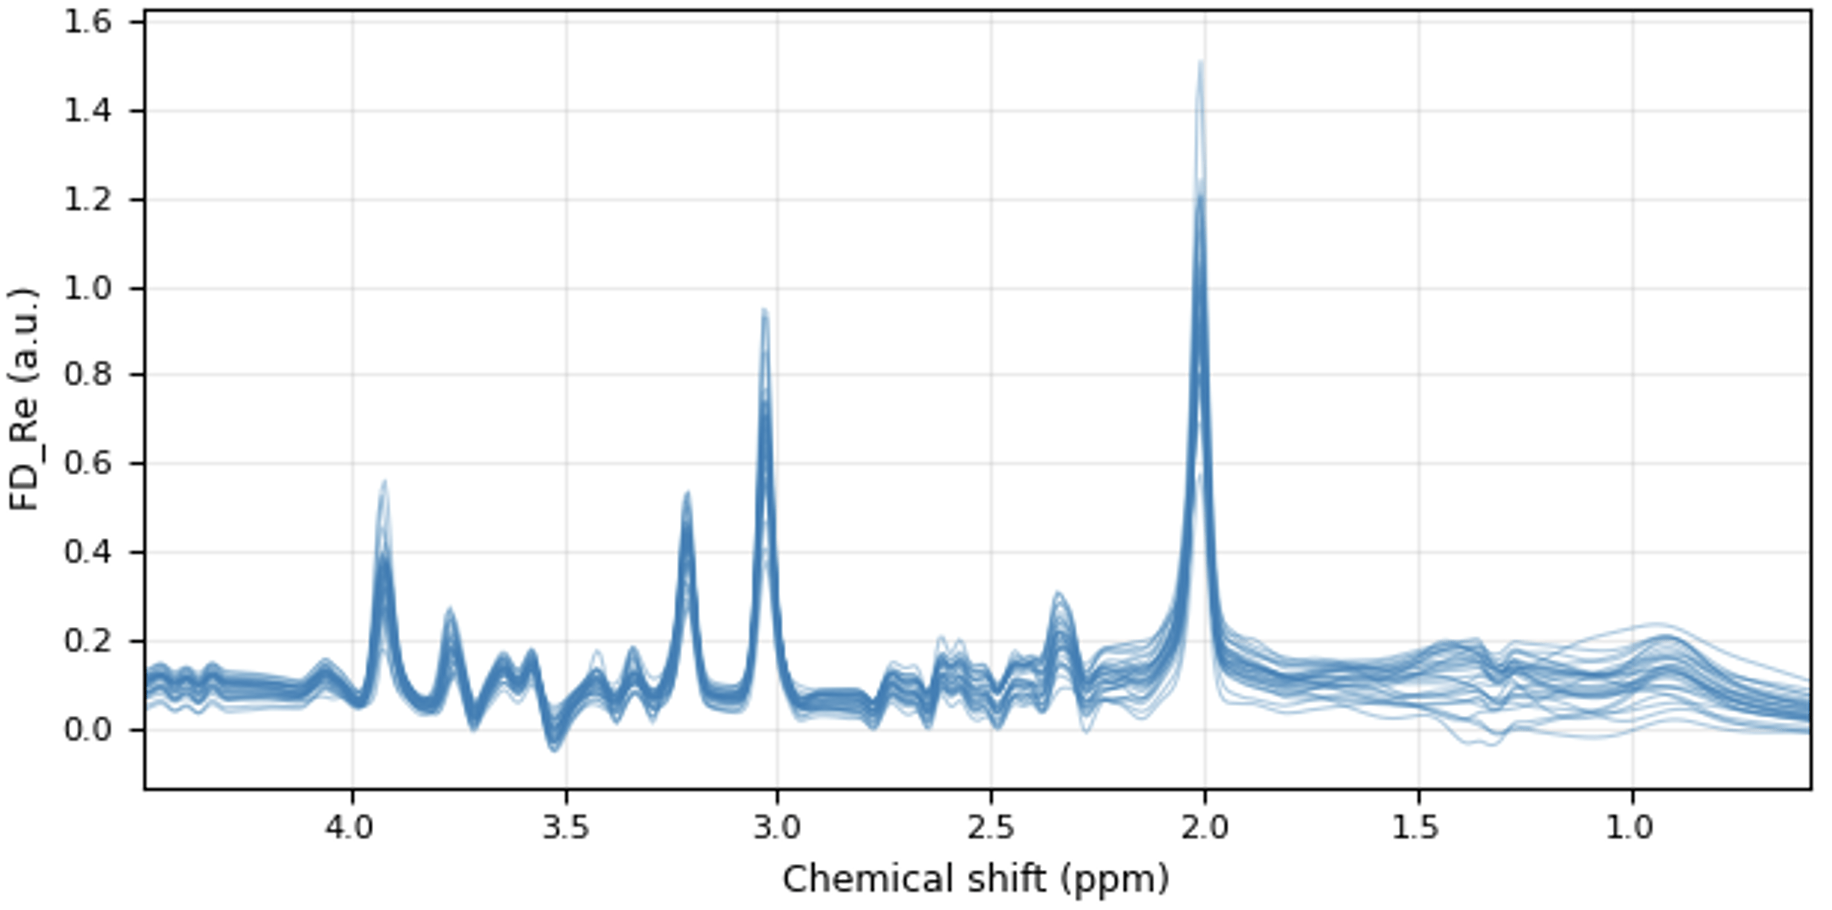
Conditional (Prox) Diffusion Sampling
baseline
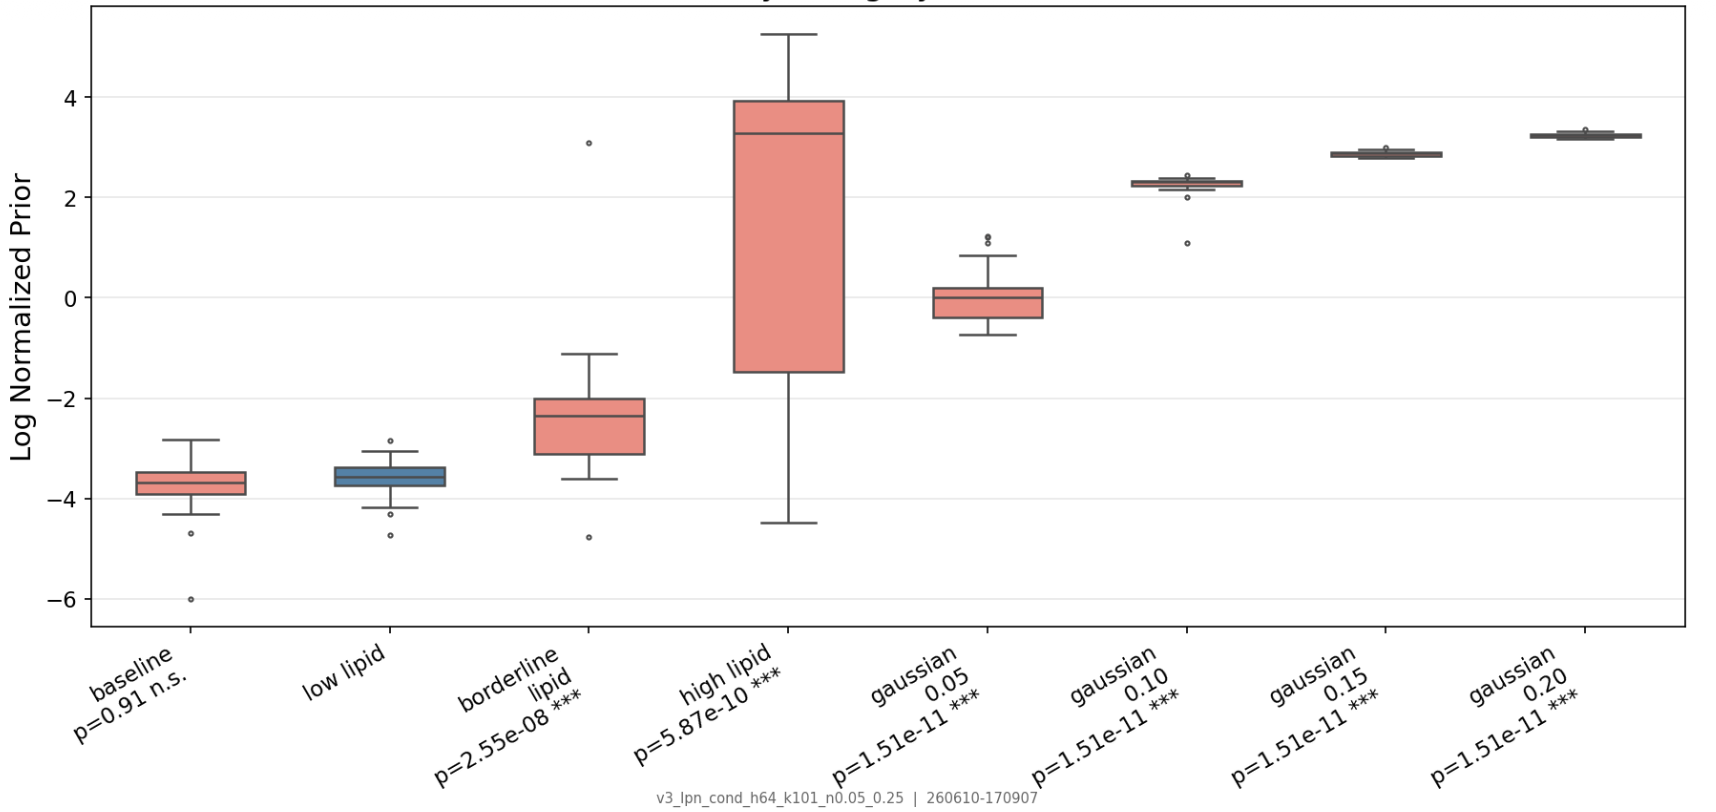
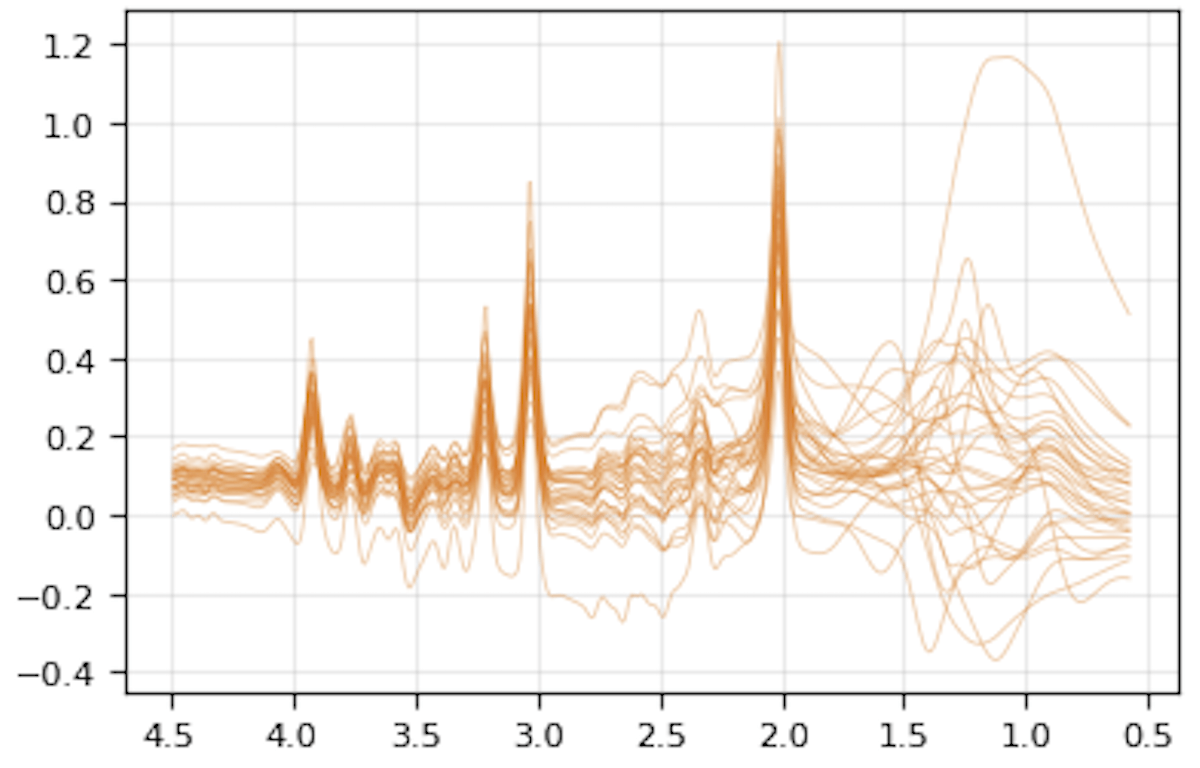
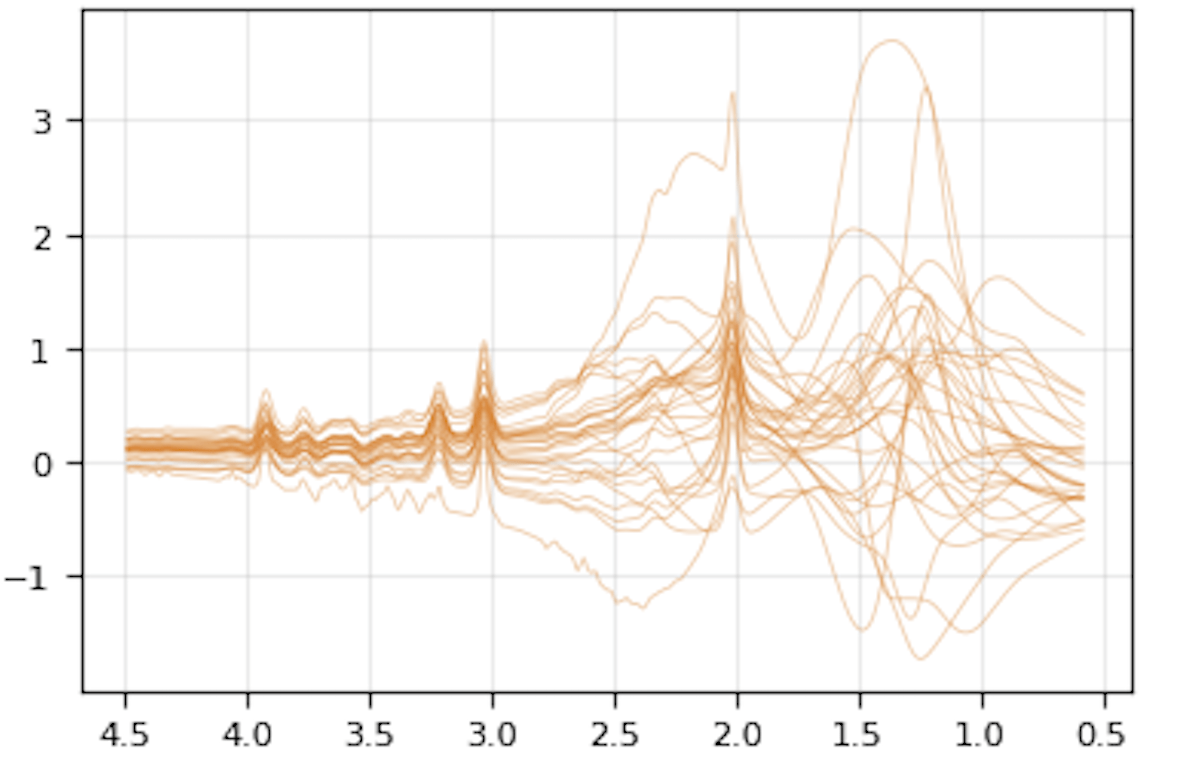
Priors for MR Spectroscopy
data-driven imagingautomatic analysis and rec.societal implicationsProblems in trustworthy biomedical imaging
inverse problems
uncertainty quantification
robustness
generalization
demographic fairness
hardware & protocol optimization
model-agnostic interpretability
policy & regulation
monitoring & auditing
in a box
Denoiser
Measurements
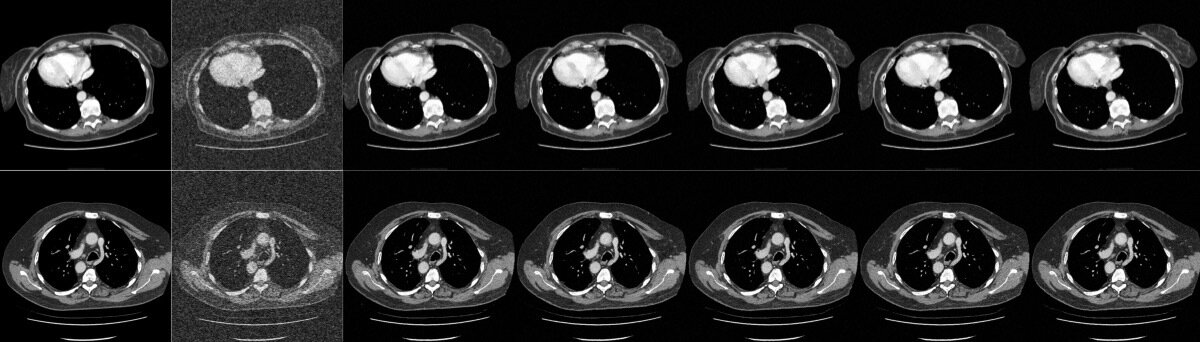
Reconstruction
Uncertainty Quantification
(point predictors)
What is the uncertainty in the guess ?
How do we report uncertainty rigorously?
\(y = Ax + z\)
Measurements
Sampling
(predictive distribution)
What is the uncertainty in the guess ?
How do we report uncertainty rigorously?
Uncertainty Quantification
\(y = Ax + z\)
in a box
Denoiser
Uncertainty through Prediction Sets
How do we construct them?
- pixel-wise mean standard deviation
- Quantile regression
- MC-dropout (Gal & Ghahramani, 2016)
- any other heuristics...
Miscoverage:
Uncertainty through Prediction Sets
ground truth!
\(x_j\)
Uncertainty through Prediction Sets
Given a calibration set \(S_\text{cal} = \{x_i,y_i\},\) provides a simple procedure so that
\(\mathbb{E} [\ell(C(y),x))]\leq \epsilon \)
(distribution free!)
Conformal Risk Control:
[Angelopoulos et al, 2024]
Observation 1: Single for all dimensions... suboptimal
Uncertainty through Prediction Sets
Observation 1: Single for all dimensions... suboptimal
Observation 2: High-dim data is heterogenous
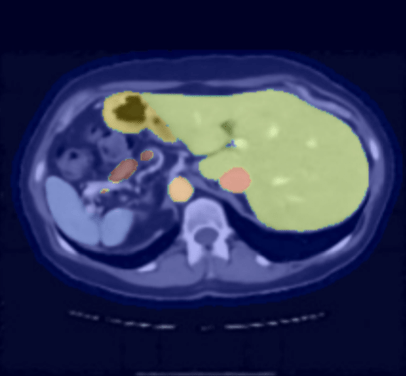
\(\lambda_j\) for each \(j^\text{th}\) organ
Uncertainty through Prediction Sets
Semantic Uncertainty Quantification
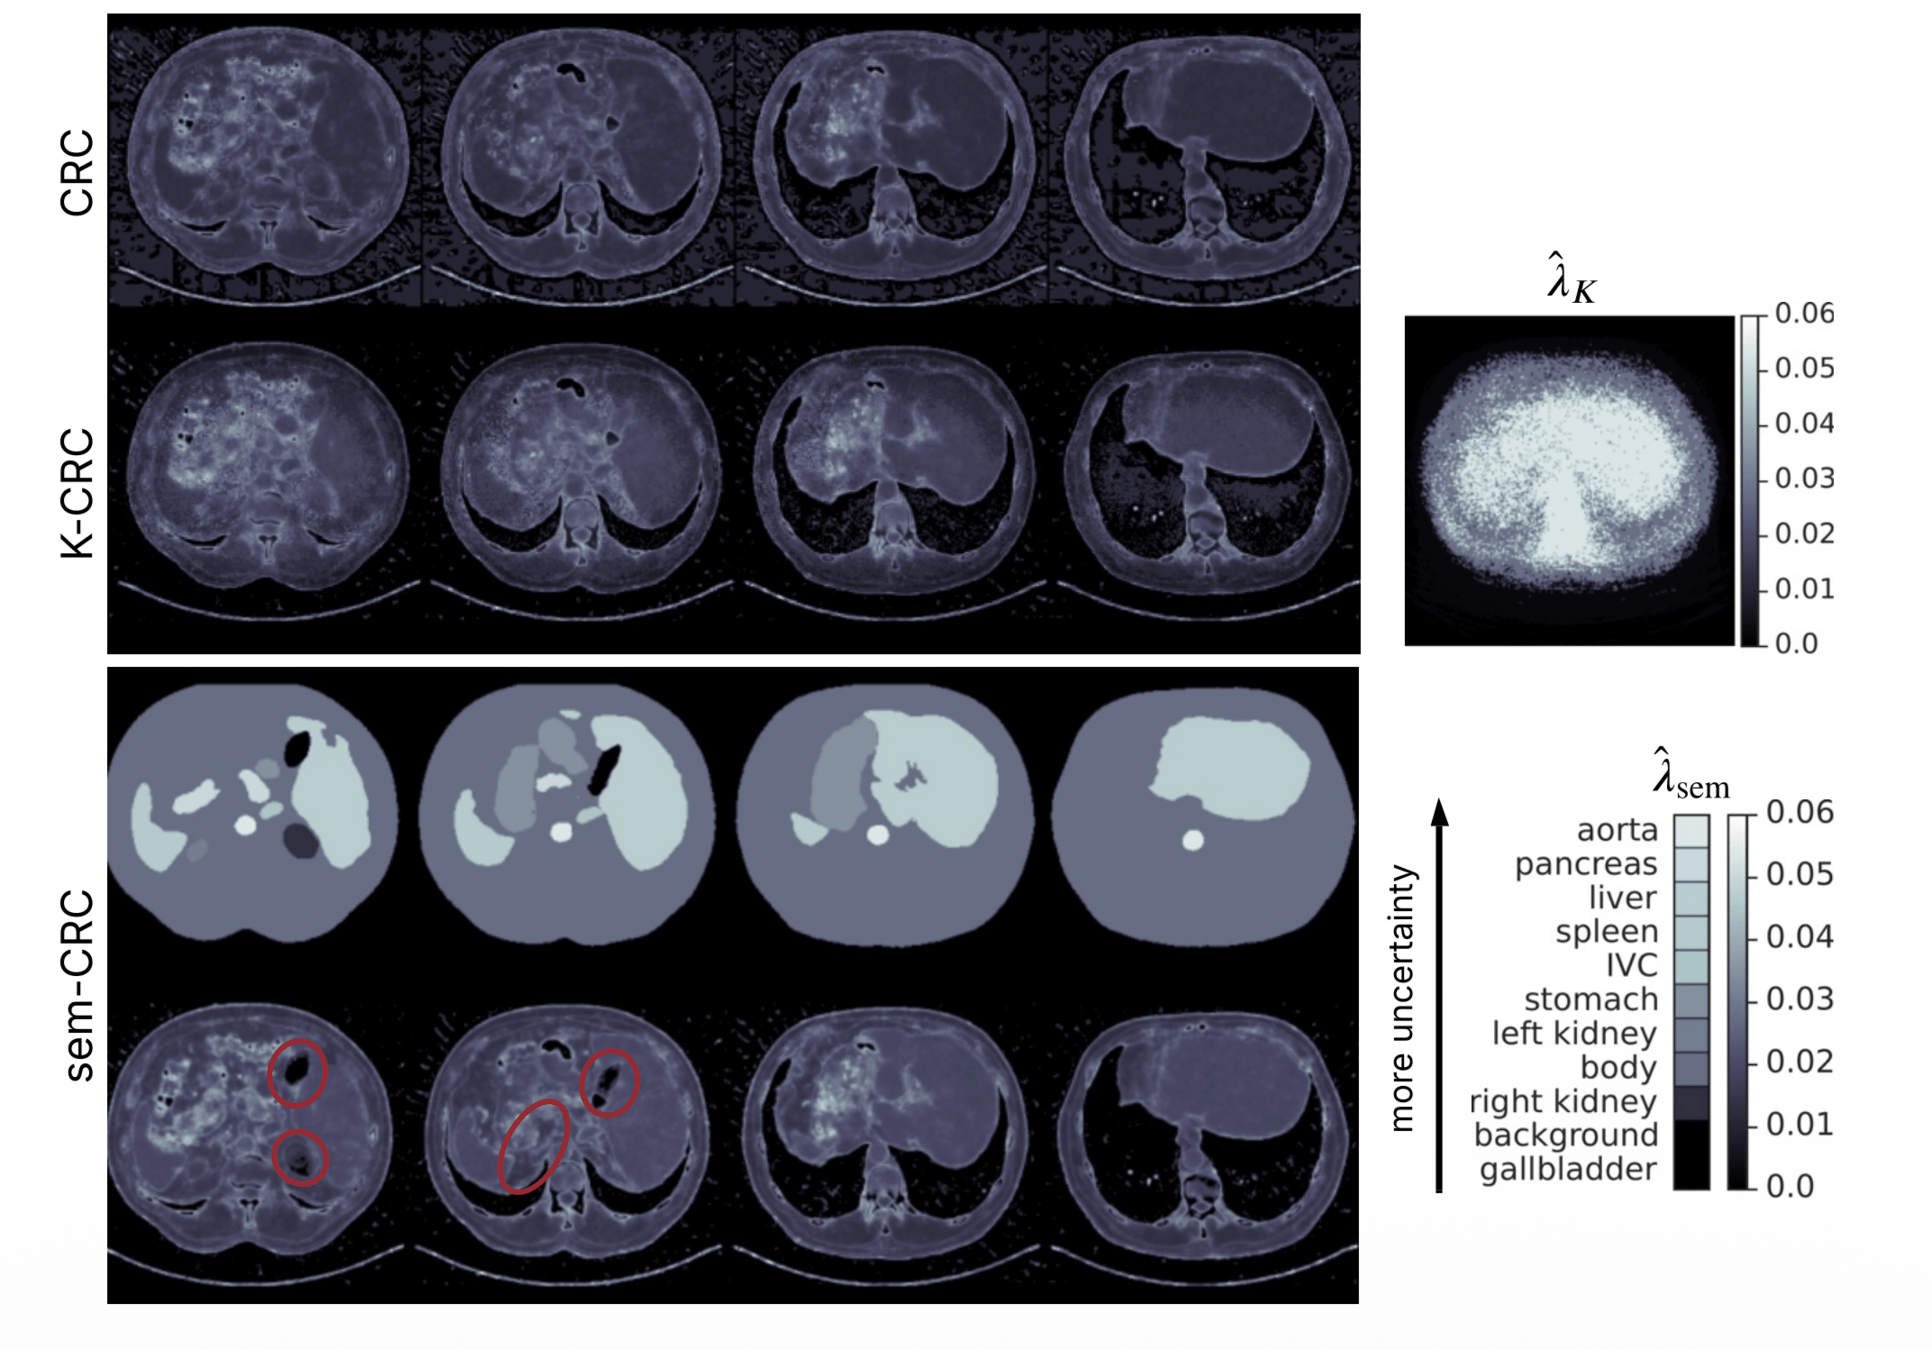
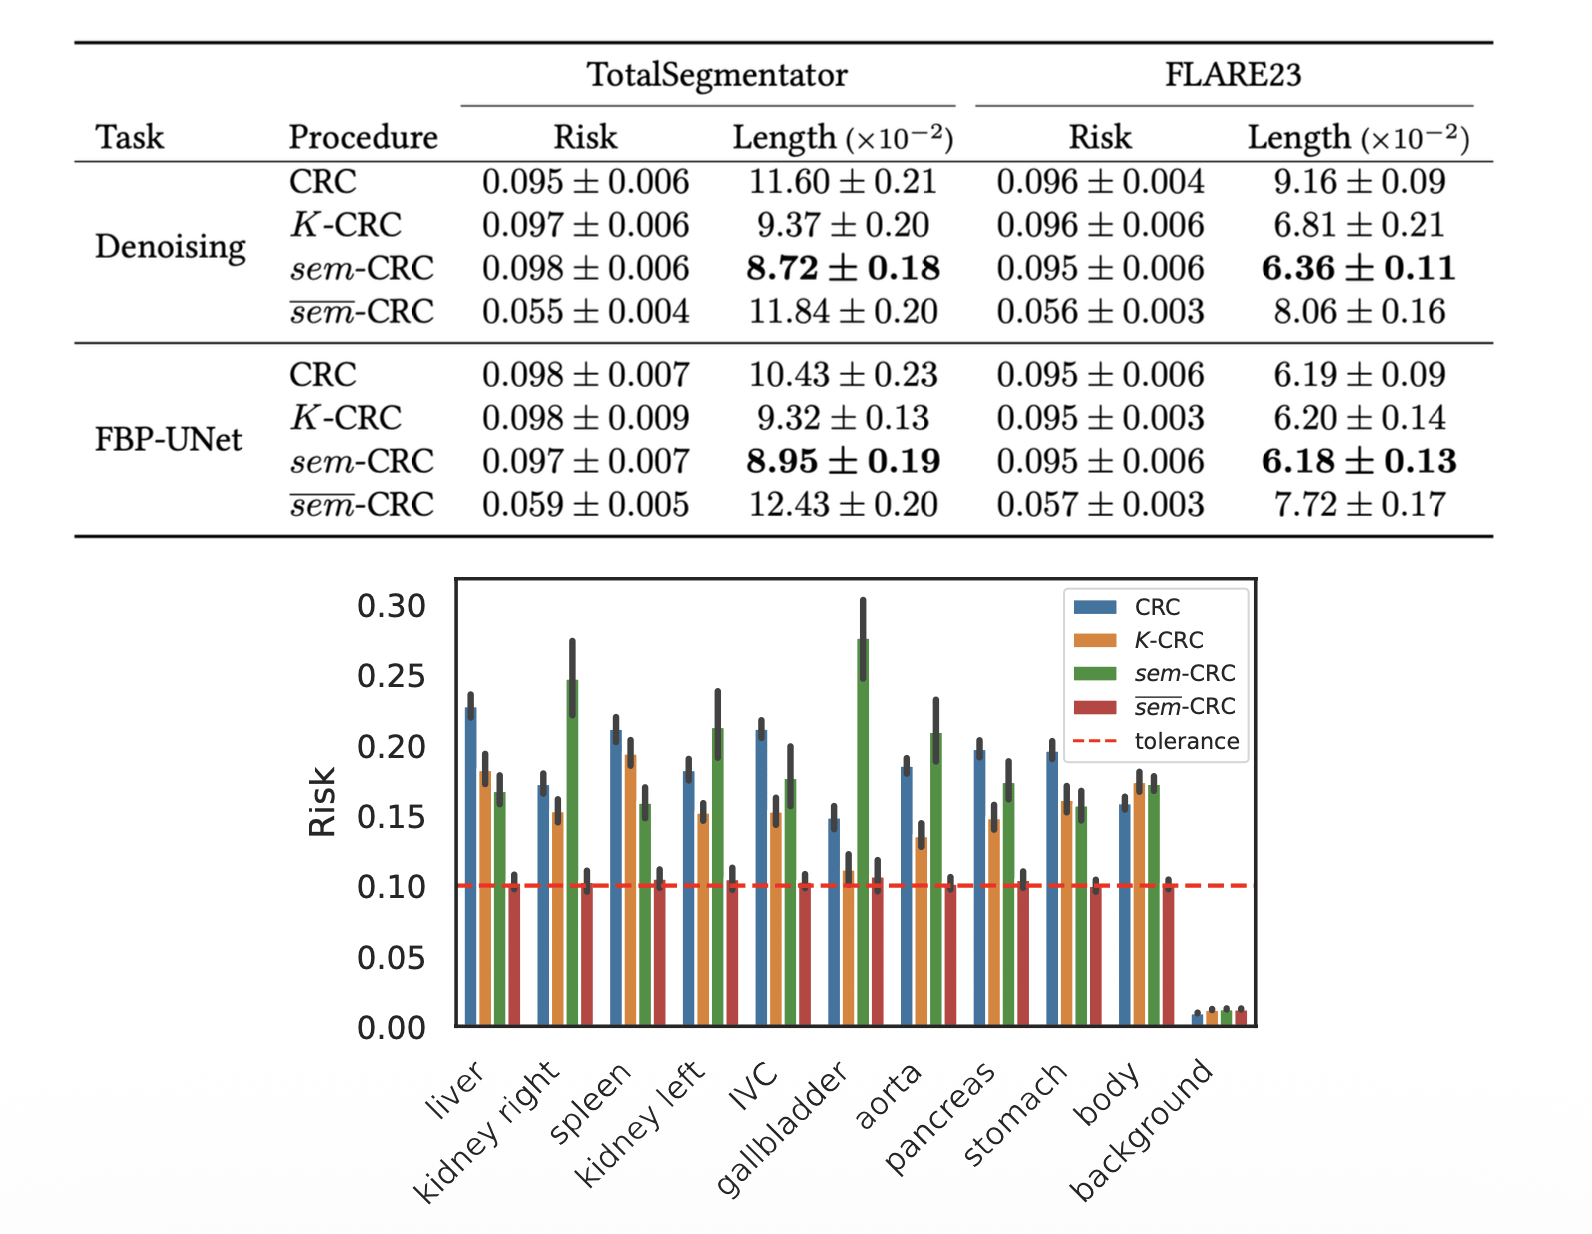
risk controlled uniformly for every organ
[Teneggi, Jacopo, J. Webster Stayman, and Jeremias Sulam. "Conformal risk control for semantic uncertainty quantification in computed tomography." MICCAI , 2025.]
data-driven imagingautomatic analysis and rec.societal implicationsProblems in trustworthy biomedical imaging
inverse problems
uncertainty quantification
robustness
generalization
demographic fairness
hardware & protocol optimization
model-agnostic interpretability
policy & regulation
monitoring & auditing
Acknowledgements
Jacopo Teneggi
Zhenghan Fang
Yuqing He
Xu Li
Peter van Zijl
Georg Oeltzschner
Chris Davies-Jenkins
policy & regulation
robustness
generalization
uncertainty quantification
Mathematical tractability vs Complexity
in a box
simpler models
more assumptions
any model
no assumptions
Denoiser
Linear models
Linear networks
Shallow
ReLU Networks
Just ask GPT
Conformal guarantees
Bayesian
MC Dropout
Problems in Biomedical Imaging EMPT 2026
By Jeremias Sulam