
russtedrake PRO
Roboticist at Walden Robotics and MIT
MIT 6.4210/2: Robotic Manipulation
Fall 2023, Lecture 1
Follow live at https://slides.com/d/sE8qYNg/live
(or later at https://slides.com/russtedrake/fall23-lec01)
Website: http://manipulation.mit.edu
Communications Instructors from Comparative Media Studies/Writing
Recitations Fridays afternoons (starting Sept 15)
from the course website:
Matthew T. Mason. Toward Robotic Manipulation. Annual Review of Control, Robotics, and Autonomous Systems, 1:1-28, 2018.
Low-level feedback control from cameras / sensors
(continuous time/state/action)
Scene-understanding +
Task-level Planning
(discrete/symbolic)
The world is even more "open" when the manipulation system goes mobile.
One goal for this year:
more mobile manipulation
(in lecture + projects)
To be clear: we're not just controlling the arm
state of the robot x state of the environment
Levine*, Finn*, Darrel, Abbeel, JMLR 2016
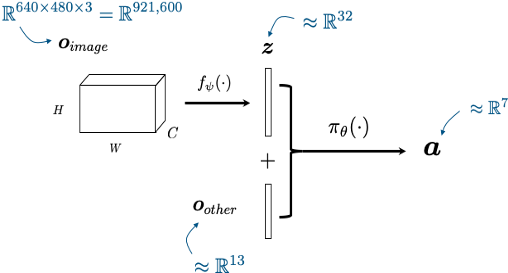
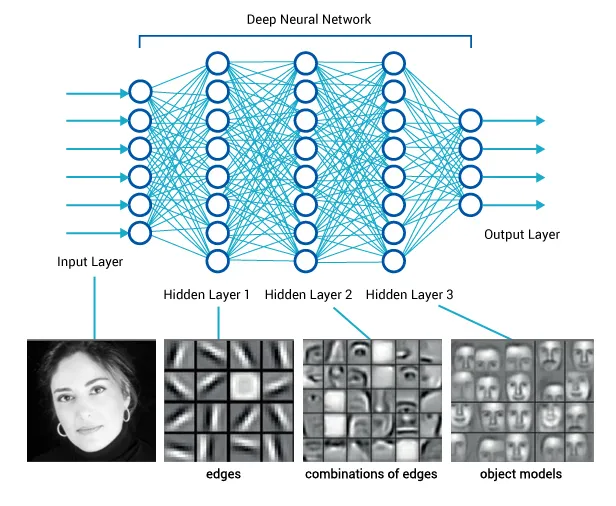
perception network
(often pre-trained)
policy network
other robot sensors
learned state representation
actions
Manipulation is much more than "pick and place"!
By russtedrake
MIT Robotic Manipulation Fall 2023 http://manipulation.mit.edu